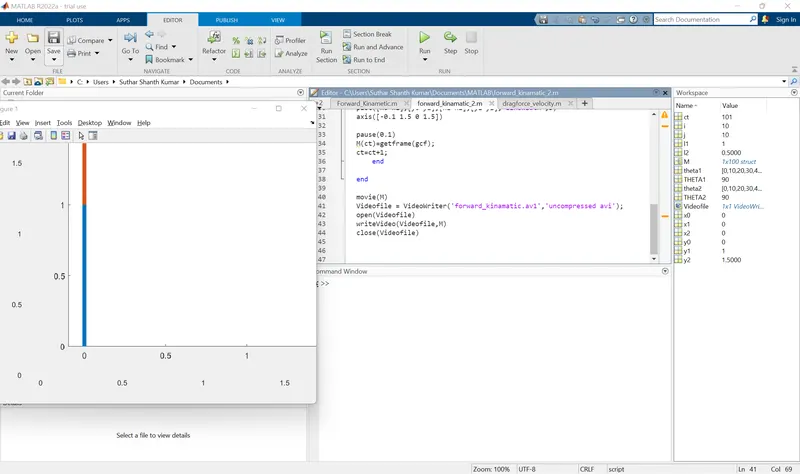
Week 2- 2R Robotic Arm Challenge
AIM: To write a program to simulate the forward kinematics of a 2R Robotic Arm in Matlab.
Theory : A robotic arm is a robot manipulator, usually programmable, with similar functions to a human arm. The links of such a manipulator are connected by joints allowing either rotational motion (such as in an articulated robot) or translational (linear) displacement. The links of the manipulator can be considered to form a kinematic chain. The use of industrial robots is increasing in areas such as food, consumer goods, wood, plastics and electronics, but is still mostly concentrated in the automotive industry.
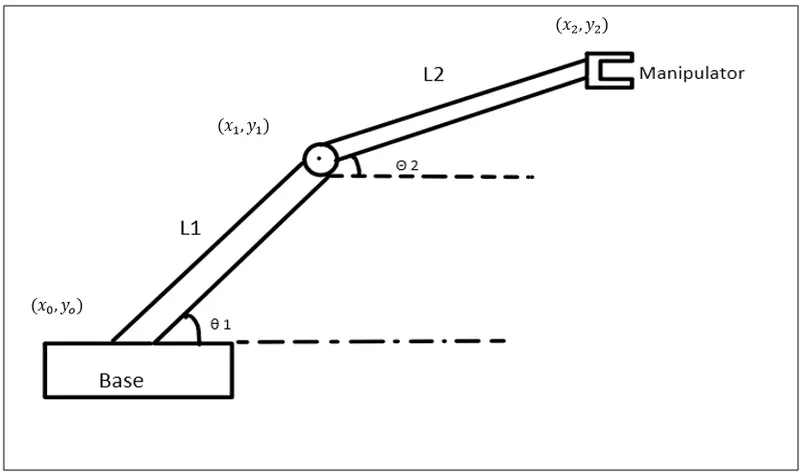
MATLAB PROGRAM:
% Forward Kinematics of a 2R robotics arm manipulator
clear all
close all
clc
% Inputs
l1 = 1;
l2 = 0.5;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1;
for i = 1:length(theta1)
THETA1 = theta1(i);
for j = 1:length(theta2)
THETA2 = theta2(j);
x0 = 0;
y0 = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1 + l2*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);
%plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',5)
axis([-0.1 1.5 0 1.5])
pause(0.1)
M(ct)=getframe(gcf);
ct=ct+1;
end
end
movie(M)
Videofile = VideoWriter('forward_kinamatic.av1','uncompressed avi');
open(Videofile)
writeVideo(Videofile,M)
close(Videofile)