week-11 Joint creation and Demonstration
Aim:
To create the spherical, revolute, cylindrical, and translational joints between two rigid bodies and two deformable bodies.
OBJECTIVE:
Using the manual (*CONSTRAINED_JOINT keyword) demonstrate spherical, revolute, cylindrical, and translational joints between two rigid bodies and two deformable bodies.
To understand the process, follow the guidelines below:
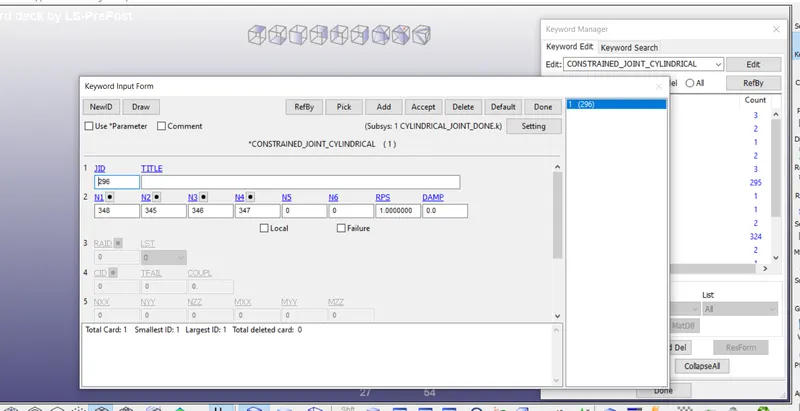
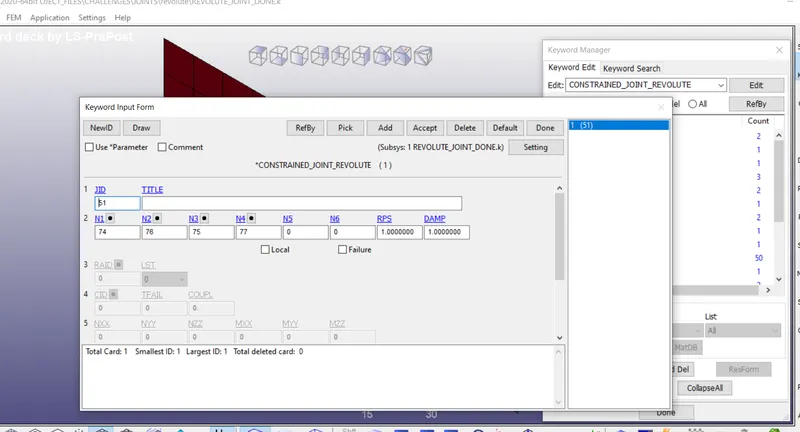
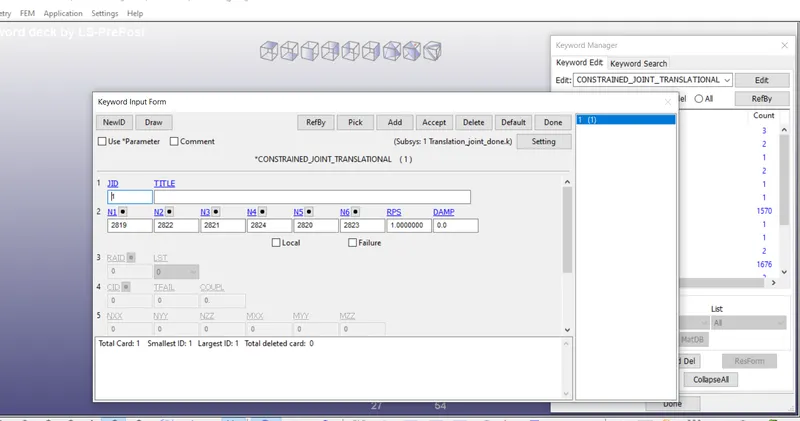
A joint is created using an even number of nodes, out of which every pair has the same position (XYZ coordinate). These nodes should belong to the bodies between which the joint operates.
So for example, for a revolute joint, we will have four nodes and their coordinates can be
NID X Y Z
1 100 120 350
2 100 120 350
3 100 150 350
4 100 150 350
Nodes (1, 3) belongs to body1 and (2,4) belongs to body2. Since the line from node 1 to 3 or node 2 to 4 is the axis of rotation.
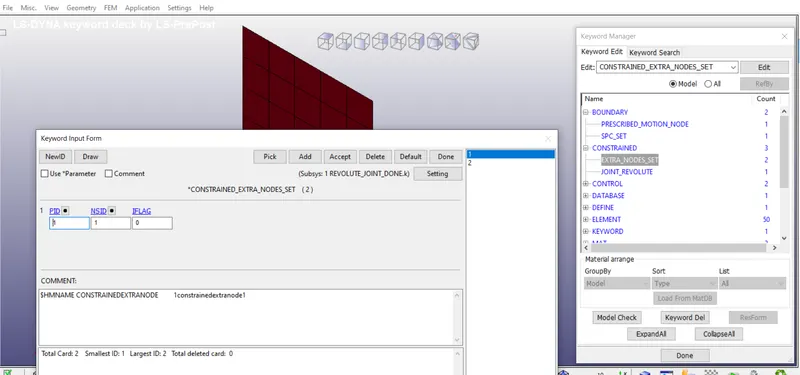
We use *CONSTRAINED_EXTRA_NODES and *CONSTRAINED_NODAL_RIGID_BODY to create joints between rigid and deformable bodies respectively.
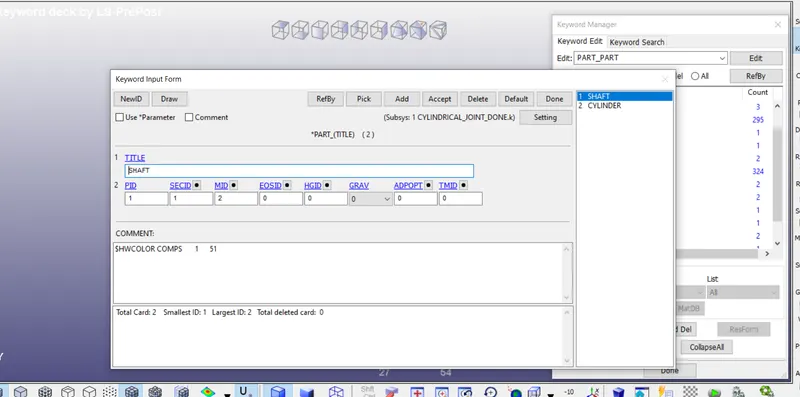
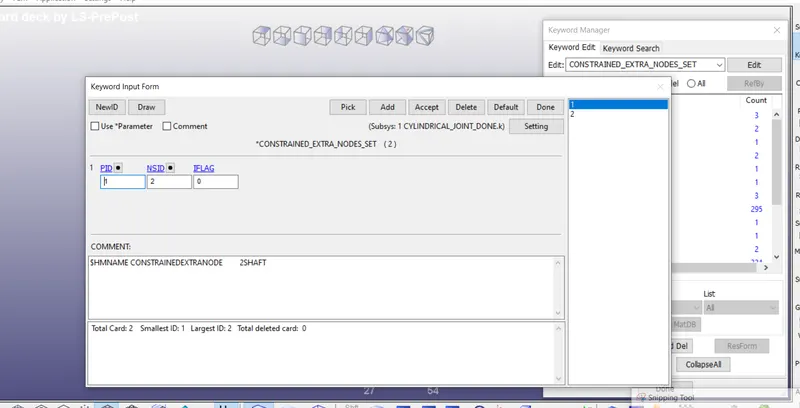
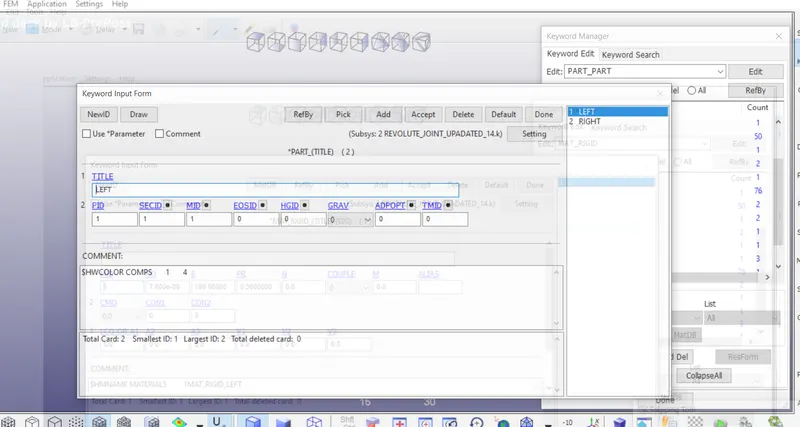
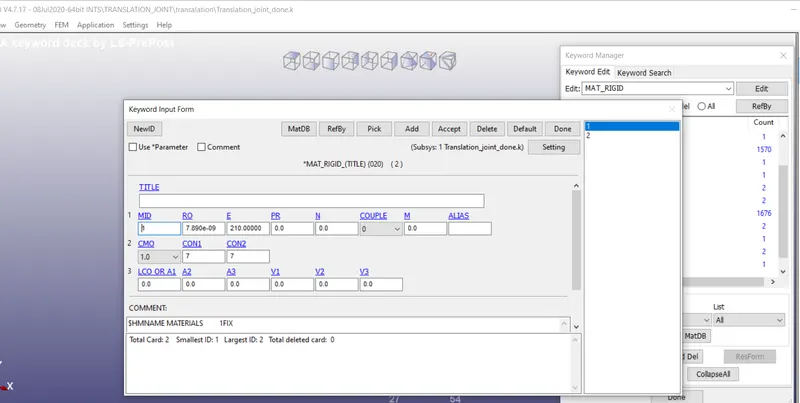
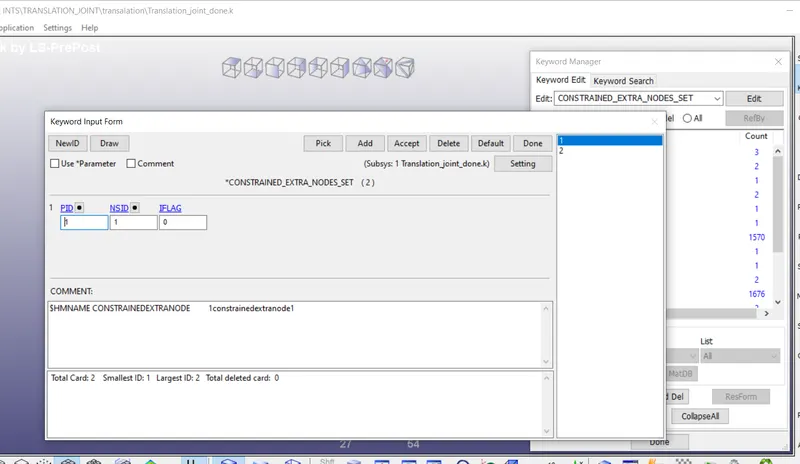
Rigid Body: Once you create the nodes at the required location, use *CONSTRAINED_EXTRA_NODES to include those nodes to the respective rigid bodies.
Deformable Body: The nodes should be part of a *CONSTRAINED_NODAL_RIGID_BODY which has some shared nodes with the deformable body.
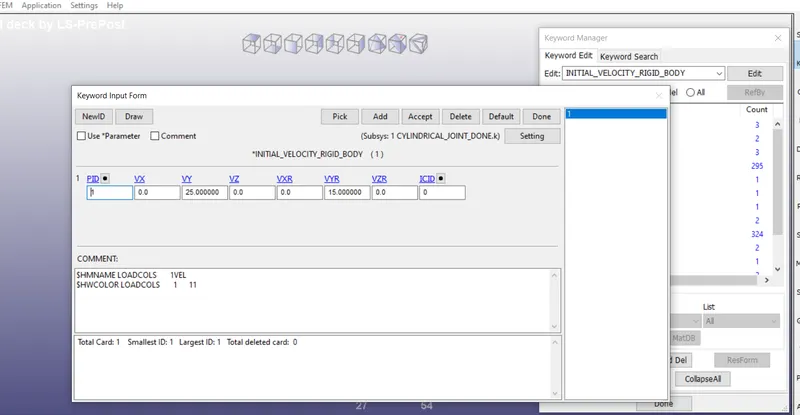
An illustration is shown below on how to demonstrate the joints. However, more creative efforts to show linkages etc. are welcome. To demonstrate the joints' working, rotation and translatory motions should be shown. The final submission should include input files for each of the joints and animations showing their results. This assignment tests a student's ability to go through the manual, understand the topic, and apply it their model since this topic is not extensively covered in the course.
PROCEDURE:
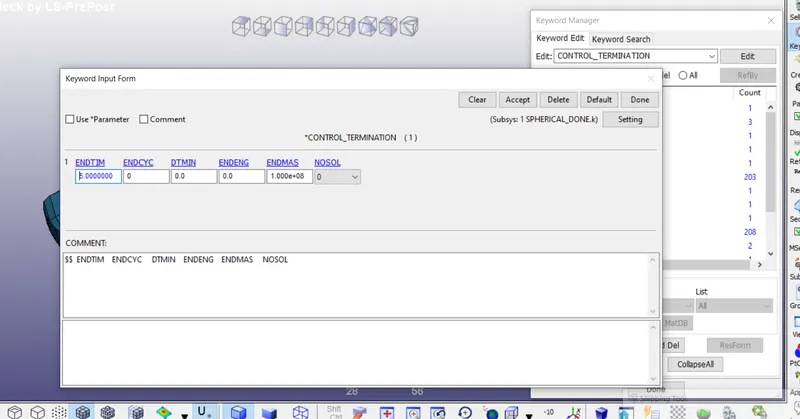
SPHERICAL_JOINT:
JOINT BETWEEN TWO RIGID BODIES:
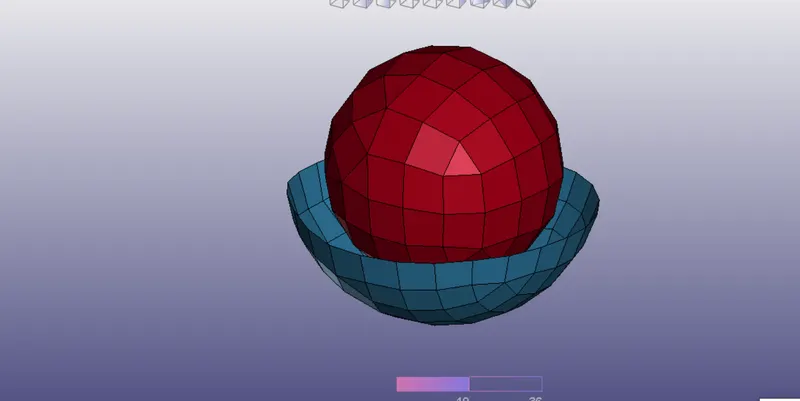
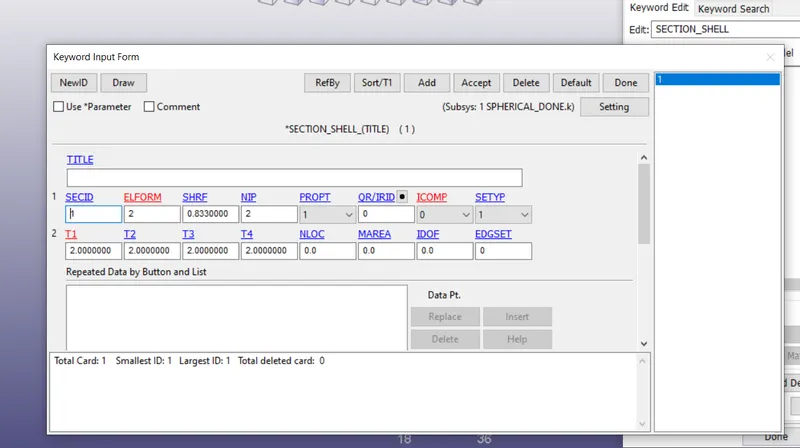
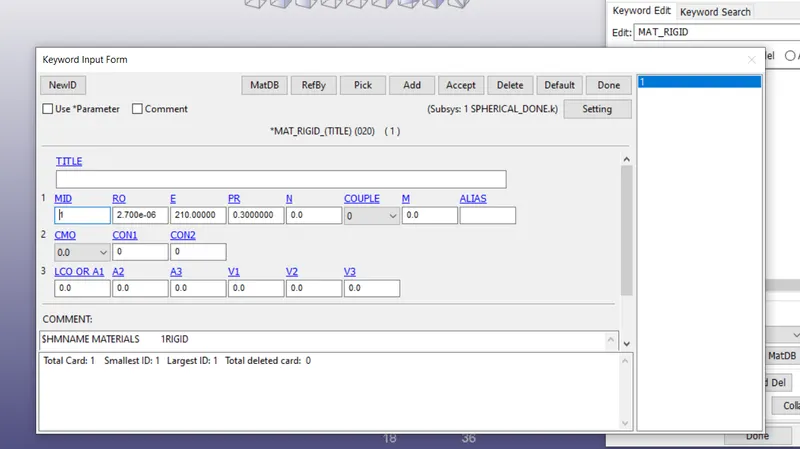
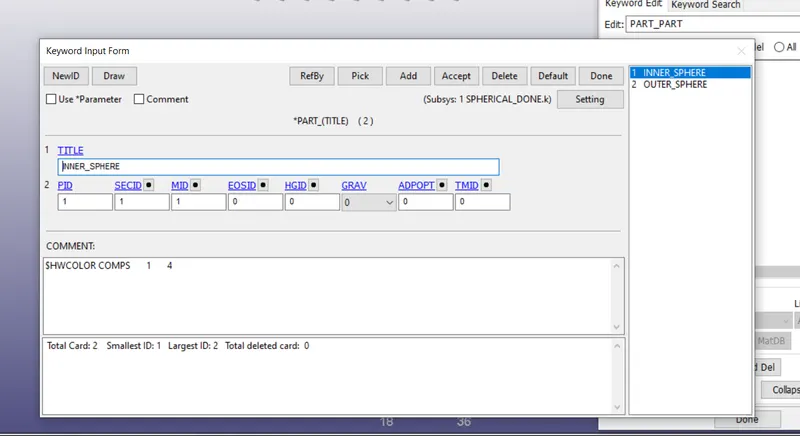
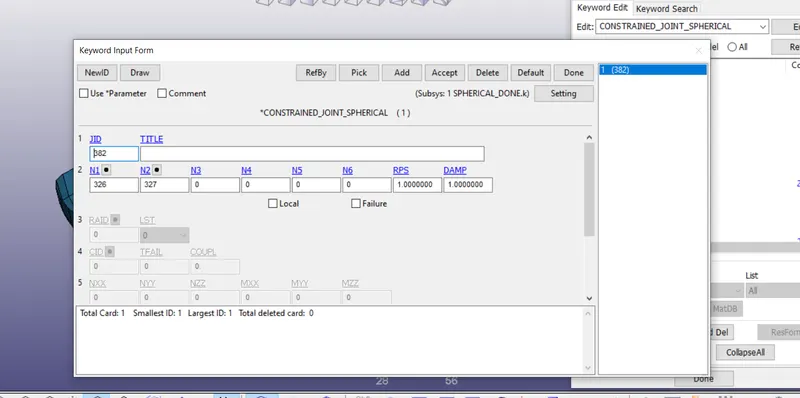
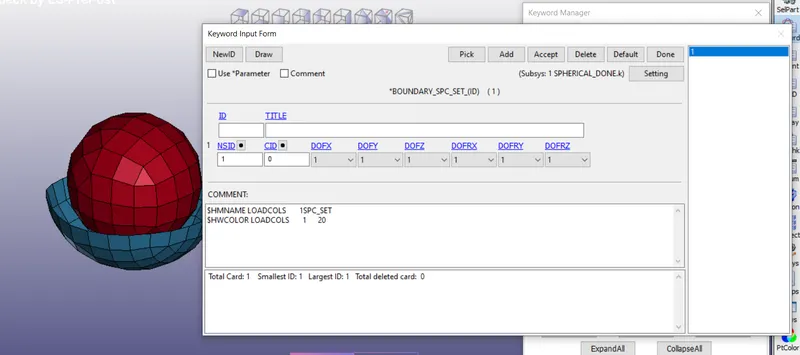
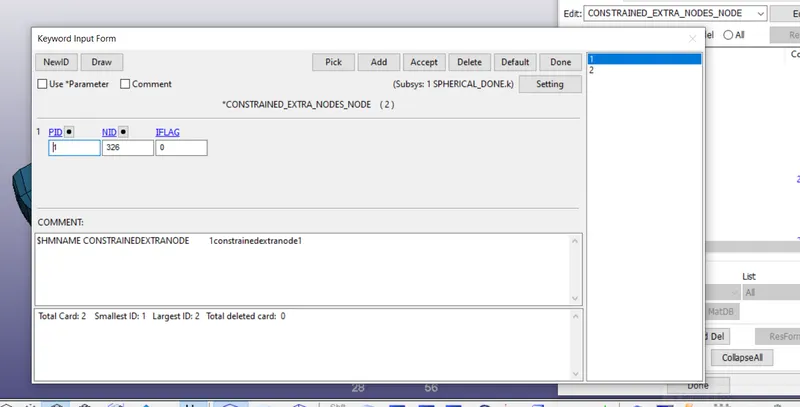
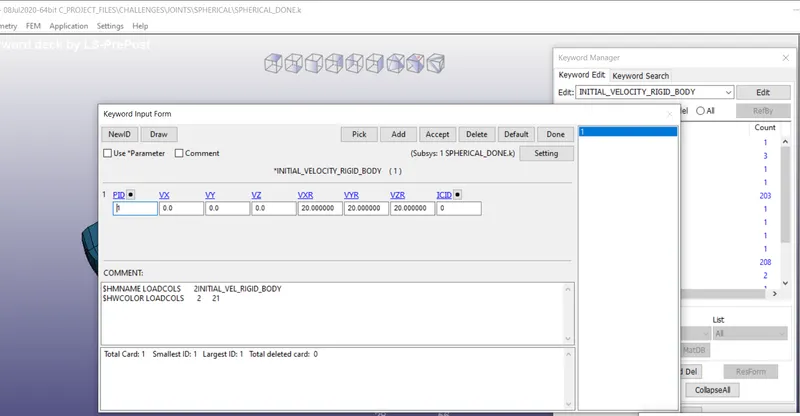
CYLINDRICAL_JOINT:
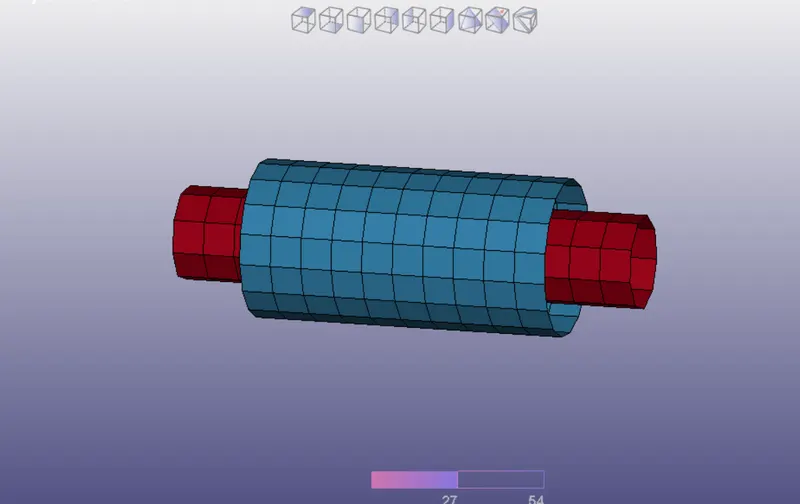
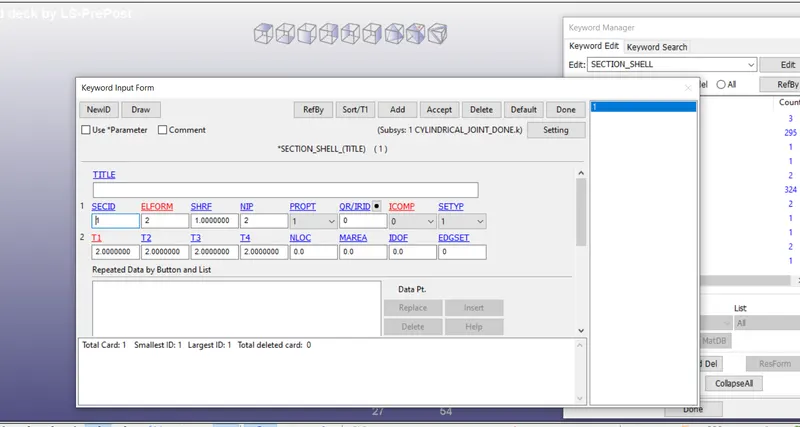
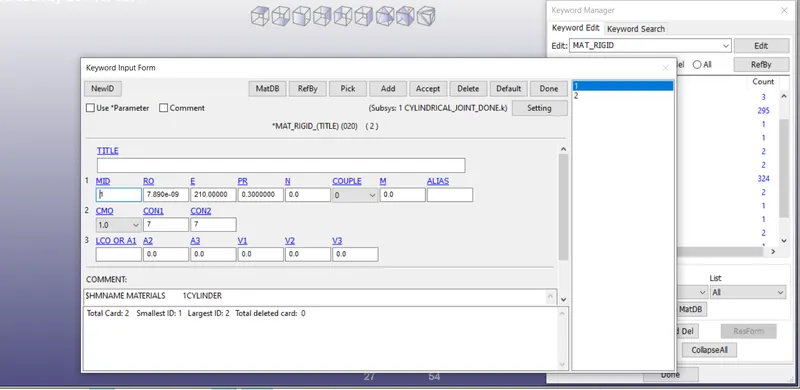
JOINT_BETWEEN_TWO_RIGID_BODIES:
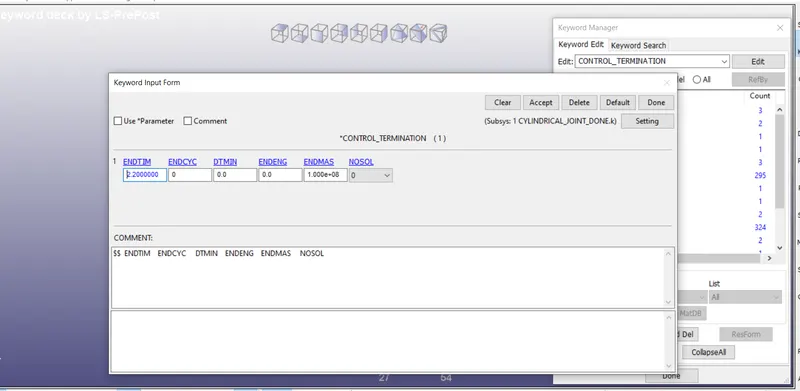
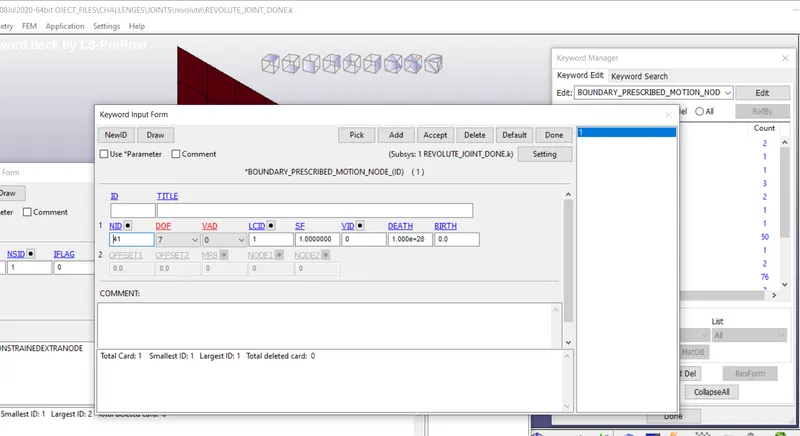
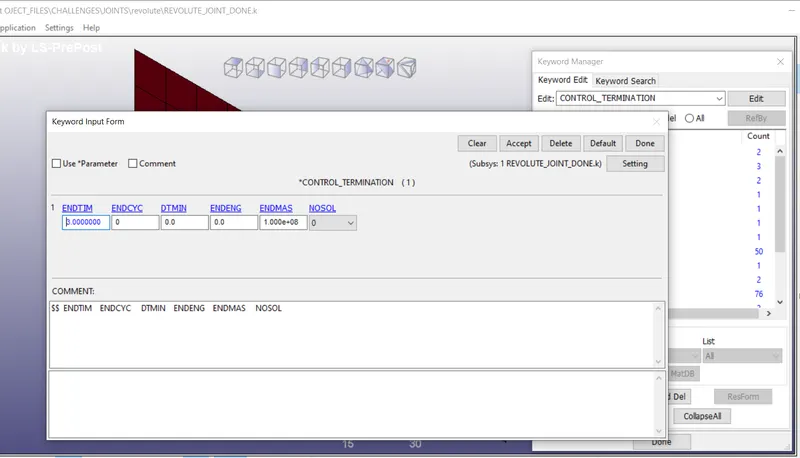
REVOLUTE JOINT:
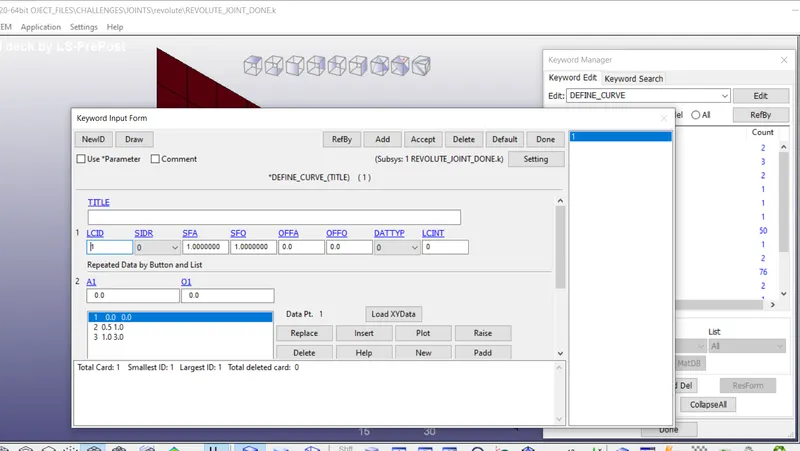
JOINT BETWEEN TWO RIGID BODIES:
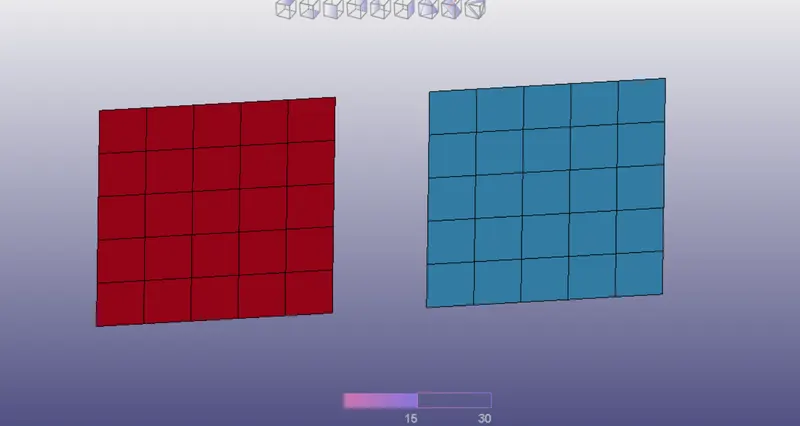
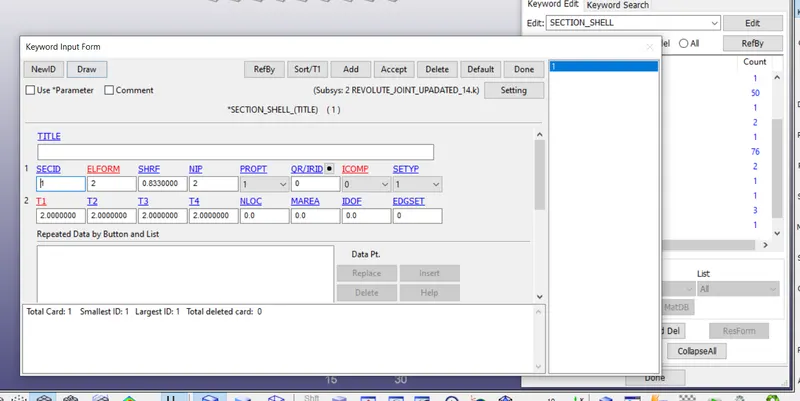
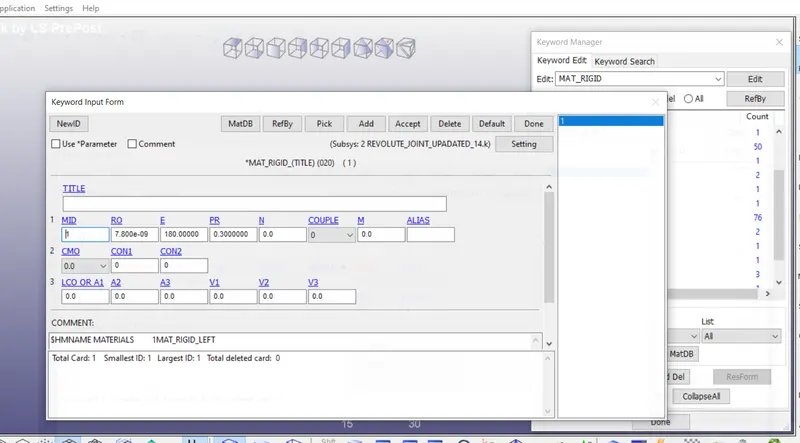
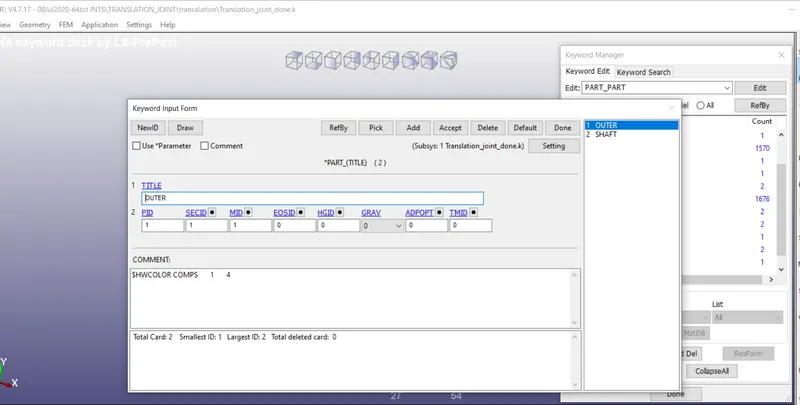
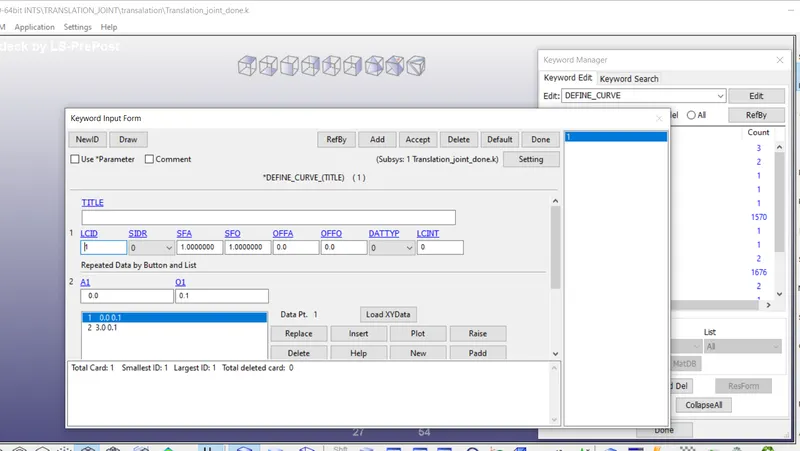
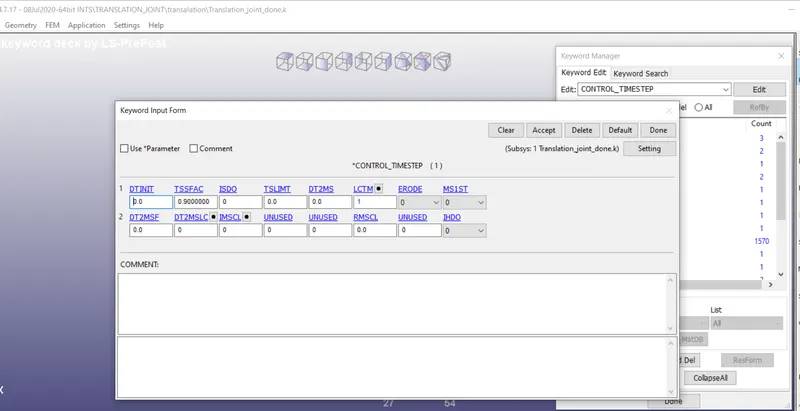
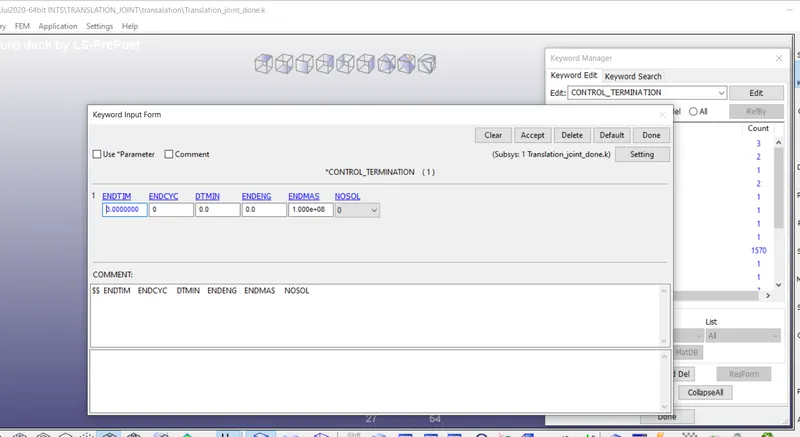
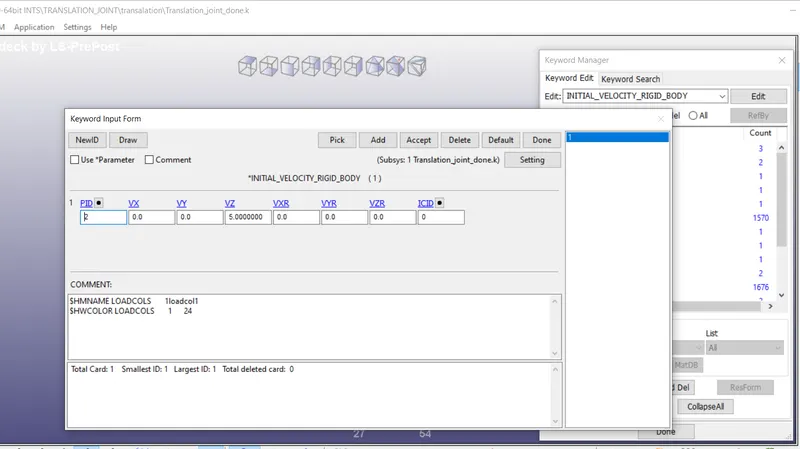
TRANSLATION JOINT:
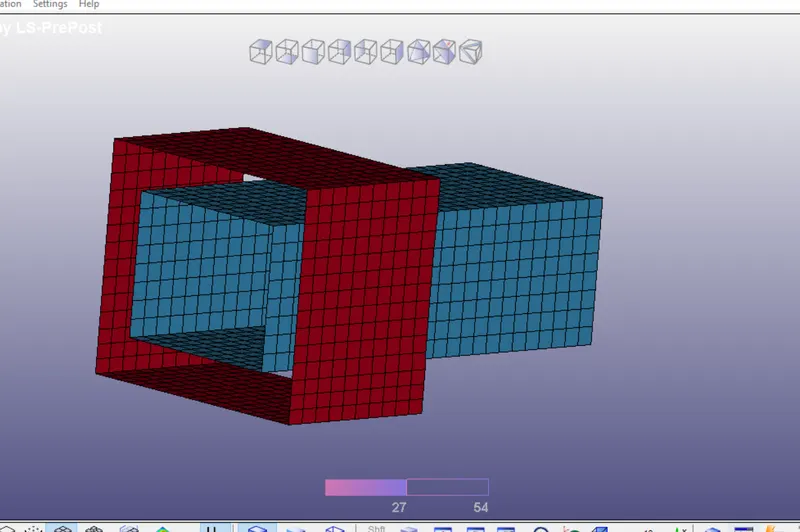
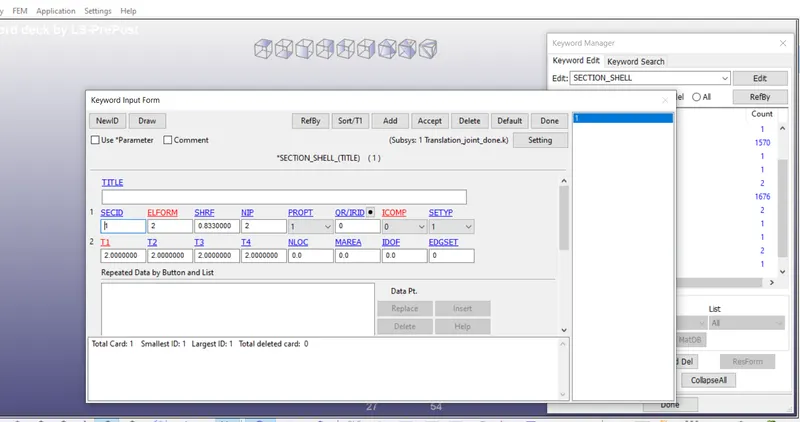
JOINT BETWEEN TWO RIGID BODIES:
CONCLUSION:
The joints are revolute,spherical,cylindrical,translation are done in between two rigid bodies by using constrained extra node set this challenges was very helpful for understanding create the joints.