Project - Speed Control of a Direct Current (DC) motor
AIM :
To the speed of the dc motor using the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
j= 0.2
b= 0.2
km=0.01
kb = 0.1
kt= 0.1
ra= 2
la= 0.5
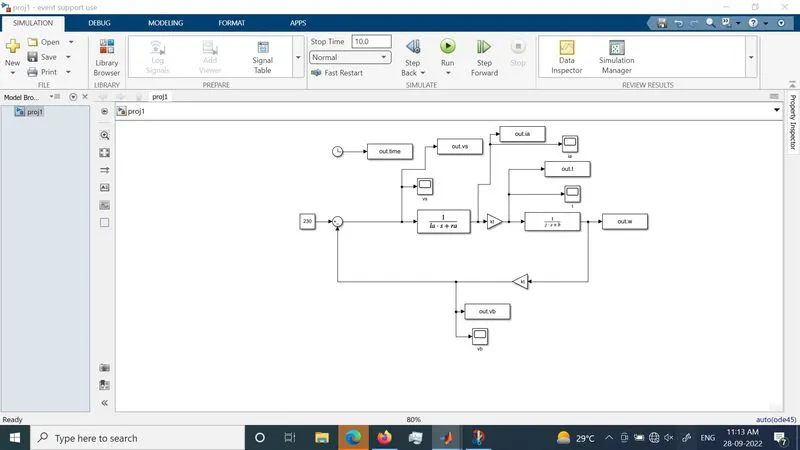
The input parameter are taken from the videos. the mathemathematical equvation is detervitaed.
w(s)/vs(s) = kt / J.LA.S^2+(J.RA+B.LA).S+(B.RA+KT.KM)
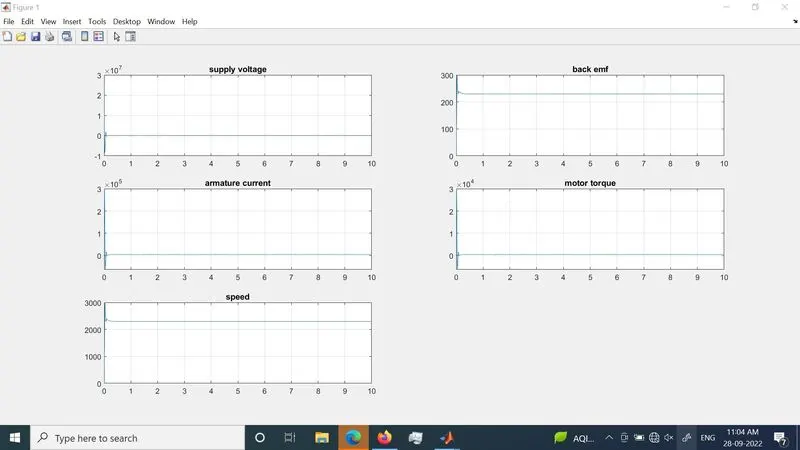
THE SPEED CONTROL OF DC MOTOR WITHOUT PID ;
OUTPUT ;
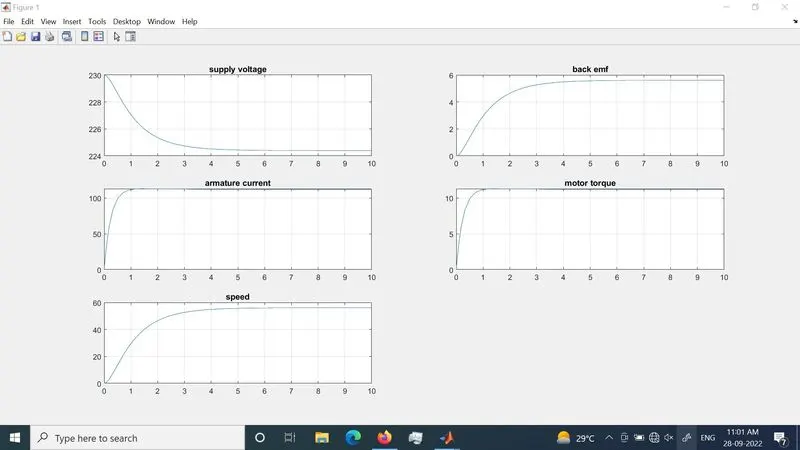
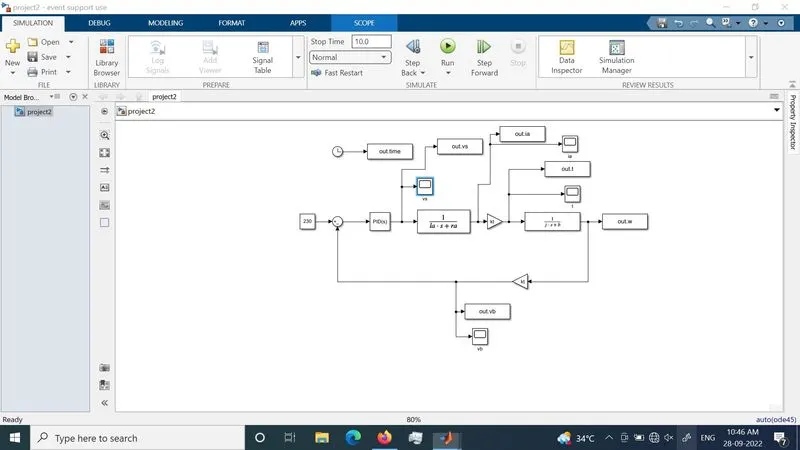
THE SPEED CONTROL OF DC MOTOR WITH PID ;
OUTPUT ;