Project - Speed Control of a Direct Current (DC) motor
Aim :
Speed Control of a Direct Current (DC) motor.
A mathematical model for DC motor:
ω(s)/Vs(s)=Kt/[J⋅La⋅s2+(J⋅Ra+B⋅La)⋅s+(B⋅Ra+kt⋅km)]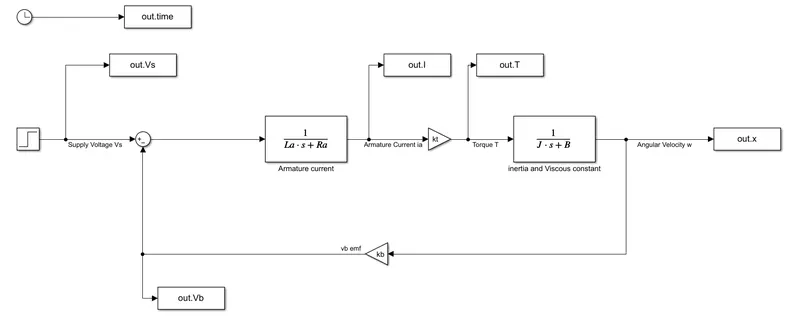
DC-Motor Parameters :
clc
clear
close all

J = 0.02 ; % moment of inertia kg-m^2
B = 0.2;   % motor viscous constant N-m-s
kb = 0.1; % Back emf constant v/rad/s
kt = 0.1; % motor torque constant N-m/amp
Ra = 2 ; % resistance of armature circuit ohm
La = 0.5 ; % inductance of armature circuit
Plot the response
close

figure(1)
subplot(3,2,1);plot(out.time,out.Vs);grid on;title('Supply Voltage');
subplot(3,2,2);plot(out.time,out.w);grid on;title('Angular velocity');
subplot(3,2,3);plot(out.time,out.Vb);grid on;title('Back emf');
subplot(3,2,4);plot(out.time,out.I);grid on;title('Armature Current');
subplot(3,2,5);plot(out.time,out.T);grid on;title('Torque ');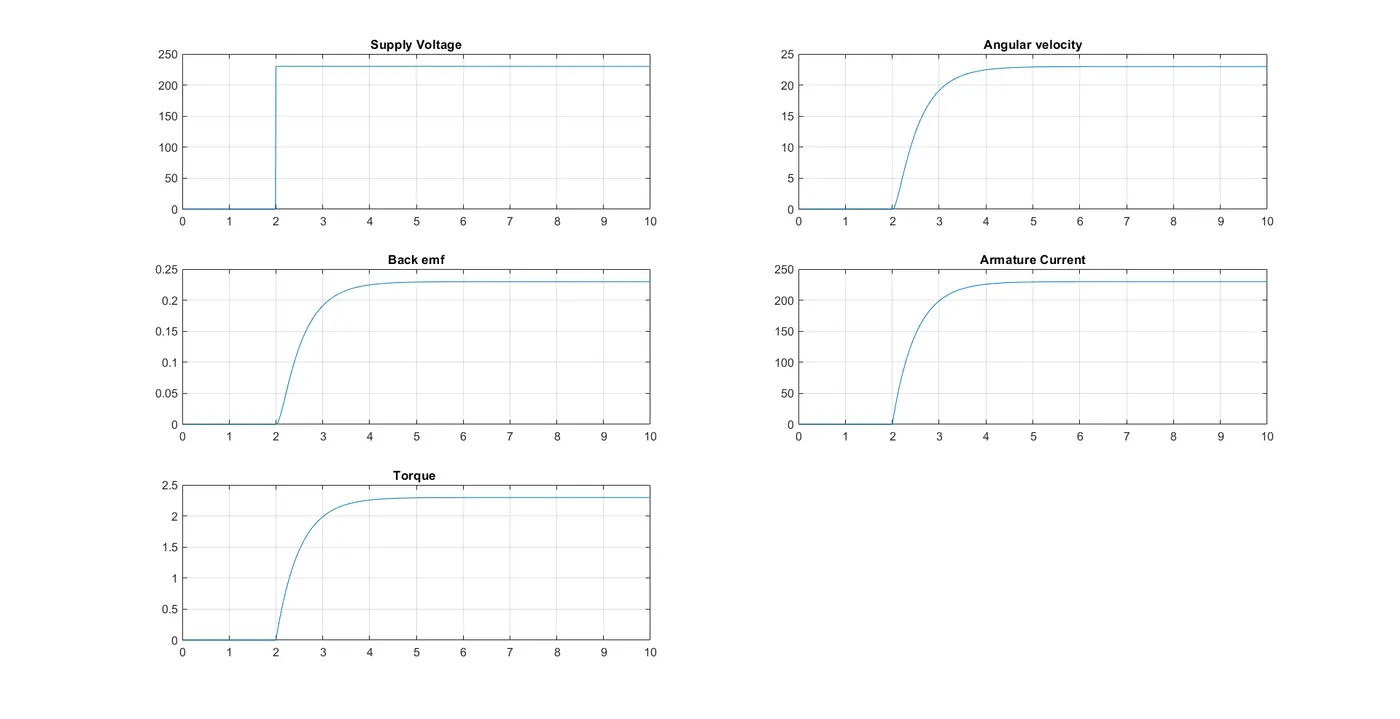
the DC motor is getting stable but it has a high Settling time and the rise time is also high.
PID controller is needed to design with a gain value of kp,kd, ki.
PID controller model with step input
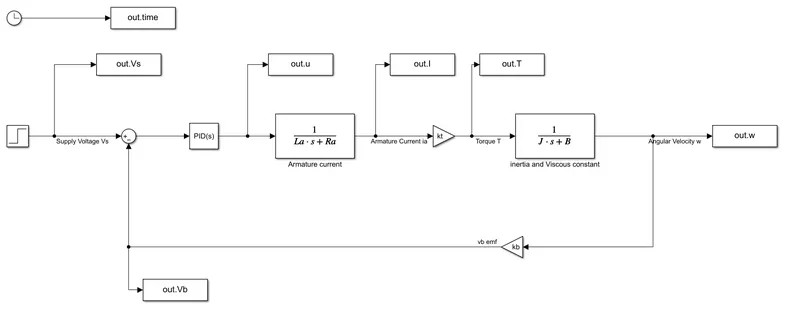
at the below PID value
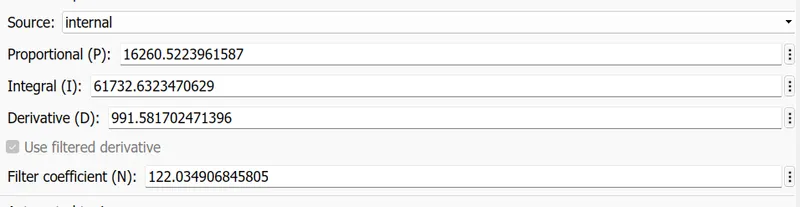
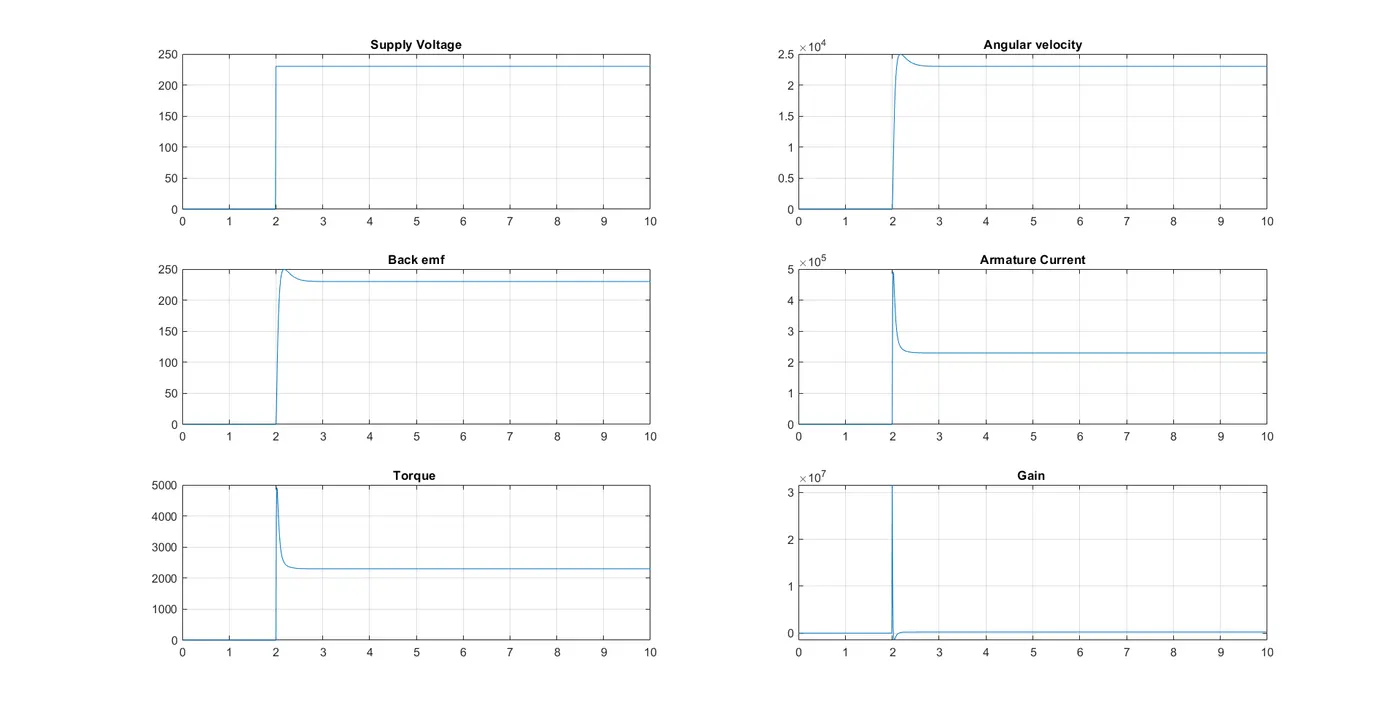
It has less rise time and settling time but a high overshoot.
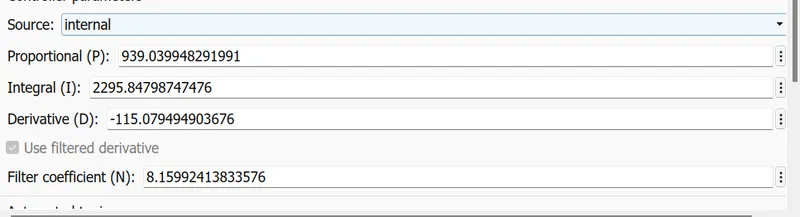
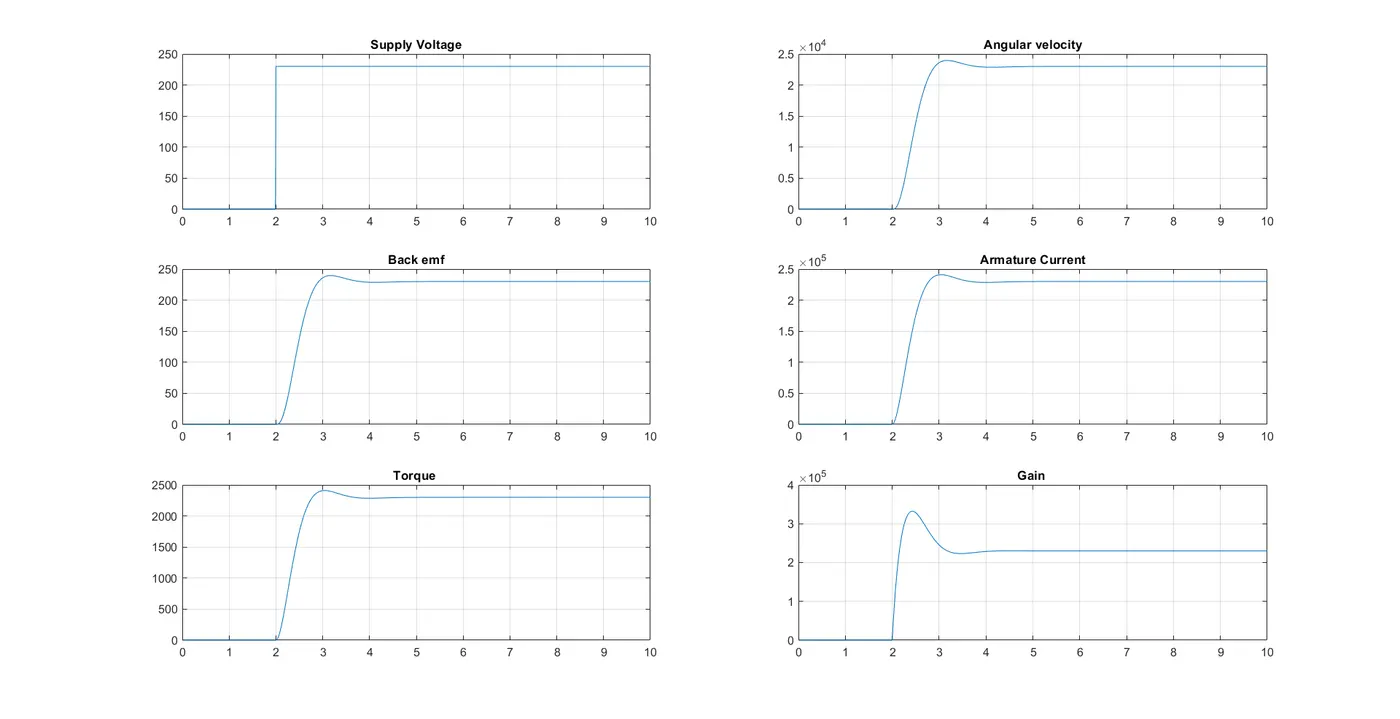
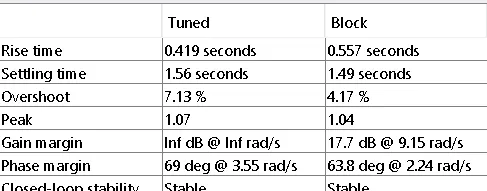
Value of overshoot, rise time, settling time, and steady-state error.