Project - Position control of mass spring damper system
Final project of the simulink Basics
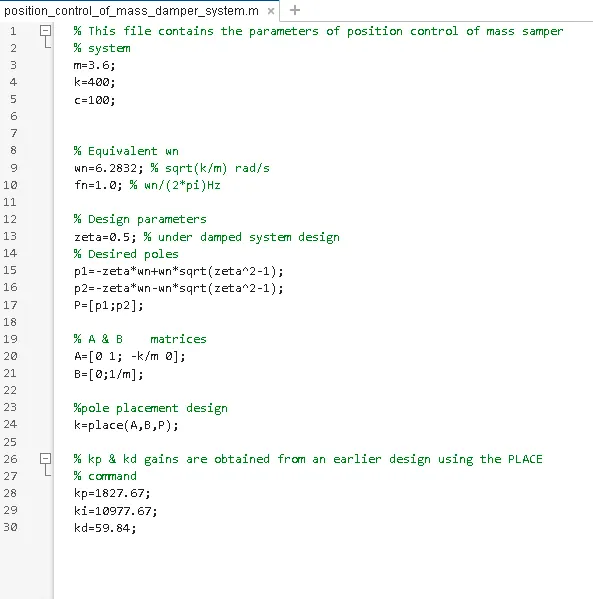
In this project we are obtaining the transfer function and we are creating the m file and taking the values and generate a model with the given values and pid contrioller
m=3.6;
k=400;
c=100;
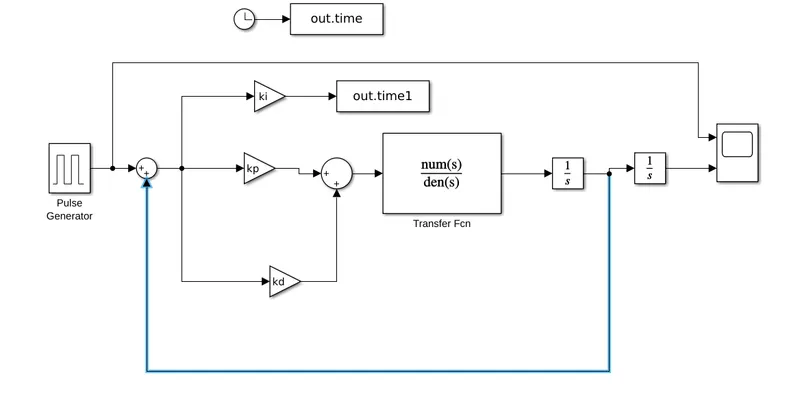
IN this model we have created transfer function by taking the values given in the question and in this we can use PID controller directly but the PID conroller we can use in the detailed way to get the output
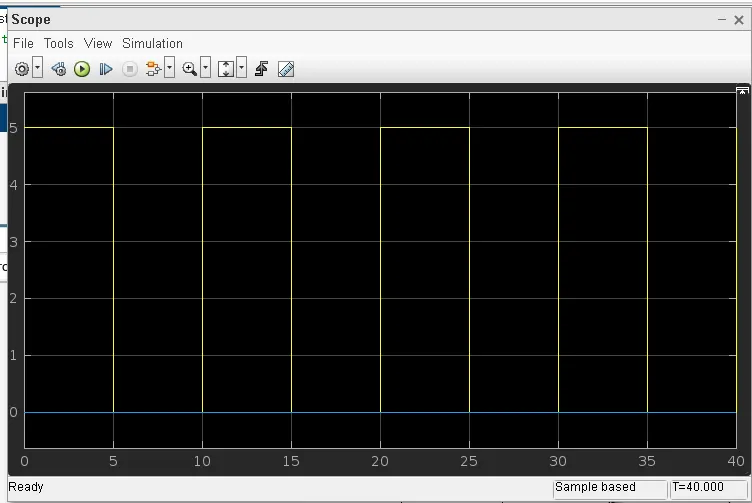
The final output of the model was not getting correct plz accept this scope