Project - Position control of mass spring damper system
Question:-
Aim:-Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Given:-
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
The reference signal is shown in the following figure.
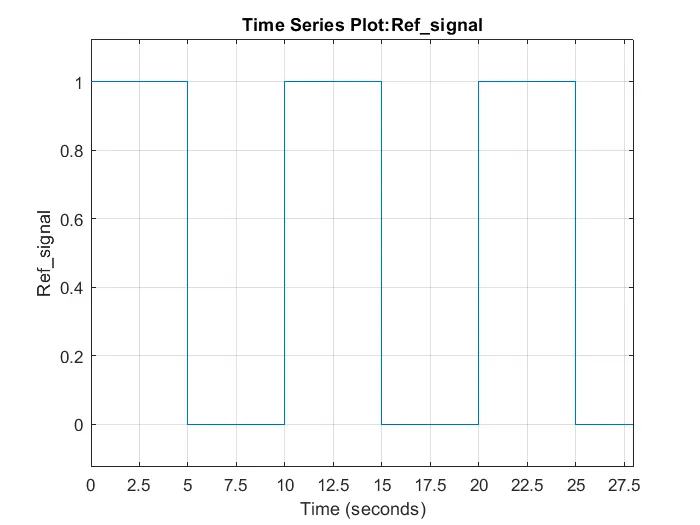
Objective:-drive the pulse generator of the waveform in other waveforme this given siginigicantly.
REQUIREMENTS
MATLAB & SIMULINK softwares
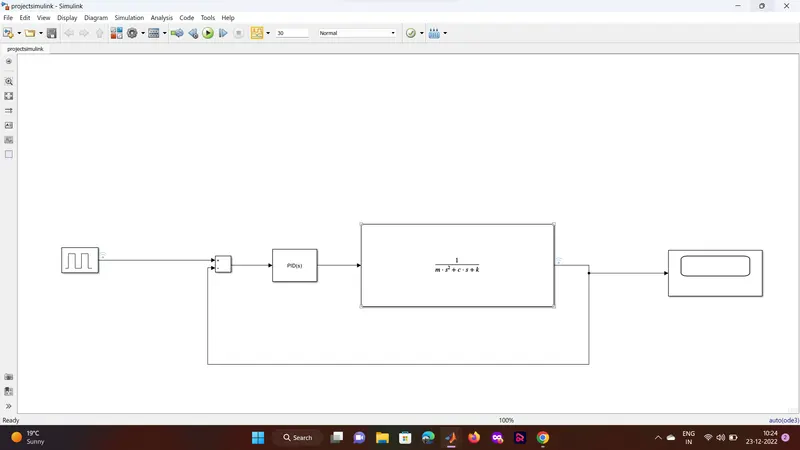
Simulink -it is a graphical user interface for modeling and simulation of block schematics. The core of the Matlab is used to compute the simulating results. Simulink is primarily used for modeling dynamic systems. and the conect the pid controller and the conect transfer function Simulink’s libraries offer a plenty of blocks useful for modeling complex systems. With help of integrating methods, we can simulate the system and analyze it in time.
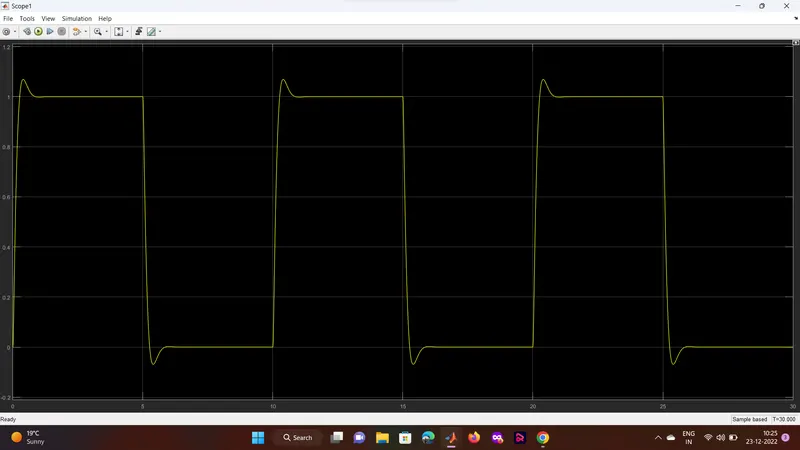
given the referance input and the get waveform of conerted the pulse generator in this model using the some blocks and for the one pulse generator and the one pid controller and the transfer function and one scope and one add bluks using make a spring mass damper model .and given referance signal....
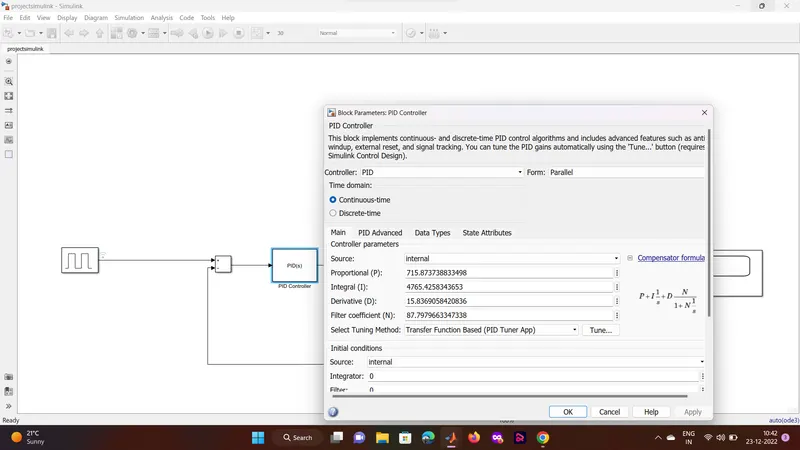
and the given the value
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
The reference signal is shown in the following figure.
all given the some figgure of model of simulink
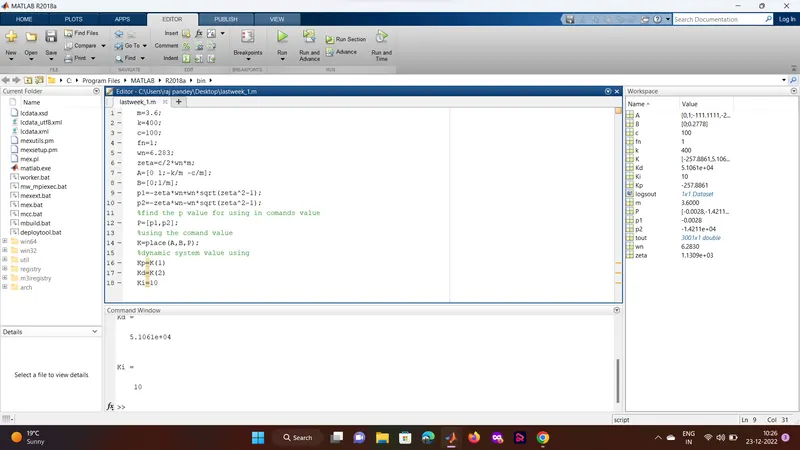
lastweek_1
Kp =
-257.8861
Kd =
5.1061e+04
Ki =
10