Project - Position control of mass spring damper system
Mathematical Modelling was initially done for the system to analyse forces and ultimately find transfer function
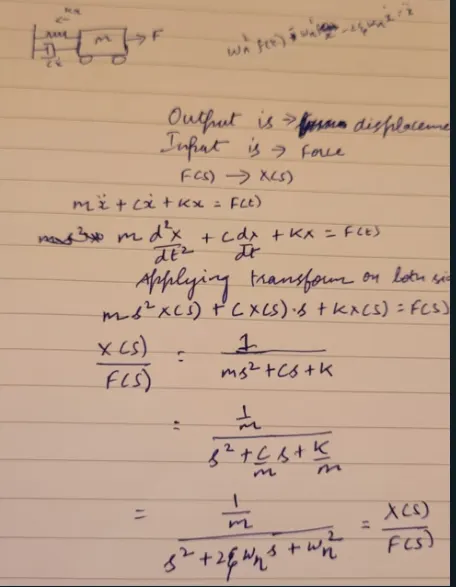
X(s) being the displacement i.e the output and F(s) being the Force to be applied the input
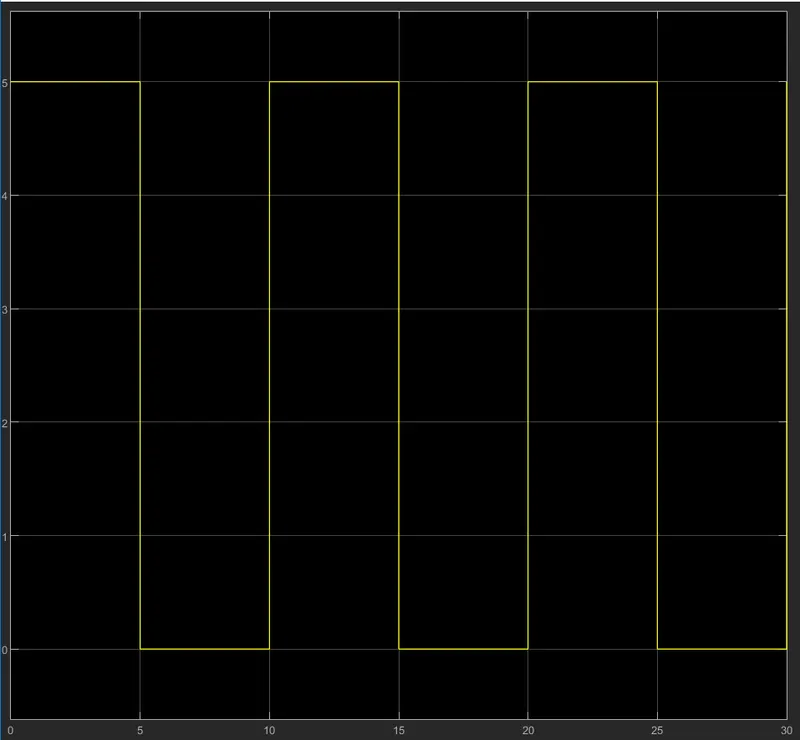
Simulink model was modelled and a reference signal to be modelled was inputted which was a pulse signal of amplitude 5 and time period of 10s
PID control was done using pole placement technique which was fed into a text file to make changes easy
m=3.6;
c=100;
k=400;
wn=sqrt(k/m);
wn2=wn^2;
zeta=c/(2*m*wn);
third=2*(c/(2*m*wn))*wn;
A=[0 1;-400/3.6 -100/3.6];
B=[0 ;1/3.6];
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2]
K=place(A,B,P)
Kp=K(1);
Kd=K(2);
Ki=750;
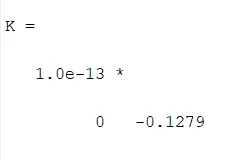
The poles Kp and Kd were obtained as follows
When the actuating signal or control signal enters the transfer function displacement is obtained ,this displacement is given as feed back to find error and input it to the controller
Over several iterations Ki value was changed to find the best suited Ki value at 750,it had the least rise time and less overshoot
Plot of Displacement vs Time
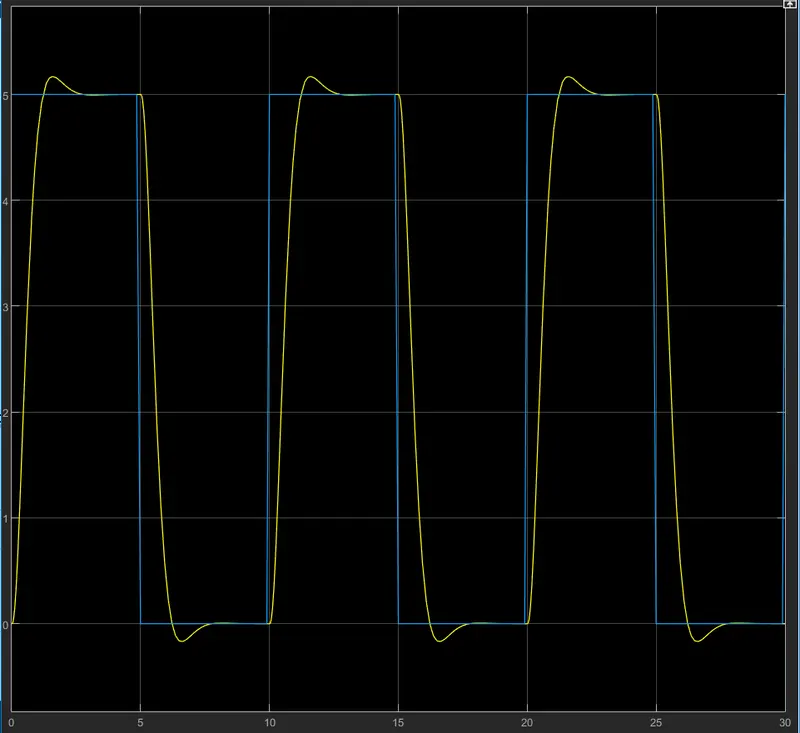
Plot of force control wrt to time
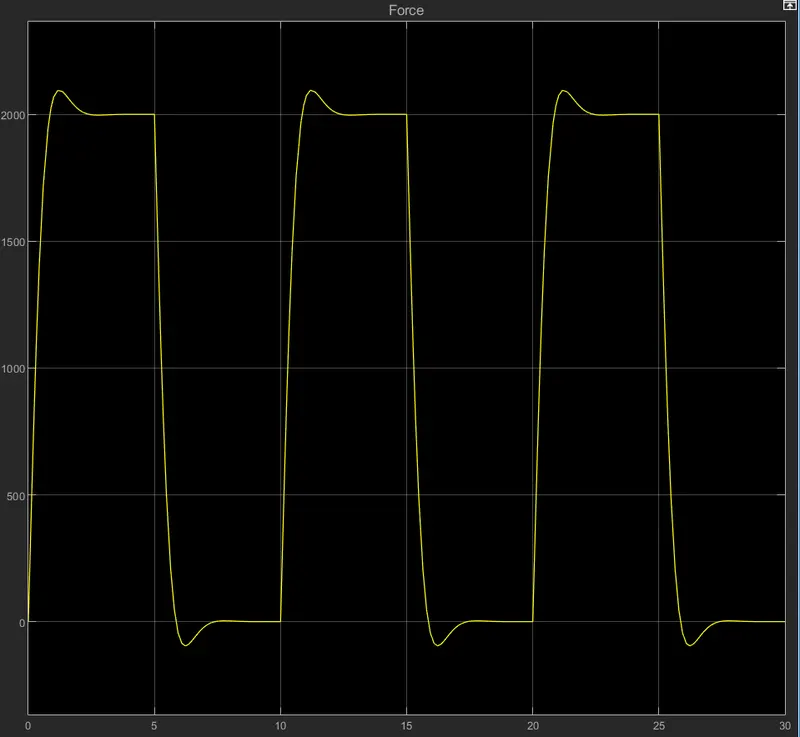
Peak of 2000N force is observed and the correctness is clarified by observing that the forcing follows the same the pattern of displacment.