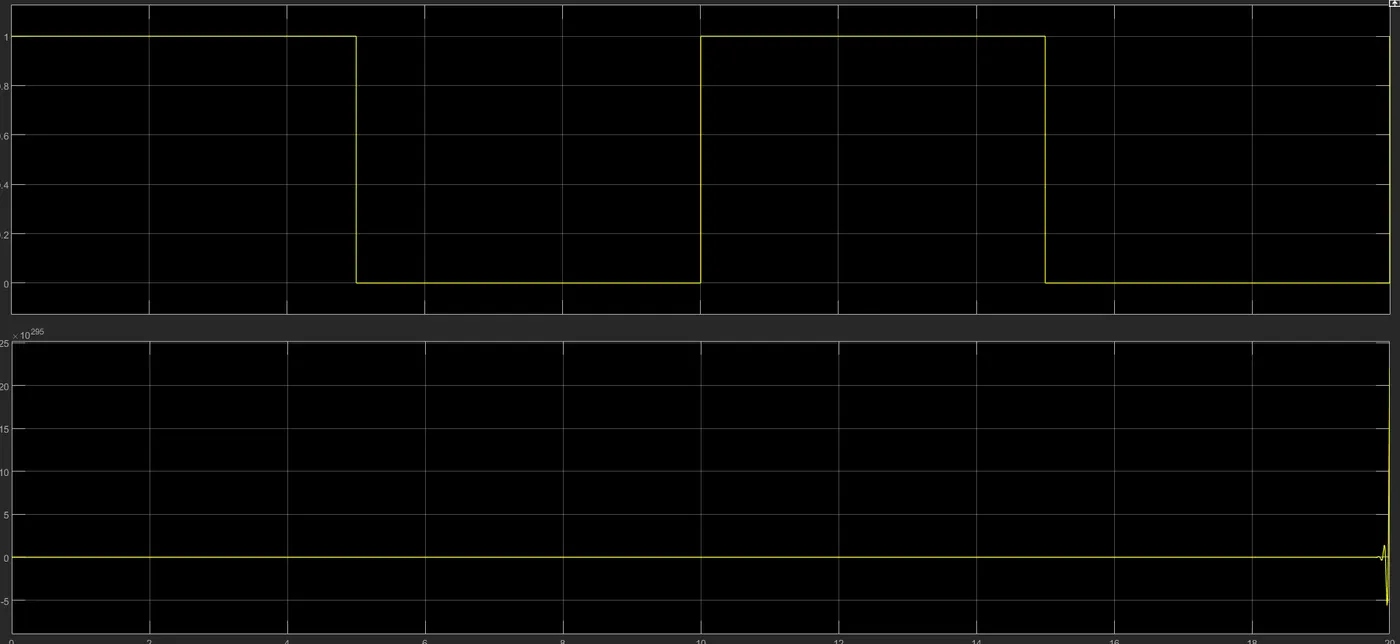
Project - Position control of mass spring damper system
Matlab script for initial condition
clear all
clc
%Basic parameters of the spring mass system
%mass,
m = 3.6; %kg
%spring constant,
k = 400;
%damping co-efficient,
c = 100; %Ns/m
Wn = k/m;
fn = Wn / (2*pi);
%Underdamped case
zeta = 0.99;
%poles
p1 = -zeta * Wn + Wn * sqrt(zeta^2-1);
p2 = -zeta * Wn - Wn * sqrt(zeta^2-1);
P = [p1;p2];
%A & B matrices
A = [0 1;-k/m c/m];
B = [0;1/m];
%Poles placement design
K = place (A,B,P);
Kp = K(1);
Kd = K(2);
Ki = 50;
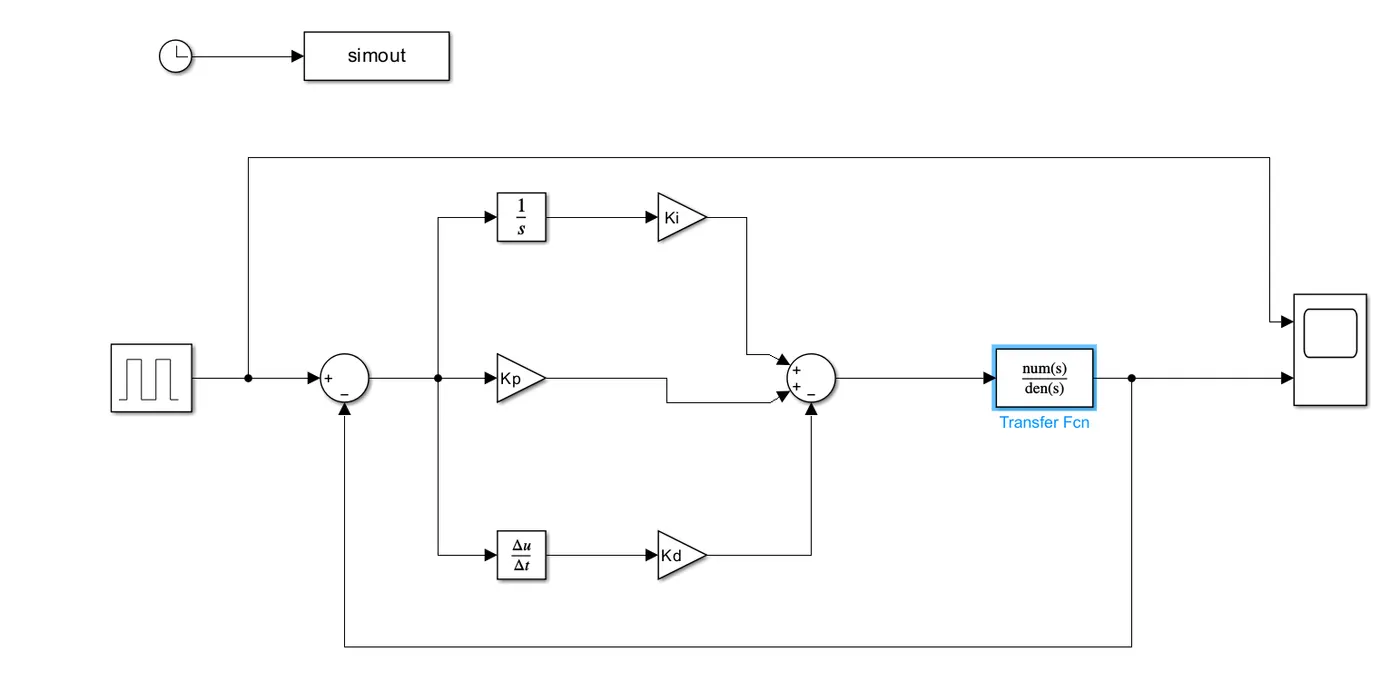
Simulink Model
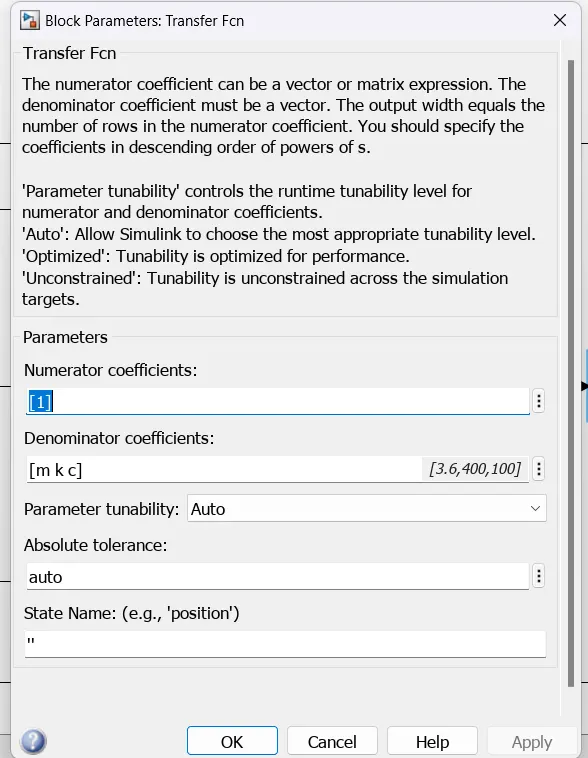
Transfer function
Result