Project - Position control of mass spring damper system
From the given data and the reference signal, the model has been developed to trace its position almost to the reference signal by using a PID controller to control its position.
From the given data;
The design parameters like natural frequency, zeta, poles, pole placement and gains have been found. It is mentioned in the script as shown below
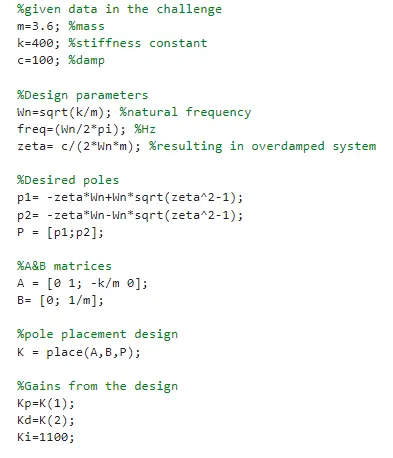
From these values, the dynamics of the transfer function has been made in the simulink model.
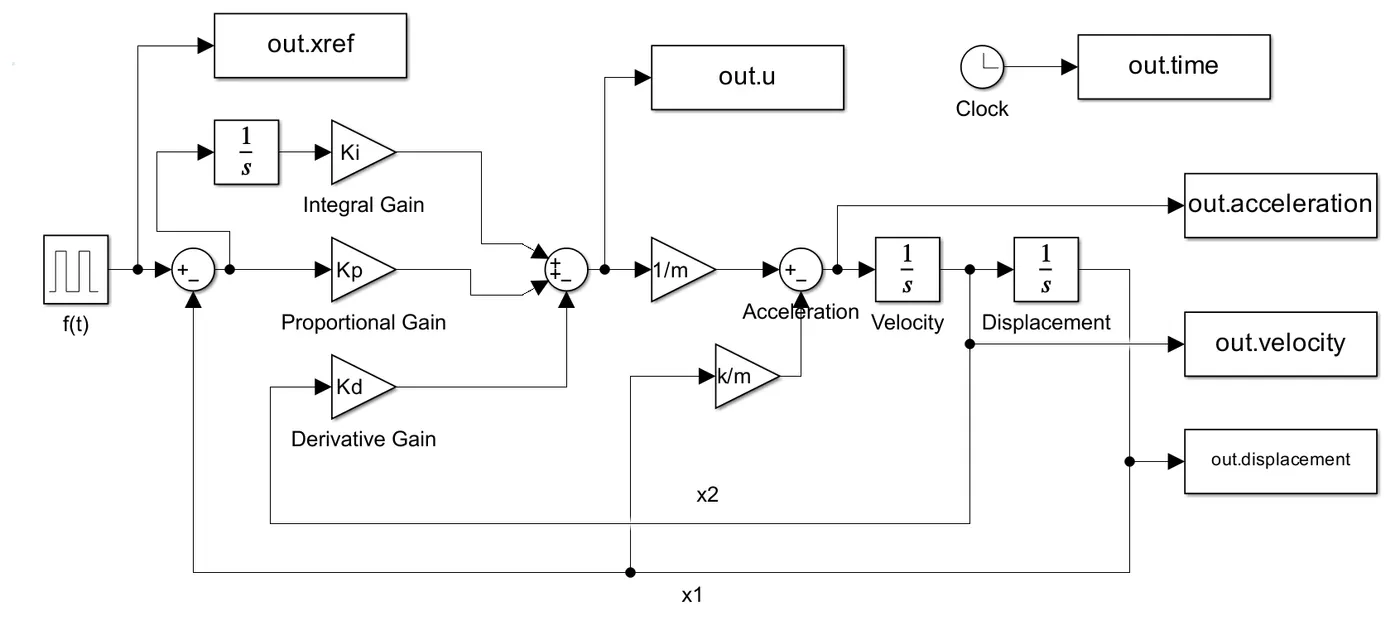
From the given specific reference signal, I used a pulse generator to generate that pulse signal to the system.
Plotting script:
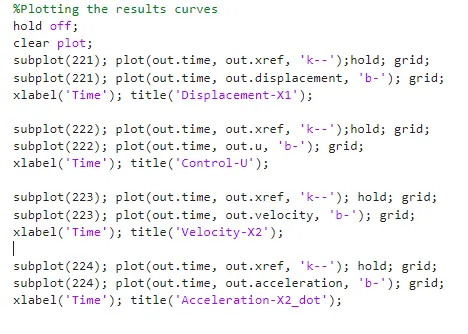
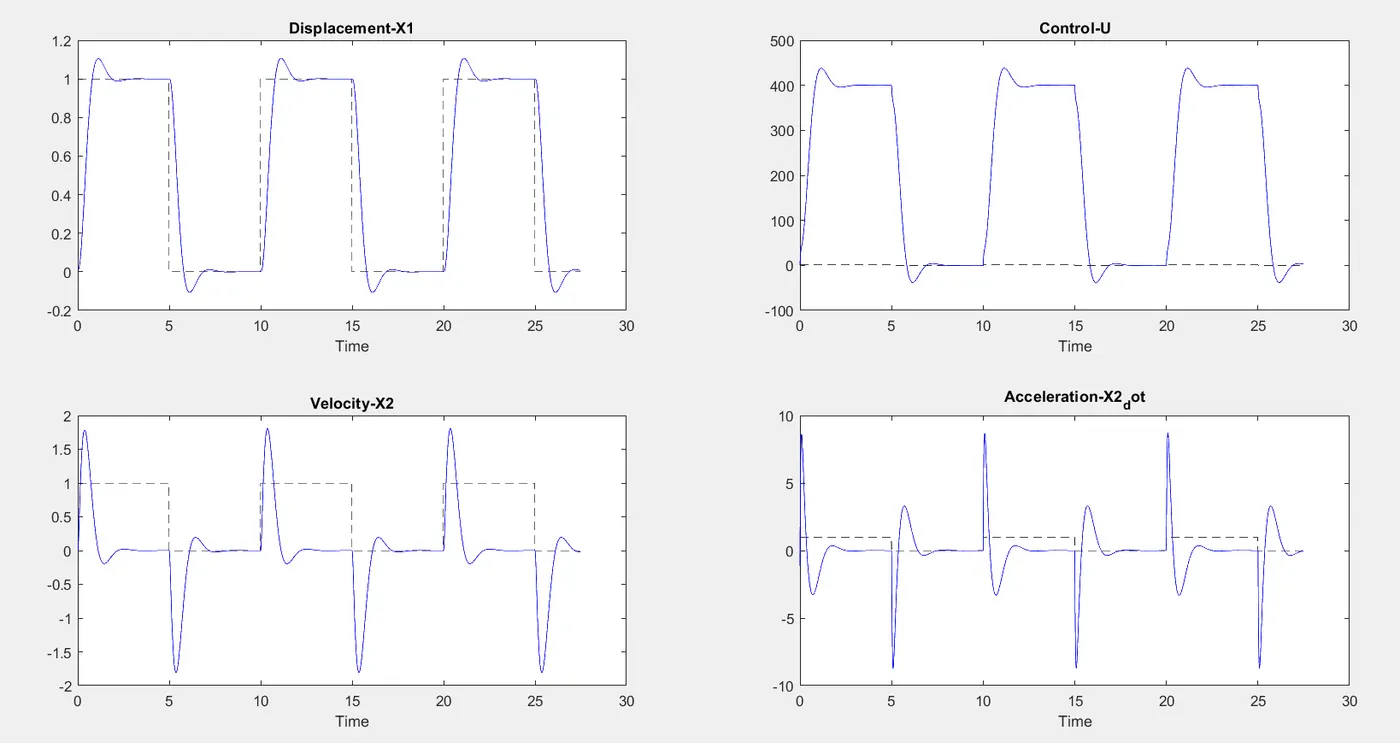
from this plotting script, we can evidently see the performance of the system is controlled or not by the PID controller. By fine tuning various integral gain value, I came up with 1100 with almost 10% of overshoot from the reference signal and also the performance. From the plot below you can verify it.
Thanks for the lessons, I hope I performed better in this project. Please retreive me with suggestions & mistakes I have to improve.
Thanks
Ragu B