Project - Position control of mass spring damper system
Q.1 Spring mass damper system
-used PID controller in spring mass damper system.
-Blocks used -
Clock-Display time =30 sec
To workspace- out.time & out.x1 - Array format used
Pulse generator - Amplitude=1, Period=10 sec, Pulse width=50% of period
Sum block - sum of kp, ki & kd values
kp - gain block used for propotional to input
kd - derivative & gain block used
ki - Integration & gain block used
Transfer function block used-
Numerator coefficent=1
denominator coefficent=m,c,k value used
Initial position given below
m=3.6 %kg; k=400 %N/m; c=100 % Ns/m
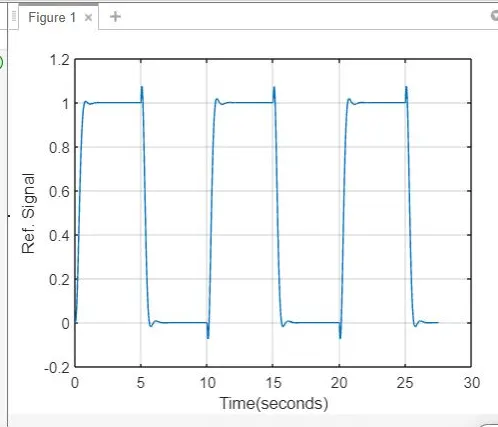
Generate wn value, A&B matrix value,Design pole placement, Design place comment & Kp,Kd,Ki value then plot Graph.
output is given below