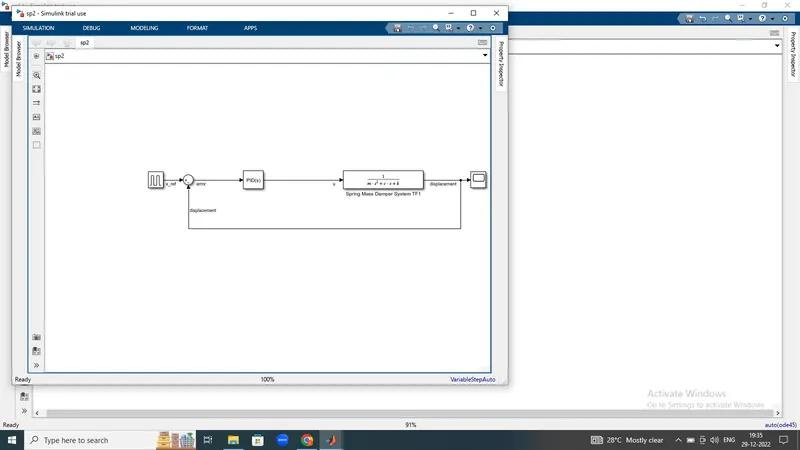
Project - Position control of mass spring damper system
mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
hence i have some issues in tunning the PID controller where i have use the instead of PID controller i use the PID as manuaallly
open the simulink and take the block which u have need
and arrange them in order
hence we have need
gain
integrator
derivative
sum
pulse generator
spring mass damper system transfer function
scope
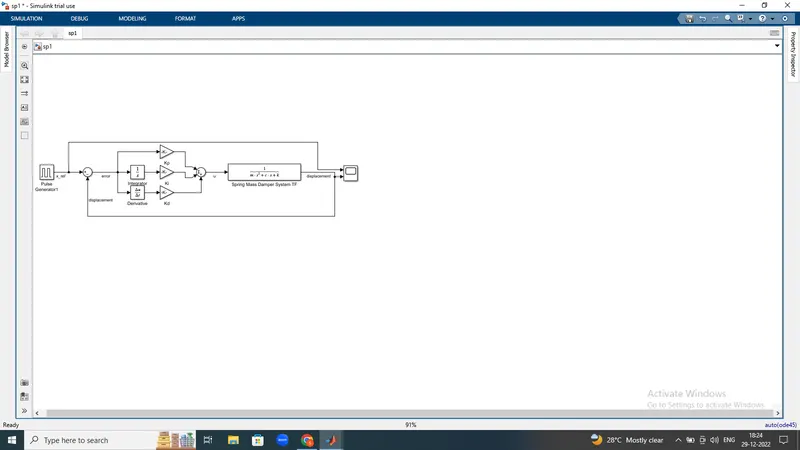
where the given value of mass dampingconstant spring constant hence we can get the value of the kp ki kd and all the values has been find by this
hence the output has shown in scope
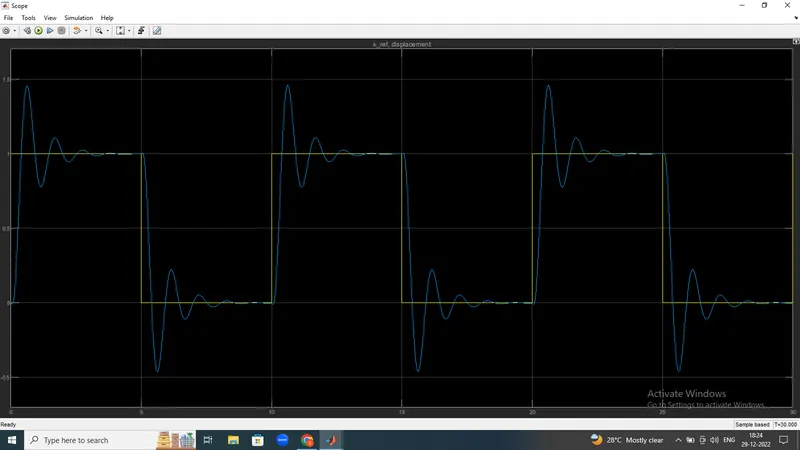
the output is verified
hence the above block we can use the PID controller here we don't need to find Kp and Kd.Here we don't need to find the values we directly tune the graph and get the output