Project - Position control of mass spring damper system
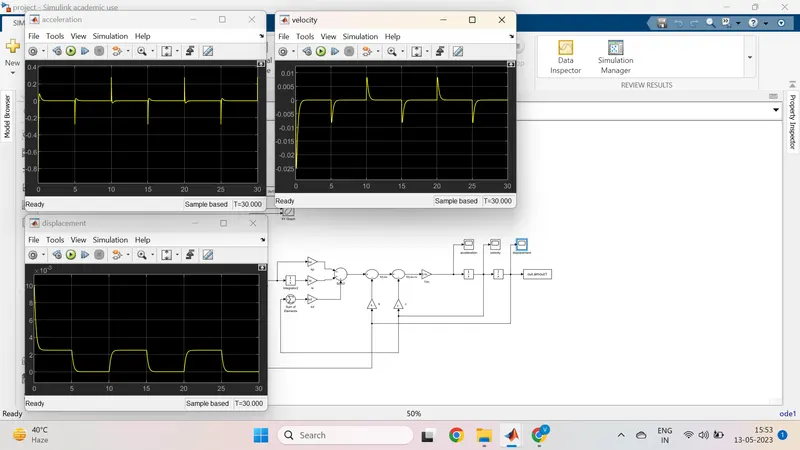
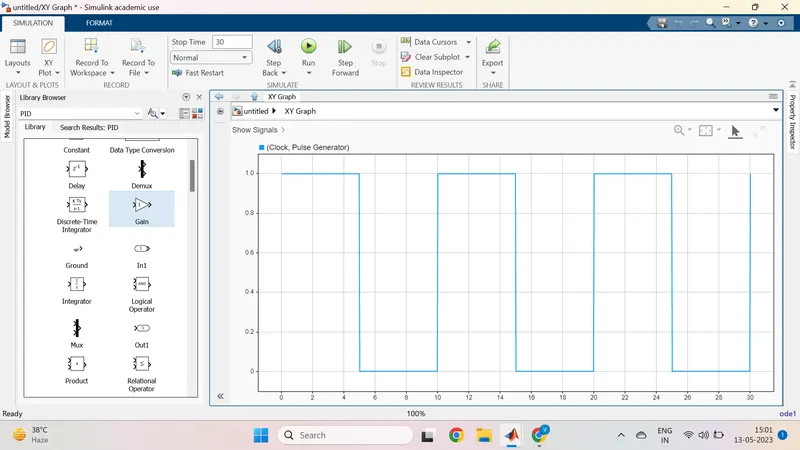
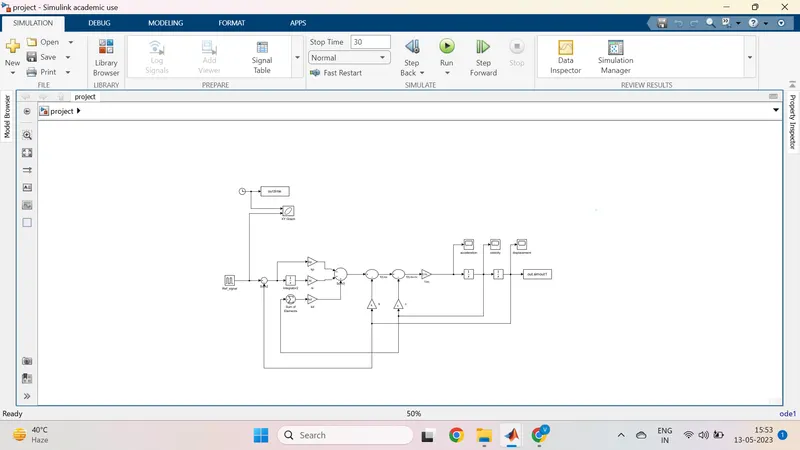
Report: As in the challenge give. i prepared a model of a mass spring damper system with m = 3.6, k = 400, c = 100; with the equation f(t) = mx_double dot + cx_dot + kx. and also added the PID controller to the model. the i learned in week 7. and with the help of ki, kp, kd . we obtained the position follows a reference signal.