Project - Position control of mass spring damper system
[1]
1st i am creating a m.file in showing the video
clc;
clear all
% Nominal parameters of the spring-mass system
m = 3.6; % mass of the spring-mass system
k = 400; % stiffness constant of the spring-mass system
c = 100;
% Equivalent wn
wn = sqrt(k/m)
% Design parameters
zeta = 0.5; % under damped system design
% Desired poles
p1 = -zeta*wn+wn*sqrt(zeta^2-1);
p2 = -zeta*wn-wn*sqrt(zeta^2-1);
p = [p1;p2];
% A & B matrices
A = [0 1;-k/m -c/m];
B = [0;1/m];
% pole placement design
K = place(A,B,p);
% Kp and Kd gains are obtained from an earlier design using the PLACE
% command
Kp = K(1);
Kd = K(2);
[2]
2nd i am create a simulation module as showing the video
simulation:
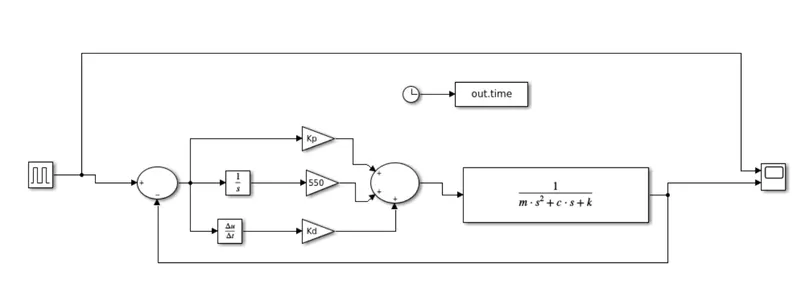
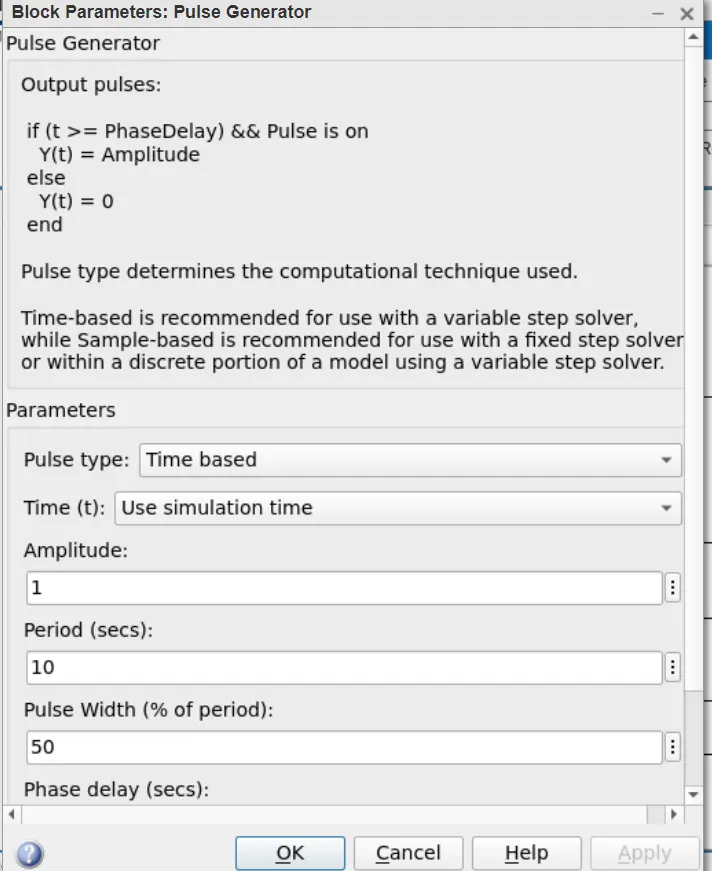
Now i am connecting the input in pulse genrator :-
and ki is the 550 in match the simulation
and run the simulation.
scope:
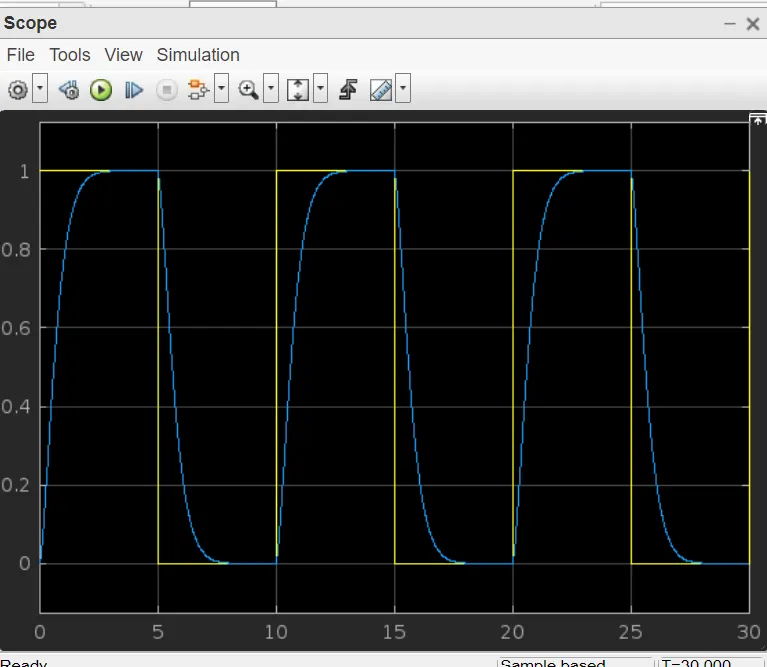
in match the input and output .