Project - Position control of mass spring damper system
Qu:-Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Ans:-
Considering Mass of the spring-mass system (m=3.6). Stiffness constant of Spring mass system(k=400.0)
Damping Coefficient (c=100). zeta=0.5 (Underdamped system)
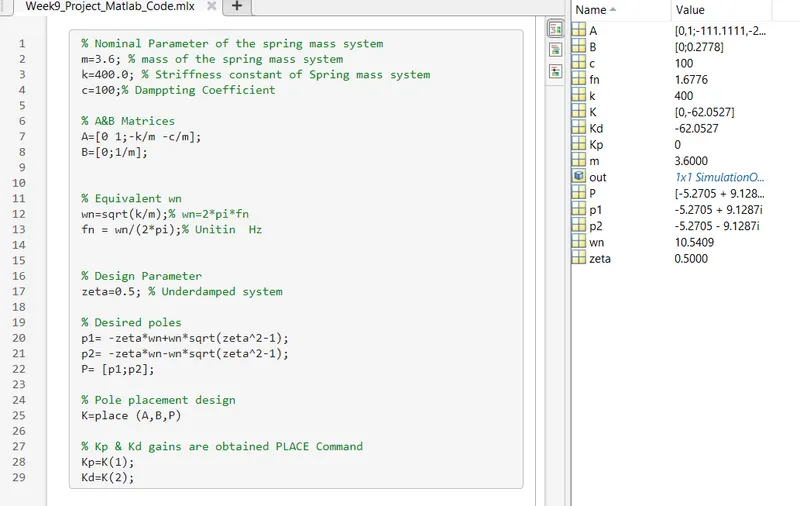
Kp & Kd Value derived from Matlab place command.Ki value manually adjusted for the stability of the system.
So here considering the Ki=2000.The result is shown here.
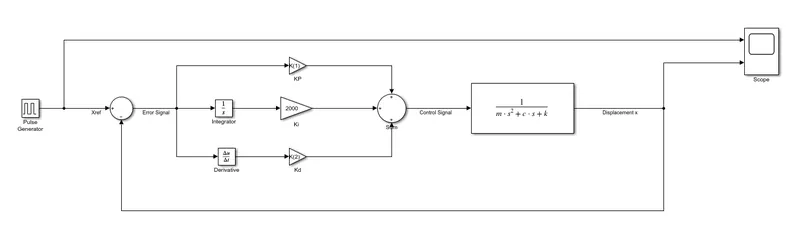
Here the overshoot & undershot value is more than the permissible limit which is 10%.
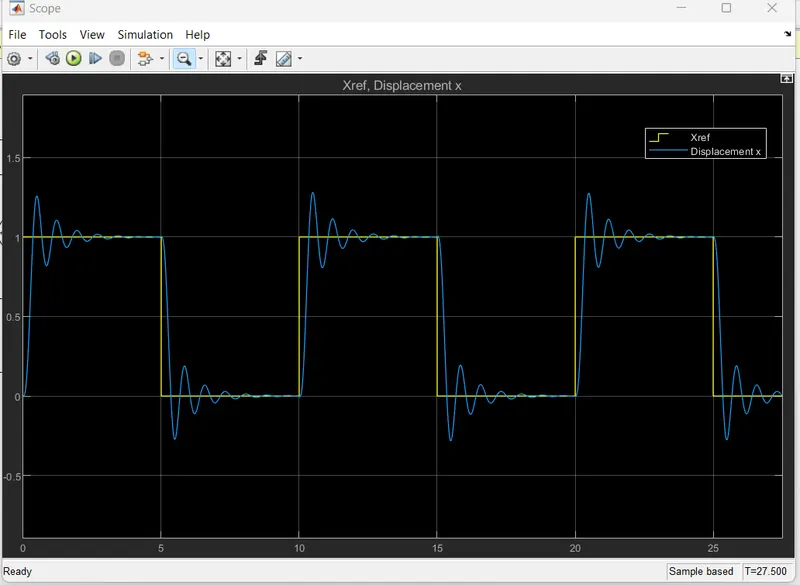
Let's consider the Ki=3000.The result is shown here.
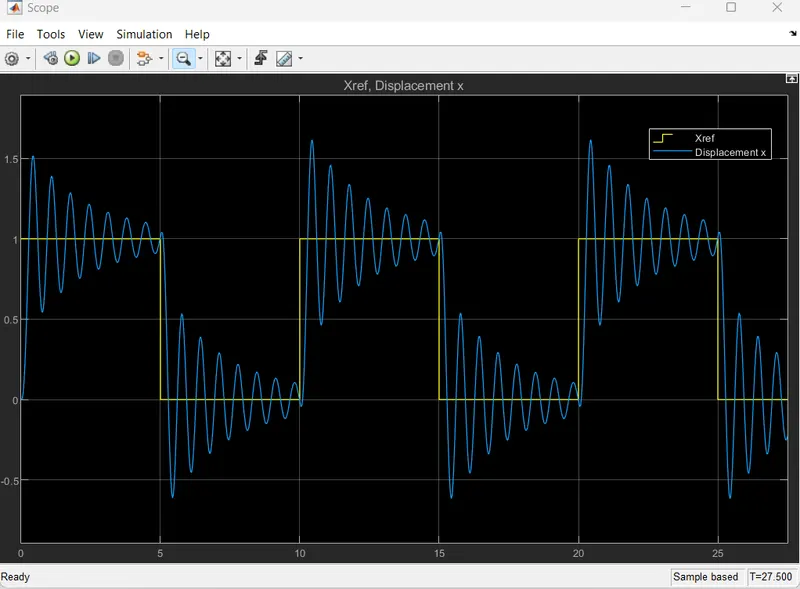
With Ki =3000 value the above result is more unstable than ki=2000. The system dosesn't stable at all at any point.
Furthermorelet's try with a less minimal value , considering the Ki=300. The result is shown given below.
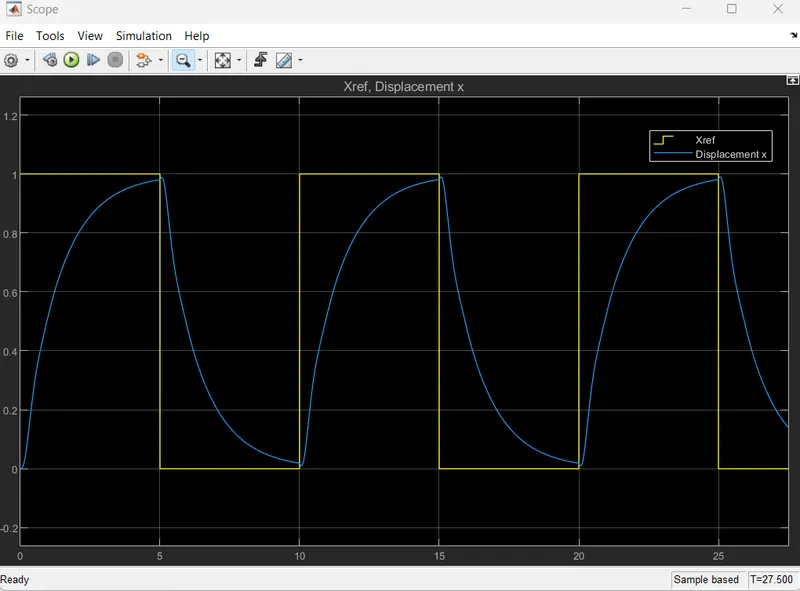
Still the system is unstable & even doesn't reach up to stability.
So the stable value of Ki must be on between 300 to 2000.
Let's try considering the value of 1400.Here is the result.
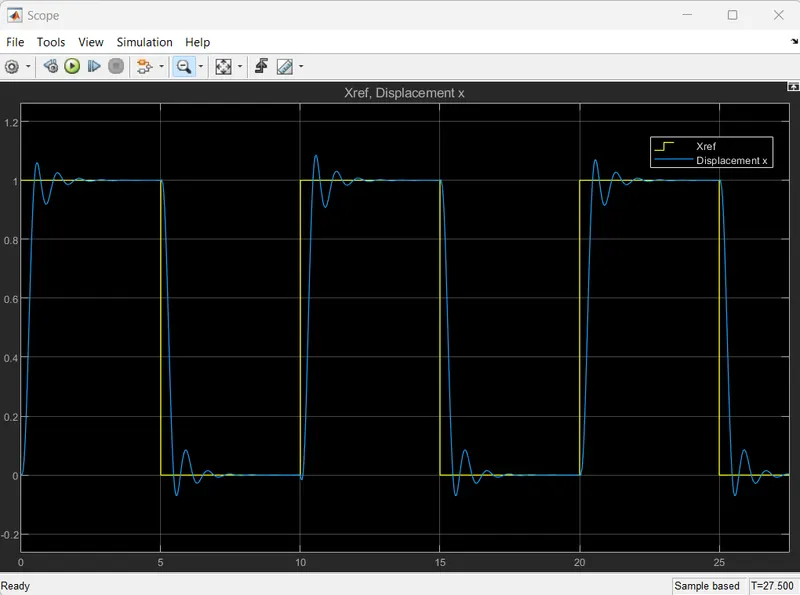
Now the system is stable with approx 3sec. Overshoot & undershoot value also within the permissible limit which is 10%.
Finally, Ki is 1400 where the system will be stable.