Project - Position control of mass spring damper system
set the value for mass spring damper system
m=3.6;
k=400;
c=100;
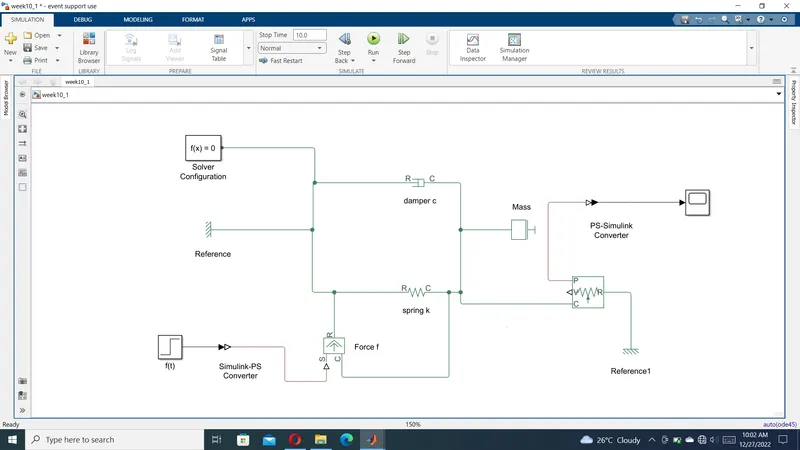
use this parameter
mass (m) = 3.6 kg
stiffness of spring (k) = 400 N/m
damping factor of damper (c) = 100 Ns/m
force (f)
motion sensor =0
two references used
motion sensor
unit step
scope
solver configuration
simulink to ps converter
ps to simulink converter
use this parameter & value, And build a mass spring damper with PID controller based model