Project - Position control of mass spring damper system
Q1Following are matlab programme of position control of spring mass damper system
% % spring mass damping equation
% mx+cx+kx=f(t)
% x=1/m(f(t)-cx-kx)
m=3.6 % kg
k=400 % N/m
c=100; % Ns/m;
% % Desired poles,
fn=1.0;
wn=2*pi*fn;
wn=6.28; % sqrt(k/m)
zeta=0.5 % underdamped% reserved poles
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
% % design of PID controller
A=[0 1 ;-k/m -c/m];
B=[0;1/m];
K=place(A,B,P);
kp=-258.0218
kd=-77.3920
Solution
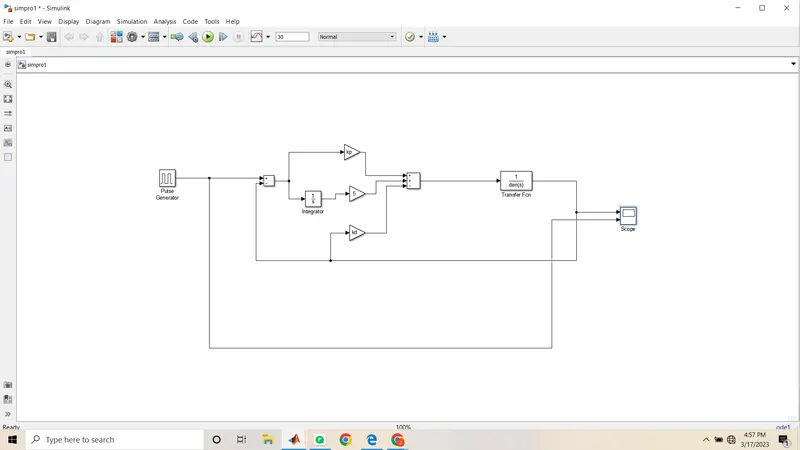
The transfer function used in model as spring damper system.In which nominator is 1 se and denominator [3.6 100 400]set.
PID controller is used in model to control reference force on mass in system.In PID propertional gain kp and derivative gain kd find out by using pole placement method through 'place' command..ki value consider manually.
Pulse Generature is used for giving pulse signl.is used as reference force input.In setting amplitude st 1,period 5 sec and pilse width is 50.It connect to Sum block positive sign.
The output of the Transfer function give displacement.the displacement back to the PID controller and substract from reference signal.Scope block is used to plot signal.
simulink model as below:
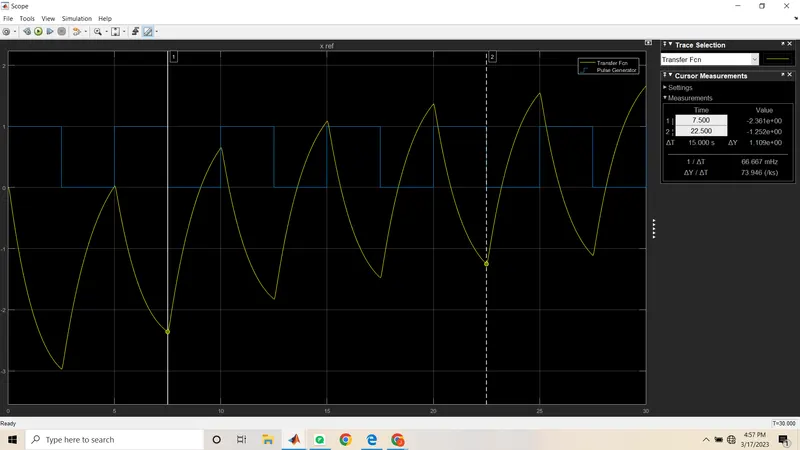
REsponse as below
Conclusion
completed the project of transfer function used as spring damper system in model.Add PID controller in model to control force on mass so that its position follows referece signal.