Project - Position control of mass spring damper system
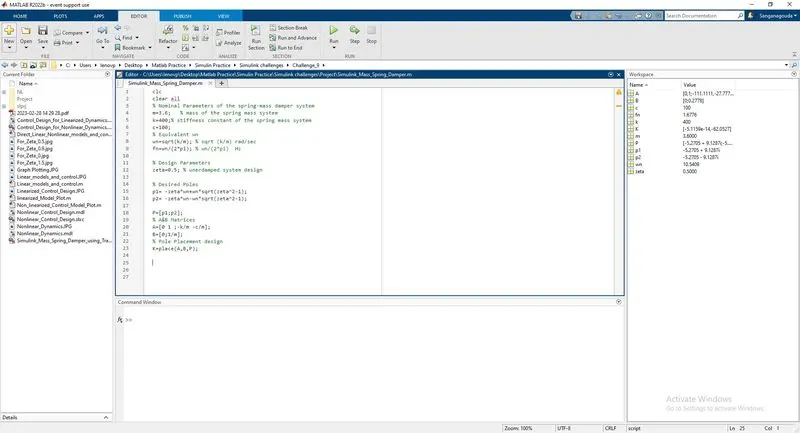
% Nominal Parameters of the spring-mass damper system
m=3.6; % mass of the spring-mass system
k=400;% stiffness constant of the spring-mass system
c=100;
% Equivalent wn
wn=sqrt(k/m); % sqrt (k/m) rad/sec
fn=wn/(2*pi); % wn/(2*pi) Hz
% Design Parameters
zeta=0.5; % underdamped system design
% Desired Poles
p1= -zeta*wn+wn*sqrt(zeta^2-1);
p2= -zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
% A&B Matrices
A=[0 1 ;-k/m -c/m];
B=[0;1/m];
% Pole Placement design
K=place(A,B,P);
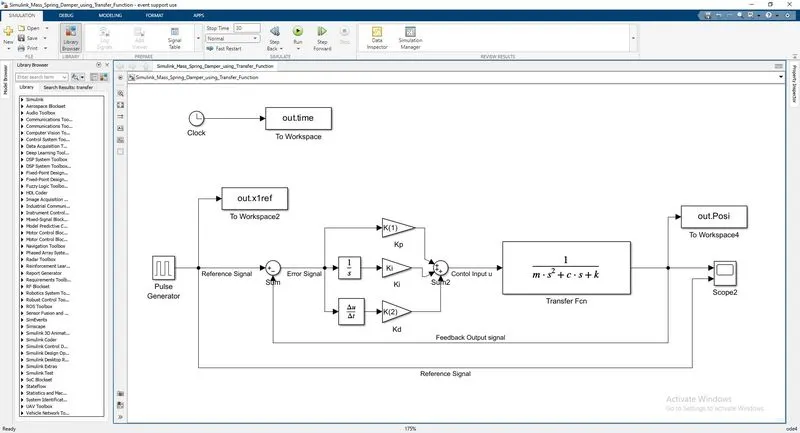
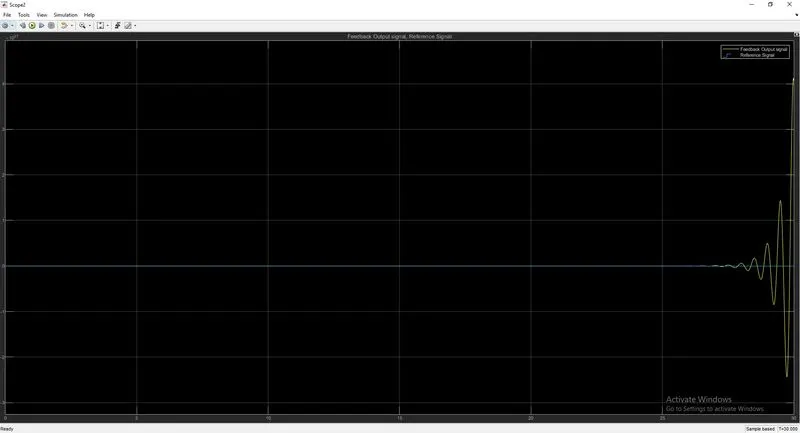
For Ki=1500
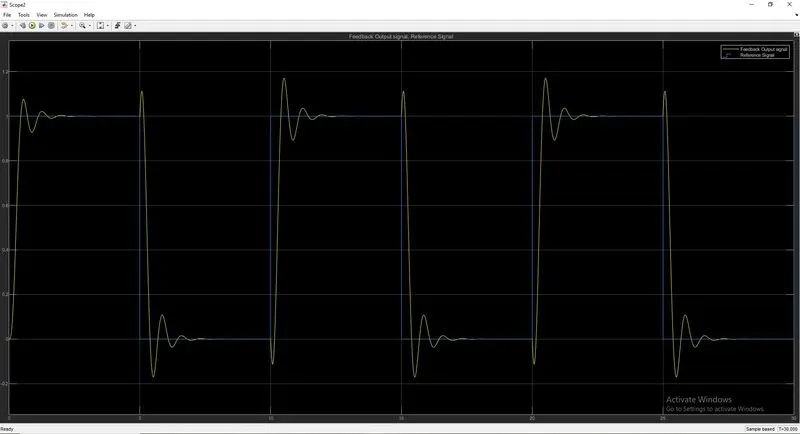
For Ki=0
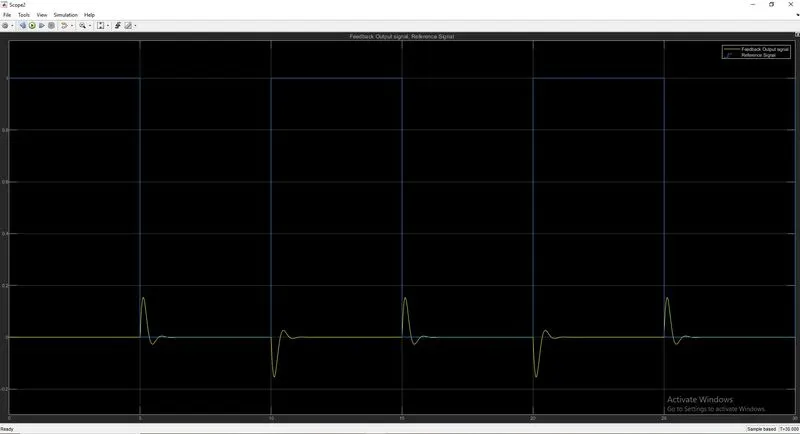
For Ki=2000
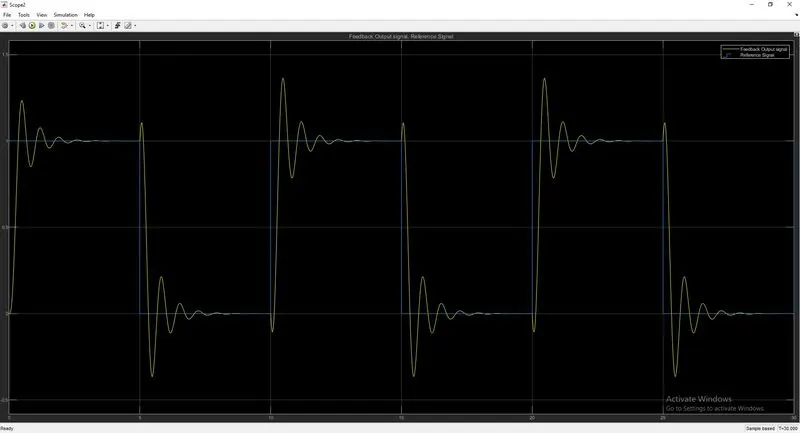
For Ki=5000
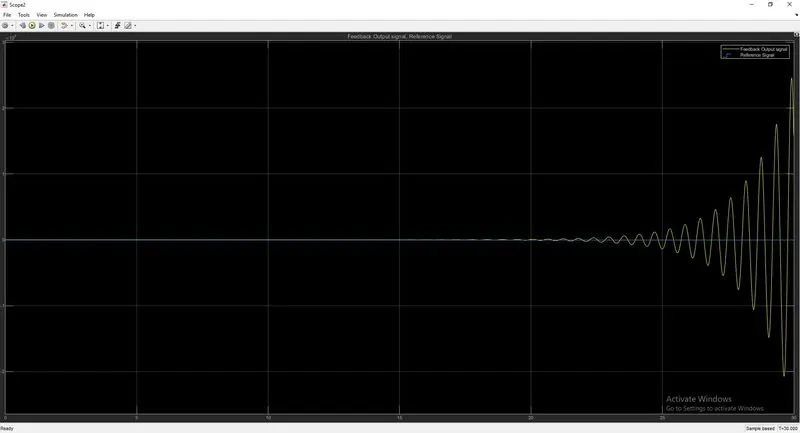
For Ki=9000