Project - Position control of mass spring damper system
Solver Details:
ODE4, Fixed step solver with 0.01s sampling time.
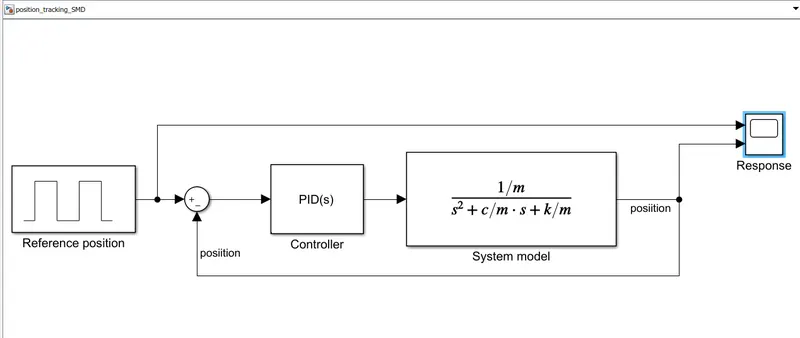
Transfer function of spring mass damper system:
1. standard S-M-D system equation is : `m ddot x+c dot x+k x = u`
`he transfer function of the system can be obtained using S- transfor`
`TF = 1/(ms^2+cs+k)`
2. The reference input is generated using a pulse generated with 10s period and 50% duty ration.
3. A feed back controller is desined using simulink PID autotune to track the reference.
Model Parameters
%Position control of spring mass damper system
% Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
m = 3.6;
k = 400;
c = 100;
Developed Model:
Response:
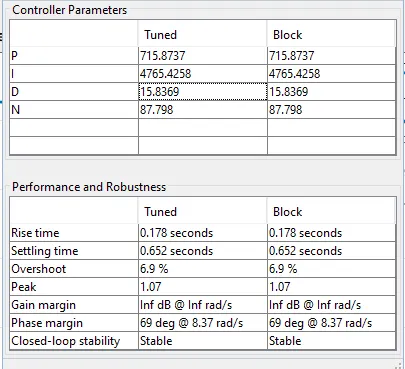
Controller gains of the tuner are Kp = 715.87;Ki = 4765.42; Kd = 15.83;
the response of the system is shown below
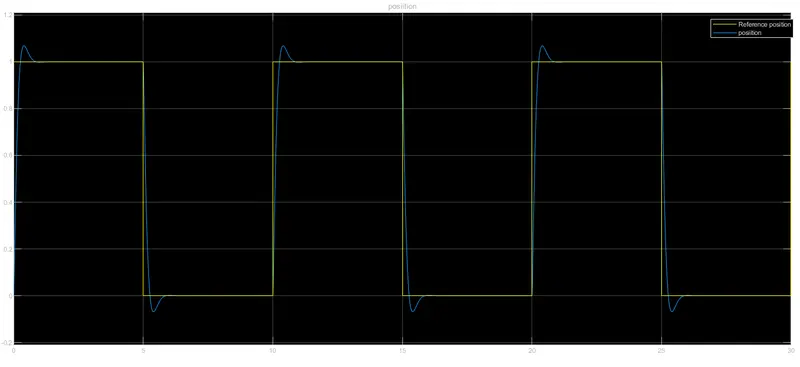
The performance characteristics of the response are