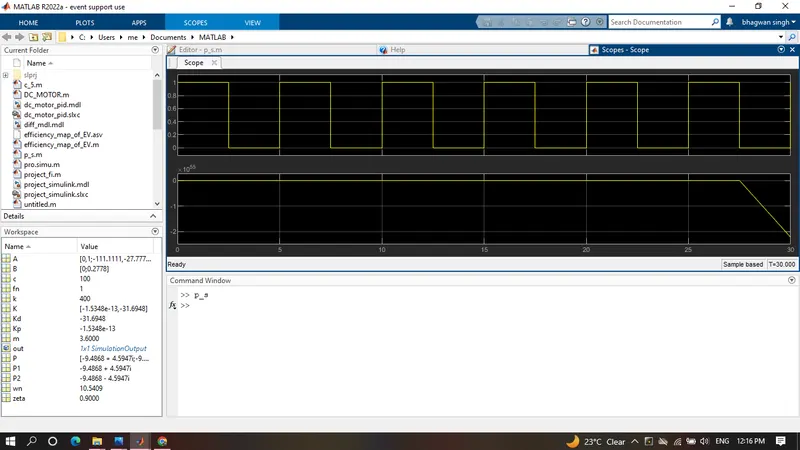
Project - Position control of mass spring damper system
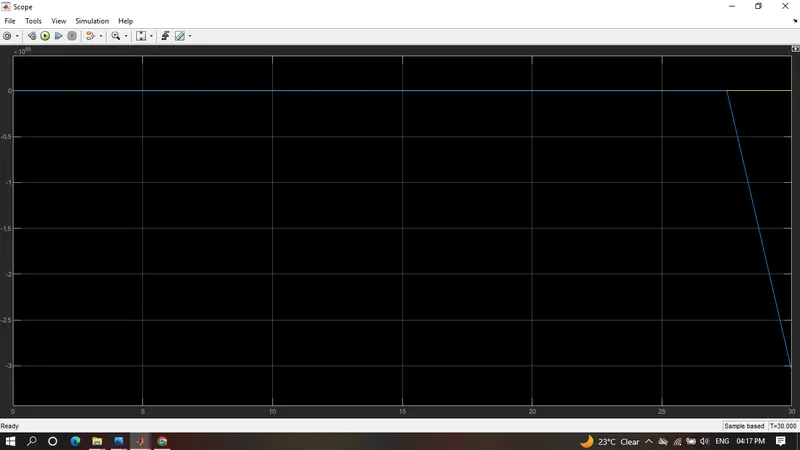
taken blocks to complete the project are pulse generator from simulink source folder as a ref. input, then i make a PID controller by using 3 gain blocks KP(PROPORTIONAL GAIN), KI(INTEGRATIVE GAIN),KD(DERIVATIVE GAIN) respectively, For KI use an integrator block, & for KD a derivative block, after that i made a transfer function with given values of M, K, C, after that i made a M.file to find out the values of kp and kd by giving the values of m k c and natural frequency, zeta and after that find the poles using place command, once i get all the values like kp kd and poles P1,P2. slightly increasing the value of ki i got the final output which are following the refrence input given as pulse generator.