Project - Position control of mass spring damper system
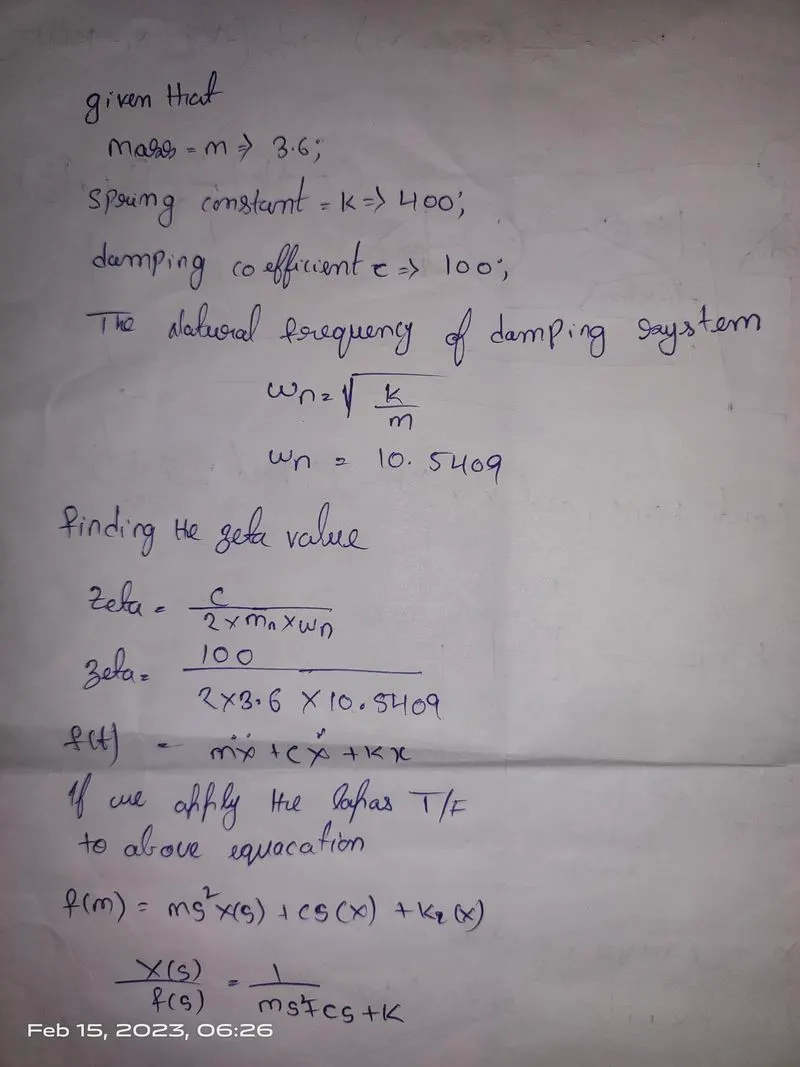
kd=place(a,b,p)
we using of the place commend we get kp and kd value here a,b jacabicum matrix
The jacabiain matrx is matrix partial deravated that change to vector value function with respect to input
p=root[(a,b,p)]
a=2*zeta*wn
b=wn^2
kp=k(1)=5.1159676....;
kd=(k2)=0;
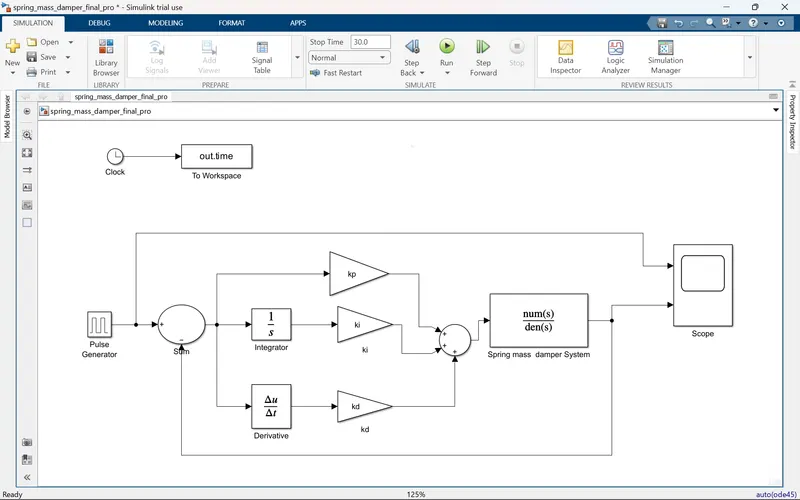
INTERGACTION GAIN:
which represent the proportionatilay constant
between the intter gain and the contral signail
ki=750;
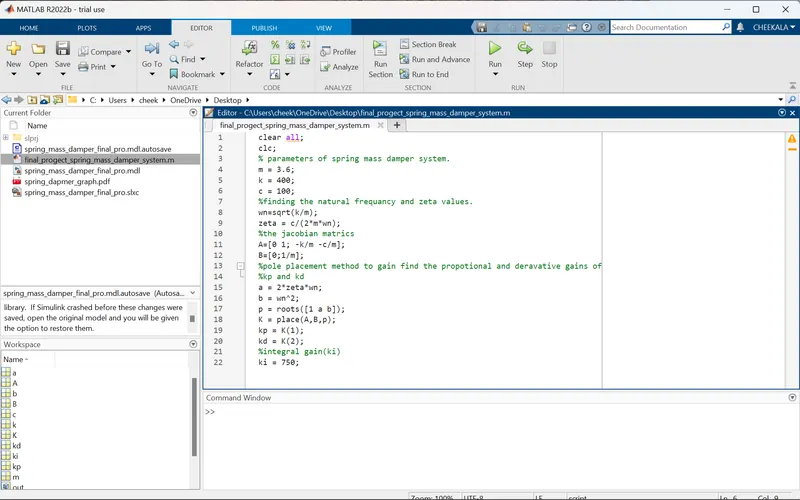
clear all;
clc;
% parameters of spring mass damper system.
m = 3.6;
k = 400;
c = 100;
%finding the natural frequancy and zeta values.
wn=sqrt(k/m);
zeta = c/(2*m*wn);
%the jacobian matrics
A=[0 1; -k/m -c/m];
B=[0;1/m];
%pole placement method to gain find the propotional and deravative gains of
%kp and kd
a = 2*zeta*wn;
b = wn^2;
p = roots([1 a b]);
K = place(A,B,p);
kp = K(1);
kd = K(2);
%integral gain(ki)
ki = 750;