Project
1)
Aim: To prepare a technical report of simulation of BAJA all terrain vehicle under different conditions
Objective: Carry out a system level simulation of all terrain vehicle and prepare a technicals report explaining the model propertieds and comments on the results.
ALL TERRAIN VEHICLE: An all terrain vehicle is defined as a motorized off highway vehicle designed to travel on four low pressure or non pneumatic tires, having a seat designed to be straddled by the operator ans handlebars for steering control.
case1
simulik model of Baja ATV with cvt
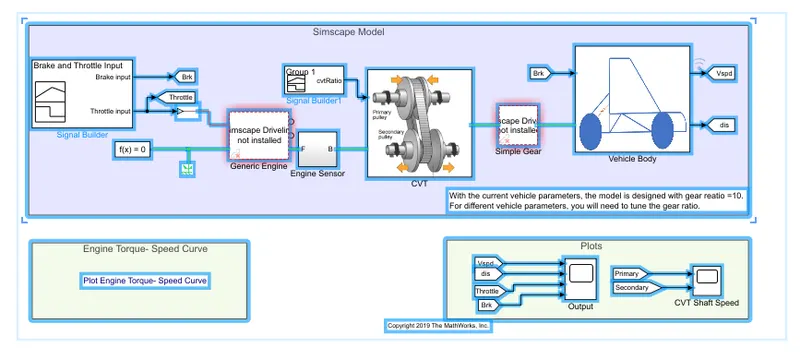
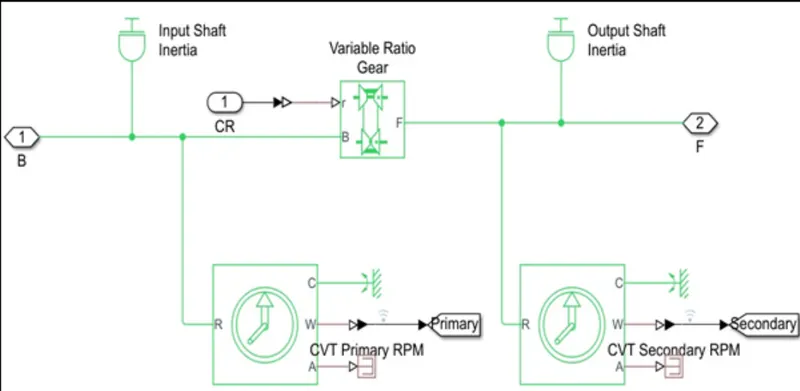
cvt:continuously variable transmission drive
Transmission have more gear means low gear can provide better acceleration while higher gear can maximize fuel economy.CVT differ from traditional automatic transmissions in that they don't have gears that provide steps between low and high speed operations. Instead, the majority of the them work via a pair of variable diameter,cone shaped pulleys connected by a steel or composite belt.
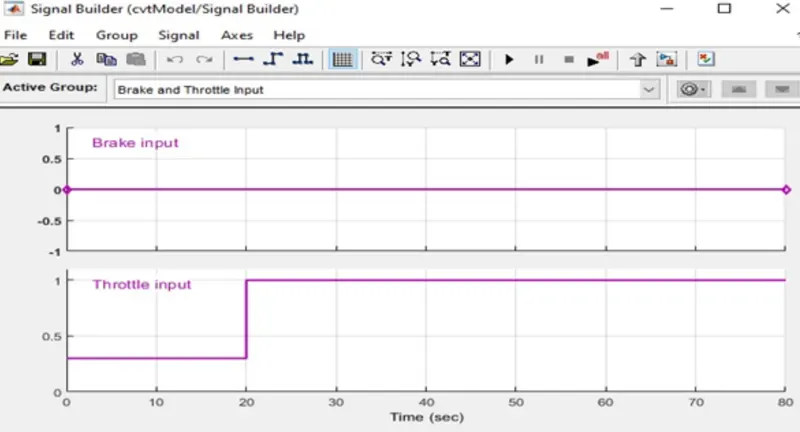
input signal
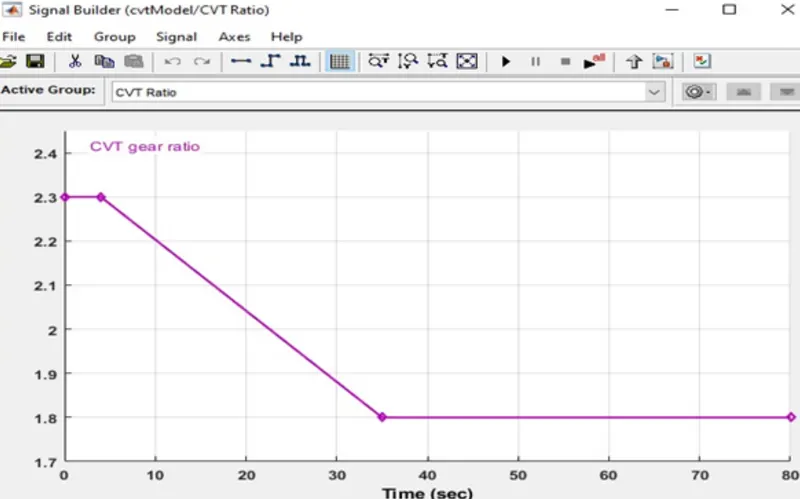
cvt ration input
speed vs torque
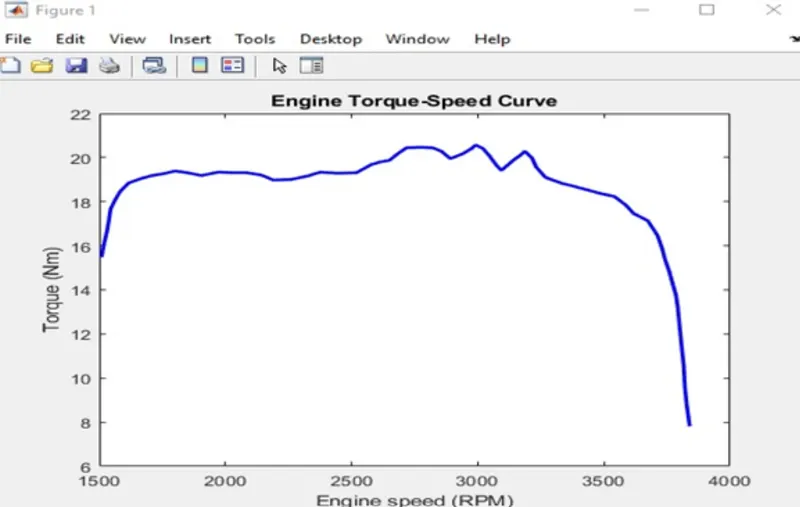
output
vehicle speed
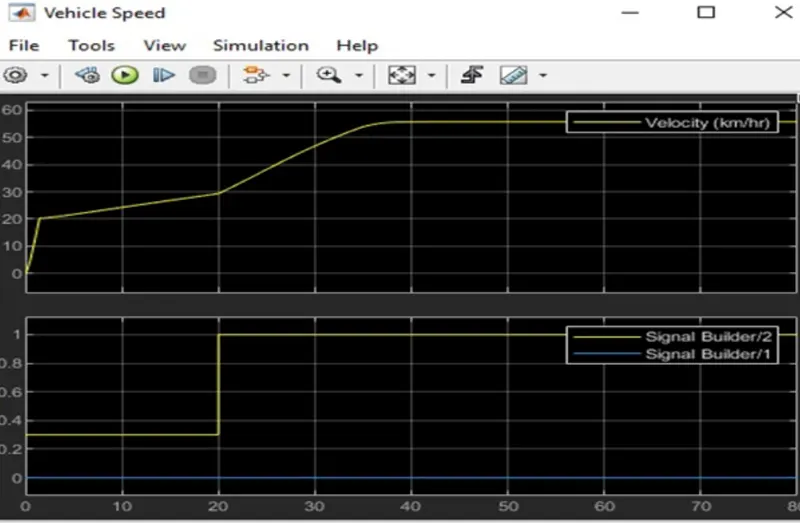
case 2
simulink model of BAJA AVT with cvt and dashboard
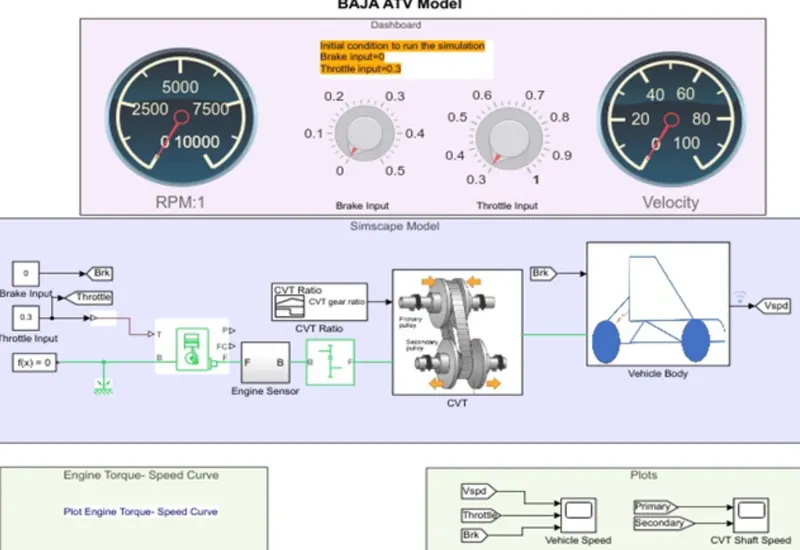
In this model we have control knobs in dashboard to control the inputs, ie we can control the throttle and brake using control knob itself without the need of signal builder.
output
vehicle speed
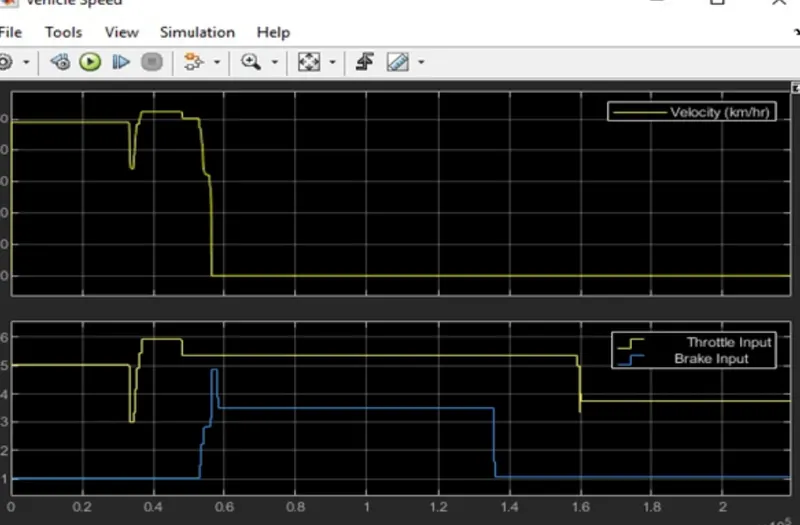
It can be obeserved that the speed of the vehicle is increasing drastically from 0 to 50 when the throttle input is 0.5 and brake is 0. But when the brake value increases from 0.1 to 0.5 the velocity of vehicle reaches zero at constant throttle.This explains the direct relation ship of vehicle velocity with throttle and brake.
cvt shaft speed
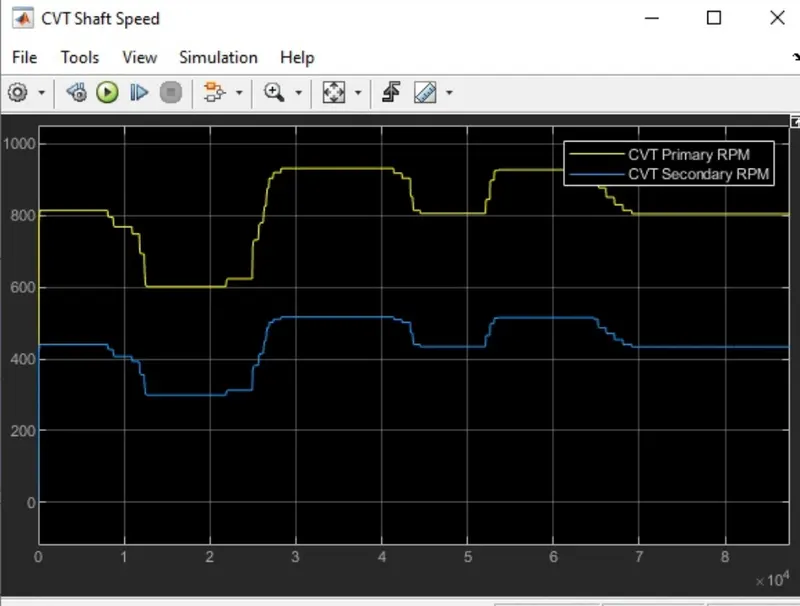
this graph indicates the relation of primary and secondary shaft speed with input throttle and brake.