Project
* Aim:
To carry out system-level simulation of an all terrain vehicle using Simulink.
* All Terrain Vehicle:
An all terrain vehicle is difined as a motorized off-gi==highway vehicle designed to travel on four low pressure or non pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control.
* CVT:
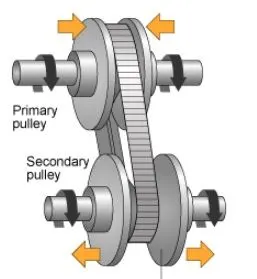
A CVT or Continuously Variable Transmission is an automatic, single-speed and gearless transmission that can shift through an infinite number of gear ratios.
A continuously variable transmission (CVT) is a transmission that operates on an ingenious pulley system that automatically varies the transmission ratio, allowing an infinite variability between highest and lowest gears with no discrete steps or shifts. CVTs provide more useable power, better fuel economy and smoother driving experience that traditional transmissions that use gearboxes with fixed number of gear states.
* How does a CVT transmission works ?:
In the CVT transmission, the pushbelt transfers the torque from one pulley to the other. The level of power transmission is adapted automatically through continuous variable adjustment of the pulleys.
* Blocks used in the Simulink Model of an BAJAJ ATV.
Signal Builder: The signal builder allows you to create interchangeable groups of piecewise linear signal sources and use them in a model.
Generic Engine: It represents a system level model of spark ignition and diesel engines suitable for use at initial stages of modelling when only the basic parameters are available.
Ideal Rotational Motion Sensor: The block represents an ideal mechanical rotational motion sensor, that is a device that converts an across variables measured between two mechanical rotational modes into a control signal proportional to angular velocity or angle.
Simple Gear: Represents a fixed ratio gear. No inertia is modeled in this block and you can optionally include gear.
Inertia: This block represents an ideal mechanical rotational inertia, this block has one mechanical rotational conserving port. The block positive direction is from its port to the reference point.
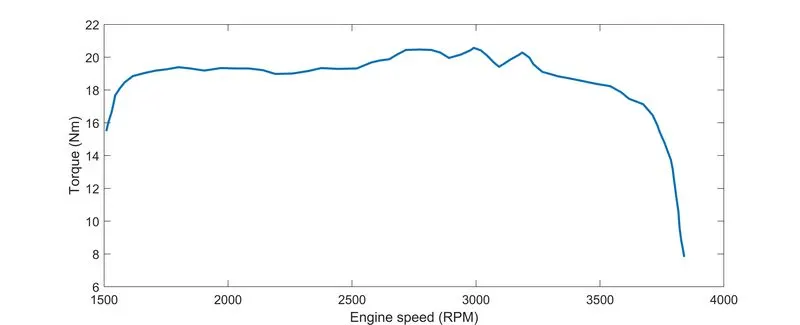
* Torque vs Speed Charactristics:
conclusion:
*) The system level simulation of an all terrain vehicle is carried out.
*) The technical report explaining the model properties and comments on the results was prepared.