Project
An Electric Vehicle (EV) is a vehicle that uses one or more electric motors or traction motors for propulsion. An electric vehicle may be powered through a collector system by electricity from off-vehicle sources, or may be self-contained with a battery, solar panels, fuel cells or an electric generator to convert fuel to electricity.
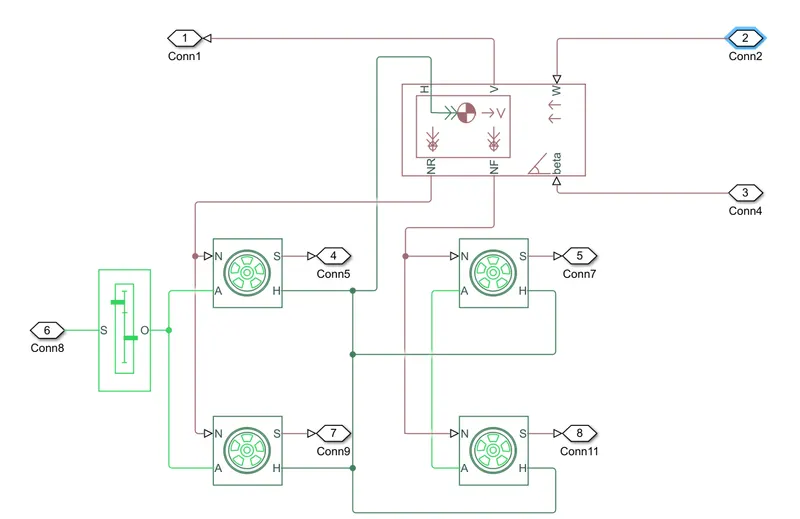
To create the vechile body and tire four wheel design using the electric vehicl the four tire and vehicl body is connecting gear and wheel this the foure wheel tire connection some conecting function is used to the NR and NF W is vehcle body parts
For tire , we entered the below values
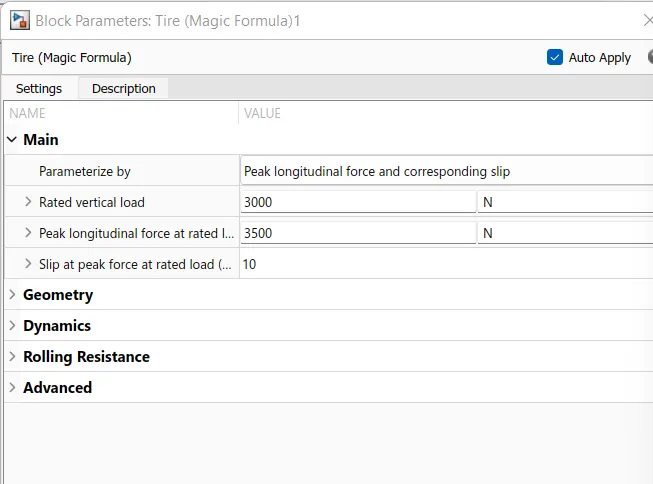
tire is main important of speed of the vehicl controler this is the longutidunal vehcle function working to the foure fitting connection. and to verialble surface speed to change to the performance of tire to electric vehicle. some porte is used in to input and output port of function.
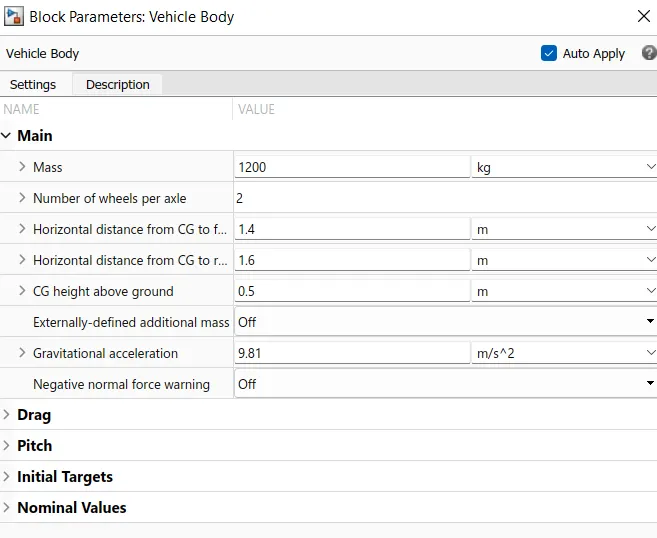
Body of the vehicle
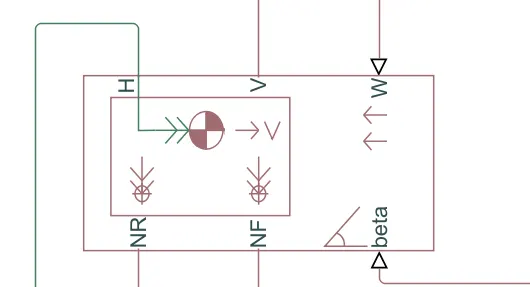
considering as below values
Adding the gearbox now
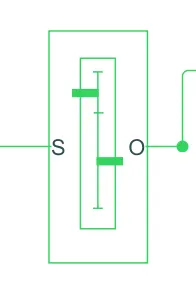
Gear is the function of the S and O is use to the condrole of speed to vehicle. S is the acclerator of inpute speed and O is the output shaft controle the function
Motor controller
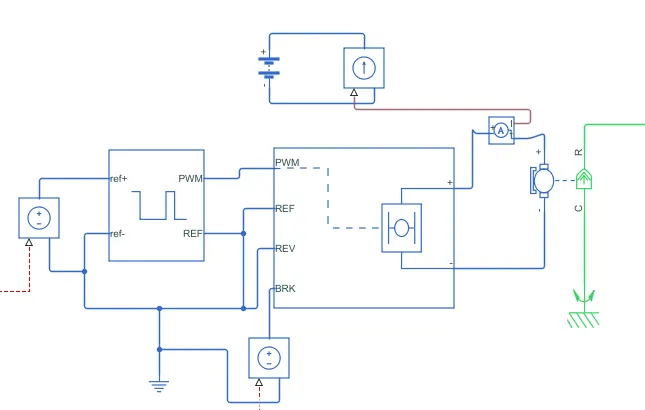
Now adding the battery
PWM controller
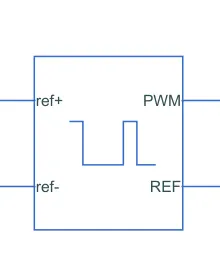
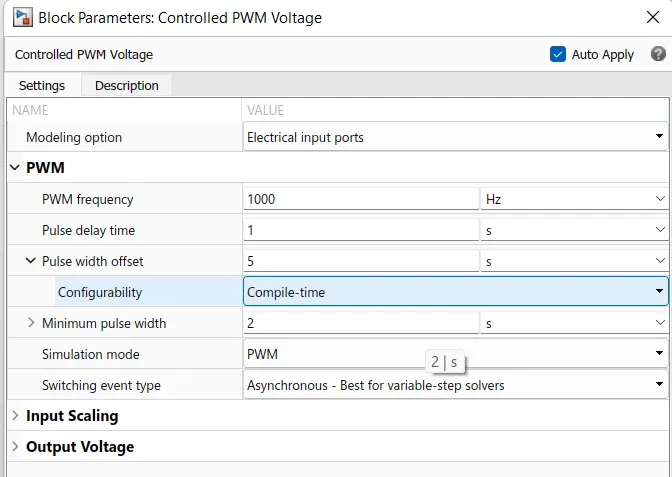
H bridge circuit
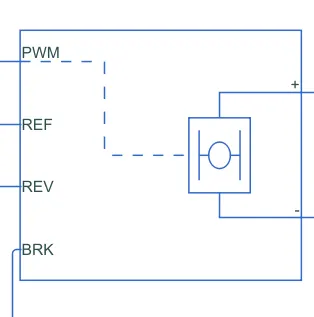
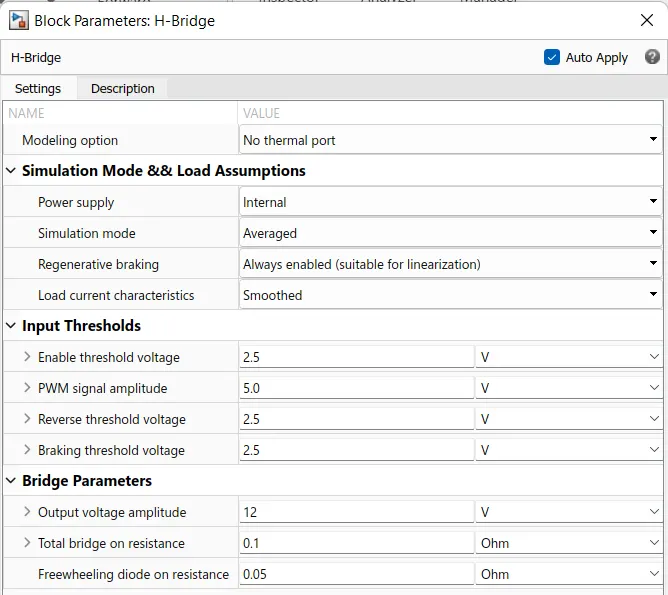
Adding the driver
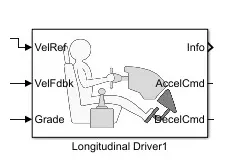
drive cycle , we use this 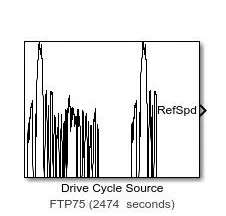
the fulll model is like this
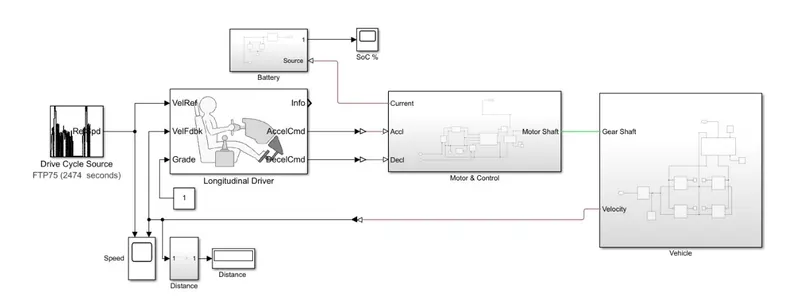
this matlab module is drive cycle source and vel/Ref and vel/Fdbk and speed and destance and motor condrol motor shaft and gear sgaft vehicl body mojer parts of the block to using in electrical vehicle design.
Simulation :
- The system is ran for simulation for 2474 s which is the total time for which the input drive cycle is defined.
- A Solver Configuration is added to ensure proper solving of the mathematical equations by the mode
results
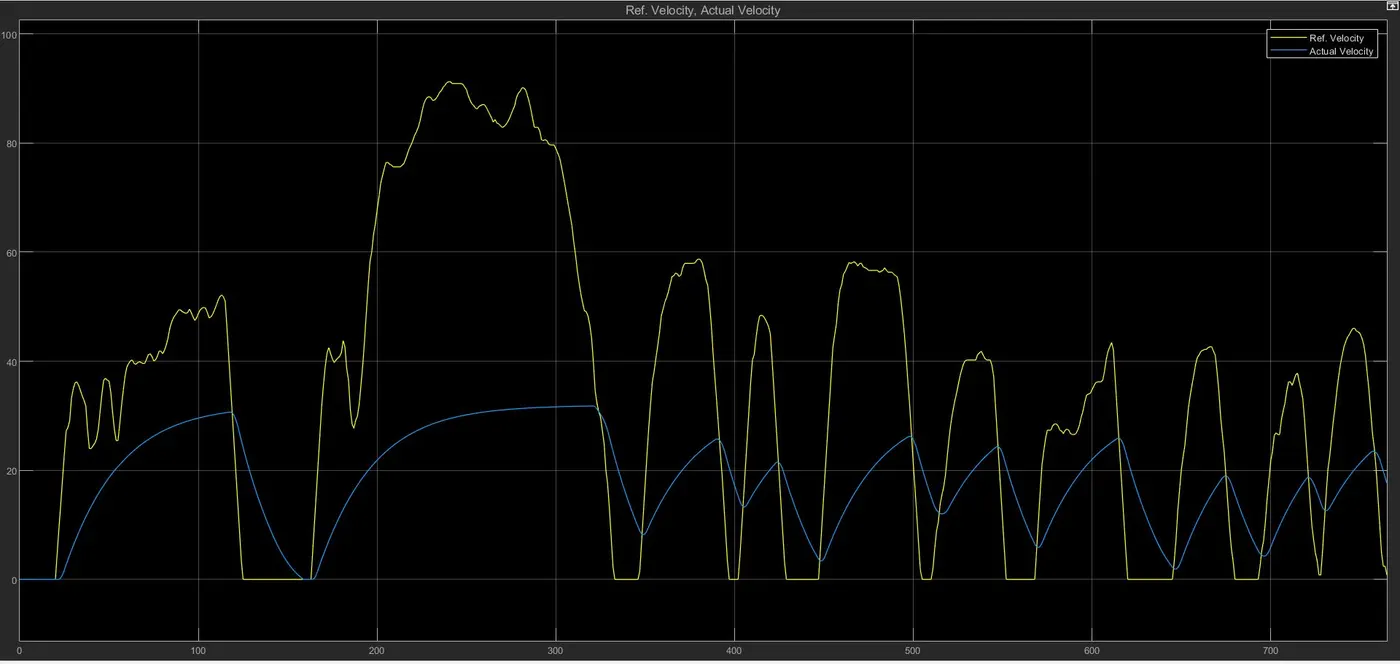
- As can be seen from the above picture, the actual velocity of the vehicle differs from the reference drive cycle velocity.
- This is because, the chosen battery capacity and motors are not able to propel the speed upto the required extent.
- If a battery of higher capacity is chosen, the actual velocity will tend to match with the reference velocity.
- Also, it may be noted that in certain regions, despite the drive cycle showing small decelerations, the vehicle actually is accelerating with decreasing magnitudes. Reason being the same.
CONCLUSION : The model was succesfully ran for simulation under the standard FTP75 drive cycle. The results have been properly analyzed.
- how to model an EV and carry out a real time simulation