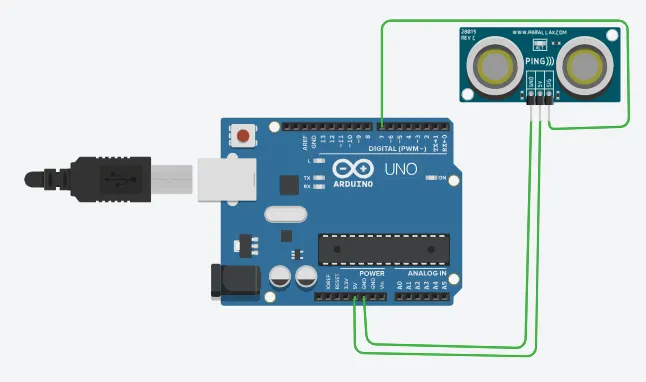
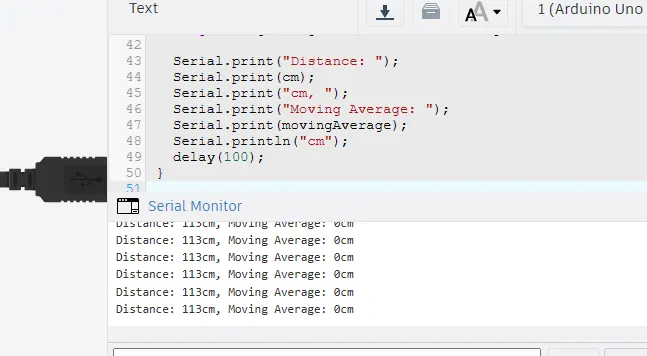
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
const int pingPin = 7;
const int numReadings = 5; // Number of readings for the moving average
void setup() {
Serial.begin(9600);
}
void loop() {
long duration, inches, cm;
// Array to store distance readings for the moving average
long readings[numReadings];
long total = 0;
int index = 0;
// Initially, the code sets the pingpin to a LOW state. After setting the pin to LOW, there's a very short delay of 2 milliseconds. The HIGH state is maintained for a very short duration (5 milliseconds) to create the pulse.
pinMode(pingPin, OUTPUT);
digitalWrite(pingPin, LOW);
delayMicroseconds(2);
digitalWrite(pingPin, HIGH);
delayMicroseconds(5);
digitalWrite(pingPin, LOW);
pinMode(pingPin, INPUT);
duration = pulseIn(pingPin, HIGH);
// Convert the time into a distance
inches = microsecondsToInches(duration);
cm = microsecondsToCentimeters(duration);
/// code will provide a smoother representation of the distance measurements over time by calculating the moving average.
// Add the current reading to the array and update the total
total = total - readings[index];
readings[index] = cm;
total = total + cm;
index = (index + 1) % numReadings;
// Calculate the moving average
long movingAverage = total / numReadings;
Serial.print("Distance: ");
Serial.print(cm);
Serial.print("cm, ");
Serial.print("Moving Average: ");
Serial.print(movingAverage);
Serial.println("cm");
delay(100);
}
long microsecondsToInches(long microseconds) {
// According to Parallax's datasheet for the PING))), there are 73.746
// microseconds per inch (i.e. sound travels at 1130 feet per second).
// This gives the distance traveled by the ping, outbound and return,
// so we divide by 2 to get the distance of the obstacle.
return microseconds / 74 / 2;
}
long microsecondsToCentimeters(long microseconds) {
// The speed of sound is 340 m/s or 29 microseconds per centimeter.
// The ping travels out and back, so to find the distance of the object we
// take half of the distance traveled.
return microseconds / 29 / 2;
}