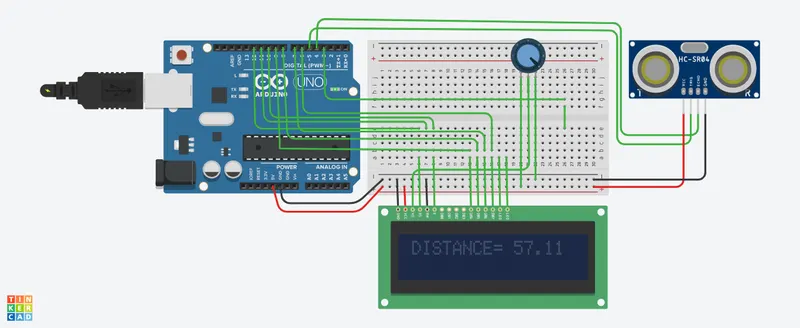
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
#include <LiquidCrystal.h>
LiquidCrystal lcd(12,10,9,8,7,6);
int trigerpin=5;
float echo=4 ;
float speedOfSound=346; //meter per sec
float pingtime;
float dist;


void setup()
{ Serial.begin(9600);
  lcd.begin(16,2);
  lcd.setCursor(0,0);
  lcd.print("DISTANCE=");
  pinMode(trigerpin,OUTPUT);
  pinMode(echo,INPUT);
}

void loop()
{
  digitalWrite(trigerpin,LOW);
  delayMicroseconds(2000);
  digitalWrite(trigerpin,HIGH);
  delayMicroseconds(15);
  digitalWrite(trigerpin,LOW);
  delayMicroseconds(10);
  pingtime=pulseIn(echo,HIGH);
  dist=pingtime*speedOfSound/20000;
  Serial.println(dist);
  lcd.setCursor(10,0);
  lcd.print(dist);
  delay(1000);
}
screenshot of output: