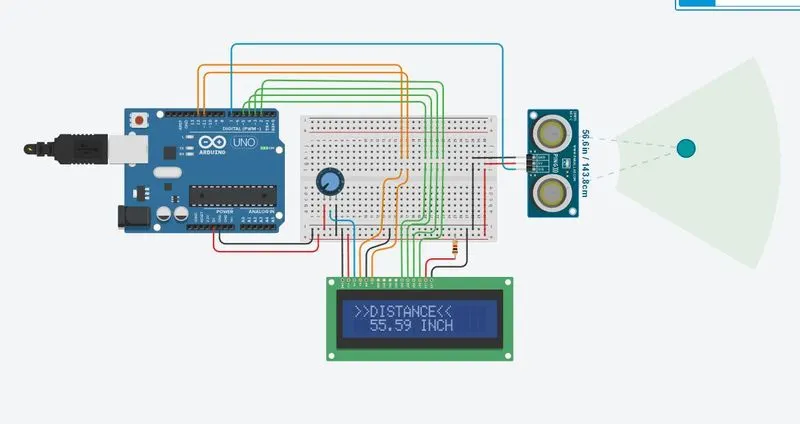
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
// C++ code
//
/*Distance= (travel time/2) * speed of sound
Where speed of sound around 340m per second.
So distance travel in one microsecond is
=340 / 1000000
= 0.00034m/microsecond
=0.00034 X 100 cm/microsecond
=0.034cm / microsecond
Distance= (travel time/2) * speed of sound
=we divide it by 2
=hence 0.017 cm/microsecond
Now input receive by ultrasonic sensor will have time duration in microsecond
If we multiply by this number we directly will get distance in cm. to convert it in inch again value will be diveide by 2.54cm.
*/
#include<LiquidCrystal.h>
//library for Liquid Crystal
#define WINDOW_SIZE 5
//window size for filter
int trigger;
//for sending data pin 7 to assigning variable name trigger
int echopin;
//same pin variable name is echopin
float CM;
//
float INCH ;
//
float inch;
float average=0;
float sum;
int index;
int reading[WINDOW_SIZE];
LiquidCrystal LCD(12,11,5,4,3,2);
void setup()
{
//LiquudCrystal LCD(RS,E,D4,D5,D6,D7);
LCD.begin(16,2);
// filter initializing
LCD.setCursor(0,0);
LCD.print(">>DISTANCE<<");
//LCD intial set um for distance measurement
LCD.setCursor(0,1);
LCD.print("MEASUREMENT");
delay(2000);
LCD.clear();
Serial.begin(9600);
}
void loop()
{
sum=sum-reading[index];
CM = 0.01723 * readUltrasonicDistance(7, 7);
//calling the function to send receive microseconds
reading[index]=CM;
//index will change from 0 to 5
sum=sum+reading[index];
index=(index+1)%WINDOW_SIZE;
//to increment index
average=sum/WINDOW_SIZE;
//taking average of the receive value
INCH = (CM/ 2.54);
inch=(average/2.54);
// converting it in inch
delay(10);
/* LCD.setCursor(0,0);
LCD.print(">>DISTANCE<<");
LCD.setCursor(0,1);
LCD.print(average);
LCD.setCursor(5,1);
LCD.print("CM");
delay(1000);
LCD.clear();*/
// diplaying on LCD measureement
LCD.print(">>DISTANCE<<");
LCD.setCursor(2,1);
LCD.print(inch);
LCD.setCursor(8,1);
LCD.print("INCH");
delay(200);
LCD.clear();
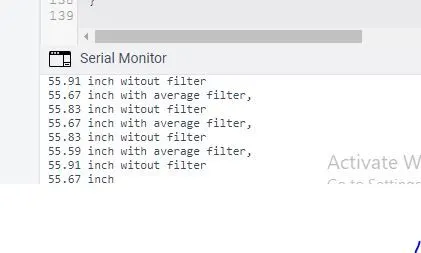
Serial.print(INCH);
Serial.print(" inch witout filter \n");
Serial.print(inch);
Serial.print(" inch with average filter, \n");
/* Serial.print(CM);
Serial.println("cm");
Serial.print(average);
Serial.print("filter cm, ");
delay(100); // Wait for 100 millisecond(s)*/
}
//called function
long readUltrasonicDistance(int trigger, int echopin)
{
pinMode(trigger,OUTPUT);
//initial is pin sevn is high
digitalWrite(trigger,LOW);
delay(2);
//sending low pulse initially
digitalWrite(trigger,HIGH);
delay(10);
//pulse will remain high for 10milis
digitalWrite(trigger,LOW);
//again low so it will get pulse of 10millis
pinMode(echopin,INPUT);
return pulseIn(echopin, HIGH);
//pulseIn function checks status of echopin is it goes from low to high or not returns the value
}