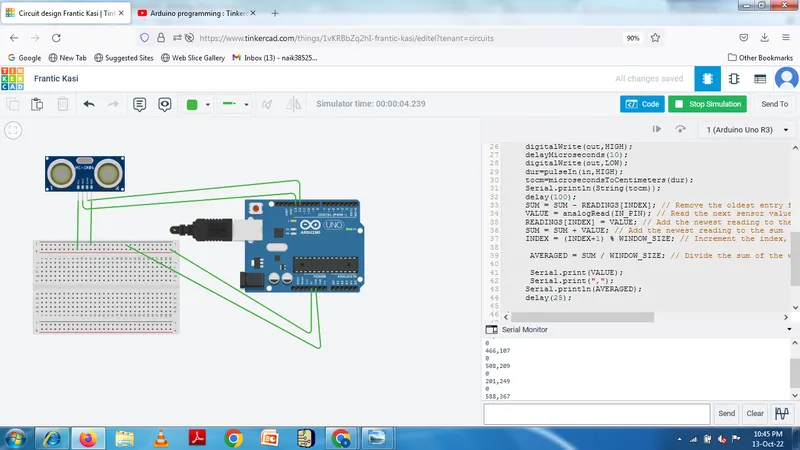
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
1.sollution
code:
#define IN_PIN A0
#define WINDOW_SIZE 5
const int out=12;
const int in=13;
int INDEX = 0;
int VALUE = 0;
int SUM = 0;
int READINGS[WINDOW_SIZE];
int AVERAGED = 0;
void setup()
{
pinMode(in, INPUT);
pinMode(out, OUTPUT);
pinMode(IN_PIN, INPUT);
Serial.begin(9600);
}
void loop()
{
long dur;
long dis;
long tocm;
digitalWrite(out,LOW);
delayMicroseconds(2);
digitalWrite(out,HIGH);
delayMicroseconds(10);
digitalWrite(out,LOW);
dur=pulseIn(in,HIGH);
tocm=microsecondsToCentimeters(dur);
Serial.println(String(tocm));
delay(100);
SUM = SUM - READINGS[INDEX]; // Remove the oldest entry from the sum
VALUE = analogRead(IN_PIN); // Read the next sensor value
READINGS[INDEX] = VALUE; // Add the newest reading to the window
SUM = SUM + VALUE; // Add the newest reading to the sum
INDEX = (INDEX+1) % WINDOW_SIZE; // Increment the index, and wrap to 0 if it exceeds the window size
AVERAGED = SUM / WINDOW_SIZE; // Divide the sum of the window by the window size for the result
Serial.print(VALUE);
Serial.print(",");
Serial.println(AVERAGED);
delay(25);
}
long microsecondsToCentimeters(long microseconds)
{
return microseconds / 29 / 2;
}
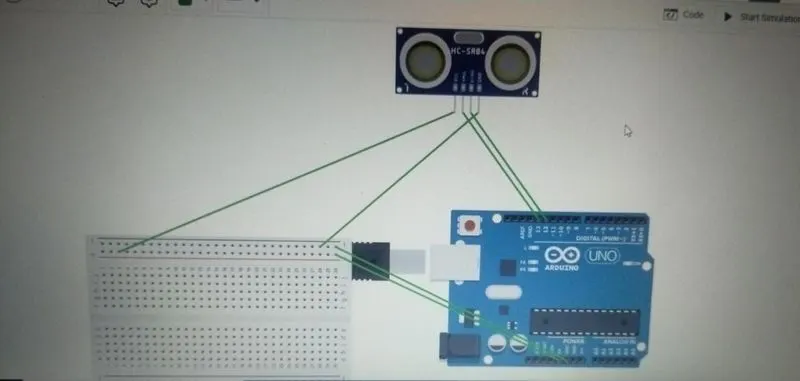
Circuit Diagram:
Output :
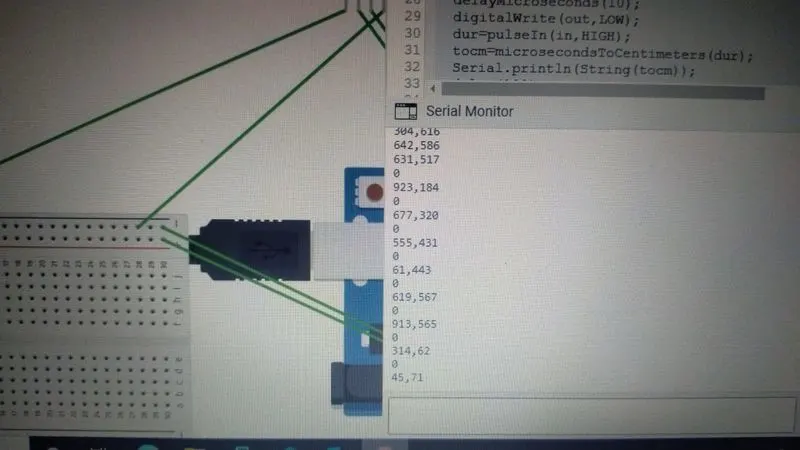
output: