Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
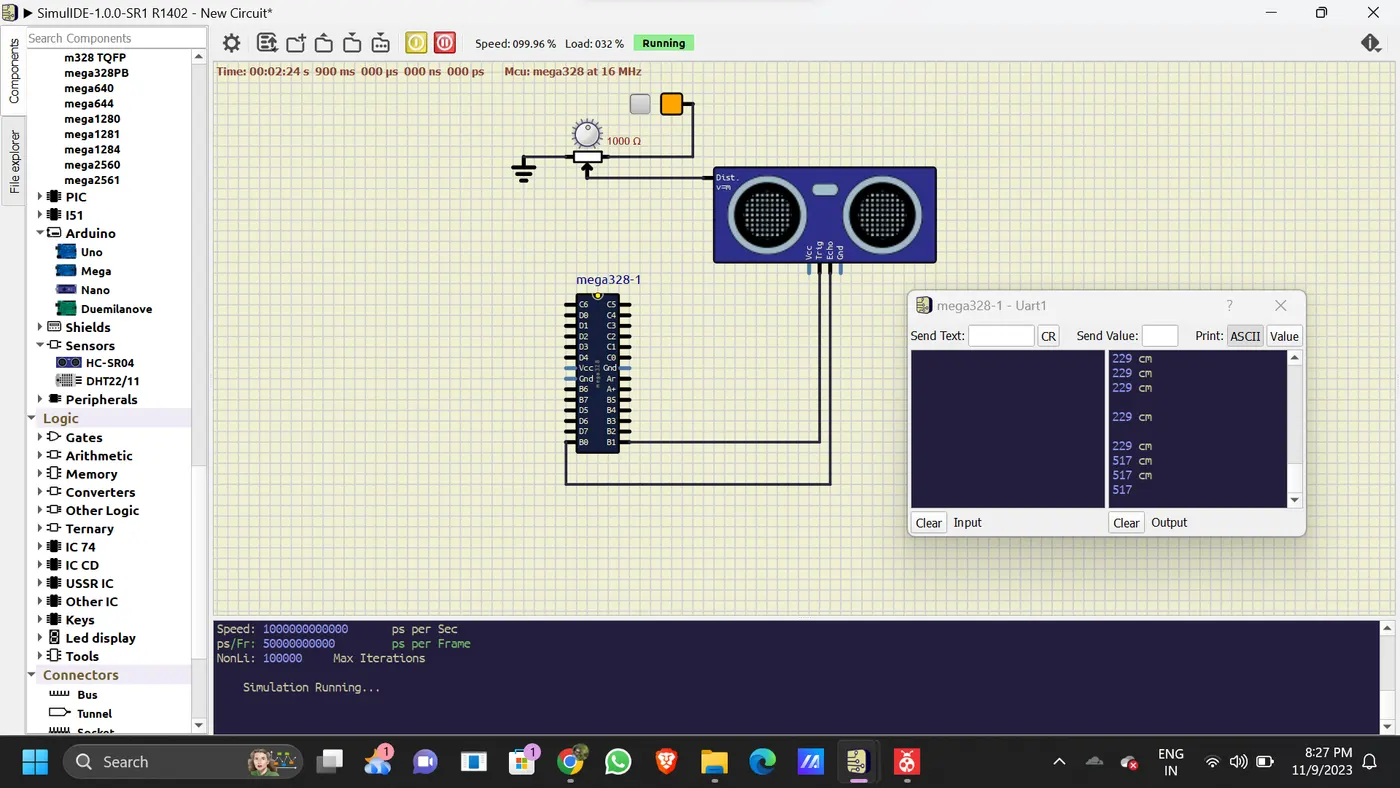
PROJECT 2 OUTPUT SCREEN SHOTS
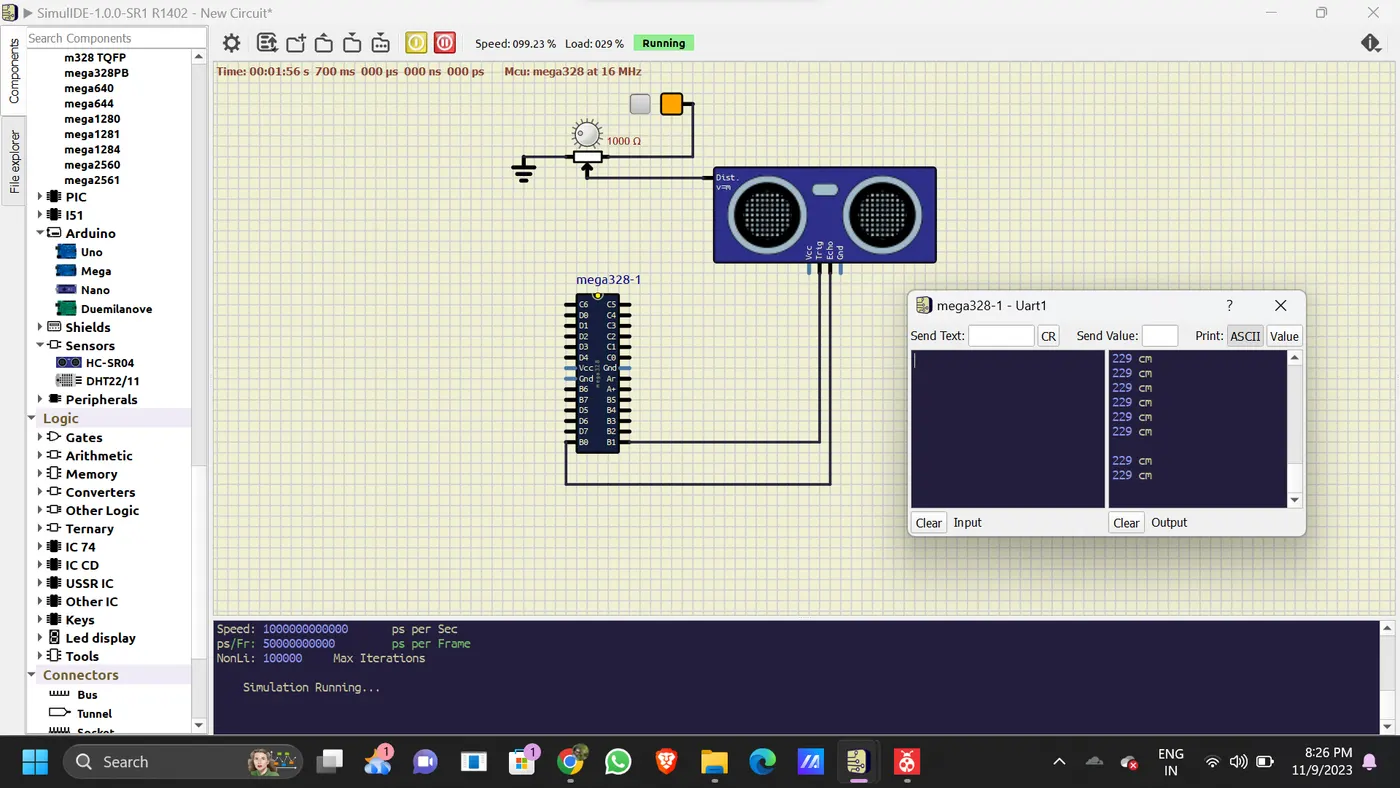
OUTPUT SCREEN SHOT 2
CODE FOR PROJECT 2
#define F_CPU 16000000
#include
#include
#include
#define BAUD_RATE 9600
void USART_Init(unsigned int baud);
void USART_Transmit(unsigned char data);
unsigned char USART_Receive(void);
void initHC_SR04(void);
unsigned int getDistance(void);
int main(void) {
USART_Init(BAUD_RATE);
initHC_SR04();
sei(); // Enable global interrupts
while (1) {
unsigned int distance = getDistance();
// Print distance to serial monitor
char buffer[10];
sprintf(buffer, "%u cm\r\n", distance);
for (int i = 0; buffer[i] != '\0'; i++) {
USART_Transmit(buffer[i]);
}
_delay_ms(1000); // Wait for 1 second
}
return 0;
}
void USART_Init(unsigned int baud) {
// Set baud rate
UBRR0H = (unsigned char)(baud >> 8);
UBRR0L = (unsigned char)baud;
// Enable receiver and transmitter
UCSR0B = (1 << RXEN0) | (1 << TXEN0);
// Set frame format: 8 data, 1 stop bit
UCSR0C = (3 << UCSZ00);
}
void USART_Transmit(unsigned char data) {
// Wait for empty transmit buffer
while (!(UCSR0A & (1 << UDRE0)))
;
// Put data into buffer, sends the data
UDR0 = data;
}
unsigned char USART_Receive(void) {
// Wait for data to be received
while (!(UCSR0A & (1 << RXC0)))
;
// Get and return received data from buffer
return UDR0;
}
void initHC_SR04(void) {
// Set PB0 as input for Echo
DDRB &= ~(1 << PB0);
// Set PB1 as output for Trigger
DDRB |= (1 << PB1);
}
unsigned int getDistance(void) {
unsigned int duration;
// Trigger pulse
PORTB |= (1 << PB1); // Set PB1 high
_delay_us(10); // Wait for 10 microseconds
PORTB &= ~(1 << PB1); // Set PB1 low
// Measure pulse duration
while (!(PINB & (1 << PB0))) // Wait for Echo to go high
;
TCNT1 = 0; // Clear Timer1 counter
TCCR1B |= (1 << CS11); // Start Timer1 with prescaler 8
while (PINB & (1 << PB0)) // Wait for Echo to go low
;
TCCR1B = 0; // Stop Timer1
// Calculate distance in centimeters
duration = (unsigned int)(TCNT1 * 0.034 / 2);
return duration;
}