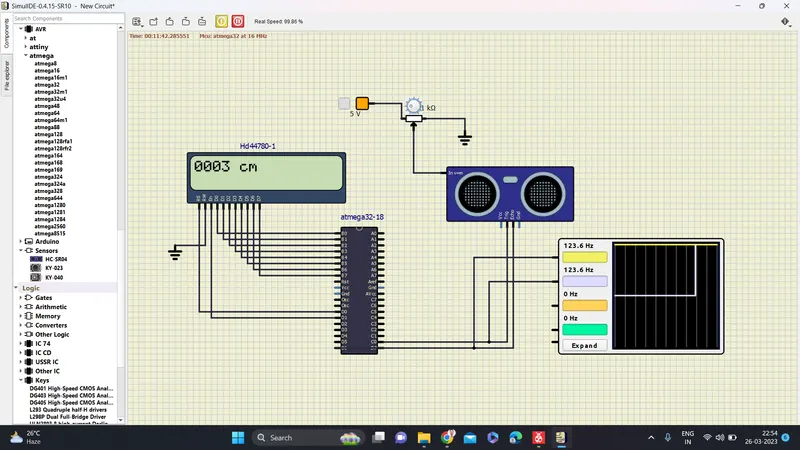
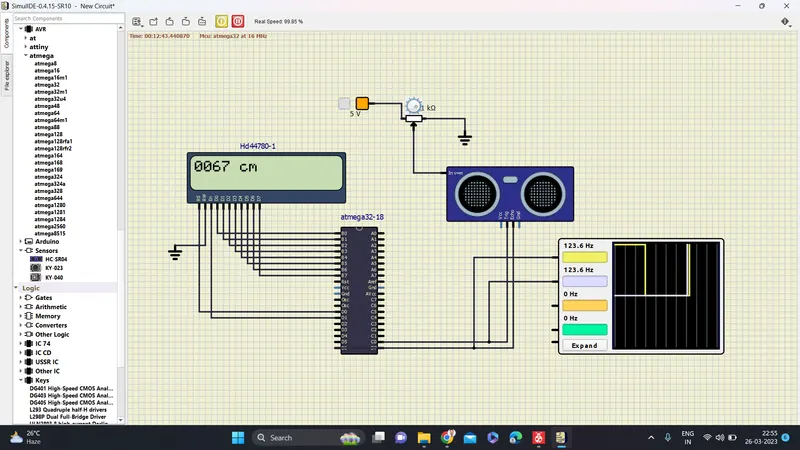
Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
// Project 2 - Measuring distance of an object using ultrasonic sensor (HC-SR04)
Overview of the Project:
In this project, the implementation of code for “Measuring distance of an object using ultrasonic distance sensor (HC-SR04)
Goals:
- Measuring the distance of an object using Ultrasonic Distance Sensor (HC-SR04)
- Usage of Input Capture Mode
Key Highlights of the Project:
- Measuring the distance travelled by the wave to the object and gets bounced back from the object to sensor.
- Measuring Pulse width using Input Capture Mode
Deliverables of this project:
- The distance travelled by a wave to the object for which we want to measure the distance using Ultrasonic Distance Sensor (HC-SR04).
- Measuring Pulse width using Input Capture Mode of Timer 1
Expected Outcomes:
The students will get the Knowledge on Ultrasonic sensor (HC-SR04) to measure the distance travelled by wave to the object, the hardware connection of Atmega328p and HC-SR04 and how to use input capture mode of Timer1
#include
#define F_CPU 16000000L
#include
#include "avr/interrupt.h"
#define lcdport PORTB
#define rs_high PORTD|=(1<<0);
#define rs_low PORTD &=~(1<<0);
#define en_high PORTD |=(1<<1);
#define en_low PORTD &=~(1<<1);
unsigned int tov=0, count, distance;
void lcd_command(unsigned char cmd);
void lcd_data(unsigned char data);
void lcd_init();
void cursorpos(char x, char y);
void lcd_out(char x, char y, char *str);
void lcd_print(char row, char coloumn, unsigned int value, int digits);


int main()
{
	DDRB=0xff;   // PORTB as output
	DDRD|=(0<<6); //PORTD pin 6 as input from echo pin of sensor
	DDRC |=(1<<0);  // PORTC. 0 as output
	sei();          // Enable global interrupt
	lcd_init();
	TCCR1A=0x00;     //Normal mode
	TIMSK|=(1<<2);

	while(1)
	{
		PORTC |=(1<<0);  //Trigger Sensor
		_delay_us(10);
		PORTC&=~(1<<0);

		TCCR1B=0x41;   // ICF Enable
		TCNT1=0;
		TIFR=(1<2)||(y<1||y>16)) // LCD is 16x2
	{
		x=1;
		y=1;
	}
	if(x==1)
	lcd_cmd(0x7f+y); //specifying points to avoid descrepencies
	else
	lcd_cmd(0xbf+y);
}
void lcd_out(char x, char y, char *str)
{
	cursorpos(x,y);
	while(*str)
	{

		lcd_data(*str);
		str++;
	}
}
void lcd_print(char row, char coloumn, unsigned int value, int digits)
{
	unsigned int temp, unit, tens, hundred,thousand, million;
	unsigned char flag=0;
	if(row==0||coloumn==0)
	{

		cursorpos(1,1);
	}
	else
	{
       cursorpos(row,coloumn);
	}
	if(digits==5||flag==1)
	{
		million=value/10000+48; //1st digit on display
		lcd_data(million);
		flag=1;
	}
	if(digits==4||flag==1)
	{
		temp=value/1000; //2nd digit on display
		thousand=temp%10 +48;
		lcd_data(thousand);
		flag=1;
	}
	if(digits==3||flag==1)
	{
		temp=value/100; //3rd digit on display
		hundred=temp%10 +48;
		lcd_data(hundred);
		flag=1;
	}
	if(digits==2||flag==1)
	{
		temp=value/10; //4th digit on display
		tens= temp%10 +48;
		lcd_data(tens);
		flag=1;
	}
	if(digits==1||flag==1)
	{
		unit=value%10 +48; //5th digit on display
		lcd_data(unit);
	}
	if(digits>5)
	{
		lcd_data('e'); // show error [e] for more than 5 digits
	}

}
Output :