Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Overview of the Project: In this project, a Finite State Machine is used to manage the retraction and extension of an airplane's landing gear (FSM). The most efficient algorithm is the FSM, which is a mathematical processing model.
Actually an airplane has 3 gears for landing: Nose gear, Left gear, Right gear.
There is an electrically powered hydraulic pump that applies pressure to the gears to bring it down or pull it up.
There is a limit switch on each leg of the gear. One extra squat switch is installed in the nose gear to assess whether the plane is on the ground or not.
Goals:
Valve's direction can be controlled.
Controlling the retraction and extension of the landing gear on an aeroplane.
Limit switches: Every leg of the gear has one limit switch.
Squat switch: only nose gear have squat switch to determine whether the airplan is in ground or not.
| Switch state | State of Gears |
| Limit Switch CLOSED | Gear is UP |
| Limit Switch OPENED | Gear is DOWN |
| Switch State | State of Airplane |
| Squat Switch CLOSED | Airplane is grounded and gears are locked |
| Squat Switch OPENED | Airplane is taking off/ landing/ airborne |
A direction valve is controlled by software to allow the hydraulic pressure to either raise or lower the landing gear
| Status of Direction Valve | States of landing gear |
| Direction valve = Down | (Gear Down) (Parked at bay or Landed) |
| Direction valve = Up | Raising Gear (Taking Off) |
| Control of hydraulic pump for the landing gear part is disabled | Gear up (Airborne) |
| Direction valve = down | Lowering Gear (Landing) |
Input for the direction valve :
| Pilot's Lever State | Direction Valve State |
| Lever UP | Direction valve = Up |
| Lever Down | Direction valve = Down |
| Pilot's Lever State | Light Status |
| Lever Rising Edge | Red |
| Lever Falling Edge | Red |
Every gear has one light. According to the state of the gear, color of the light is changing.
| Landing Gear State | Light Status |
|
Gear is up |
OFF |
| Gear is down | Green |
| Gear in transit | Red |
C CODE
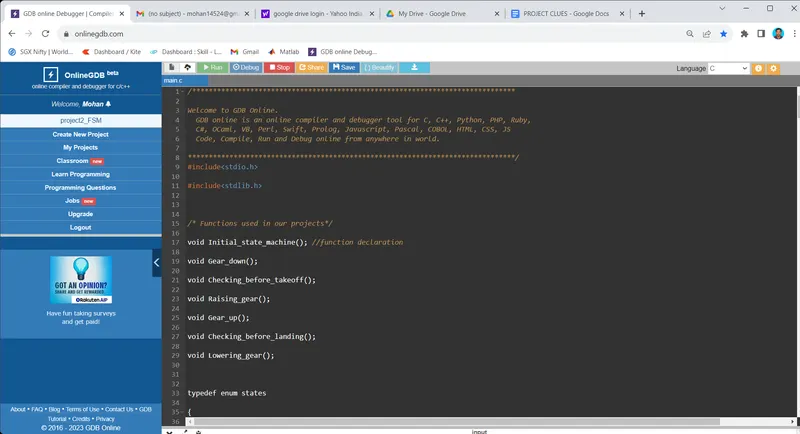
#include<stdio.h>
#include<stdlib.h>
/* Functions used in our projects*/
void Initial_state_machine(); //function declaration
void Gear_down();
void Checking_before_takeoff();
void Raising_gear();
void Gear_up();
void Checking_before_landing();
void Lowering_gear();
typedef enum states
{
GEAR_DOWN, //ENUM IS USED TO GIVING SUBSEQUENT VALUE FOR EACH STATES
CHECK_BEFORE_TAKEOFF,
RAISING_GEAR,
GEAR_UP,
CHECK_BEFORE_LANDING,
LOWERING_GEAR
}state_type;
typedef enum Switch
{
open, //open=0,close=1;
close //plane is in ground
}Switch_status;
typedef enum pilot_lever
{
raising, //by using enum rising =0,falling=1,up=3and down=4 is assumed
falling,
up,
down
}pilot_lever_status;
typedef enum hydraulic_mechanism
{
working, //here 0 means for working and 1 means for malfunction
malfunctioning
}hydraulic_mechanism_status;
/* input used in order to change the state */
static volatile Switch_status squat_switch;
static volatile Switch_status limit_switch;
static volatile pilot_lever_status pilot_lever;
static volatile pilot_lever_status hydraulic_mechanism;
state_type current_state;
typedef struct // structure is used to have different types of data type
{
char* current_state_status; //output which we want to visualize are given under structure as structure member.
char* light_status;
char* direction_value_status;
char* hydraulic_pump_ctrl_status;
char* gas_pressurized_spring_status[2];
}state_table;
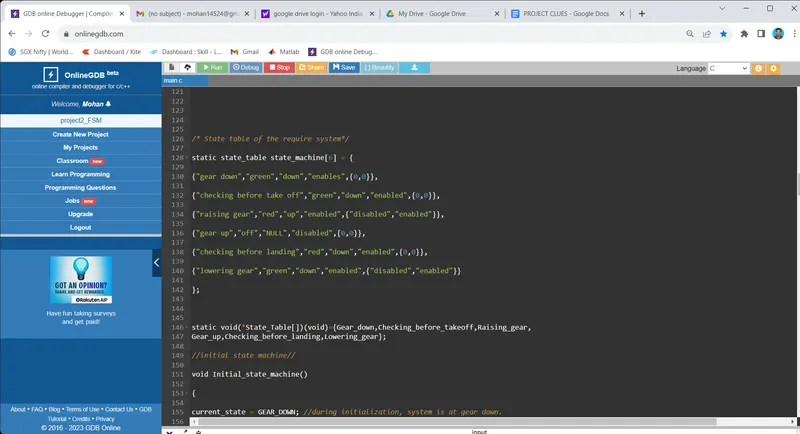
/* State table of the require system*/
static state_table state_machine[6] = {
{"gear down","green","down","enables",{0,0}},
{"checking before take off","green","down","enabled",{0,0}},
{"raising gear","red","up","enabled",{"disabled","enabled"}},
{"gear up","off","NULL","disabled",{0,0}},
{"checking before landing","red","down","enabled",{0,0}},
{"lowering gear","green","down","enabled",{"disabled","enabled"}}
};
static void(*State_Table[])(void)={Gear_down,Checking_before_takeoff,Raising_gear,
Gear_up,Checking_before_landing,Lowering_gear};
//initial state machine//
void Initial_state_machine()
{
current_state = GEAR_DOWN; //during initialization, system is at gear down.
printf("\n state machine is initials and at first program is in gear down and its light status is:%s\n",state_machine[current_state].light_status);
}
//Gear down//
void Gear_down(void)
{
current_state =GEAR_DOWN;
printf("\n Enter the pilot's lever position and squat switch status:\n");// getting pilot lever and squat switch value from input
fflush(stdout);
scanf("%d %d",&pilot_lever,&squat_switch);
if(pilot_lever == raising && squat_switch == open) // if pilot lever raising(0) and squar switch is open(0)
{
current_state = CHECK_BEFORE_TAKEOFF;
printf("\n The current state of the machine is: %s\n",state_machine[current_state].current_state_status);// current status value is printed from the state table
printf("\n Light status of the current machine state is:%s\n",state_machine[current_state].light_status);// light status value is taken from state table current state
}
else
{
Gear_down(); //gear down function is called
}
}
//checking before takeoff//
void Checking_before_takeoff()
{
current_state= CHECK_BEFORE_TAKEOFF; //current state is check before takeoff
printf("\n Enter the pilot lever position, squat switch and hydraulic mechancism:\n");// getting pilot liver, squat switch and hydraulic mechanism as input
fflush(stdout);
scanf("%d %d %d",&pilot_lever, &squat_switch,&hydraulic_mechanism);
printf("\n just wait 2secs\n");
if (pilot_lever == up && squat_switch== close) //pilot lever is up and squat switch is closed it get into the if loop
{
Gear_down(); //gear down function is called
}
else if (pilot_lever== up && squat_switch == open && hydraulic_mechanism == working)//
{
current_state= RAISING_GEAR;
printf("\n Current state: %s\n",state_machine[current_state].current_state_status);
printf("light status: %s\n", state_machine[current_state].light_status);
printf("\n direction status:%s\n\n",state_machine[current_state].direction_value_status);
}
else if (pilot_lever== up && squat_switch == open && hydraulic_mechanism == malfunctioning)
{
current_state= RAISING_GEAR;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("\nlight status: %s\n", state_machine[current_state].light_status);
printf("\n direction status:%s\n\n",state_machine[current_state].direction_value_status);
printf("\n Gas pressurised spring status:%s\n",state_machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
}
}
//raising gear//
void Raising_gear()
{
current_state = RAISING_GEAR;
printf("\n Enter the switch status and pilot lever status:\n");
fflush(stdout);
scanf("%d %d",&limit_switch,&pilot_lever);
printf("\n wait for 1 sec\n");
if(pilot_lever == falling && limit_switch == open)
{
current_state = CHECK_BEFORE_LANDING;
printf("\n current state is:%s\n",state_machine[current_state].current_state_status);
printf("\n Light status:%s\n",state_machine[current_state].light_status);
printf("\nHydraulic condition for landing gear status is %s\n",state_machine[current_state].hydraulic_pump_ctrl_status);
}
else if(limit_switch == close && pilot_lever == up)
{
current_state= GEAR_UP;
printf("\n current state is:%s\n",state_machine[current_state].current_state_status);
printf("\n Light status:%s\n",state_machine[current_state].light_status);
printf("\nHydraulic condition for landing gear status is %s\n",state_machine[current_state].hydraulic_pump_ctrl_status);
}
else
{
Raising_gear();
}
}
//gear up//
void Gear_up()
{
current_state= GEAR_UP;
printf("\n Enter the pilot lever position :\n");
fflush(stdout);
scanf("%d",&pilot_lever);
if (pilot_lever == falling )
{
current_state= CHECK_BEFORE_LANDING;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("\nlight status: %s\n", state_machine[current_state].light_status);
printf("\nHydraulic condition for landing gear status is %s\n",state_machine[current_state].hydraulic_pump_ctrl_status);
}
else
{
Gear_up();
}
}
//checking before landing//
void Checking_before_landing()
{
current_state= CHECK_BEFORE_LANDING;
printf("\n Enter the pilot lever position, status of hydraulic mechanism :\n");
fflush(stdout);
scanf("%d %d",&pilot_lever, &hydraulic_mechanism);
if(pilot_lever == down && hydraulic_mechanism == working)
{
current_state= LOWERING_GEAR;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("\nlight status: %s\n", state_machine[current_state].light_status);
printf("\n direction status:%s\n\n",state_machine[current_state].direction_value_status);
}
else if (pilot_lever== down && hydraulic_mechanism == malfunctioning)
{
current_state= LOWERING_GEAR;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("light status: %s\n", state_machine[current_state].light_status);
printf("\n direction status:%s\n\n",state_machine[current_state].direction_value_status);
printf("\n Gas pressurised spring status:%s\n",state_machine[current_state].gas_pressurized_spring_status[hydraulic_mechanism]);
}
if(pilot_lever== (up || raising || falling))
{
Checking_before_landing();
}
}
//lowering gear//
void Lowering_gear()
{
current_state= LOWERING_GEAR;
printf("\n Enter the pilot lever position, limit switch :");
fflush(stdout);
scanf("%d %d",&pilot_lever, &limit_switch);
if (pilot_lever == raising && limit_switch==close)
{
current_state= CHECK_BEFORE_TAKEOFF;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("\nlight status: %s\n", state_machine[current_state].light_status);
}
if (pilot_lever== down && limit_switch == open)
{
current_state= GEAR_DOWN;
printf("\n Current state: %s\n", state_machine[current_state].current_state_status);
printf("\n light status: %s\n", state_machine[current_state].light_status);
printf("\n Hydraulic condition for landing gear status is %s\n",state_machine[current_state].hydraulic_pump_ctrl_status);
}
else
{
Lowering_gear();
}
}
int main()
{
Initial_state_machine();
while(1)
{
State_Table[current_state]();
}
}
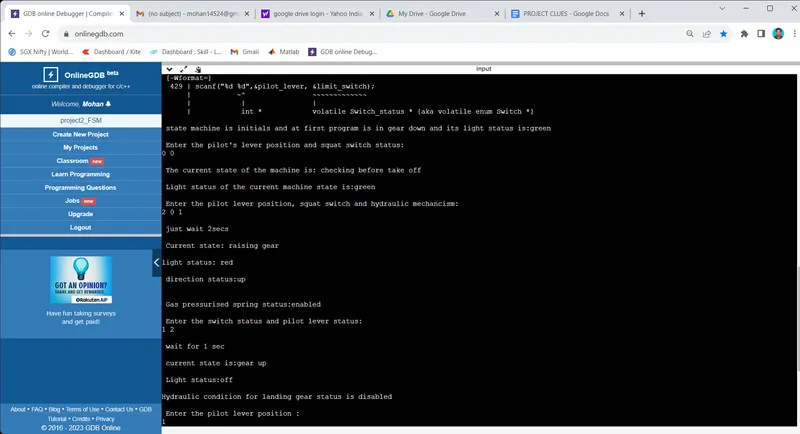
OUTPUT
state machine is initials and at first program is in gear down and its light status is:green
Enter the pilot's lever position and squat switch status:
0 0
The current state of the machine is: checking before take off
Light status of the current machine state is:green
Enter the pilot lever position, squat switch and hydraulic mechancism:
2 0 1
just wait 2secs
Current state: raising gear
light status: red
direction status:up
Gas pressurised spring status:enabled
Enter the switch status and pilot lever status:
1 2
wait for 1 sec
current state is:gear up
Light status:off
Hydraulic condition for landing gear status is disabled