printf("\nPIOLT'S LEVER FALLING::HYDRAULIC ENABLED::RED LIGHT");
}
else if(lwg_gr1==lwg_gr){
printf("\nPIOLT'S LEVER DOWN::DIRECTION VALVE DOWN");
}
}
OUTPUT:-
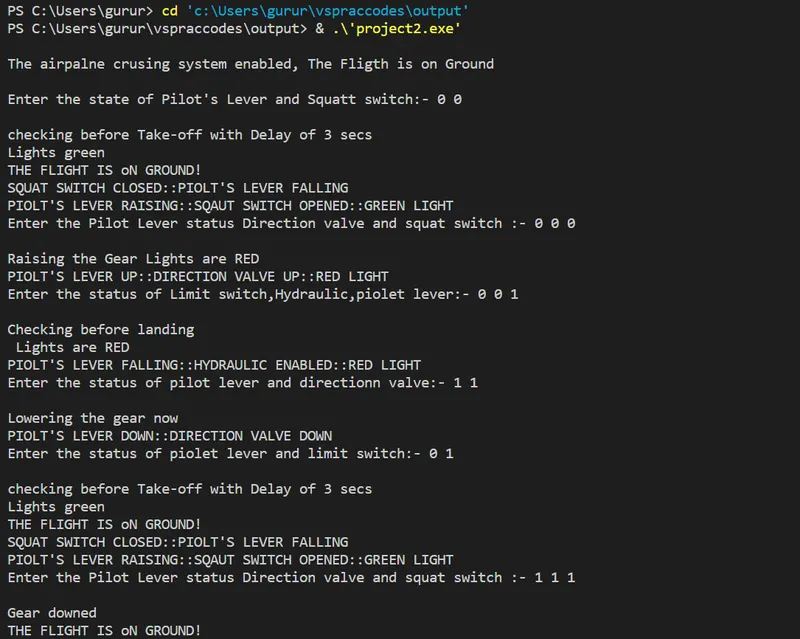
PS C:\Users\gurur> cd 'c:\Users\gurur\vspraccodes\output' PS C:\Users\gurur\vspraccodes\output> & .\'project2.exe'
The airpalne crusing system enabled, The Fligth is on Ground
Enter the state of Pilot's Lever and Squatt switch:- 0 0
checking before Take-off with Delay of 3 secs Lights green THE FLIGHT IS oN GROUND! SQUAT SWITCH CLOSED::PIOLT'S LEVER FALLING PIOLT'S LEVER RAISING::SQAUT SWITCH OPENED::GREEN LIGHT Enter the Pilot Lever status Direction valve and squat switch :- 0 0 0
Raising the Gear Lights are RED PIOLT'S LEVER UP::DIRECTION VALVE UP::RED LIGHT Enter the status of Limit switch,Hydraulic,piolet lever:- 0 0 1
Checking before landing Lights are RED PIOLT'S LEVER FALLING::HYDRAULIC ENABLED::RED LIGHT Enter the status of pilot lever and directionn valve:- 1 1
Lowering the gear now PIOLT'S LEVER DOWN::DIRECTION VALVE DOWN Enter the status of piolet lever and limit switch:- 0 1
checking before Take-off with Delay of 3 secs Lights green THE FLIGHT IS oN GROUND! SQUAT SWITCH CLOSED::PIOLT'S LEVER FALLING PIOLT'S LEVER RAISING::SQAUT SWITCH OPENED::GREEN LIGHT Enter the Pilot Lever status Direction valve and squat switch :- 1 1 1
Gear downed THE FLIGHT IS oN GROUND! SQUAT SWITCH CLOSED::PIOLT'S LEVER FALLING Enter the state of Pilot's Lever and Squatt switch:- 0 0
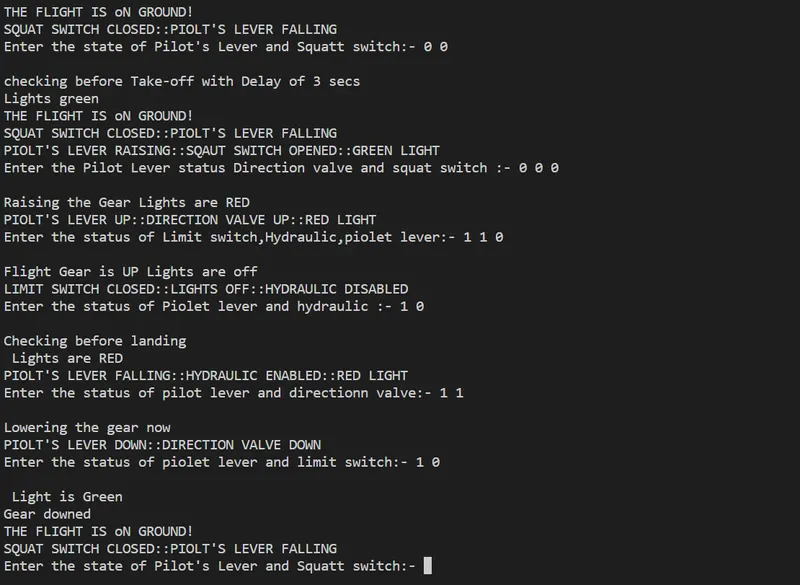
checking before Take-off with Delay of 3 secs Lights green THE FLIGHT IS oN GROUND! SQUAT SWITCH CLOSED::PIOLT'S LEVER FALLING PIOLT'S LEVER RAISING::SQAUT SWITCH OPENED::GREEN LIGHT Enter the Pilot Lever status Direction valve and squat switch :- 0 0 0
Raising the Gear Lights are RED PIOLT'S LEVER UP::DIRECTION VALVE UP::RED LIGHT Enter the status of Limit switch,Hydraulic,piolet lever:- 1 1 0
Flight Gear is UP Lights are off LIMIT SWITCH CLOSED::LIGHTS OFF::HYDRAULIC DISABLED Enter the status of Piolet lever and hydraulic :- 1 0
Checking before landing Lights are RED PIOLT'S LEVER FALLING::HYDRAULIC ENABLED::RED LIGHT Enter the status of pilot lever and directionn valve:- 1 1
Lowering the gear now PIOLT'S LEVER DOWN::DIRECTION VALVE DOWN Enter the status of piolet lever and limit switch:- 1 0
Light is Green Gear downed THE FLIGHT IS oN GROUND! SQUAT SWITCH CLOSED::PIOLT'S LEVER FALLING
Enter the state of Pilot's Lever and Squatt switch:-
*SCREENSHOTS*
*NOTE* I done this project with an idea of making the Finite automation in an easy way, that anyone can easily understand the code, And I used the nested functioning that will easily go up with self-calling or assigning the system state inputs one to one each. other.