Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
/*
Project 2 - Implement the Code for controlling the retraction and extension of the Airplane’s landing gear
*/
/*
To implement the Code for controlling the retraction and extension of an Airplane’s landing gear we will be using the Finite State Machine concept to make State Diagram and then State Table to make our algorithm and then implement that using c code.
Actually, an airplane has 3 gears for landing :
• Nose Gear
• Left Gear
• Right Gear
There is a hydraulic pump which is exerting pressure on the gears to bring them down or pull them up and that pump is electrically driven.
Here I am considering the following scenario:
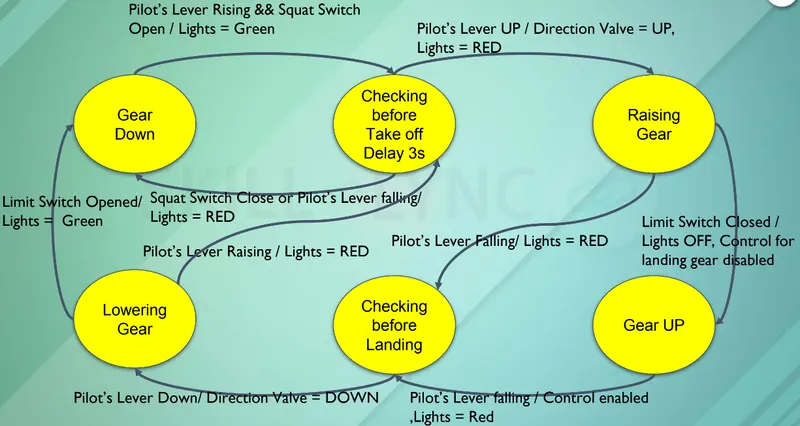
6 Output States of the Machine( GearDown, DelayBeforeTakeOff, RaisingGear, GearUp, CheckBeforeLanding, LoweringGear).
3 status of indicator Light (Red, Green, OFF)
4 states of control input lever (Raising, Up, Falling, Down)
2 states of the limit switch (On, Off):- Every leg of the gear has one limit switch.
2 states of the squat switch (On, Off):- Nose gear has one Squat Switch to determine whether the airplane
is in the ground or not.
4 states of direction valve (Up, Down, Enable, Disable):- A direction valve is controlled by the software to allow the hydraulic pressure to either raise or lower the landing gear
*/
State Diagram
State Table
|
Current State |
Lever Control Input |
Next State |
Light |
Limit Switch |
Squat Switch |
Direction Valve |
|
Gear Down |
Raising |
Delay 4 sec before Take Off |
Green |
Open |
Open |
Down |
|
Delay 4 sec before Take Off |
Up |
Raising Gear |
Red |
Open |
Open |
Up |
|
Delay 4 sec before Take Off |
Falling |
Gear Down |
Red |
Open |
Close |
Down |
|
Raising Gear |
Up |
Gear Up (Airborne) |
Off |
Closed |
Open |
disable |
|
Raising Gear |
Falling |
Check before Landing |
Red |
Open |
Open |
Down |
|
Gear Up (Airborne |
Falling |
Check before Landing |
Red |
closed |
Open |
enable |
|
Check before Landing |
Down |
Lowering Gear |
Red |
open |
open |
Down |
|
Lowering Gear |
Down |
Gear Down |
Green |
open |
close |
Down |
|
Lowering Gear |
Raising |
Delay 4 sec before Take Off |
Red |
open |
open |
down |
CODE:
#include<stdio.h>
typedef enum
{
Raising, Up, Falling, Down
}Lever;
typedef enum
{
GearDown, DelayBeforeTakeOff, RaisingGear,
GearUp, CheckBeforeLanding, LoweringGear
}State;
int main()
{
int input;
State Current_state = GearDown; // by default
printf("\n Different Lever control inputs for landing gear are as follows:");
printf("\n Enter '0' for Raising");
printf("\n Enter '1' for Up");
printf("\n Enter '2' for Falling");
printf("\n Enter '3' for Down");
while(1)
{
//for taking lever input
printf("\n Enter Lever Control Input: ");
fflush(stdout);
scanf("%d",&input);
fflush(stdin);
if((Current_state == GearDown)&&(input==Raising))
{
printf("\n Current State = waiting for 4 second before Take Off");
printf("\n Light = Green");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Down");
Current_state = DelayBeforeTakeOff;
printf("\n \n \n");
}
else if((Current_state == DelayBeforeTakeOff)&&(input==Up))
{
printf("\n Current State = Raising Landing Gear");
printf("\n Light = Red");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Up");
Current_state = RaisingGear;
printf("\n \n \n");
}
else if((Current_state == DelayBeforeTakeOff)&&(input==Falling))
{
printf("\n Current State = Gear Down");
printf("\n Light = Red");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Close");
printf("\n Valve Direction => Down");
Current_state = GearDown;
printf("\n \n \n");
}
else if((Current_state == RaisingGear)&&(input==Up))
{
printf("\n Current State = Gear Up (Airborne)");
printf("\n Light = OFF");
printf("\n Limit Switch => Closed");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Disabled");
Current_state = GearUp;
printf("\n \n \n");
}
else if((Current_state == RaisingGear)&&(input==Falling))
{
printf("\n Current State = Checking Before Landing");
printf("\n Light = Red");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Down");
Current_state = CheckBeforeLanding;
printf("\n \n \n");
}
else if((Current_state == GearUp)&&(input==Falling))
{
printf("\n Current State = Checking Before Landing");
printf("\n Light = Red");
printf("\n Limit Switch => Closed");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Enabled");
Current_state = CheckBeforeLanding;
printf("\n \n \n");
}
else if((Current_state == CheckBeforeLanding)&&(input==Down))
{
printf("\n Current State = Lowering Landing Gear");
printf("\n Light = Red");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Down");
Current_state = LoweringGear;
printf("\n \n \n");
}
else if((Current_state == LoweringGear)&&(input==Down))
{
printf("\n Current State = Landing Gear Down");
printf("\n Light = Green");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Close");
printf("\n Valve Direction => Down");
Current_state = GearDown;
printf("\n \n \n");
}
else if((Current_state == LoweringGear)&&(input==Raising))
{
printf("\n Current State = Waiting for 4 seconds before Take Off");
printf("\n Light = Red");
printf("\n Limit Switch => Open");
printf("\n Squat Switch => Open");
printf("\n Valve Direction => Down");
Current_state = DelayBeforeTakeOff;
printf("\n \n \n");
}
else
{
printf("\n Wrong input Command Retry \n \n \n ");
}
}
return (0);
}
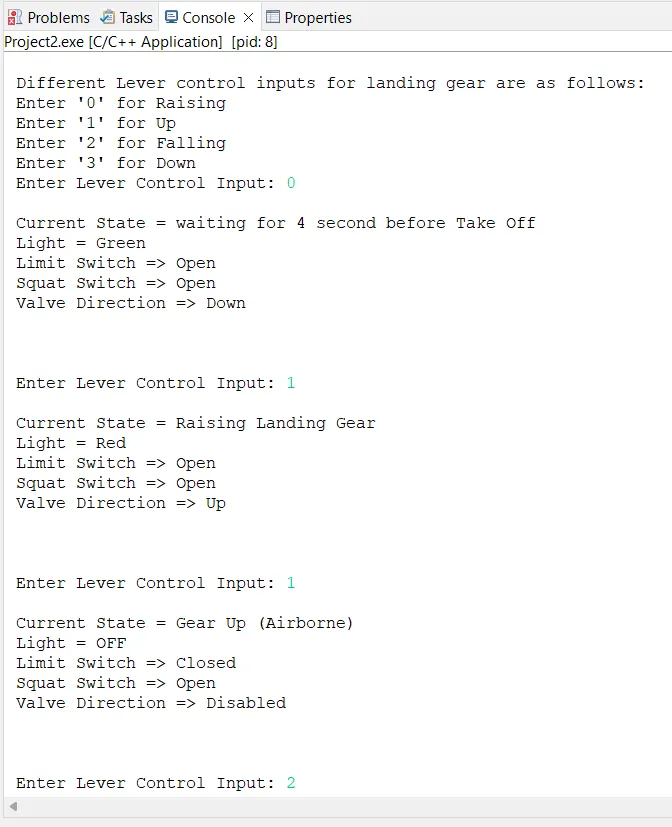
OUTPUT: