Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
main.c
#include<stdio.h>
#include<states.h>
static void(*stateTable[])(void)={GearDown, CheckingBeforeTakeOFF, RaisingGear, GearUp,
CheckBeforeLanding, LoweringGear};
int main()
{Initiate_State_Machine();
while(1)
{
stateTable[current_state]();
}
}
//GearDown
void GearDown(void)
{
current_state=GEAR_DOWN;
printf("Enter the status of pilot's lever and squat switch:");
fflush(stdout);
scanf("%d %d", &pilot_lever, &squat_switch);
if(pilot_lever==raising && squat_switch==on)
{
current_state=CHECK_BEFORE_TAKEOFF;
printf("Current state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
}
else
{
GearDown();
}
}
//CheckingBeforeTakeOFF
void ChekingBeforeTakeOFF(void)
{
current_state=CHECKING_BEFORE_TAKEOFF;
printf("Enter the status of pilot's lever and squat switch and hydraulic mechanism:");
fflush(stdout);
scanf("%d %d", &pilot_lever, &squat_switch, &hydraulic_mechanism);
if(pilot_lever==falling && squat_switch==off)
{
GearDown();
}
else if(pilot_lever==raising && squat_switch==On && hydraulic_mechanism== working)
{
current_state==RAISING_GEAR;
printf("Current state:%s\n", State_Merchanism[current_state].current_state_indication);
printf("Light is :%s\n", State_Mechanism[current_state].light);
printf("Status of Direction valve :%s\n", State_Mechanism[current_state].direction_vale_status);
}
else if(pilot_lever == raising && squat_switch == On && hydraulic_mechanism == not working)
{
current_state=RAISING_GEAR;
printf("Current state:%s\n", State_Mechanism[current_state].current_state_indication);
pintf("Light is :%s\n", State_Mechine[current_state].ligjht);
printf("Status of Direction valve :%s\n", State_Mechanism[current_state].direction_valve_status);
printf("Status of Gas Pressurized Spring System:%s\n",
State_Mechine[current_state].Gas_Pressurised_Spring_system_status);
}
}
//RaisingGear
void RaisingGear(void)
{
current_state=RAISING_GEAR;
printf("Enter the status of pilot's lever and limit switch:");
fflush(stdout);
scanf("%d %d", &pilot_lever, &limit_switch);
if(pilot_lever==falling && limit_switch==On);
{
currrent_state=CHECK_BEFORE_LANDING;
printf("Current state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is %S\n", State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",
State_Machine[current_state].landing_gear_hydraulic_contol);
}
else if(pilot_lever==raisinggear && limit_switch==OFF)
{
current_state=GEAR_UP;
printf("Current state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",
State_Machine[current_state].landing_gear__hydraulic_control);
}
else
{
RaisingGear();
}
}
//GearUP
void GearUP(void)
{
current_state=GEAR_UP;
printf("Enter the status of pilot's lever:");
fflush(stdout);
scanf("%d", &pilot_lever);
if(pilot_lever==falling)
{
current_state=CHECK_BEFORE_LANDING;
printf("Current state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",
State_Machine[current_state].landing_gear_hydraulic_control);
}
else
{
GearUP();
}
}
//CheckBeforeLanding
void CheckBeforeLanding(void)
{
current_state=CHECK_BEFORE_LANDING;
printf("Enter the status of pilot's lever and hydraulic mechanism status:");
fflush(stdout);
scanf("%d %d", &pilot_lever, &hydraulic_mechanism);
if(pilot_lever==falling && hydraulic_mechanism==working)
{
current_state=LOWERING_GEAR;
printf("Current state:%s\n", State_Mechanism[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
printf("Status of Direction valve :%s\n",
State_Machine[current_state].direction_valve_status);
}
else if(pilot_lever==falling && squat_switch==On && hydraulic_mechanism== not working)
{
current_state=LOWERING_GEAR;
printf("Current state:%s\n", State_Machine[current_state].current_state_indicator);
printf("Light is :%s\n", State_Machine[current_state].light);
printf("Status of Direction valve :%s\n",
State_Machine[current_state].direction_valve_status);
printf("Status of Gas Pressurized Spring System:%s\n",
State_Machine[current_state].Gas_Pressurised_Spring_System_Status);
}
if(pilot_lever== (raising || falling))
{
CheckBeforeLanding();
}
}
//LoweringGear
void LoweringGear(void)
{
current_state=LOWERING_GEAR;
printf("Enter the status of pilot's lever and limit switch:");
fflush(stdout);
scanf("%d %d", &pilot_lever, &limit_switch);
if(pilot_lever==raising && limit_switch==On)
{
current_state=CHECK_BEFORE_TAKEOFF;
printf("Current_state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is :%s\n",
State_Machine[current_state].light);
}
if(pilot_lever==raising && limit_switch==off)
{
current_state=GEAR_DOWN;
printf("Current state:%s\n", State_Machine[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",
State_Machine[current_state].landing_gear_hydraulic_control);
}
if(limit_switch==Off)
{
LoweringGear();
}
}
void Initiate_State_Machine()
{
current_state=GEAR_DOWN;
printf("The Finite State Machine is Initialized and current the program is in"
"GearDown State & Light is: %s\n", State_Machine[current_state].light);
}
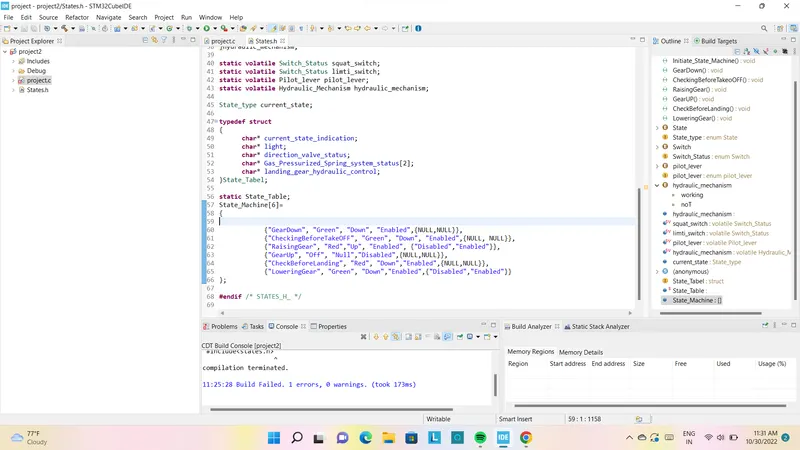
header file.h
#ifndef STATES_H_
#define STATES_H_
#include<stdio.h>
void Initiate_State_Machine();
void GearDown();
void CheckingBeforeTakeoOFF();
void RaisingGear();
void GearUP();
void CheckBeforeLanding();
void LoweringGear();
typedef enum State
{
GEAR_DOWN,
CHECKING_BEFORE_TAKEOFF,
RAISING_GEAR,
GEAR_UP,
CHECK_BEFORE_LANDING,
LOWERING_GEAR,
}State_type;
typedef enum Switch
{
On,
off//Plane is on Grnd
}Switch_Status;
typedef enum pilot_lever
{
Raising,
falling,
}pilot_lever;
typedef enum hydraulic_mechanism
{
working,
noT WORKING
}hydraulic_mechanism;
static volatile Switch_Status squat_switch;
static volatile Switch_Status limti_switch;
static volatile Pilot_lever pilot_lever;
static volatile Hydraulic_Mechanism hydraulic_mechanism;
State_type current_state;
typedef struct
{
char* current_state_indication;
char* light;
char* direction_valve_status;
char* Gas_Pressurized_Spring_system_status[2];
char* landing_gear_hydraulic_control;
}State_Tabel;
static State_Table;
State_Machine[6]=
{
{"GearDown", "Green", "Down", "Enabled",{NULL,NULL}},
{"CheckingBeforeTakeOFF", "Green", "Down", "Enabled",{NULL, NULL}},
{"RaisingGear", "Red","Up", "Enabled", {"Disabled","Enabled"}},
{"GearUp", "Off", "Null","Disabled",{NULL,NULL}},
{"CheckBeforeLanding", "Red", "Down","Enabled",{NULL,NULL}},
{"LoweringGear", "Green", "Down","Enabled",{"Disabled","Enabled"}}
};
#endif /* STATES_H_ */
output;
- Nanga Sarath Chandrahello u did project also but why requested for challenge 10