IMPLEMENT THE CODE FOR CONTROLLING THE RETRACTION AND EXTENSION OF
AIRPLANE'S LANDING GEAR
OVERVIEW OF THE PROJECT:
In this project we are going to find an retraction and extension of aeroplane,controlling the retraction and extension of Airplane’s landing gear can be implemented using Finite
State Machine (FSM).The program to find the retraction and extension of Airplane’s landing gear for an different states are doing in an source file inside an main file.
The following are the different states of an airplan gear extension.
- Initializing state machine of all condition
- Gear down
- checking before take off
- raising gear
- gear up condition
- Check before landing
- Lowering gear.
GOALS:
* The main goal is to write an code using the concept of finite state machine.
* Controlling the retraction and extension of Airplane’s landing gear and seeing in an different modes of an operation
* Controlling the direction of Valve of Airplane’s landing gear.
KEY HIGHLIGHTS OF THE PROJECT:
-
A direction valve is controlled by the software to allow the hydraulic pressure to either raise or lower the landing gear.
-
Implementing the control for the retraction and extension of Airplane’s landing gear using the Finite state machine with the knowledge of various states of switch and gear.
-
The retraction and also an extension of an aireplane landing gear is illustrated from this project.
CODE:
#include<stdio.h>
void Initiate_State_Machine();
void GearDown();
void CheckingBeforeTakeOFF();
void RaisingGear();
void GearUp();
void CheckBeforeLanding();
void LoweringGear();
static void(*statetable[])(void)={GearDown, CheckingBeforeTakeOFF, RaisingGear, GearUp, CheckBeforeLanding, LoweringGear};
typedef enum State
{
GEAR_DOWN,
CHECKING_BEFORE_TAKEOFF,
RAISING_GEAR,
GEAR_UP,
CHECK_BEFORE_LANDING,
LOWERING_GEAR,
}State_Type;
typedef enum Switch
{
on,
off//plane is on groung
}Switch_status;
typedef enum pilot_lever
{
Raising,
falling
}pilot_lever;
typedef enum hydraulic_mechanism
{
working,
not_working
}hydraulic_mechanism;
static volatile Switch_status squat_switch;
static volatile Switch_status limit_switch;
static volatile pilot_lever pl;
static volatile hydraulic_mechanism hm;
State_Type current_state;
typedef struct
{
char* current_state_indication;
char* light;
char* direction_valve_status;
char* landing_gear_hydraulic_control;
char* Gas_Pressurized_Spring_system_status[2];
}State_Table;
static State_Table State_Machine[6]={{"GearDown","Green","Down","Enabled",{NULL,NULL}},
{"CheckingBeforeTakeOFF","Green","Down","Enabled",{NULL,NULL}},
{"RaisingGear","Red","Up","Enabled",{NULL,NULL}},
{"GearUp","Off","NULL","Disbled",{NULL,NULL}},
{"CheckBeforeLanding","Red","Down","Enabled",{NULL,NULL}},
{"LoweringGear","Green","Down","Enabled",{"Disabled","Enabled"}}
};
int main()
{
Initiate_State_Machine();
while(1)
{
statetable[current_state]();
}
}
void GearDown(void)
{
current_state=GEAR_DOWN;
printf("Enter the status of pilot's lever and squat switch");
fflush(stdout);
scanf("%d %d",&pl,&squat_switch);
if(pl==Raising && squat_switch==on)
{
current_state=CHECKING_BEFORE_TAKEOFF;
printf("current state:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is :%s\n", State_Machine[current_state].light);
}
else
{
GearDown();
}
}
//CheckingBeforeTakeOFF
void CheckingBeforeTakeOFF(void)
{
current_state=CHECKING_BEFORE_TAKEOFF;
printf("Enter the status of pilot's lever and squat switch and hydraulic mechanism:");
fflush(stdout);
scanf("%d %d",&pl,&squat_switch,&hm);
if(pl==falling&&squat_switch==off)
{
GearDown();
}
else if(pl==Raising && squat_switch==on && hm==working)
{
current_state=RAISING_GEAR;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Status of Direction valve:%s\n",State_Machine[current_state].direction_valve_status);
}
else if(pl==Raising && squat_switch==on && hm==not_working)
{
current_state=RAISING_GEAR;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Status of Direction valve:%s\n",State_Machine[current_state].direction_valve_status);
printf("Status of gas pressurised Spring System:%s\n",State_Machine[current_state].Gas_Pressurized_Spring_system_status);
}
}
//RaisingGear
void RaisingGear(void)
{
current_state=RAISING_GEAR;
printf("Enter the status of pilot's lever and limit switch:");
fflush(stdout);
scanf("%d %d",&pl,&limit_switch);
if(pl==falling && limit_switch==on)
{
current_state=CHECK_BEFORE_LANDING;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",State_Machine[current_state].landing_gear_hydraulic_control);
}
else if(pl==Raising && limit_switch==off)
{
current_state=GEAR_UP;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",State_Machine[current_state].landing_gear_hydraulic_control);
}
else
{
RaisingGear();
}
}
//GearUp
void GearUp(void)
{
current_state=GEAR_UP;
printf("Enter the status of pilot's lever:");
fflush(stdout);
scanf("%d",&pl);
if(pl==falling)
{
current_state=CHECK_BEFORE_LANDING;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",State_Machine[current_state].landing_gear_hydraulic_control);
}
else
{
GearUp();
}
}
//CheckBeforeLanding
void CheckBeforeLanding(void)
{
current_state=CHECK_BEFORE_LANDING;
printf("Enter the status of pilot's lever and hydraulic mechanism status:");
fflush(stdout);
scanf("%d %d",&pl,&hm);
if(pl==falling && hm==working)
{
current_state=LOWERING_GEAR;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Status of Direction valve:%s\n",State_Machine[current_state].direction_valve_status);
}
else if(pl==falling && hm==not_working)
{
current_state=LOWERING_GEAR;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Status of Direction valve:%s\n",State_Machine[current_state].direction_valve_status);
printf("Status of gas pressurised Spring System:%s\n",State_Machine[current_state].Gas_Pressurized_Spring_system_status);
}
else if(pl==(Raising))
{
CheckBeforeLanding();
}
}
//LoweringGear.
void LoweringGear(void)
{
current_state=LOWERING_GEAR;
printf("Enter the status of pilot's lever and limit switch:");
fflush(stdout);
scanf("%d %d",&pl,&limit_switch);
if(pl==falling && limit_switch==on)
{
current_state=CHECKING_BEFORE_TAKEOFF;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
}
else if(pl==Raising && limit_switch==off)
{
current_state=GEAR_DOWN;
printf("Current State:%s\n",State_Machine[current_state].current_state_indication);
printf("Light is:%s\n",State_Machine[current_state].light);
printf("Landing Gear Hydraulic Control:%s\n",State_Machine[current_state].landing_gear_hydraulic_control);
}
if(limit_switch==off)
{
LoweringGear();
}
}
//Initiate_State_Machine
void Initiate_State_Machine()
{
current_state==GEAR_DOWN;
printf("The Finite State Machine is Intialized and current the program is in""GearDown State & Light is:%s\n",State_Machine[current_state].light);
}
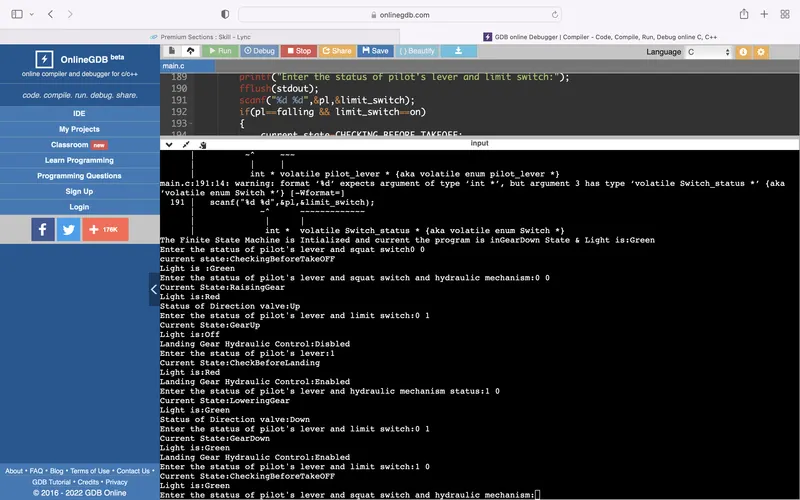
EXPECTED OUTCOMES:
* First we have to enter the pilot lever position and also an squat position of an machine.
* we have to enter the limit of an swith status and an pilot lever status as 0 and 1,after an sec we are able to see the status is in an null state.
* Similarly we have to check the conditions for an different modes or an stste of the machine.
* In the below output attached image we can seee clearly about controlling the retraction and extension of Airplane’s landing gear.