Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Project 2
Embedded system
- No. 1 Implement the Code for controlling the retraction and extension of Airplane’s landing gear.
ANS:
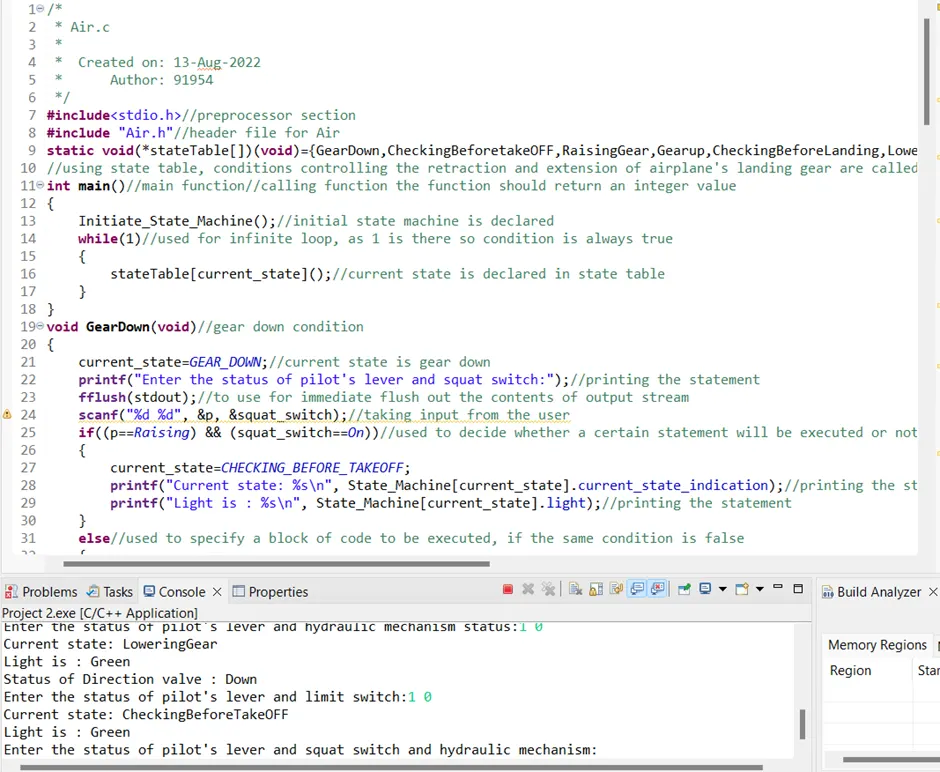
Main C program for airplane
#include<stdio.h>//preprocessor section
#include "Air.h"//header file for Air
static void(*stateTable[])(void)={GearDown,CheckingBeforetakeOFF,RaisingGear,Gearup,CheckingBeforeLanding,LoweringGear};
//using state table, conditions controlling the retraction and extension of airplane's landing gear are called
int main()//main function//calling function the function should return an integer value
{
Initiate_State_Machine();//initial state machine is declared
while(1)//used for infinite loop, as 1 is there so condition is always true
{
stateTable[current_state]();//current state is declared in state table
}
}
void GearDown(void)//gear down condition
{
current_state=GEAR_DOWN;//current state is gear down
printf("Enter the status of pilot's lever and squat switch:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d %d", &p, &squat_switch);//taking input from the user
if((p==Raising) && (squat_switch==On))//used to decide whether a certain statement will be executed or not
{
current_state=CHECKING_BEFORE_TAKEOFF;
printf("Current state: %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
}
else//used to specify a block of code to be executed, if the same condition is false
{
GearDown();//gear down statement
}
}
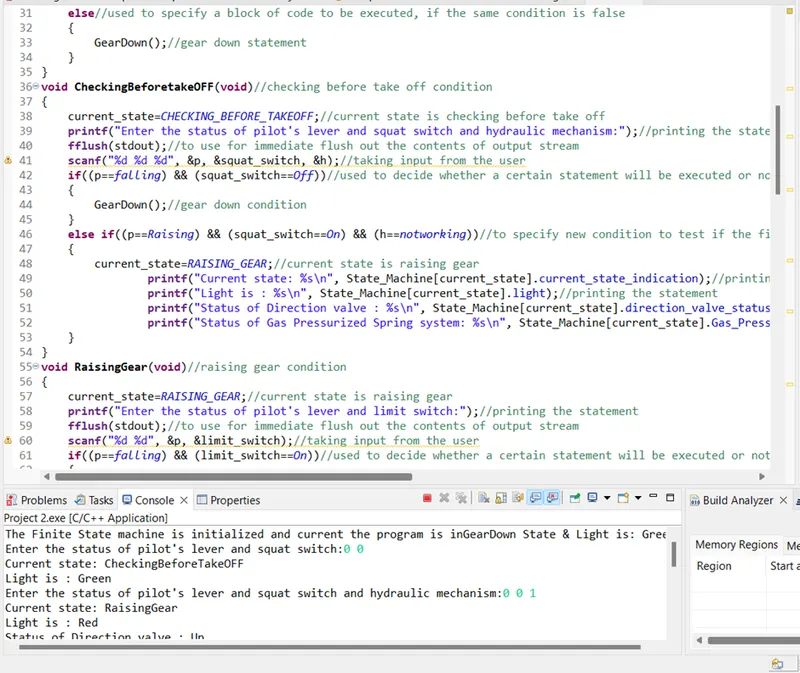
void CheckingBeforetakeOFF(void)//checking before take off condition
{
current_state=CHECKING_BEFORE_TAKEOFF;//current state is checking before take off
printf("Enter the status of pilot's lever and squat switch and hydraulic mechanism:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d %d %d", &p, &squat_switch, &h);//taking input from the user
if((p==falling) && (squat_switch==Off))//used to decide whether a certain statement will be executed or not
{
GearDown();//gear down condition
}
else if((p==Raising) && (squat_switch==On) && (h==notworking))//to specify new condition to test if the first condition false
{
current_state=RAISING_GEAR;//current state is raising gear
printf("Current state: %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Status of Direction valve : %s\n", State_Machine[current_state].direction_valve_status);//printing the statement
printf("Status of Gas Pressurized Spring system: %s\n", State_Machine[current_state].Gas_Pressurized_Spring_system_status[0]);//printing the statement
}
}
void RaisingGear(void)//raising gear condition
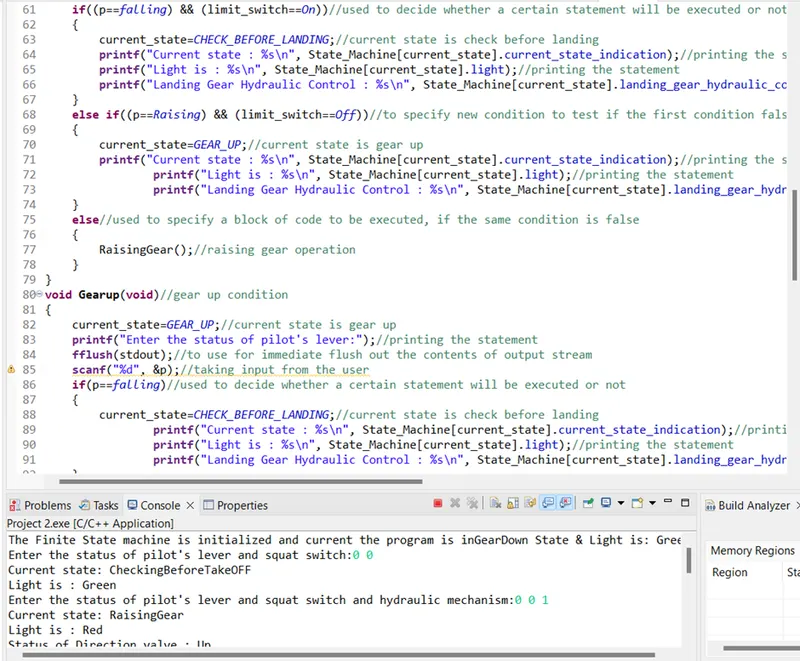
{
current_state=RAISING_GEAR;//current state is raising gear
printf("Enter the status of pilot's lever and limit switch:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d %d", &p, &limit_switch);//taking input from the user
if((p==falling) && (limit_switch==On))//used to decide whether a certain statement will be executed or not
{
current_state=CHECK_BEFORE_LANDING;//current state is check before landing
printf("Current state : %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Landing Gear Hydraulic Control : %s\n", State_Machine[current_state].landing_gear_hydraulic_control);//printing the statement
}
else if((p==Raising) && (limit_switch==Off))//to specify new condition to test if the first condition false
{
current_state=GEAR_UP;//current state is gear up
printf("Current state : %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Landing Gear Hydraulic Control : %s\n", State_Machine[current_state].landing_gear_hydraulic_control);//printing the statement
}
else//used to specify a block of code to be executed, if the same condition is false
{
RaisingGear();//raising gear operation
}
}
void Gearup(void)//gear up condition
{
current_state=GEAR_UP;//current state is gear up
printf("Enter the status of pilot's lever:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d", &p);//taking input from the user
if(p==falling)//used to decide whether a certain statement will be executed or not
{
current_state=CHECK_BEFORE_LANDING;//current state is check before landing
printf("Current state : %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Landing Gear Hydraulic Control : %s\n", State_Machine[current_state].landing_gear_hydraulic_control);//printing the statement
}
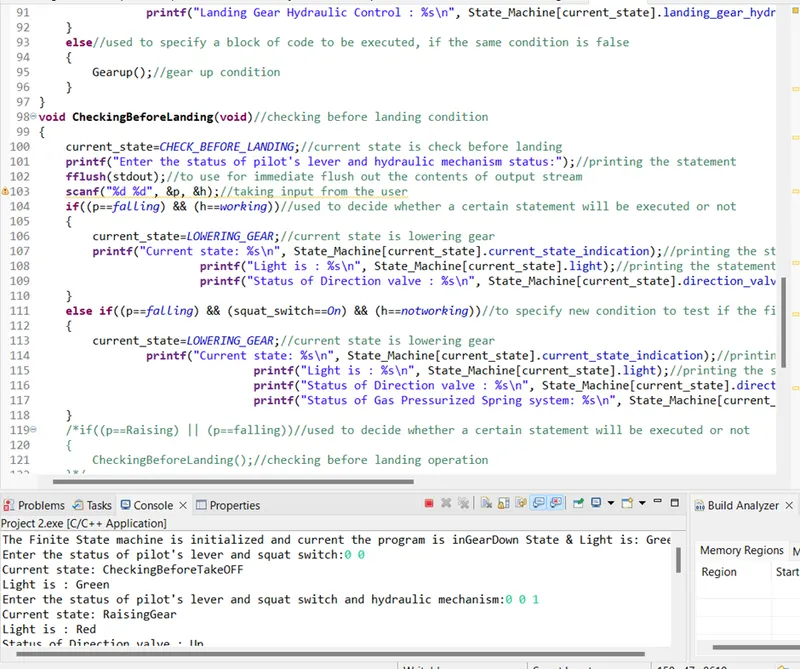
else//used to specify a block of code to be executed, if the same condition is false
{
Gearup();//gear up condition
}
}
void CheckingBeforeLanding(void)//checking before landing condition
{
current_state=CHECK_BEFORE_LANDING;//current state is check before landing
printf("Enter the status of pilot's lever and hydraulic mechanism status:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d %d", &p, &h);//taking input from the user
if((p==falling) && (h==working))//used to decide whether a certain statement will be executed or not
{
current_state=LOWERING_GEAR;//current state is lowering gear
printf("Current state: %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Status of Direction valve : %s\n", State_Machine[current_state].direction_valve_status);//printing the statement
}
else if((p==falling) && (squat_switch==On) && (h==notworking))//to specify new condition to test if the first condition false
{
current_state=LOWERING_GEAR;//current state is lowering gear
printf("Current state: %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Status of Direction valve : %s\n", State_Machine[current_state].direction_valve_status);//printing the statement
printf("Status of Gas Pressurized Spring system: %s\n", State_Machine[current_state].Gas_Pressurized_Spring_system_status[0]);//printing the statement
}
/*if((p==Raising) || (p==falling))//used to decide whether a certain statement will be executed or not
{
CheckingBeforeLanding();//checking before landing operation
}*/
}
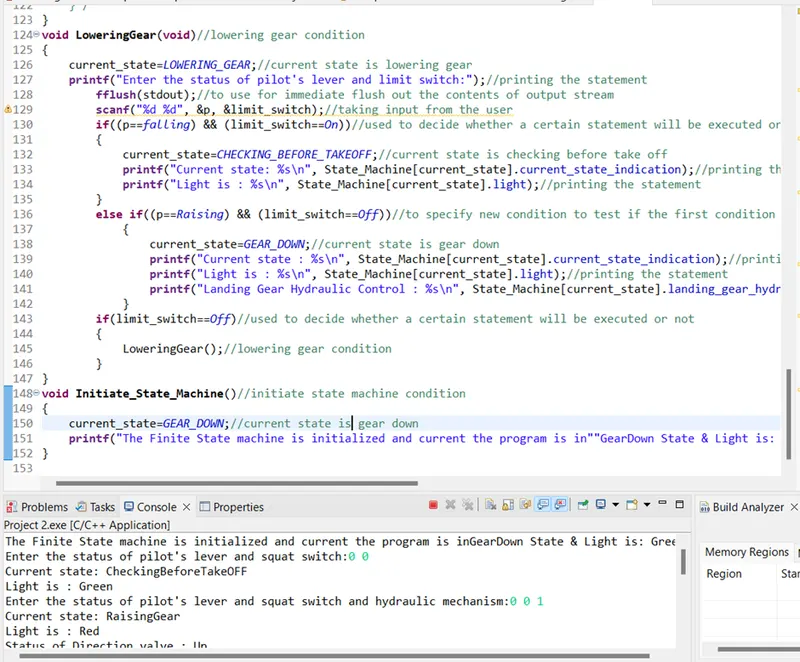
void LoweringGear(void)//lowering gear condition
{
current_state=LOWERING_GEAR;//current state is lowering gear
printf("Enter the status of pilot's lever and limit switch:");//printing the statement
fflush(stdout);//to use for immediate flush out the contents of output stream
scanf("%d %d", &p, &limit_switch);//taking input from the user
if((p==falling) && (limit_switch==On))//used to decide whether a certain statement will be executed or not
{
current_state=CHECKING_BEFORE_TAKEOFF;//current state is checking before take off
printf("Current state: %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
}
else if((p==Raising) && (limit_switch==Off))//to specify new condition to test if the first condition false
{
current_state=GEAR_DOWN;//current state is gear down
printf("Current state : %s\n", State_Machine[current_state].current_state_indication);//printing the statement
printf("Light is : %s\n", State_Machine[current_state].light);//printing the statement
printf("Landing Gear Hydraulic Control : %s\n", State_Machine[current_state].landing_gear_hydraulic_control);//printing the statement
}
if(limit_switch==Off)//used to decide whether a certain statement will be executed or not
{
LoweringGear();//lowering gear condition
}
}
void Initiate_State_Machine()//initiate state machine condition
{
current_state=GEAR_DOWN;//current state is gear down
printf("The Finite State machine is initialized and current the program is in""GearDown State & Light is: %s\n", State_Machine[current_state].light);//printing the statement of State_Machine[current_state].light
}
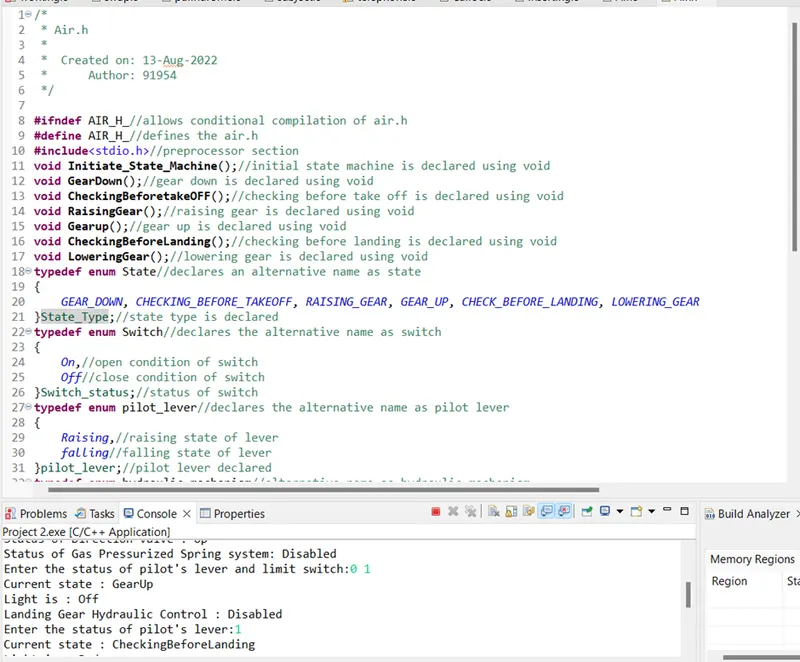
Header file
#ifndef AIR_H_//allows conditional compilation of air.h
#define AIR_H_//defines the air.h
#include<stdio.h>//preprocessor section
void Initiate_State_Machine();//initial state machine is declared using void
void GearDown();//gear down is declared using void
void CheckingBeforetakeOFF();//checking before take off is declared using void
void RaisingGear();//raising gear is declared using void
void Gearup();//gear up is declared using void
void CheckingBeforeLanding();//checking before landing is declared using void
void LoweringGear();//lowering gear is declared using void
typedef enum State//declares an alternative name as state
{
GEAR_DOWN, CHECKING_BEFORE_TAKEOFF, RAISING_GEAR, GEAR_UP, CHECK_BEFORE_LANDING, LOWERING_GEAR
}State_Type;//state type is declared
typedef enum Switch//declares the alternative name as switch
{
On,//open condition of switch
Off//close condition of switch
}Switch_status;//status of switch
typedef enum pilot_lever//declares the alternative name as pilot lever
{
Raising,//raising state of lever
falling//falling state of lever
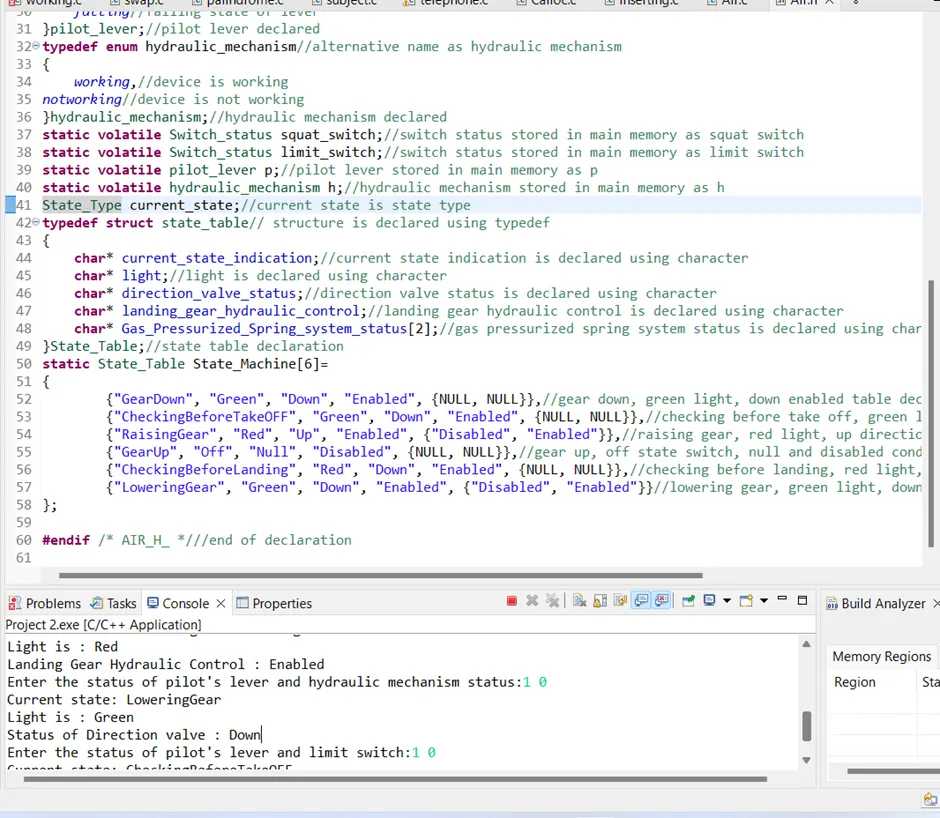
}pilot_lever;//pilot lever declared
typedef enum hydraulic_mechanism//alternative name as hydraulic mechanism
{
working,//device is working
notworking//device is not working
}hydraulic_mechanism;//hydraulic mechanism declared
static volatile Switch_status squat_switch;//switch status stored in main memory as squat switch
static volatile Switch_status limit_switch;//switch status stored in main memory as limit switch
static volatile pilot_lever p;//pilot lever stored in main memory as p
static volatile hydraulic_mechanism h;//hydraulic mechanism stored in main memory as h
State_Type current_state;//current state is state type
typedef struct state_table// structure is declared using typedef
{
char* current_state_indication;//current state indication is declared using character
char* light;//light is declared using character
char* direction_valve_status;//direction valve status is declared using character
char* landing_gear_hydraulic_control;//landing gear hydraulic control is declared using character
char* Gas_Pressurized_Spring_system_status[2];//gas pressurized spring system status is declared using character
}State_Table;//state table declaration
static State_Table State_Machine[6]=
{
{"GearDown", "Green", "Down", "Enabled", {NULL, NULL}},//gear down, green light, down enabled table declared
{"CheckingBeforeTakeOFF", "Green", "Down", "Enabled", {NULL, NULL}},//checking before take off, green light, down, enabled table declared
{"RaisingGear", "Red", "Up", "Enabled", {"Disabled", "Enabled"}},//raising gear, red light, up direction, enabled table declared
{"GearUp", "Off", "Null", "Disabled", {NULL, NULL}},//gear up, off state switch, null and disabled condition declared
{"CheckingBeforeLanding", "Red", "Down", "Enabled", {NULL, NULL}},//checking before landing, red light, down, enabled table declared
{"LoweringGear", "Green", "Down", "Enabled", {"Disabled", "Enabled"}}//lowering gear, green light, down, enabled declared
};
#endif /* AIR_H_ *///end of declaration
Output:
The Finite State machine is initialized and current the program is inGearDown State & Light is: Green
Enter the status of pilot's lever and squat switch:0 0
Current state: CheckingBeforeTakeOFF
Light is : Green
Enter the status of pilot's lever and squat switch and hydraulic mechanism:0 0 1
Current state: RaisingGear
Light is : Red
Status of Direction valve : Up
Status of Gas Pressurized Spring system: Disabled
Enter the status of pilot's lever and limit switch:0 1
Current state : GearUp
Light is : Off
Landing Gear Hydraulic Control : Disabled
Enter the status of pilot's lever:1
Current state : CheckingBeforeLanding
Light is : Red
Landing Gear Hydraulic Control : Enabled
Enter the status of pilot's lever and hydraulic mechanism status:1 0
Current state: LoweringGear
Light is : Green
Status of Direction valve : Down
Enter the status of pilot's lever and limit switch:1 0
Current state: CheckingBeforeTakeOFF
Light is : Green
Enter the status of pilot's lever and squat switch and hydraulic mechanism: