Project 2-Highway Assistant-Lane Changing Assistant
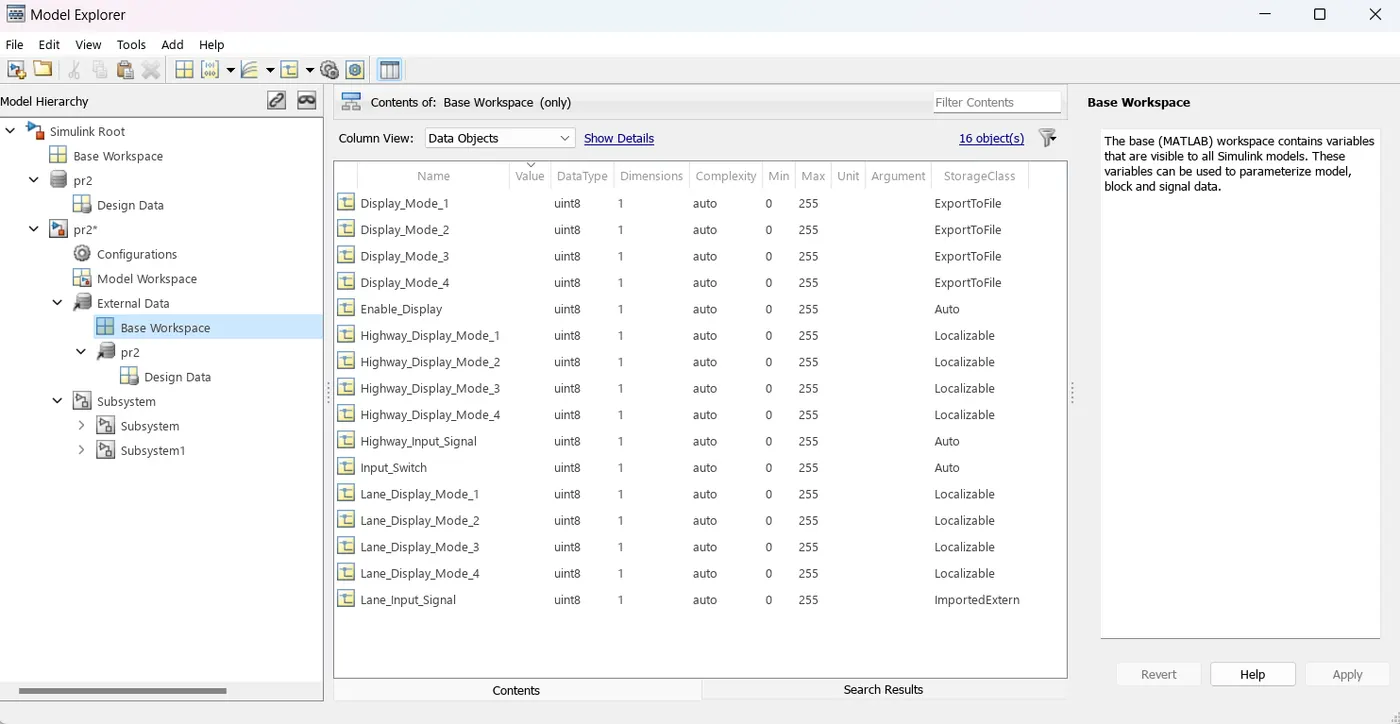
The modelling of the Lange changing assist feature is initiated with the creation of a simulink data dictionary. The above mentioned signals are all added to the dictionary and the necessary calibration data is provided.
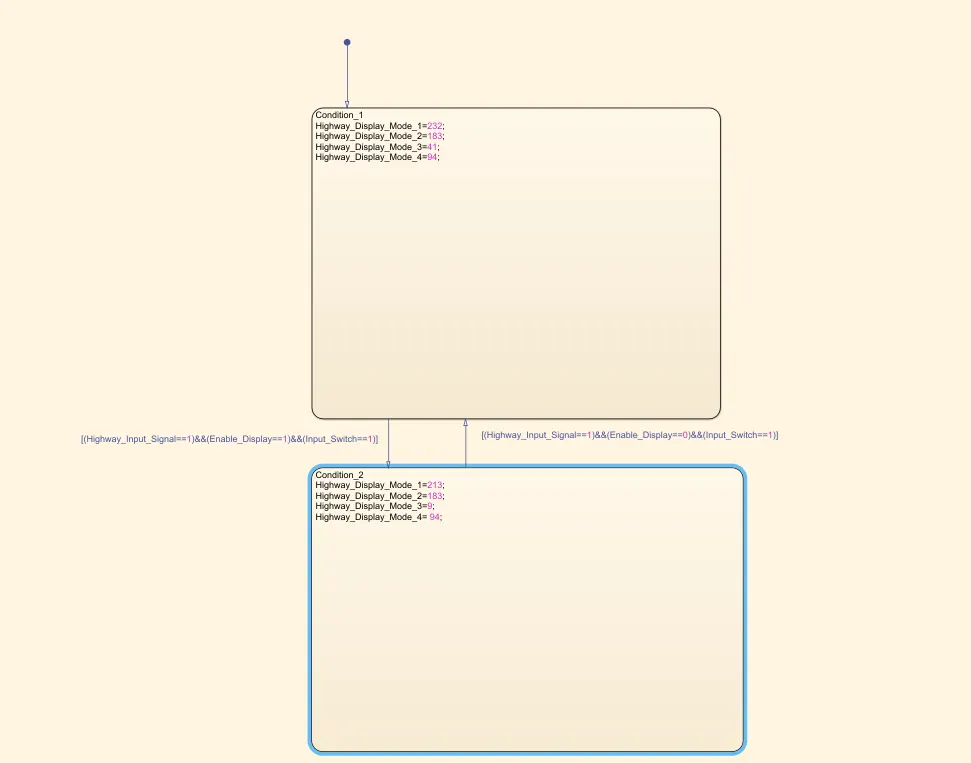
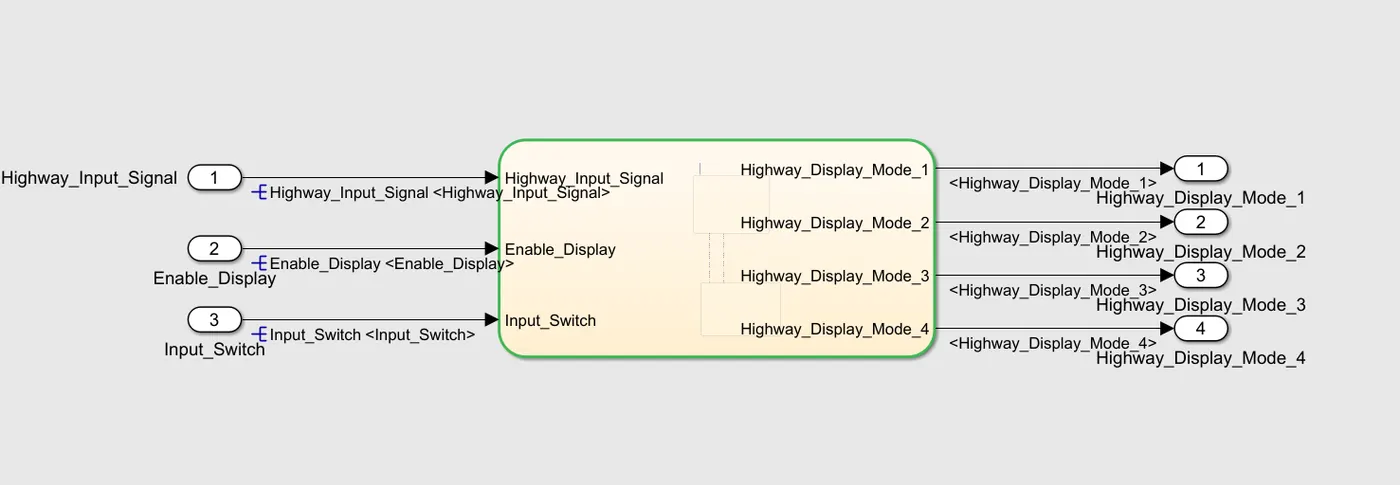
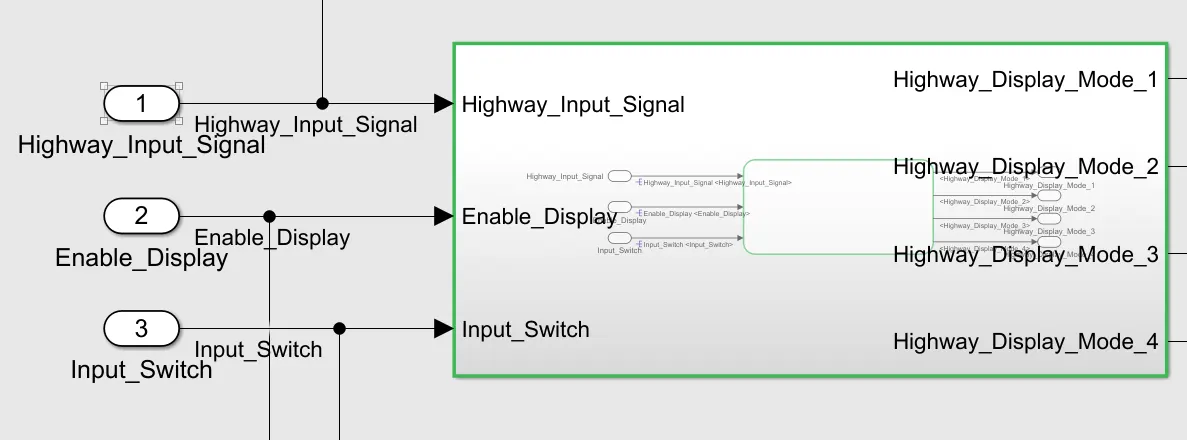
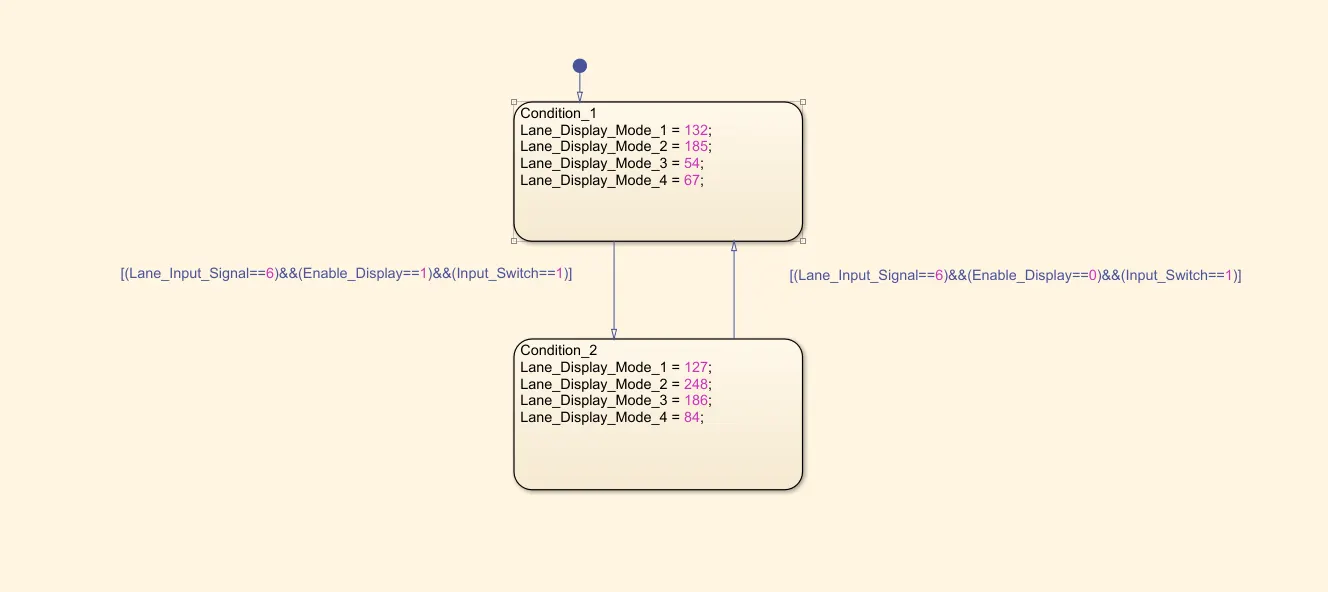
Onto to the further steps of the modelling, the requirements are carefully analyzed and the first subsystem, which is suggested to be comprised of 3 inputs and 4 outputs is created. At the lower levels of this subsystem a chart is inserted with thye stateflow as follows.
Another Subsystem, with one more set of charts and stateflow has been created that comprises of the lane display modes.
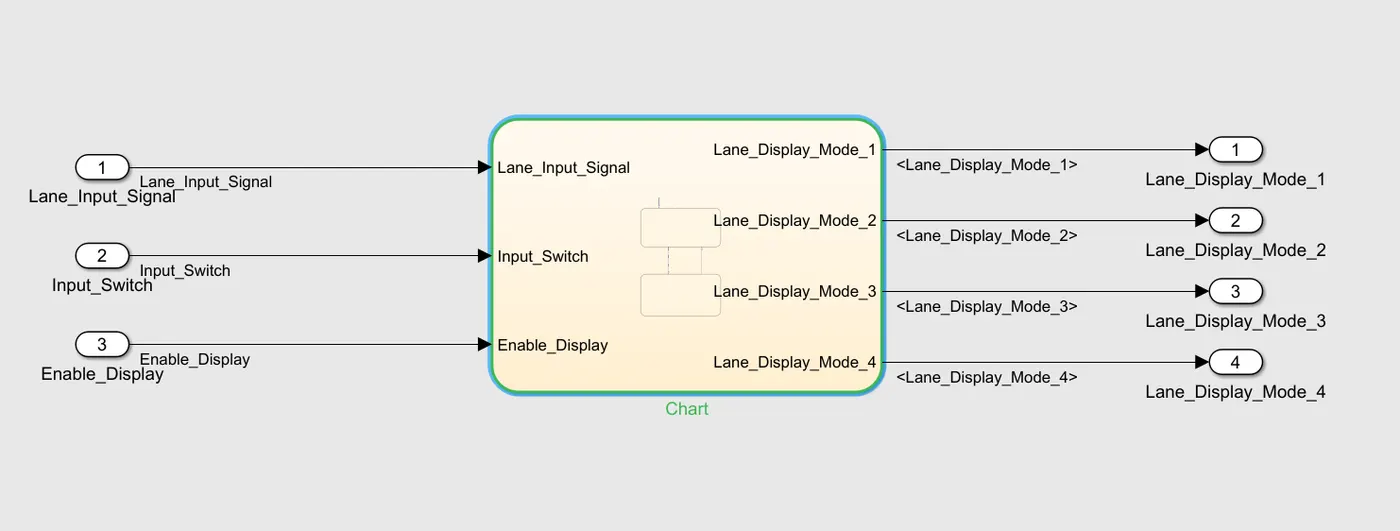
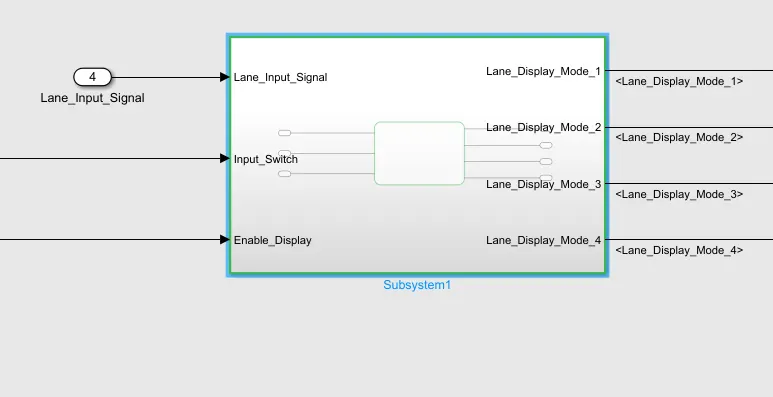
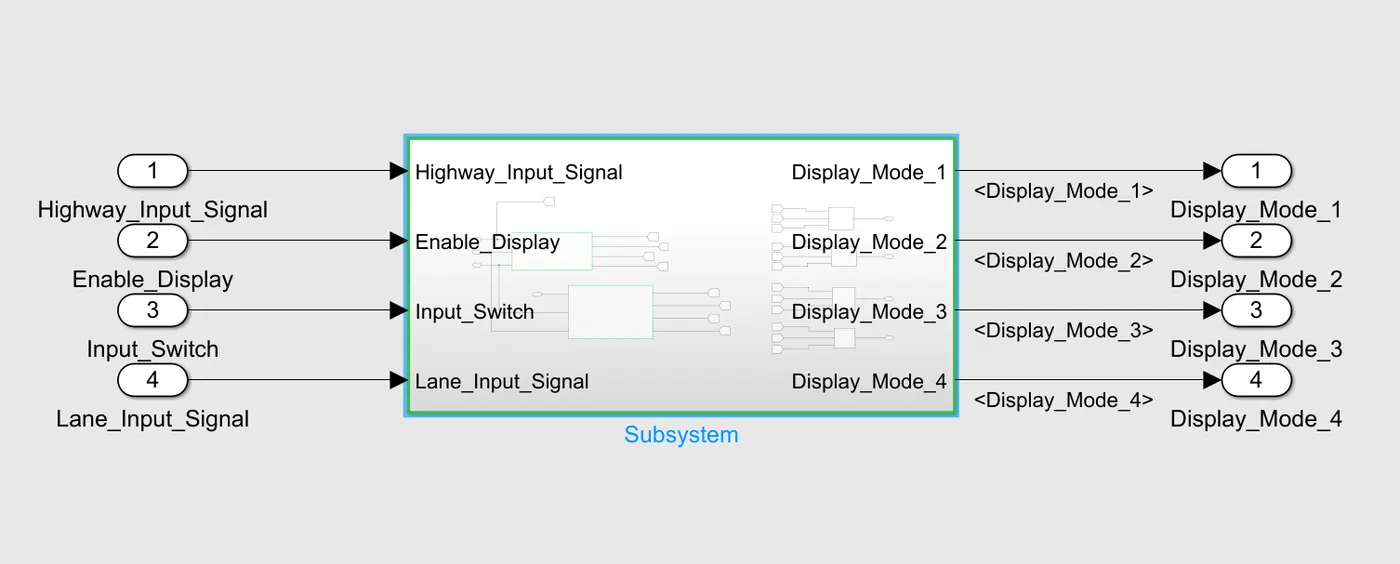
All the ouput and input signals are then resolved after making appropriate connections with the inports and the outports. The outputs form the subsytems are connected to gotoblocks in order to avoid signal lines passing over one another and ease of understanding and troubleshooting. Switch blocks are made use of to implement the conditional cases and the from blocks serve the input signals to these blocks. The overall model looks as follows.
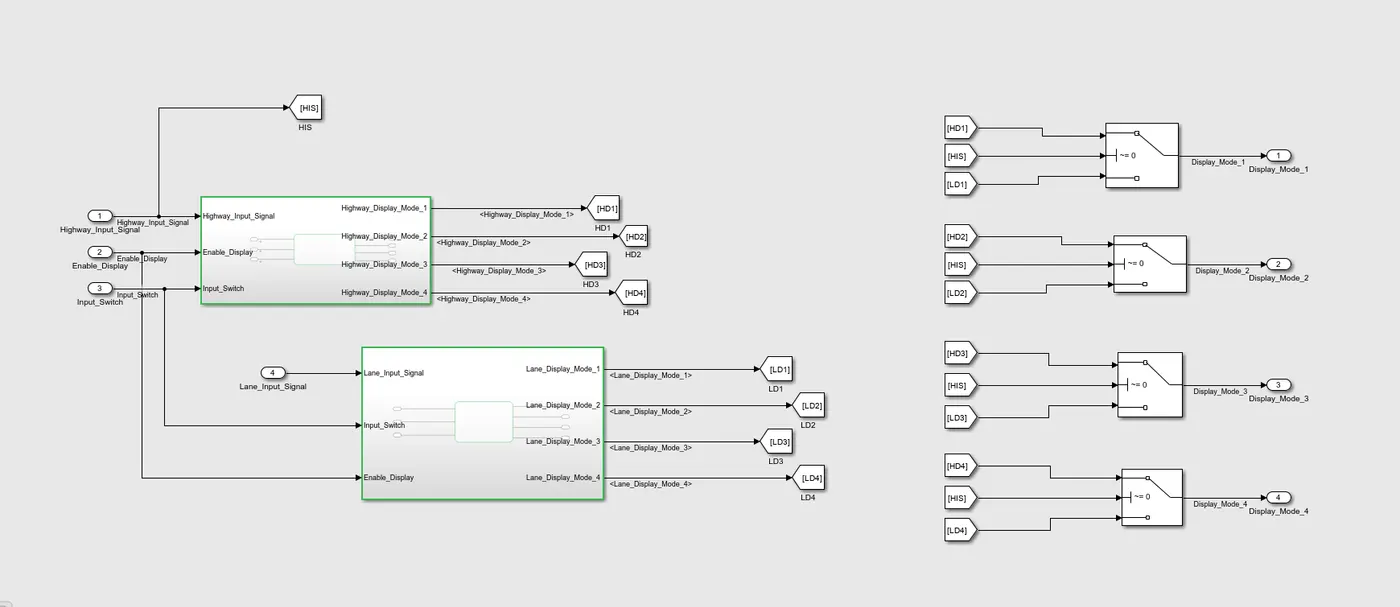
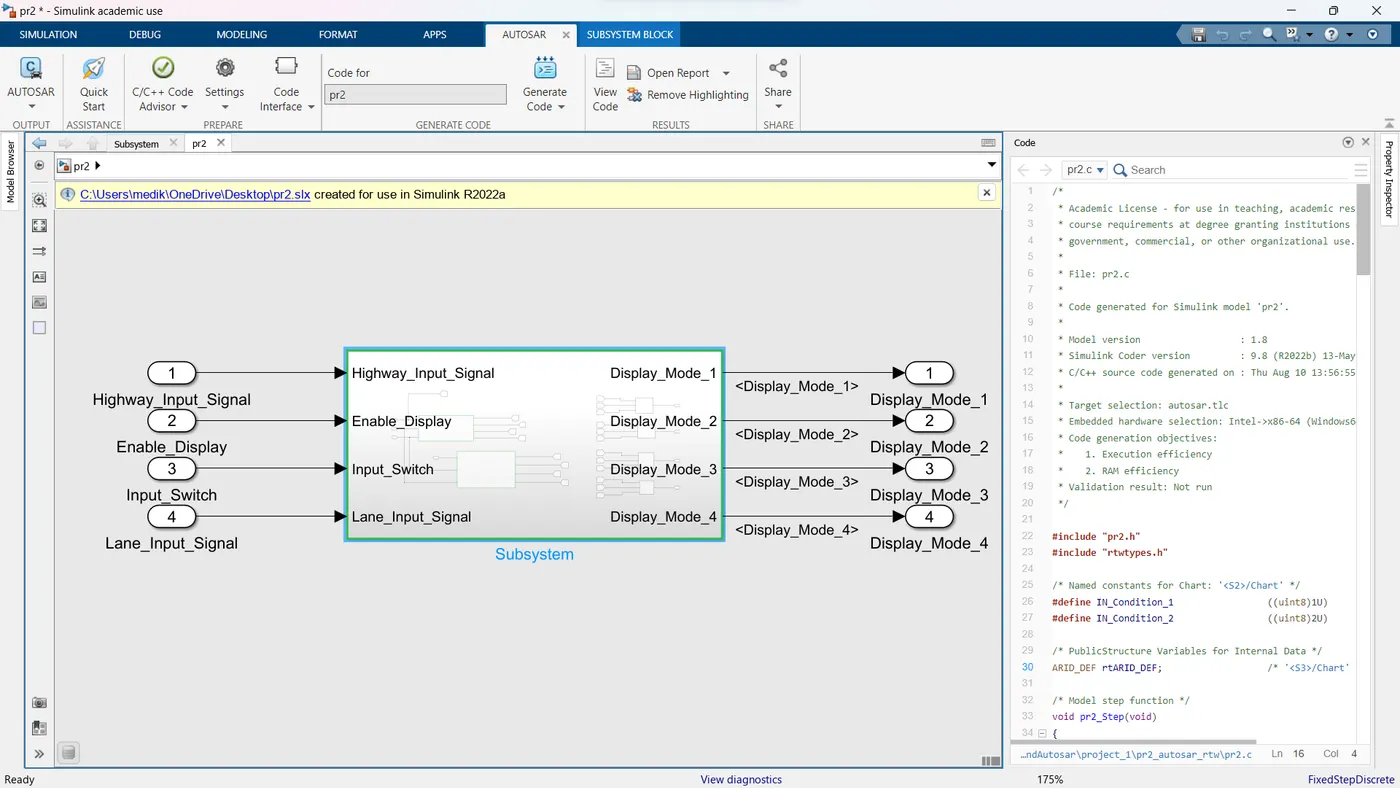
This model, for viewing purposes is masked using a subsystem.
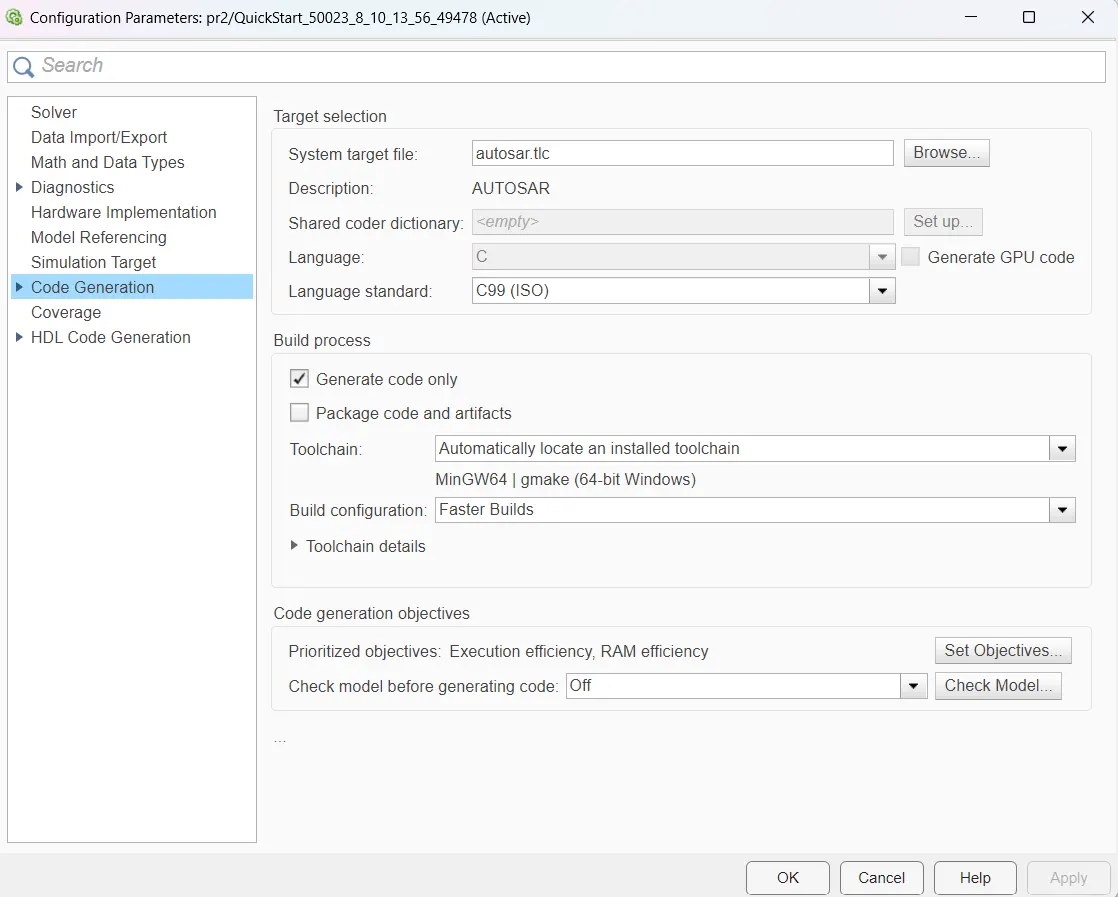
The model configurations are adjusted as per the requirements of the Autosar code generation. The system target file is changed to autosar.tlc and the solver characteristics are adjusted to fixed step and discrete.
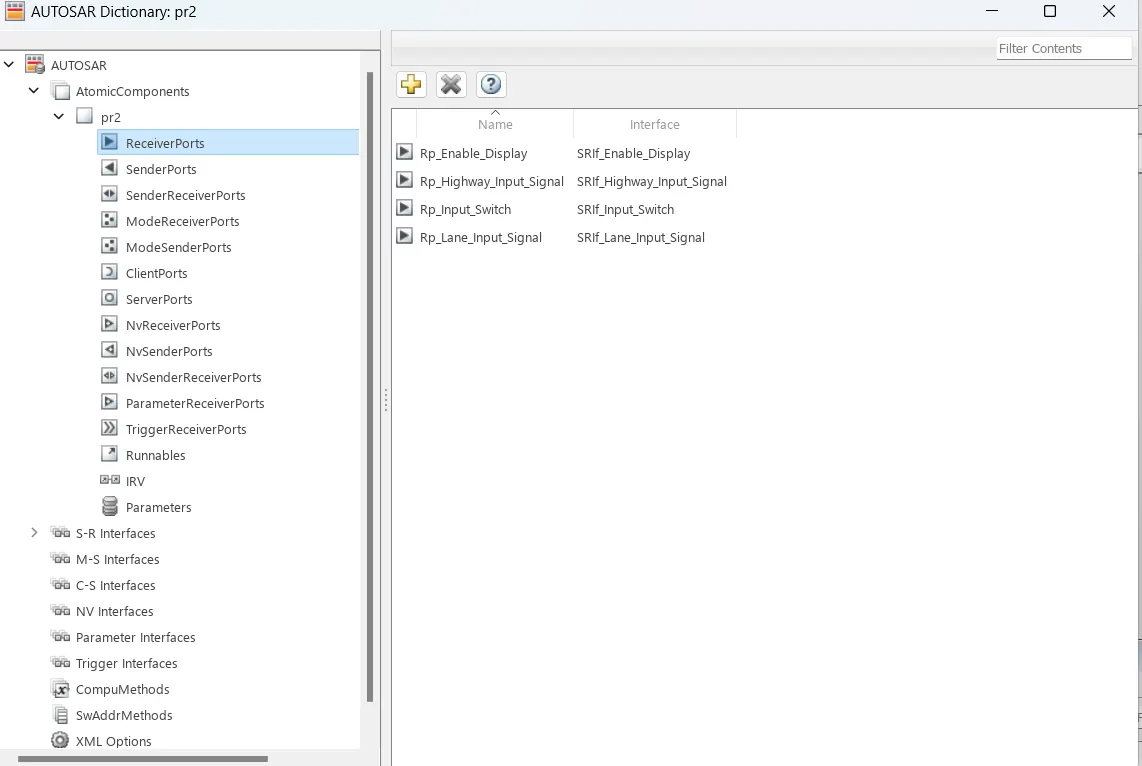
Under the apps tab the autosar component is run and the autosar dictionary is opened. Proper prefixes are assigned to reciever, sender ports. Interfaces and data elements. XML options are verified and runnables are created.
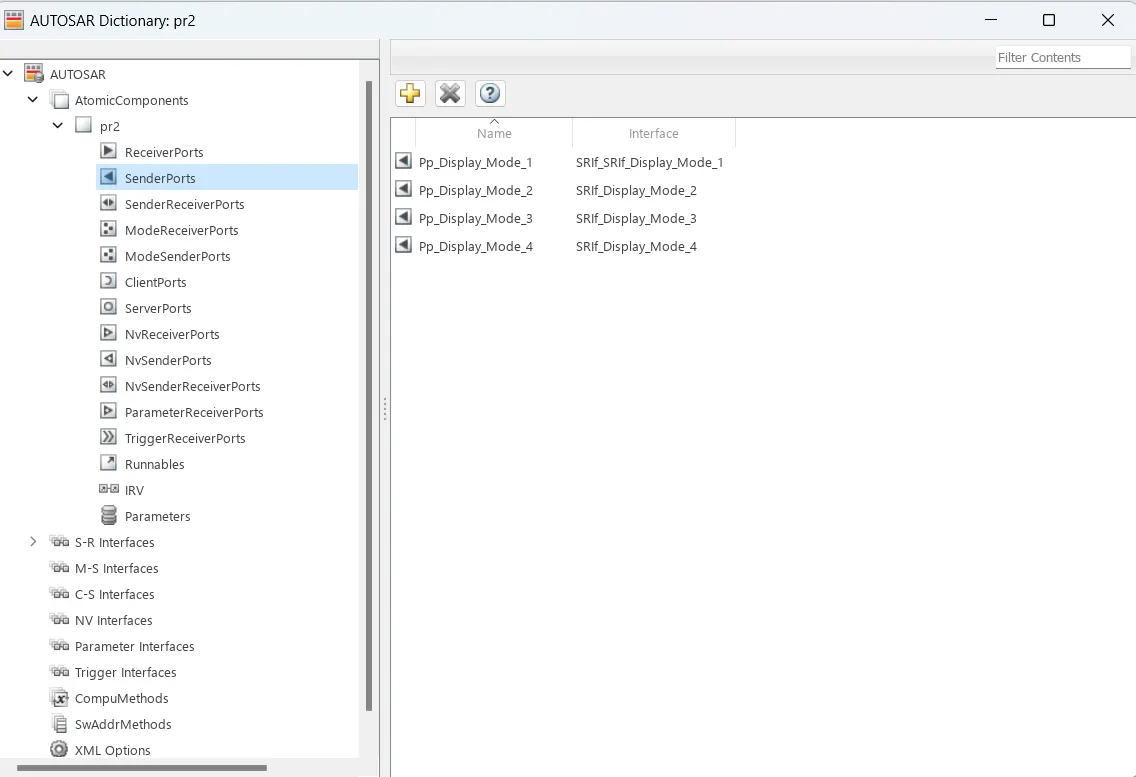
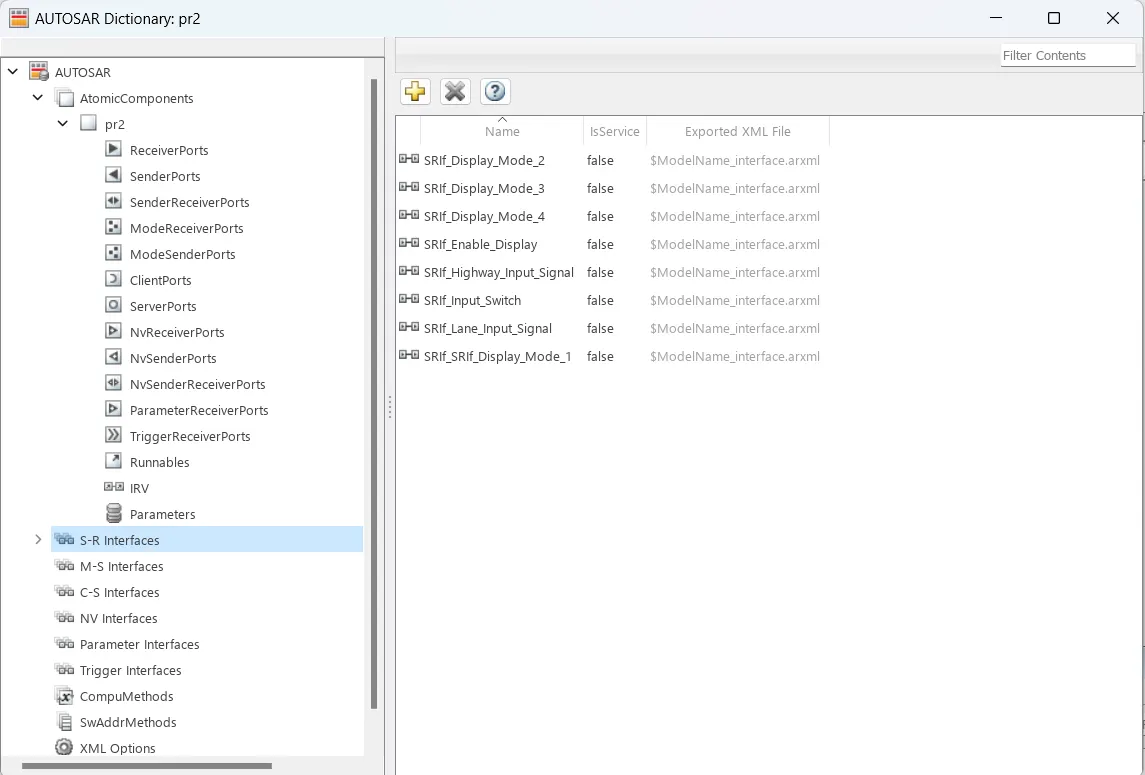
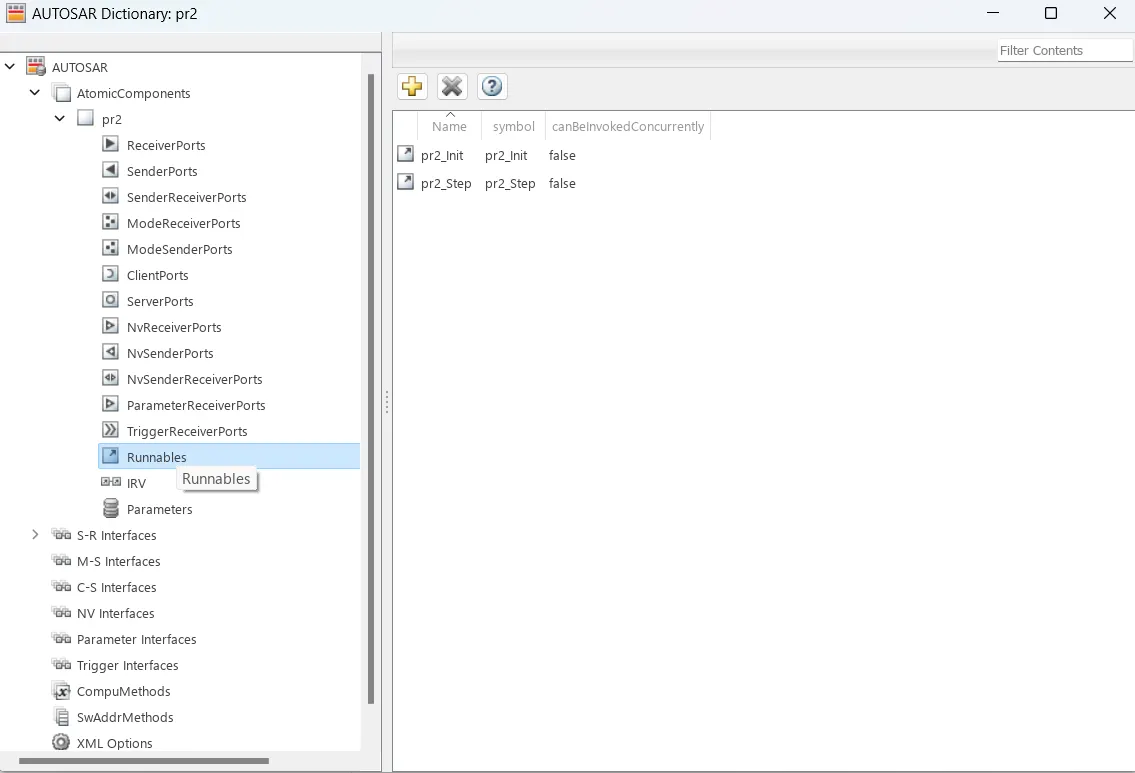
From the code mappings editor the ports, interfaces and data elements are mapped with each other and they are validated successfully.
For the generation of autosar compliant code, the quick start is run for the autosar tab in simulink. The code is successfully generated using the autosar coder and no errors or diagnostic issues are recorded.
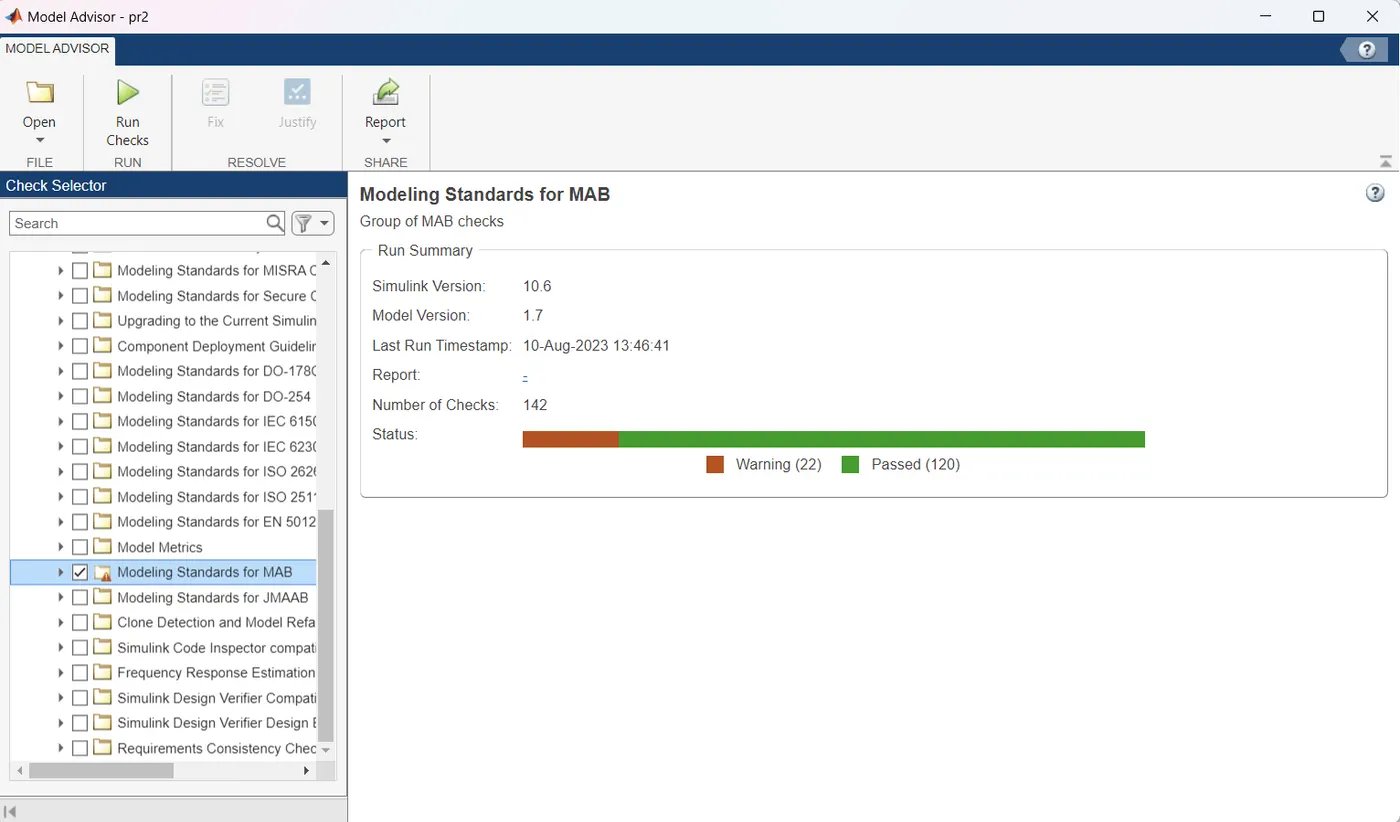
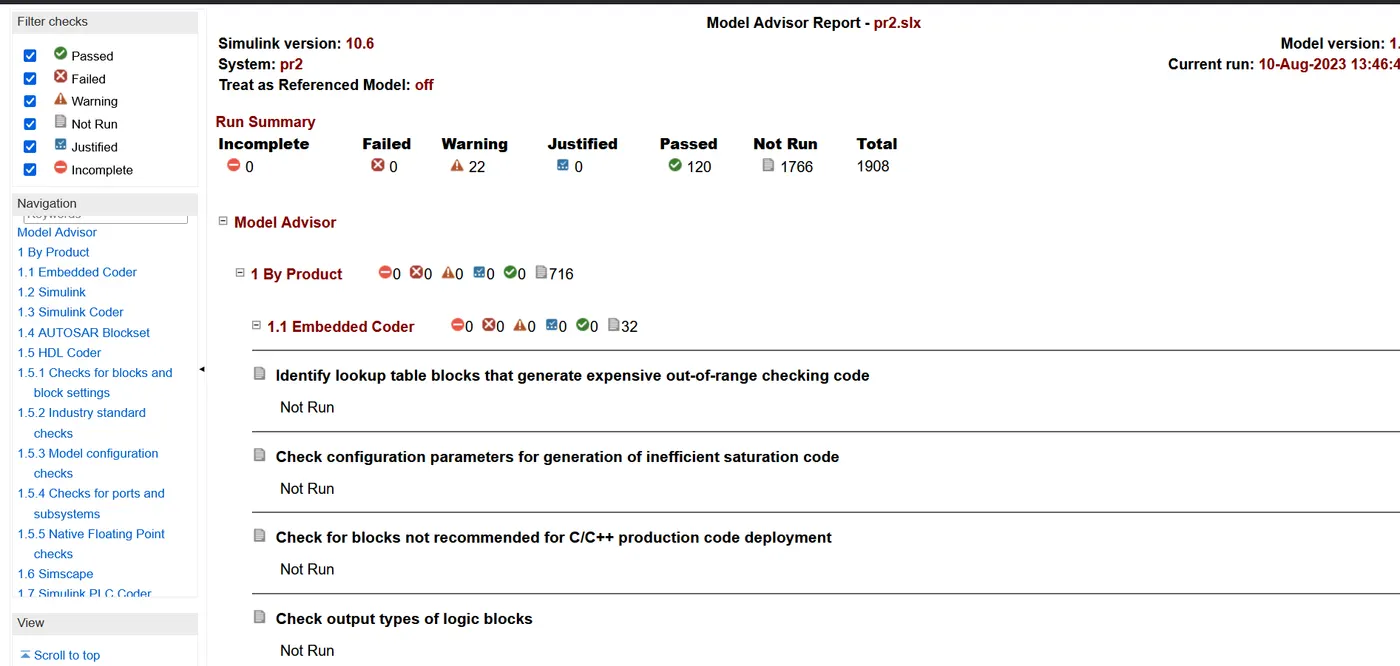
The model advisor is run for MAAB guidelines and no failures are reported.
Conclusion:
The Lane change assist model is successfully developed and implemented. The autosar port mapping is performed followed by code genaration and model advisor checks with no noticeable issues or failures.