Project 2 Adaptive Cruise Control
AIM: To develop an adaptive CruiseControl feauture as per the model according to the given requirements in the Document Using Matlab/Simulink
MATLAB Version: MATLAB2018a
Steps
- Linking of the Simulink Data Dictionary
- Developement of the Desired model
- Configuration Parameter Setting
- Requirement Tagging
- Signal resolving and Signal Propogation
- Model Advisor Report Generation
- C-code generation
Create the simulink Data Dictionary
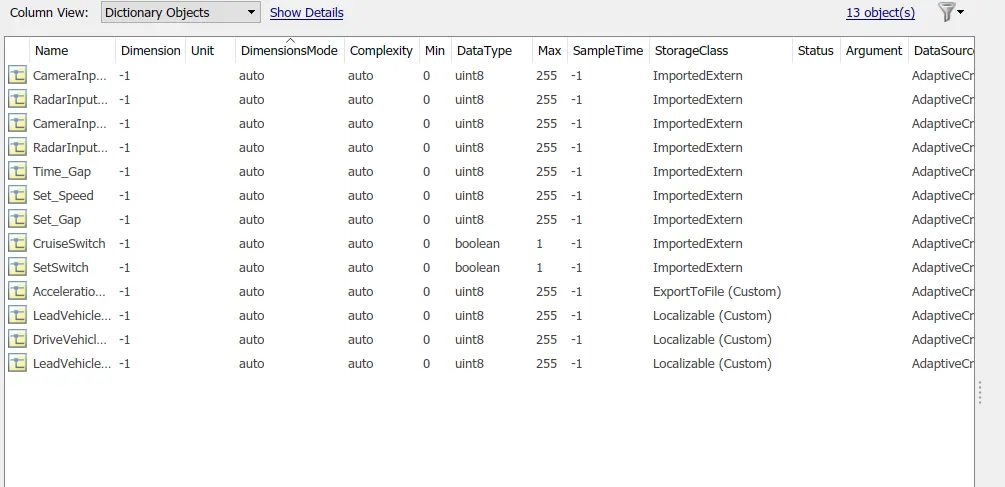
To Create a sldd file to update all the given inputs, outputs & parameters on this file later calling these variables on the Simulink blocks are shown in the fig. select the storage classes for inputs as imported extern,outputs storage class is Export to file,local variables storage class as Localizable
Developement of the Desired model
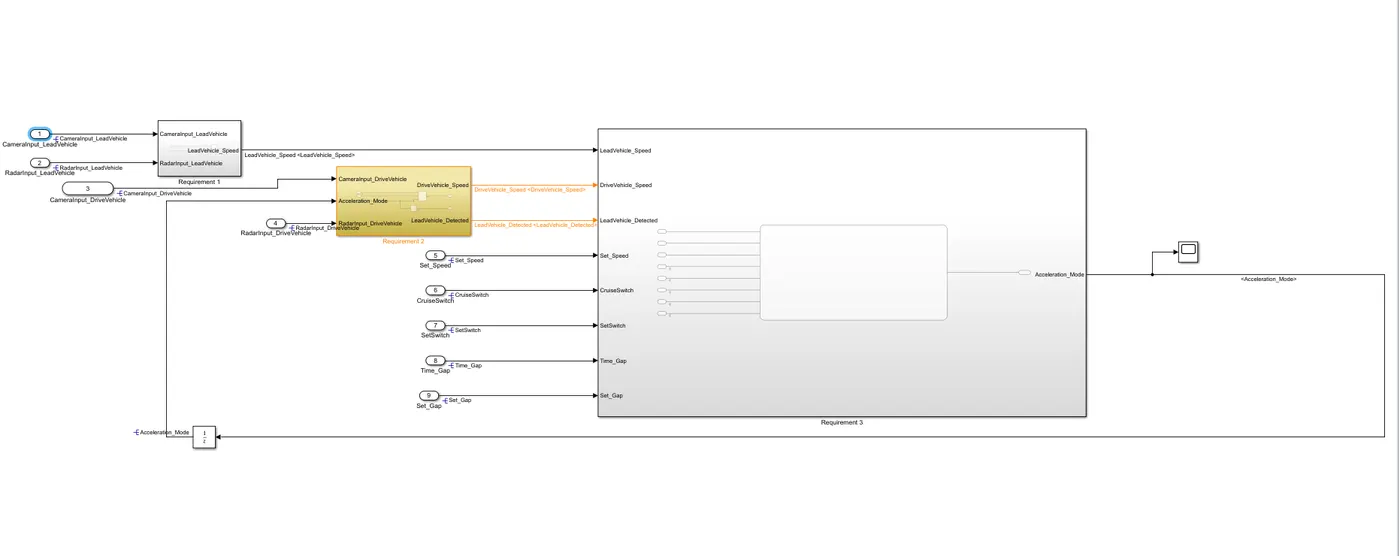
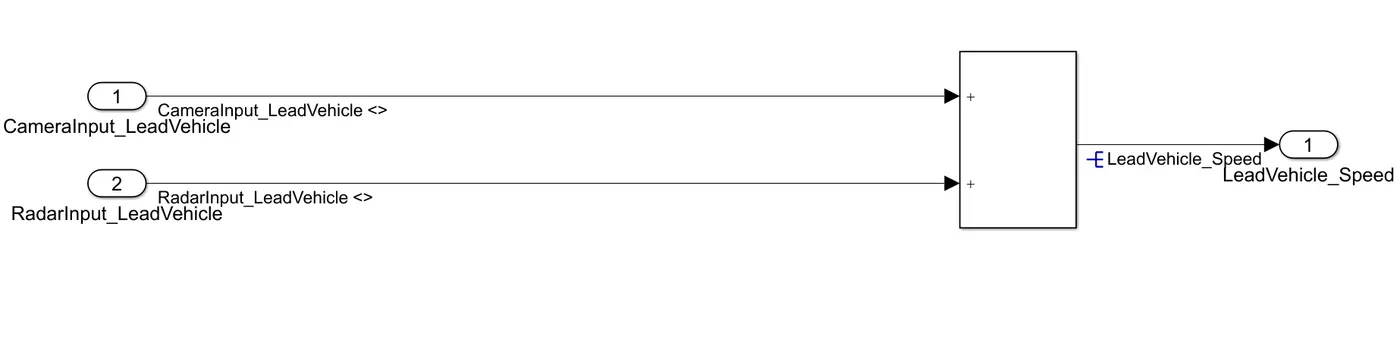
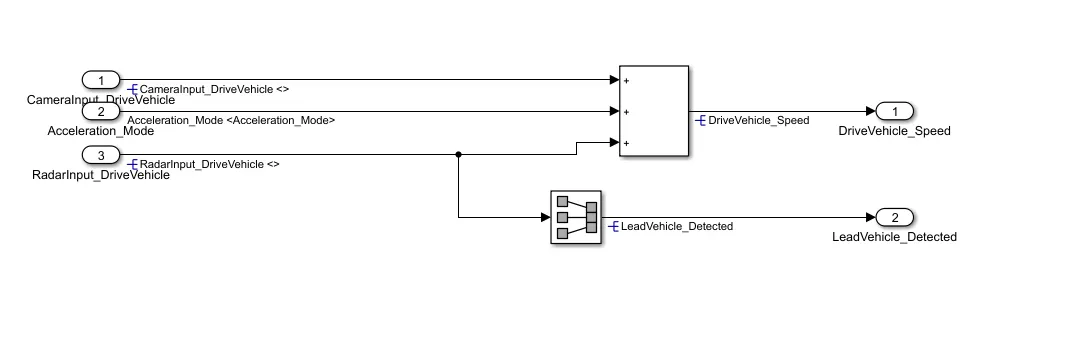
As per the requirement develop the model here there is 3 requirements with the inputs, outputs
Requirement_1
Requirement_2
Requirement_3
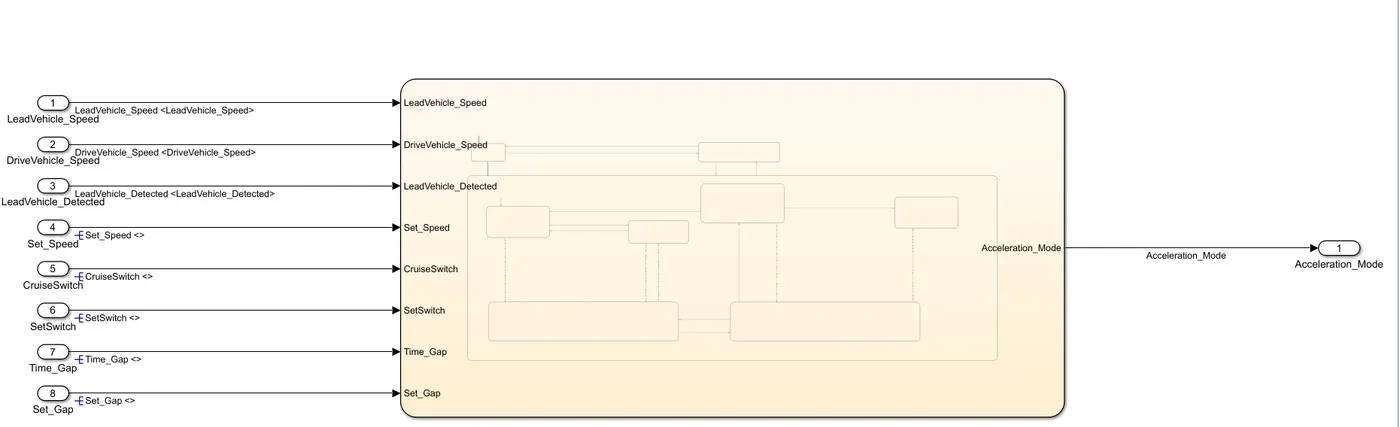
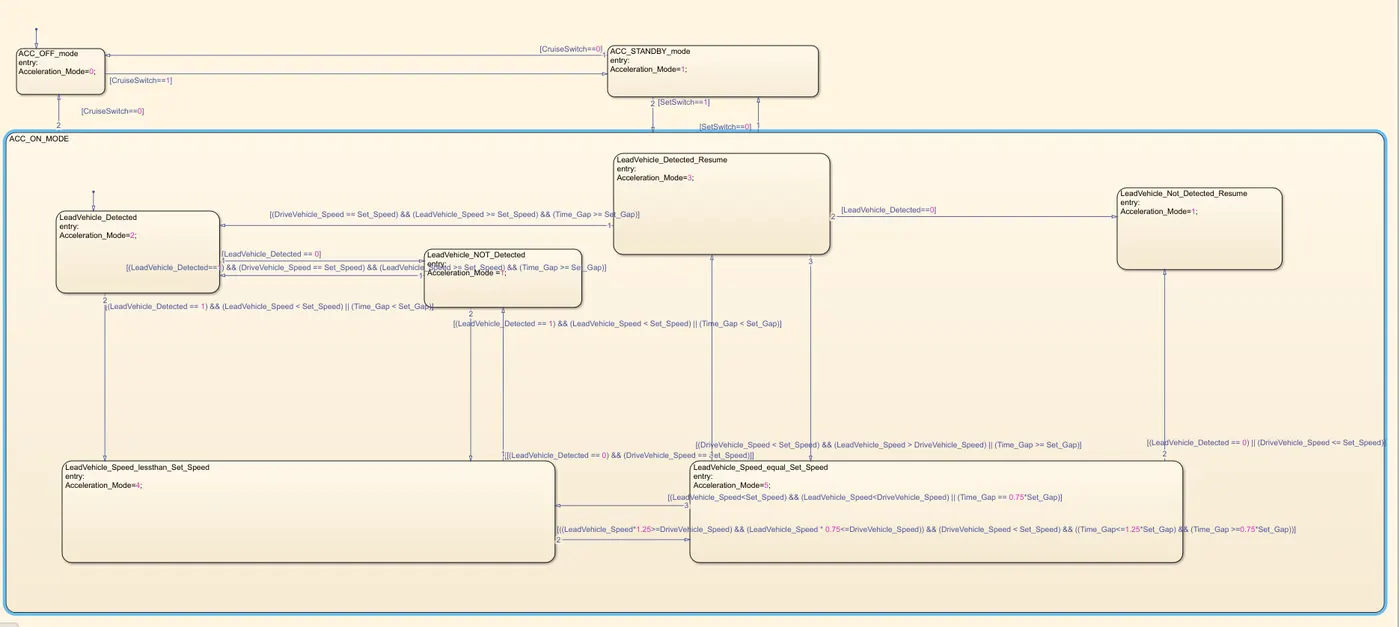
Configuration Settings
Solver Type is changed from variable step to Fixed step and Solver type is selected as Discrete ( No continuous state) and also sample time is declared as 0.01 sec as per the project requirement.
Also under the Code generation option selecting embedded real time as system target file (ert.tlc) under target selection option
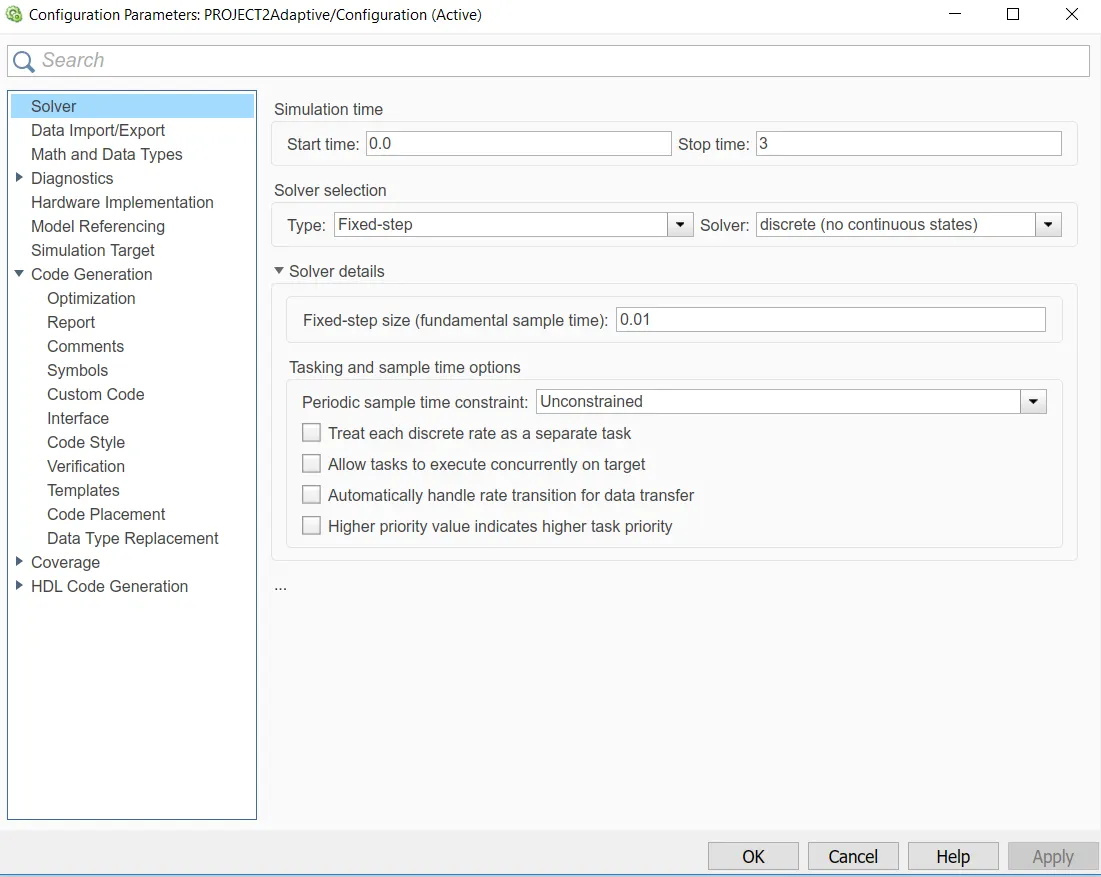
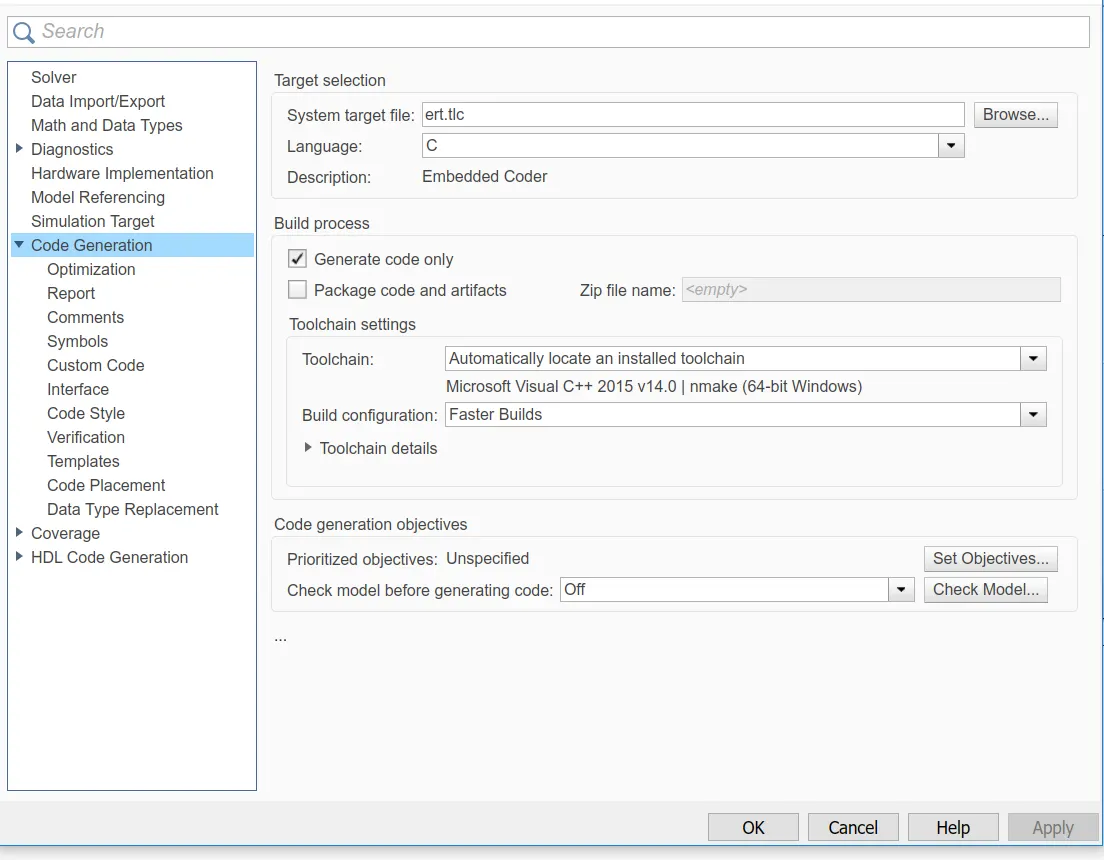
Requirement Tagging:-
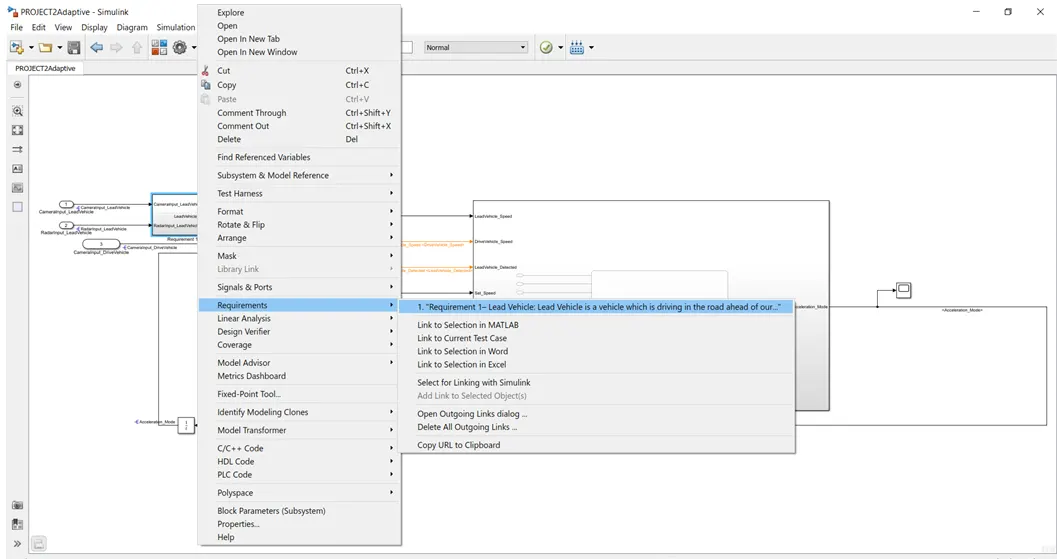
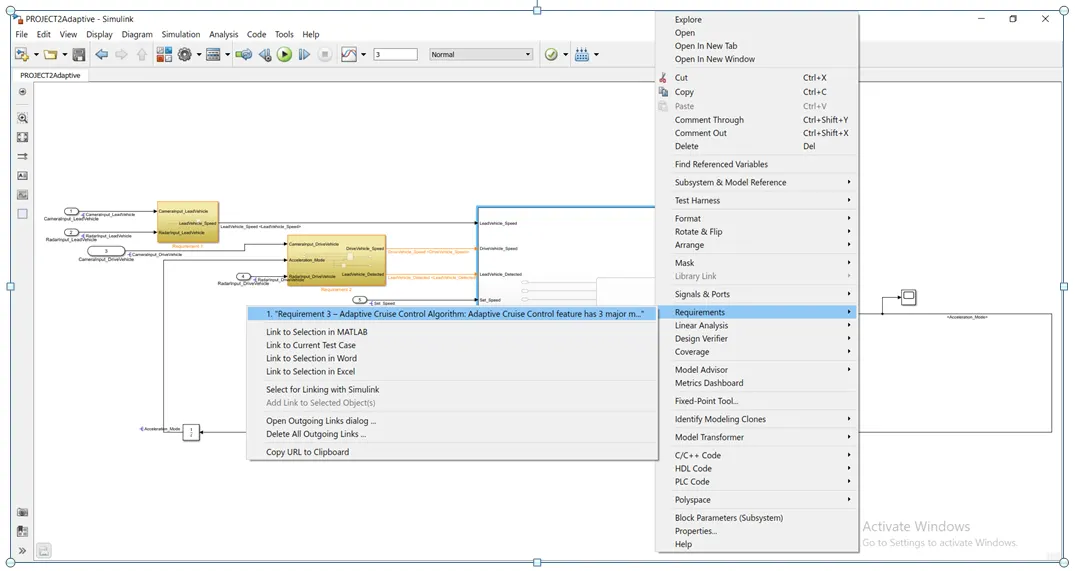
A MS Word file is created which contain all the requirements and necessary information to develop the model appropiately. This Word file is tagged for both the subsystem Requirement1 , Requirement2, Requirement3 respectively.
Model Advisor Report Generation
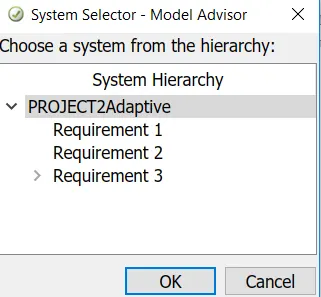
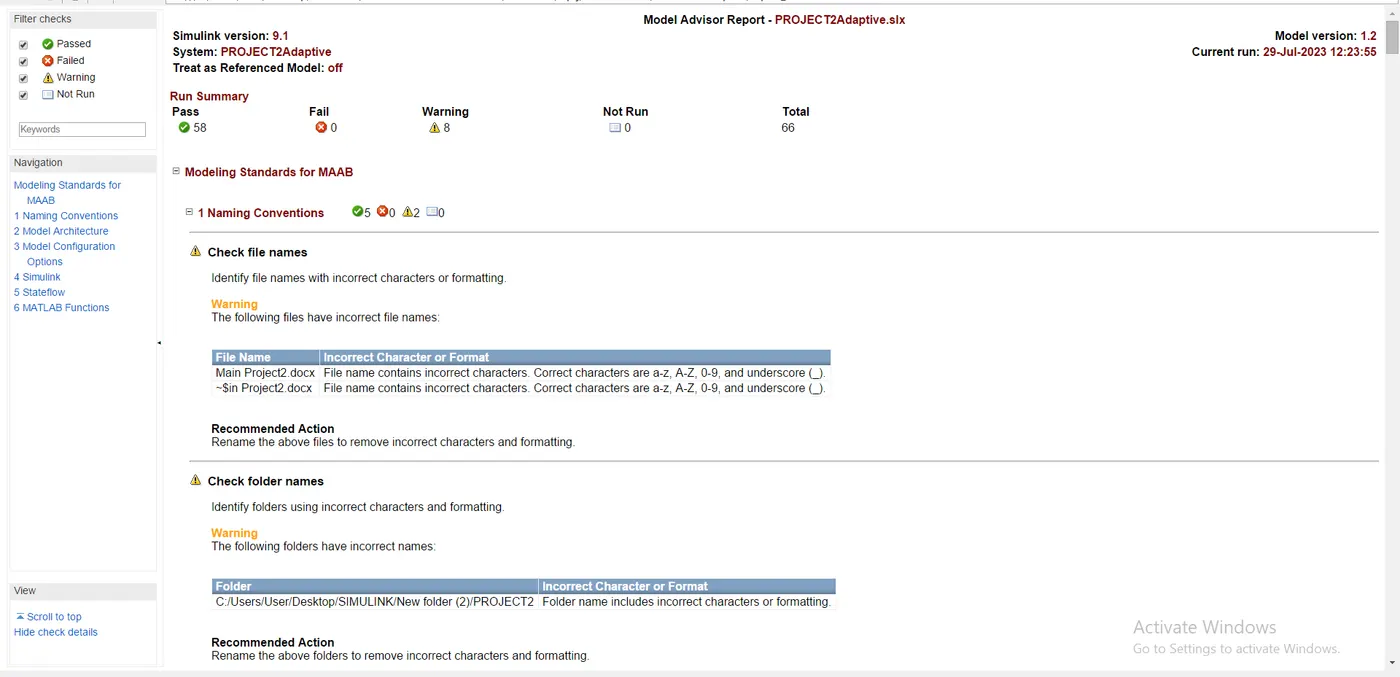
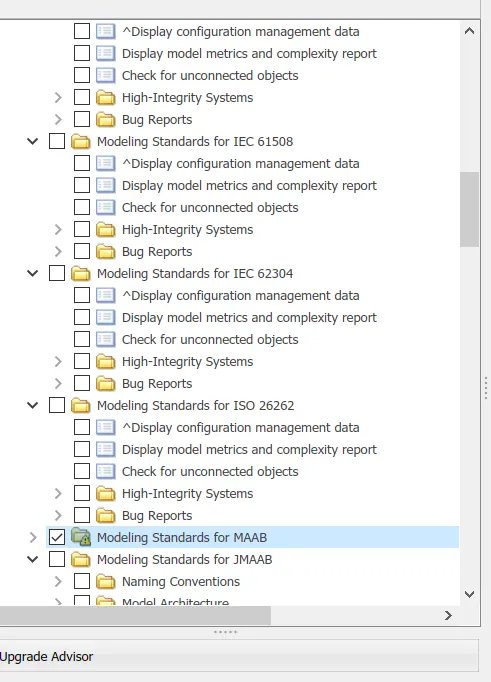
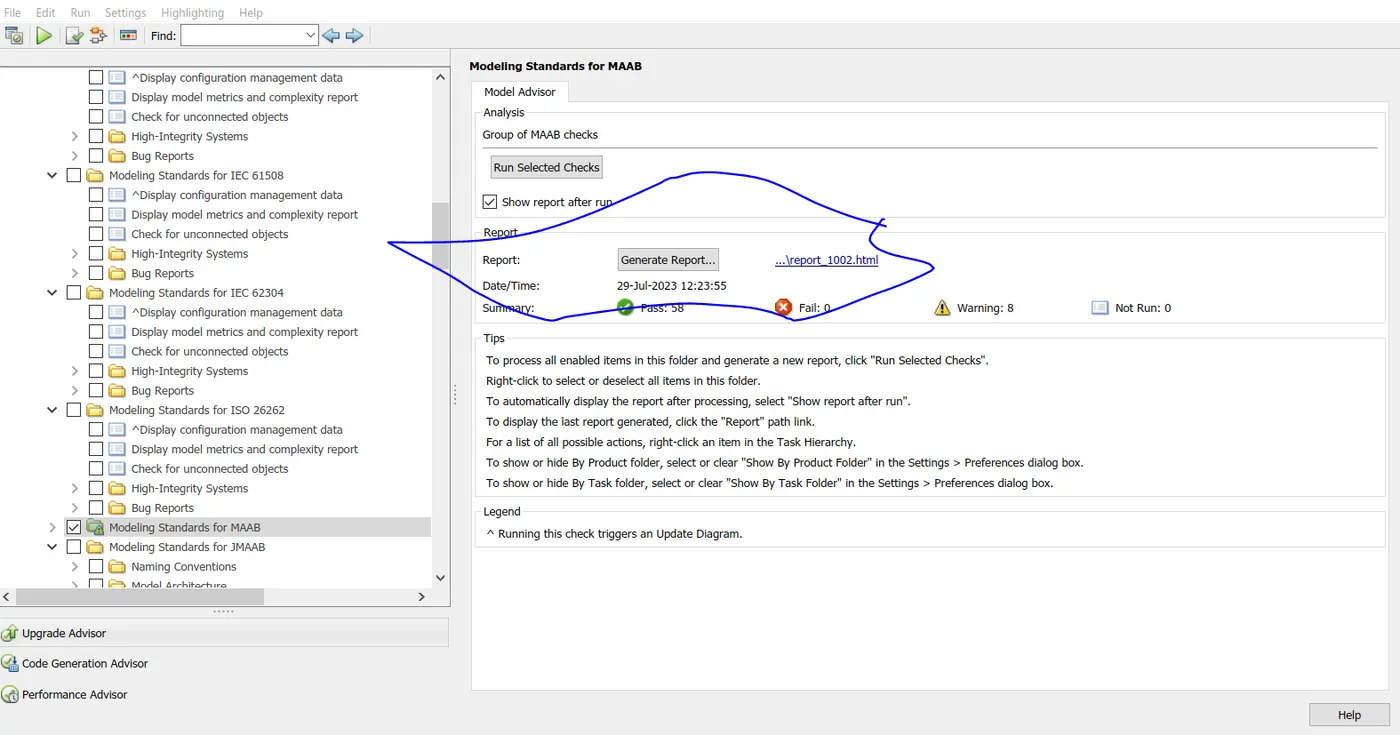
Click on the Model advisor and click on ok after that report is generated than selected modelling standards for MAAB after that click on run selected checks and save the report format in html format
Code generation Report
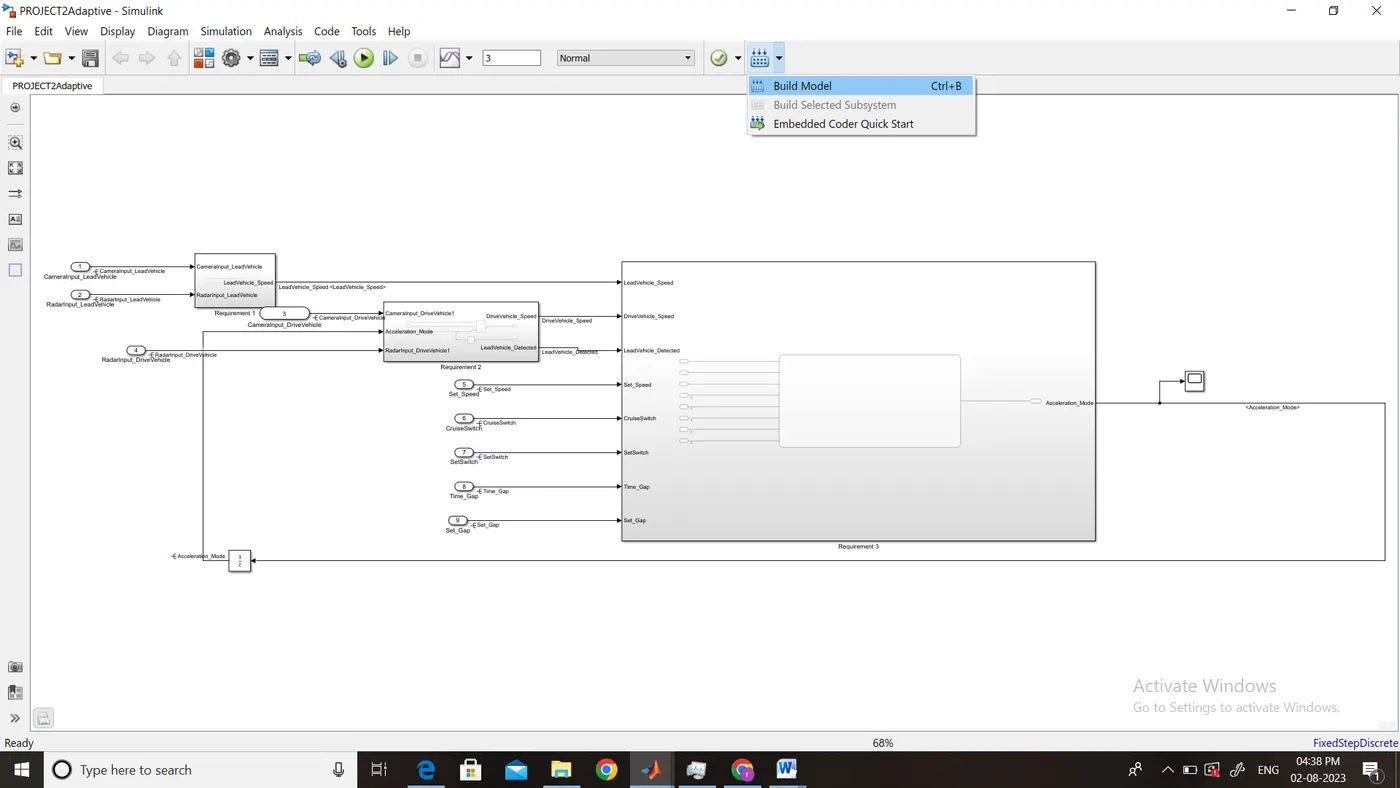
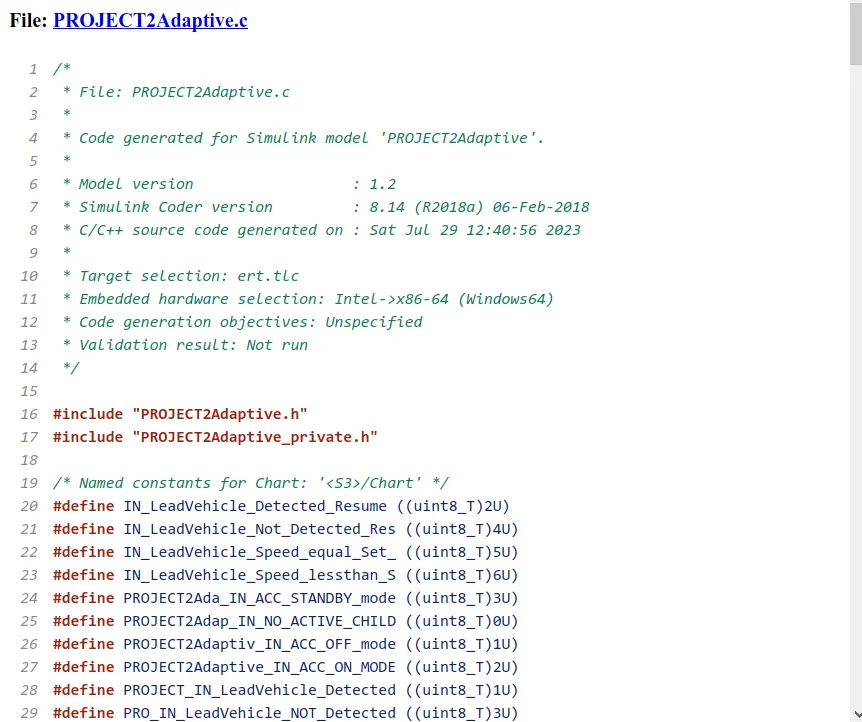
after execution of the model advisor report click on the build model than code is generated
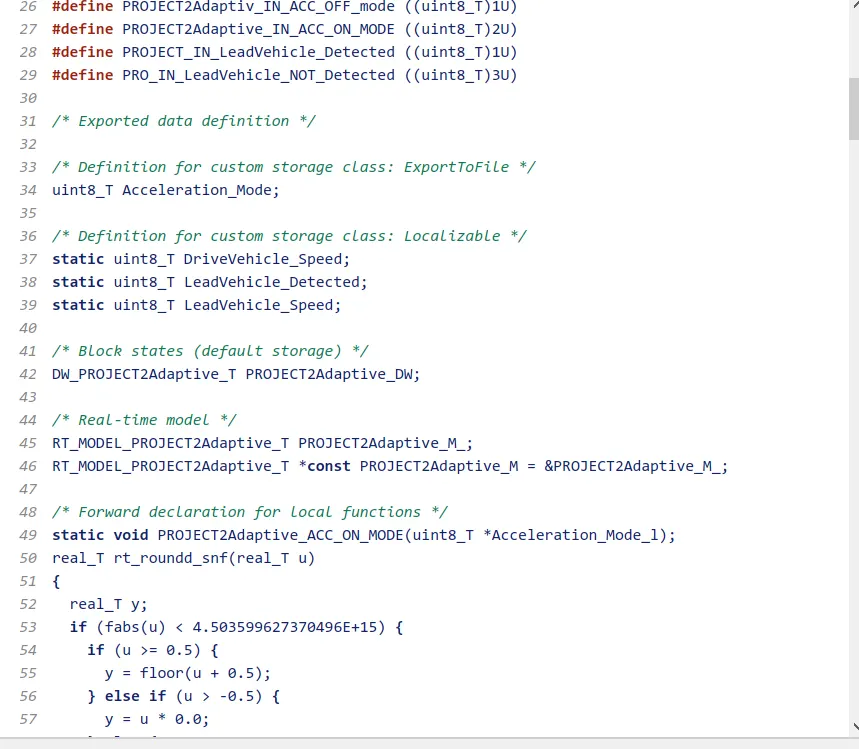
Code generation
File: PROJECT2Adaptive.c
|
1 |
/* |
|
2 |
* File: PROJECT2Adaptive.c |
|
3 |
* |
|
4 |
* Code generated for Simulink model 'PROJECT2Adaptive'. |
|
5 |
* |
|
6 |
* Model version : 1.0 |
|
7 |
* Simulink Coder version : 8.14 (R2018a) 06-Feb-2018 |
|
8 |
* C/C++ source code generated on : Thu Jul 27 23:21:07 2023 |
|
9 |
* |
|
10 |
* Target selection: ert.tlc |
|
11 |
* Embedded hardware selection: Intel->x86-64 (Windows64) |
|
12 |
* Code generation objectives: Unspecified |
|
13 |
* Validation result: Not run |
|
14 |
*/ |
|
15 |
|
|
16 |
#include "PROJECT2Adaptive.h" |
|
17 |
#include "PROJECT2Adaptive_private.h" |
|
18 |
|
|
19 |
/* Named constants for Chart: '/Chart' */ |
|
20 |
#define IN_LeadVehicle_Detected_Resume ((uint8_T)2U) |
|
21 |
#define IN_LeadVehicle_Not_Detected_Res ((uint8_T)4U) |
|
22 |
#define IN_LeadVehicle_Speed_equal_Set_ ((uint8_T)5U) |
|
23 |
#define IN_LeadVehicle_Speed_lessthan_S ((uint8_T)6U) |
|
24 |
#define PROJECT2Ada_IN_ACC_STANDBY_mode ((uint8_T)3U) |
|
25 |
#define PROJECT2Adap_IN_NO_ACTIVE_CHILD ((uint8_T)0U) |
|
26 |
#define PROJECT2Adaptiv_IN_ACC_OFF_mode ((uint8_T)1U) |
|
27 |
#define PROJECT2Adaptive_IN_ACC_ON_MODE ((uint8_T)2U) |
|
28 |
#define PROJECT_IN_LeadVehicle_Detected ((uint8_T)1U) |
|
29 |
#define PRO_IN_LeadVehicle_NOT_Detected ((uint8_T)3U) |
|
30 |
|
|
31 |
/* Exported data definition */ |
|
32 |
|
|
33 |
/* Definition for custom storage class: ExportToFile */ |
|
34 |
uint8_T Acceleration_Mode; |
|
35 |
|
|
36 |
/* Definition for custom storage class: Localizable */ |
|
37 |
static uint8_T DriveVehicle_Speed; |
|
38 |
static uint8_T LeadVehicle_Detected; |
|
39 |
static uint8_T LeadVehicle_Speed; |
|
40 |
|
|
41 |
/* Block states (default storage) */ |
|
42 |
DW_PROJECT2Adaptive_T PROJECT2Adaptive_DW; |
|
43 |
|
|
44 |
/* External inputs (root inport signals with default storage) */ |
|
45 |
ExtU_PROJECT2Adaptive_T PROJECT2Adaptive_U; |
|
46 |
|
|
47 |
/* Real-time model */ |
|
48 |
RT_MODEL_PROJECT2Adaptive_T PROJECT2Adaptive_M_; |
|
49 |
RT_MODEL_PROJECT2Adaptive_T *const PROJECT2Adaptive_M = &PROJECT2Adaptive_M_; |
|
50 |
|
|
51 |
/* Forward declaration for local functions */ |
|
52 |
static void PROJECT2Adaptive_ACC_ON_MODE(uint8_T *Acceleration_Mode_l); |
|
53 |
real_T rt_roundd_snf(real_T u) |
|
54 |
{ |
|
55 |
real_T y; |
|
56 |
if (fabs(u) < 4>{ |
|
57 |
if (u >= 0.5) { |
|
58 |
y = floor(u + 0.5); |
|
59 |
} else if (u > -0.5) { |
|
60 |
y = u * 0.0; |
|
61 |
} else { |
|
62 |
y = ceil(u - 0.5); |
|
63 |
} |
|
64 |
} else { |
|
65 |
y = u; |
|
66 |
} |
|
67 |
|
|
68 |
return y; |
|
69 |
} |
|
70 |
|
|
71 |
/* Function for Chart: '/Chart' */ |
|
72 |
static void PROJECT2Adaptive_ACC_ON_MODE(uint8_T *Acceleration_Mode_l) |
|
73 |
{ |
|
74 |
int32_T tmp; |
|
75 |
int32_T tmp_0; |
|
76 |
uint8_T tmp_1; |
|
77 |
uint8_T tmp_2; |
|
78 |
|
|
79 |
/* Inport: '/SetSwitch' incorporates: |
|
80 |
* Inport: '/CruiseSwitch' |
|
81 |
* Inport: '/Set_Gap' |
|
82 |
* Inport: '/Set_Speed' |
|
83 |
* Inport: '/Time_Gap' |
|
84 |
*/ |
|
85 |
if (!SetSwitch) { |
|
86 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PROJECT2Adap_IN_NO_ACTIVE_CHILD; |
|
87 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = PROJECT2Ada_IN_ACC_STANDBY_mode; |
|
88 |
*Acceleration_Mode_l = 1U; |
|
89 |
} else if (!CruiseSwitch) { |
|
90 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PROJECT2Adap_IN_NO_ACTIVE_CHILD; |
|
91 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = PROJECT2Adaptiv_IN_ACC_OFF_mode; |
|
92 |
*Acceleration_Mode_l = 0U; |
|
93 |
} else { |
|
94 |
switch (PROJECT2Adaptive_DW.is_ACC_ON_MODE) { |
|
95 |
case PROJECT_IN_LeadVehicle_Detected: |
|
96 |
*Acceleration_Mode_l = 2U; |
|
97 |
if (LeadVehicle_Detected == 0) { |
|
98 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PRO_IN_LeadVehicle_NOT_Detected; |
|
99 |
*Acceleration_Mode_l = 1U; |
|
100 |
} else { |
|
101 |
if (((LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set> |
|
102 |
(Time_Gap < Set>{ |
|
103 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_lessthan_S; |
|
104 |
*Acceleration_Mode_l = 4U; |
|
105 |
} |
|
106 |
} |
|
107 |
break; |
|
108 |
|
|
109 |
case IN_LeadVehicle_Detected_Resume: |
|
110 |
*Acceleration_Mode_l = 3U; |
|
111 |
|
|
112 |
/* Inport: '/Set_Speed' incorporates: |
|
113 |
* Inport: '/Set_Gap' |
|
114 |
* Inport: '/Time_Gap' |
|
115 |
*/ |
|
116 |
if ((DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && |
|
117 |
(Time_Gap >= Set_Gap)) { |
|
118 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PROJECT_IN_LeadVehicle_Detected; |
|
119 |
*Acceleration_Mode_l = 2U; |
|
120 |
} else if (LeadVehicle_Detected == 0) { |
|
121 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Not_Detected_Res; |
|
122 |
*Acceleration_Mode_l = 1U; |
|
123 |
} else { |
|
124 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_equal_Set_; |
|
125 |
*Acceleration_Mode_l = 5U; |
|
126 |
} |
|
127 |
break; |
|
128 |
|
|
129 |
case PRO_IN_LeadVehicle_NOT_Detected: |
|
130 |
*Acceleration_Mode_l = 1U; |
|
131 |
|
|
132 |
/* Inport: '/Set_Speed' incorporates: |
|
133 |
* Inport: '/Set_Gap' |
|
134 |
* Inport: '/Time_Gap' |
|
135 |
*/ |
|
136 |
if ((LeadVehicle_Detected == 1) && (DriveVehicle_Speed == Set_Speed) && |
|
137 |
(LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)) { |
|
138 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PROJECT_IN_LeadVehicle_Detected; |
|
139 |
*Acceleration_Mode_l = 2U; |
|
140 |
} else { |
|
141 |
if (((LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set> |
|
142 |
(Time_Gap < Set>{ |
|
143 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_lessthan_S; |
|
144 |
*Acceleration_Mode_l = 4U; |
|
145 |
} |
|
146 |
} |
|
147 |
break; |
|
148 |
|
|
149 |
case IN_LeadVehicle_Not_Detected_Res: |
|
150 |
*Acceleration_Mode_l = 1U; |
|
151 |
break; |
|
152 |
|
|
153 |
case IN_LeadVehicle_Speed_equal_Set_: |
|
154 |
*Acceleration_Mode_l = 5U; |
|
155 |
|
|
156 |
/* Inport: '/Set_Speed' incorporates: |
|
157 |
* Inport: '/Set_Gap' |
|
158 |
* Inport: '/Time_Gap' |
|
159 |
*/ |
|
160 |
if (((DriveVehicle_Speed < Set> |
|
161 |
DriveVehicle_Speed)) || (Time_Gap >= Set_Gap)) { |
|
162 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Detected_Resume; |
|
163 |
*Acceleration_Mode_l = 3U; |
|
164 |
} else if ((LeadVehicle_Detected == 0) || (DriveVehicle_Speed <= Set_Speed)) |
|
165 |
{ |
|
166 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Not_Detected_Res; |
|
167 |
*Acceleration_Mode_l = 1U; |
|
168 |
} else { |
|
169 |
if (((LeadVehicle_Speed < Set> |
|
170 |
DriveVehicle_Speed)) || ((uint8_T)(int32_T)rt_roundd_snf(0.75 * |
|
171 |
(real_T)Set_Gap) == Time_Gap)) { |
|
172 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_lessthan_S; |
|
173 |
*Acceleration_Mode_l = 4U; |
|
174 |
} |
|
175 |
} |
|
176 |
break; |
|
177 |
|
|
178 |
default: |
|
179 |
*Acceleration_Mode_l = 4U; |
|
180 |
|
|
181 |
/* Inport: '/Set_Speed' */ |
|
182 |
if ((LeadVehicle_Detected == 0) && (DriveVehicle_Speed == Set_Speed)) { |
|
183 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PRO_IN_LeadVehicle_NOT_Detected; |
|
184 |
*Acceleration_Mode_l = 1U; |
|
185 |
} else { |
|
186 |
tmp = (int32_T)rt_roundd_snf((real_T)LeadVehicle_Speed * 1.25); |
|
187 |
|
|
188 |
/* Inport: '/Set_Gap' */ |
|
189 |
tmp_0 = (int32_T)rt_roundd_snf(1.25 * (real_T)Set_Gap); |
|
190 |
if (tmp < 256>{ |
|
191 |
tmp_1 = (uint8_T)tmp; |
|
192 |
} else { |
|
193 |
tmp_1 = MAX_uint8_T; |
|
194 |
} |
|
195 |
|
|
196 |
if (tmp_0 < 256>{ |
|
197 |
tmp_2 = (uint8_T)tmp_0; |
|
198 |
} else { |
|
199 |
tmp_2 = MAX_uint8_T; |
|
200 |
} |
|
201 |
|
|
202 |
/* Inport: '/Time_Gap' incorporates: |
|
203 |
* Inport: '/Set_Gap' |
|
204 |
*/ |
|
205 |
if ((tmp_1 >= DriveVehicle_Speed) && ((uint8_T)(int32_T)rt_roundd_snf |
|
206 |
((real_T)LeadVehicle_Speed * 0.75) <= DriveVehicle_Speed) && |
|
207 |
(DriveVehicle_Speed < Set xss=removed> |
|
208 |
>= (uint8_T)(int32_T)rt_roundd_snf(0.75 * (real_T)Set_Gap))) { |
|
209 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = IN_LeadVehicle_Speed_equal_Set_; |
|
210 |
*Acceleration_Mode_l = 5U; |
|
211 |
} |
|
212 |
} |
|
213 |
break; |
|
214 |
} |
|
215 |
} |
|
216 |
|
|
217 |
/* End of Inport: '/SetSwitch' */ |
|
218 |
} |
|
219 |
|
|
220 |
/* Model step function */ |
|
221 |
void PROJECT2Adaptive_step(void) |
|
222 |
{ |
|
223 |
/* Sum: '/Add' incorporates: |
|
224 |
* Inport: '/CameraInput_LeadVehicle' |
|
225 |
* Inport: '/RadarInput_LeadVehicle' |
|
226 |
*/ |
|
227 |
LeadVehicle_Speed = (uint8_T)((uint32_T) |
|
228 |
PROJECT2Adaptive_U.CameraInput_LeadVehicle + |
|
229 |
PROJECT2Adaptive_U.RadarInput_LeadVehicle); |
|
230 |
|
|
231 |
/* SignalConversion: '/Signal Conversion' incorporates: |
|
232 |
* Inport: '/RadarInput_DriveVehicle' |
|
233 |
*/ |
|
234 |
LeadVehicle_Detected = RadarInput_DriveVehicle; |
|
235 |
|
|
236 |
/* UnitDelay: '/Unit Delay' */ |
|
237 |
Acceleration_Mode = PROJECT2Adaptive_DW.UnitDelay_DSTATE; |
|
238 |
|
|
239 |
/* Sum: '/Sum' incorporates: |
|
240 |
* Inport: '/CameraInput_DriveVehicle' |
|
241 |
* Inport: '/RadarInput_DriveVehicle' |
|
242 |
*/ |
|
243 |
DriveVehicle_Speed = (uint8_T)((uint32_T)(uint8_T)((uint32_T) |
|
244 |
CameraInput_DriveVehicle + Acceleration_Mode) + RadarInput_DriveVehicle); |
|
245 |
|
|
246 |
/* Chart: '/Chart' incorporates: |
|
247 |
* Inport: '/CruiseSwitch' |
|
248 |
* Inport: '/SetSwitch' |
|
249 |
*/ |
|
250 |
if (PROJECT2Adaptive_DW.is_active_c3_PROJECT2Adaptive == 0U) { |
|
251 |
PROJECT2Adaptive_DW.is_active_c3_PROJECT2Adaptive = 1U; |
|
252 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = PROJECT2Adaptiv_IN_ACC_OFF_mode; |
|
253 |
|
|
254 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
255 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 0U; |
|
256 |
} else { |
|
257 |
switch (PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive) { |
|
258 |
case PROJECT2Adaptiv_IN_ACC_OFF_mode: |
|
259 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
260 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 0U; |
|
261 |
if (CruiseSwitch) { |
|
262 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = |
|
263 |
PROJECT2Ada_IN_ACC_STANDBY_mode; |
|
264 |
|
|
265 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
266 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 1U; |
|
267 |
} |
|
268 |
break; |
|
269 |
|
|
270 |
case PROJECT2Adaptive_IN_ACC_ON_MODE: |
|
271 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
272 |
PROJECT2Adaptive_ACC_ON_MODE(&PROJECT2Adaptive_DW.UnitDelay_DSTATE); |
|
273 |
break; |
|
274 |
|
|
275 |
default: |
|
276 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
277 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 1U; |
|
278 |
if (!CruiseSwitch) { |
|
279 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = |
|
280 |
PROJECT2Adaptiv_IN_ACC_OFF_mode; |
|
281 |
|
|
282 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
283 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 0U; |
|
284 |
} else { |
|
285 |
if (SetSwitch) { |
|
286 |
PROJECT2Adaptive_DW.is_c3_PROJECT2Adaptive = |
|
287 |
PROJECT2Adaptive_IN_ACC_ON_MODE; |
|
288 |
PROJECT2Adaptive_DW.is_ACC_ON_MODE = PROJECT_IN_LeadVehicle_Detected; |
|
289 |
|
|
290 |
/* Update for UnitDelay: '/Unit Delay' */ |
|
291 |
PROJECT2Adaptive_DW.UnitDelay_DSTATE = 2U; |
|
292 |
} |
|
293 |
} |
|
294 |
break; |
|
295 |
} |
|
296 |
} |
|
297 |
|
|
298 |
/* End of Chart: '/Chart' */ |
|
299 |
} |
|
300 |
|
|
301 |
/* Model initialize function */ |
|
302 |
void PROJECT2Adaptive_initialize(void) |
|
303 |
{ |
|
304 |
/* (no initialization code required) */ |
|
305 |
} |
|
306 |
|
|
307 |
/* Model terminate function */ |
|
308 |
void PROJECT2Adaptive_terminate(void) |
|
309 |
{ |
|
310 |
/* (no terminate code required) */ |
|
311 |
} |
|
312 |
|
|
313 |
/* |
|
314 |
* File trailer for generated code. |
|
315 |
* |
|
316 |
* [EOF] |
|
317 |
*/ |
|
318 |
Result
After implementing the ACC model run the simulation. If the model is running successfully without any errors then the Adaptive Cruise Control is works as per the requirement.
- The model is running successfully without any error