Project 2 Adaptive Cruise Control
Aim:
Aim of this project is to created a adaptive cruise control fueature as per the requirement given. Basically cruise control is speed control according to lead vechicle
Description:
i,created a subsytem and added input to the subsystem as like the subsytem
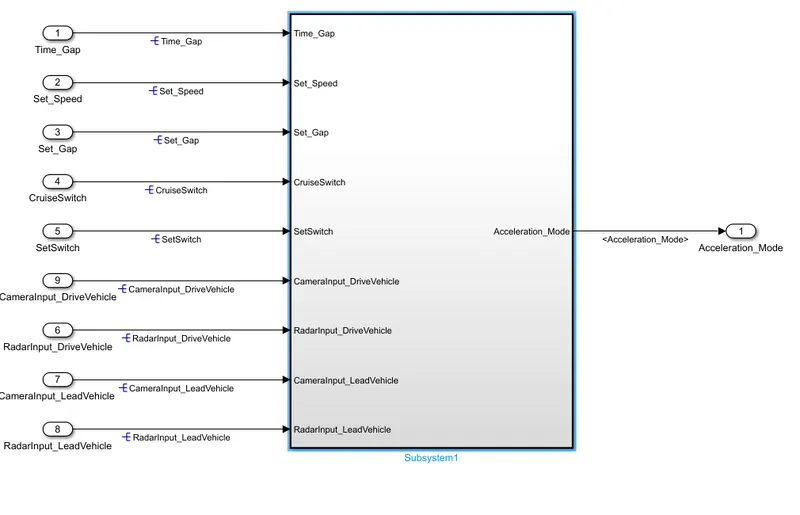
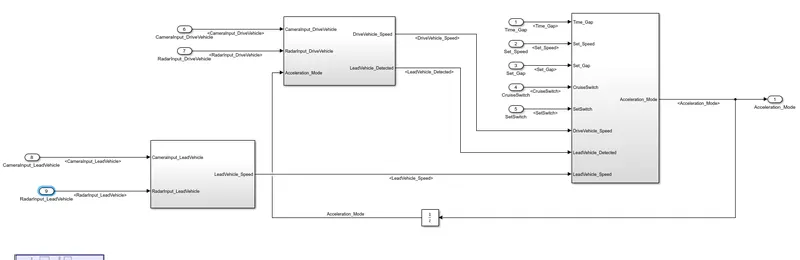
ii, inside the subsystem 1 developed with the reqirement and the signal are propagated and resolving the signal
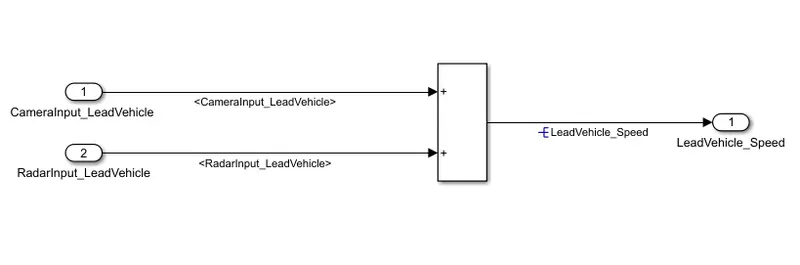
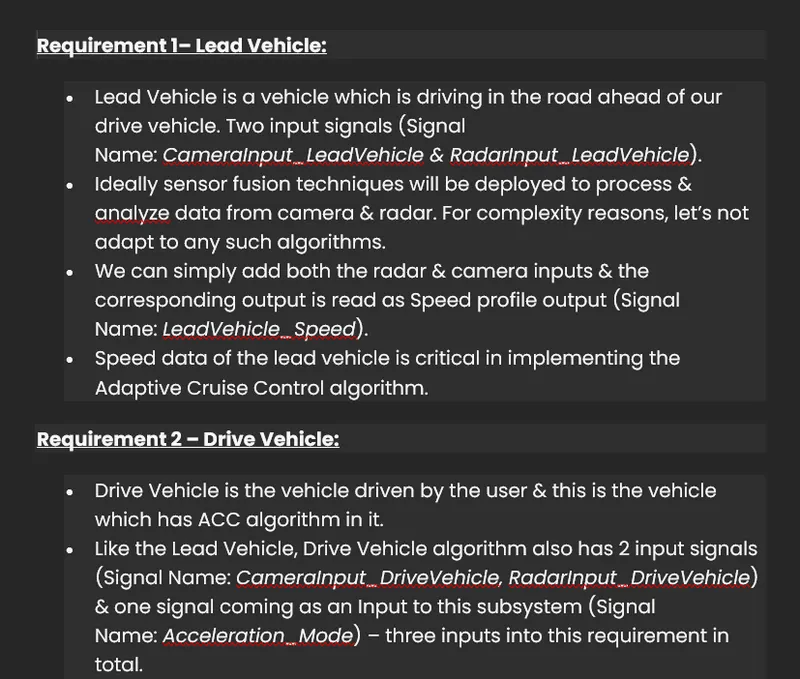
The camera input lead vehicle and radar inpur lead vehicle get added and form lead vehicle speed
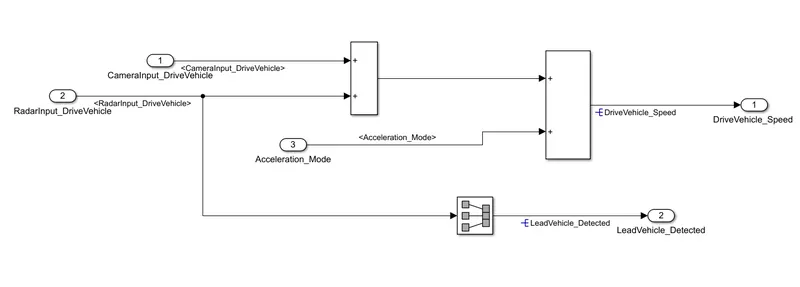
iii, second subsytem is we get input of camera input drive vehicle and radar input drive vehicle are get added and the result of the both and accelaration mode get added and drive vehicle speed is formed. the radar input drive vehicle is converted using signal editor and that signal is called lead vehicle detected
iv, inside subsystem 3 created a chart. and made input and output ports
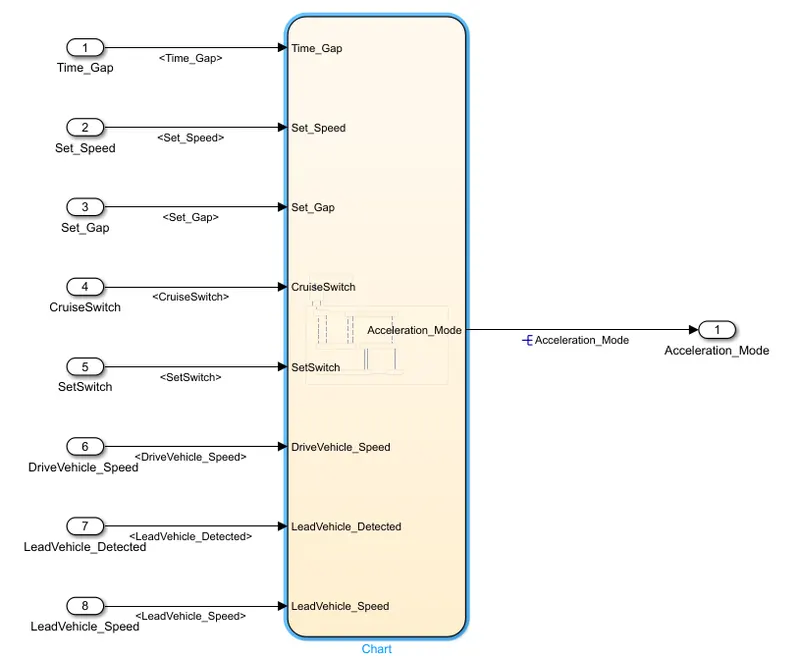
created blocks and transition lines and condition to the transition lines according to the requirement
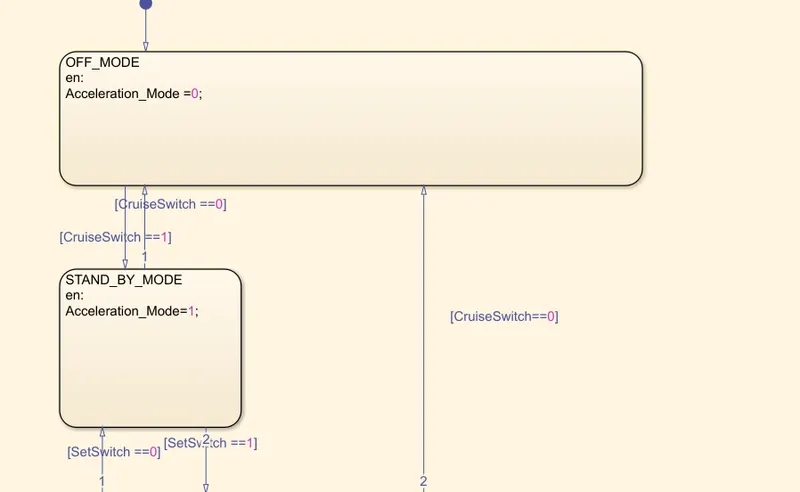
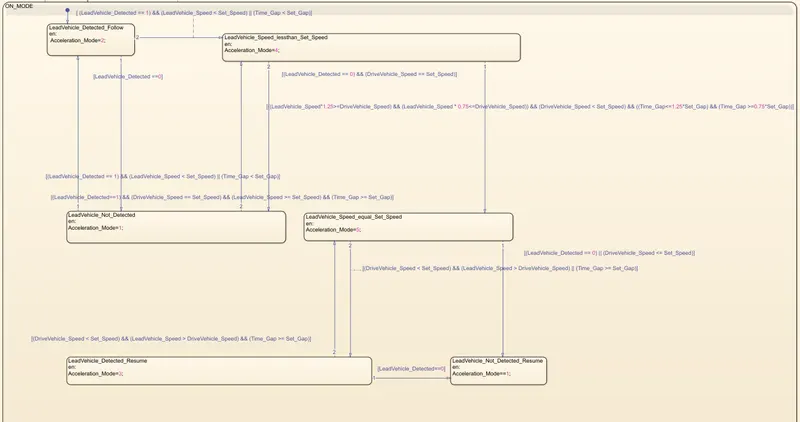
iv,Inside the subsytem created three subsystem as per the reuirements and connected with input and output ports
the output of subsystem 2 are connected to the input of subsystem 3. and the output of subsytem 1 is input of subsystem3.
The output from the subsytem 3 is given to the input of subsytem 2 as a feedback. because by this only can calculate the acceleration of the vehicle.
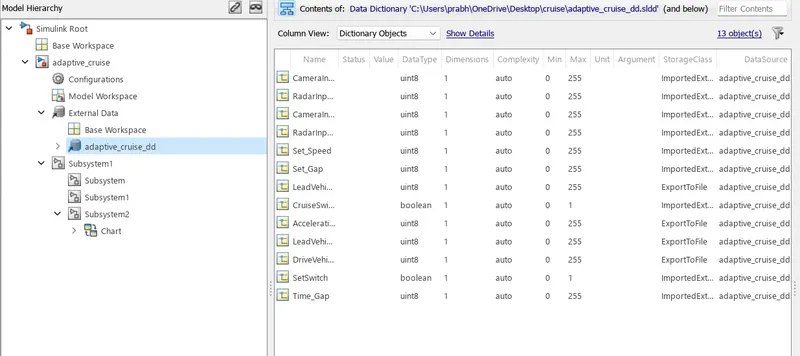
v,created the sldd file (dictionary)
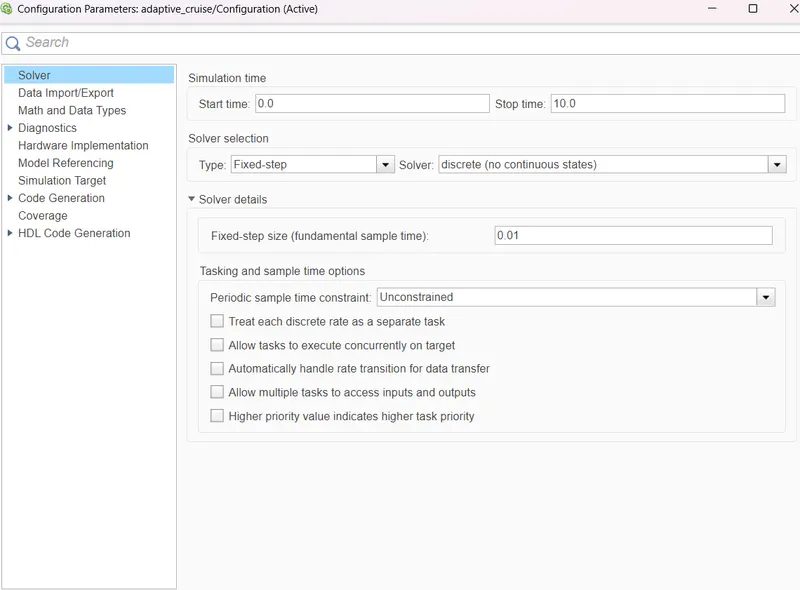
vi, done the configuration setting solver type want to be fixed and discrete
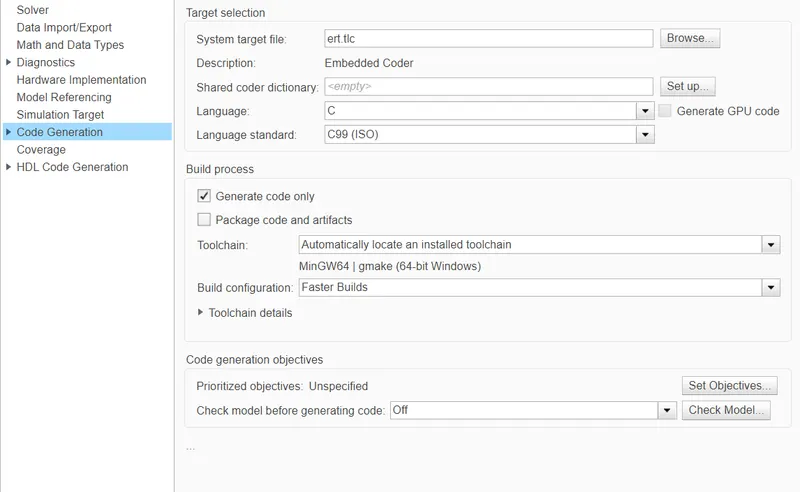
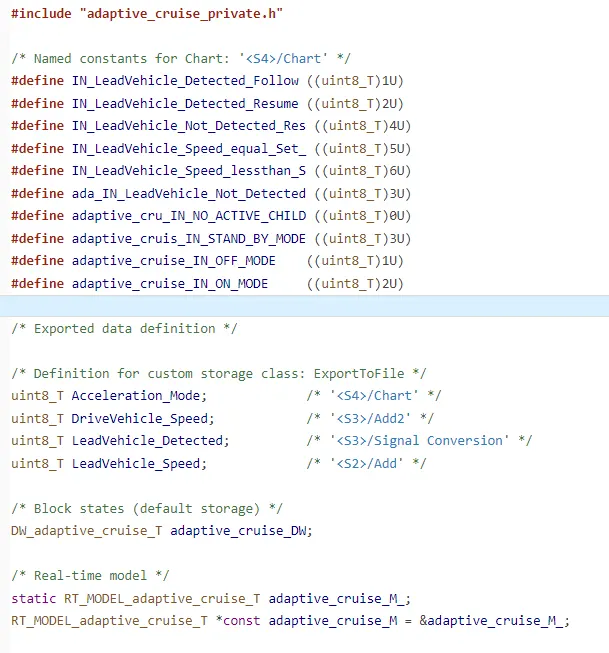
code generation setting is ert.tlc
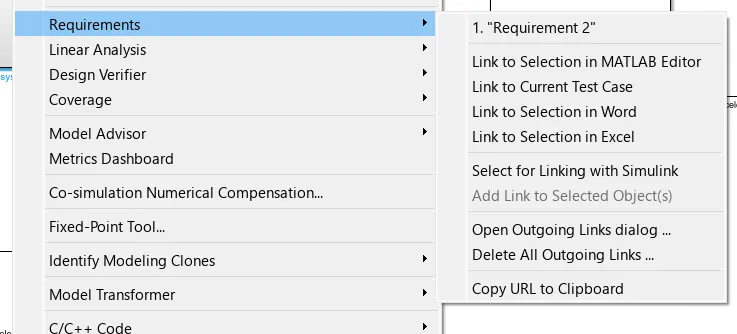
vii,created a requirement documet and done requirement tagging
viii,model report
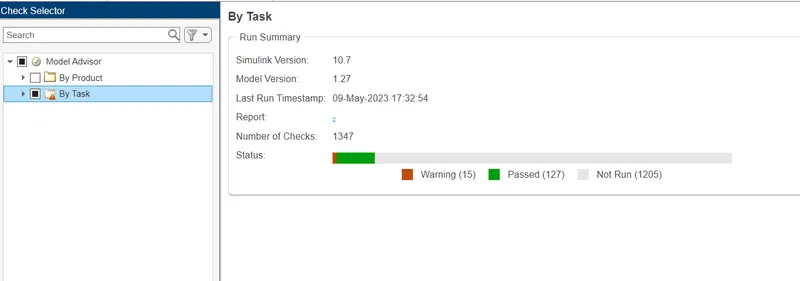
ix, generated code
Result:
The model is done as per the requirement and ran sucessfully