Project 2 Adaptive Cruise Control
Aim: -
- To Build a Simulink model as per the requirement document and create requirements tagging.
- To check a model under standard guidelines with help of a model adviser. (MABB guidelines)
- To build an embedded code for the model.
Objective: -
- Developing Adaptive Cruise Control feature as per the Requirement Document using MATLAB Simulink.
- Follow all the MBD related processes: Requirement Tagging & Traceability, SLDD creation, Configuration Parameter changes, Model Advisor check & Code Generation.
- In Configuration Parameters: enable “Support Floating Numbers” under Code Generation settings.
- Use Embedded Coder to generate the code.
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Const.
- Choose sample time for all signals as 0.01s
Theory: -
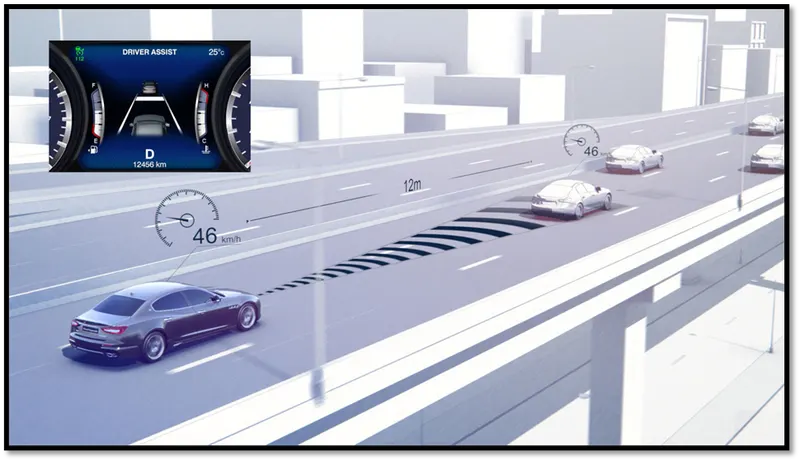
Adaptive cruise control (ACC) is an available cruise control advanced driver-assistance system for road vehicles that automatically adjusts the vehicle speed to maintain a safe distance from vehicles ahead. As of 2019, it is also called by 20 unique names that describe that basic functionality. This is also known as Dynamic cruise control.
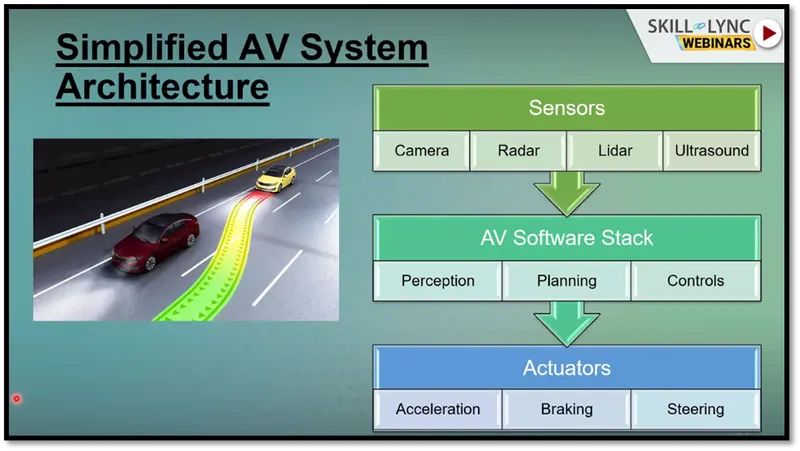
Control is based on sensor information from onboard sensors. Such systems may use a radar or laser sensor or a camera setup allowing the vehicle to brake when it detects the car is approaching another vehicle ahead, then accelerate when traffic allows it to.
Simulink Model: -
Requirement 1– Lead Vehicle:
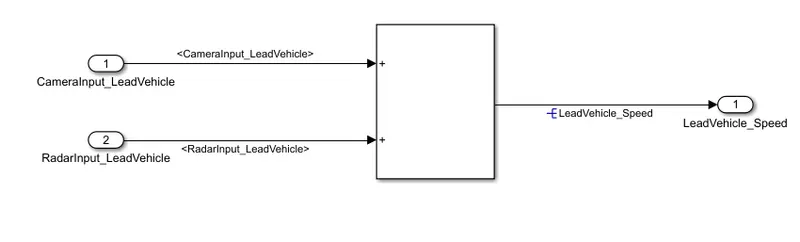
1. Lead Vehicle is a vehicle which is driving in the road ahead of our drive vehicle. Two input signals (Signal Name: CameraInput_LeadVehicle & RadarInput_LeadVehicle).
2.Ideally sensor fusion techniques will be deployed to process & analyze data from camera & radar. For complexity reasons, let’s not adapt to any such algorithms.
3.We can simply add both the radar & camera inputs & the corresponding output is read as Speed profile output (Signal Name: LeadVehicle_Speed).
4.Speed data of the lead vehicle is critical in implementing the Adaptive Cruise Control algorithm.
Requirement 2 – Drive Vehicle:
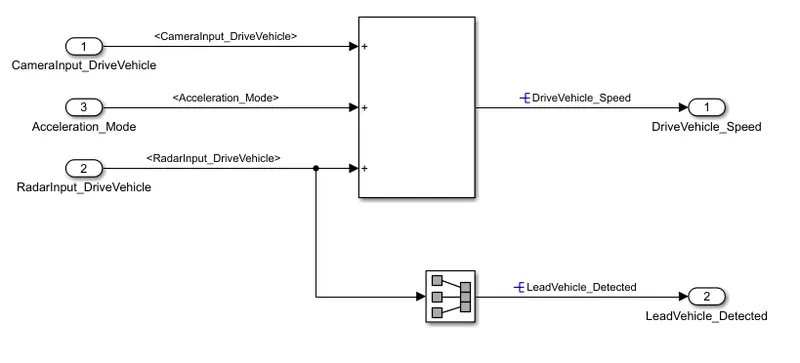
- Drive Vehicle is the vehicle driven by the user & this is the vehicle which has ACC algorithm in it.
- Like the Lead Vehicle, Drive Vehicle algorithm also has 2 input signals (Signal Name: CameraInput_DriveVehicle, RadarInput_DriveVehicle) & one signal coming as an Input to this subsystem (Signal Name: Acceleration_Mode) – three inputs into this requirement in total.
- Like the above requirement, sensor fusion techniques will also be deployed here, for complexity reasons we are ignoring them.
- Two output signals come from this subsystem (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected).
- Signal DriveVehicle_Speed is summation of three input signals mentioned above & LeadVehicle_Detected is renamed from Input Signal RadarInput_DriveVehicle by mere use of Signal Conversion block.
Requirement 3 – Adaptive Cruise Control Algorithm: -
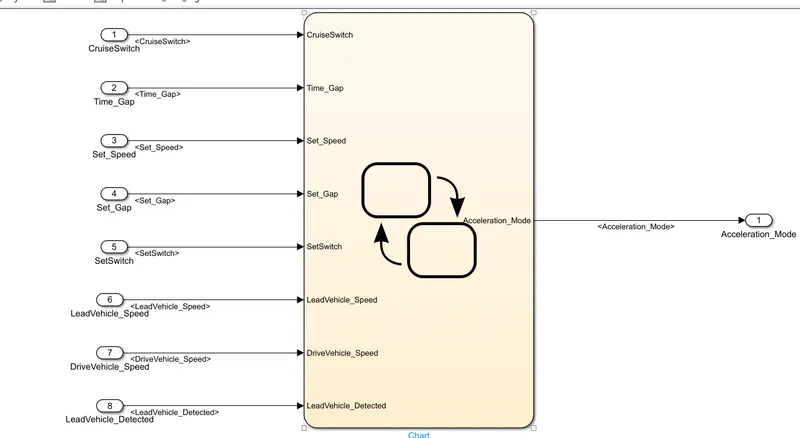
- Adaptive Cruise Control feature has 3 major modes of operation: OFF Mode, STANDBY Mode & ON Mode. This particular requirement has to be implemented as state machine logic in Simulink.
- The input signals to this state machine system are (Signal Name: Time_Gap, Set_Speed, Set_Gap, CruiseSwitch, SetSwitch).
- Also, the output signals (Signal Name: DriveVehicle_Speed & LeadVehicle_Detected) from requirement-2 is fed back as an input signal into this state machine block.
- Additionally, output signal (Signal Name: LeadVehicle_Speed) from requirement-1 is given as an input signal to this state machine block as well.
- Output from this subsystem is a signal (Signal Name: Acceleration_Mode) which governs the vehicular speed of the drive vehicle which automatically adjusts its speed & velocity to match the lead vehicle.
-
- Requirement 3a – ACC OFF MODE state logic: -
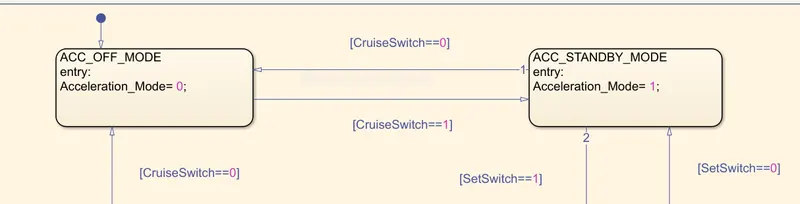
- This is the default state inside state machine logic. Output signal Acceleration_Mode is at value 0 in this state.
- This state is governed by input signal CruiseSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
Requirement 3b – ACC STANDBY MODE state logic: -
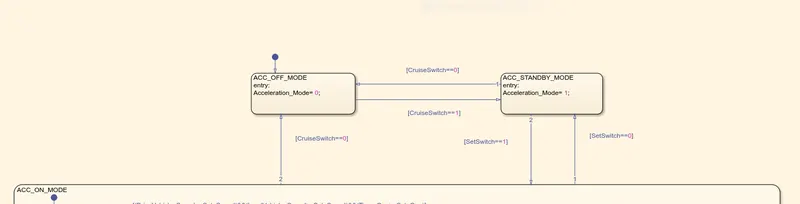
- This is the second activated state inside state machine logic. Output signal Acceleration_Mode is at value 1 in this state.
- This state is governed by both input signals CruiseSwitch & SetSwitch.
- If CruiseSwitch is equal to 1, state ACC STANDBY mode will get activated. If CruiseSwitch is equal to 0, state ACC OFF mode will get activated, from either ACC ON mode or ACC STANDBY mode
- If SetSwitch is equal to 1, state ACC ON mode will get activated. If SetSwitch is equal to 0, state ACC STANDBY mode will get activated.
Requirement 3c – ACC ON MODE state logic: -
This state will be activated when input signal SetSwitch is equal to 1. There are 6 sub states to this state logic:
They are: -
- LeadVehicle_Detected_Follow (Default)
- LeadVehicle_Not_Detected
- LeadVehicle_Detected_Resume
- LeadVehicle_Not_Detected_Resume
- LeadVehicle_Speed_lessthan_Set_Speed
- LeadVehicle_Speed_equal_Set_Speed
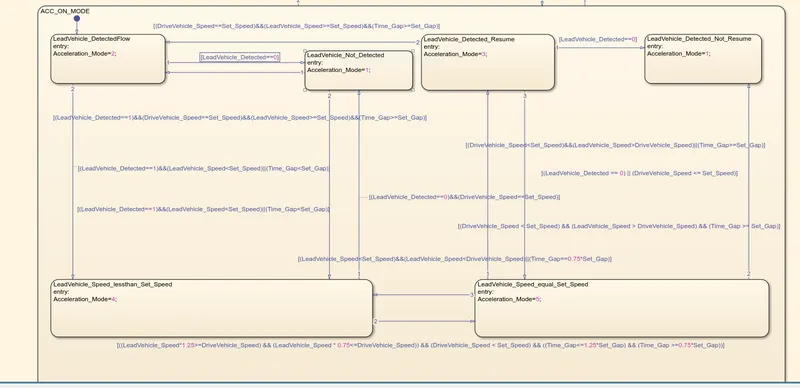
- Requirement 3c (i) – LeadVehicle_Detected_Follow (ACC ON MODE): -
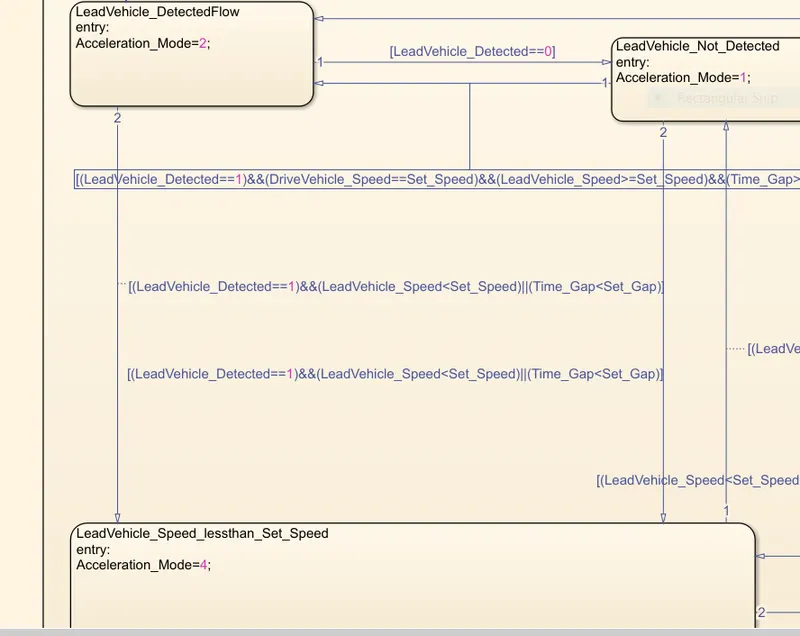
- This is the default sub state inside ACC ON MODE state. Output signal Acceleration_Mode is equal to 2.
- Condition to transit from LeadVehicle_Detected_Follow to LeadVehicle_Not_Detected; Input signal condition LeadVehicle_Detected == 0.
- Condition to transit from LeadVehicle_Detected_Follow to LeadVehicle_Speed_lessthan_Set_Speed; Input Signals condition (LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap).
Requirement 3c (ii) – LeadVehicle_Not_Detected (ACC ON MODE): -
- Output signal Acceleration_Mode is equal to 1.
- Condition to transit from LeadVehicle_Not_Detected to LeadVehicle_Detected_Follow; Input signals condition [(LeadVehicle_Detected==1) && (DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Not_Detected to LeadVehicle_Speed_lessthan_Set_Speed; Input signals condition [(LeadVehicle_Detected == 1) && (LeadVehicle_Speed < Set_Speed) || (Time_Gap < Set_Gap)]
Requirement 3c (iii) – LeadVehicle_Detected_Resume (ACC ON MODE): -
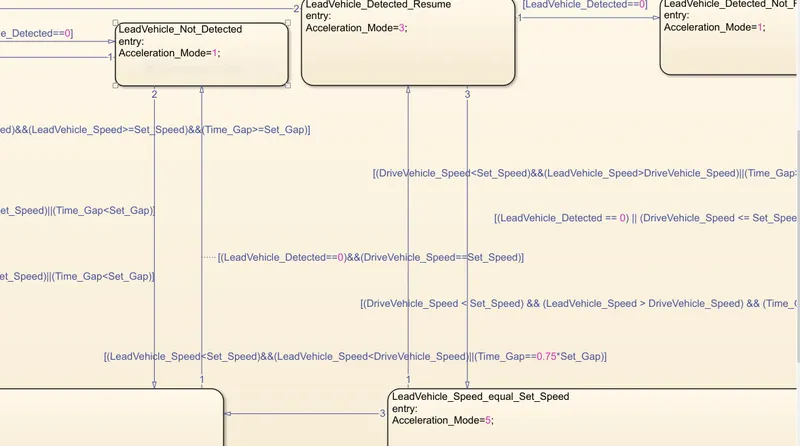
- Output signal Acceleration_Mode is equal to 3.
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Detected_Follow; Input signals condition [(DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Not_Detected_Resume; Input signal condition LeadVehicle_Detected==0.
- Condition to transit from LeadVehicle_Detected_Resume to LeadVehicle_Speed_equal_Set_Speed; Input Signal condition [(DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) && (Time_Gap >= Set_Gap)]
Requirement 3c (iv) - LeadVehicle_Not_Detected_Resume (ACC ON MODE): -
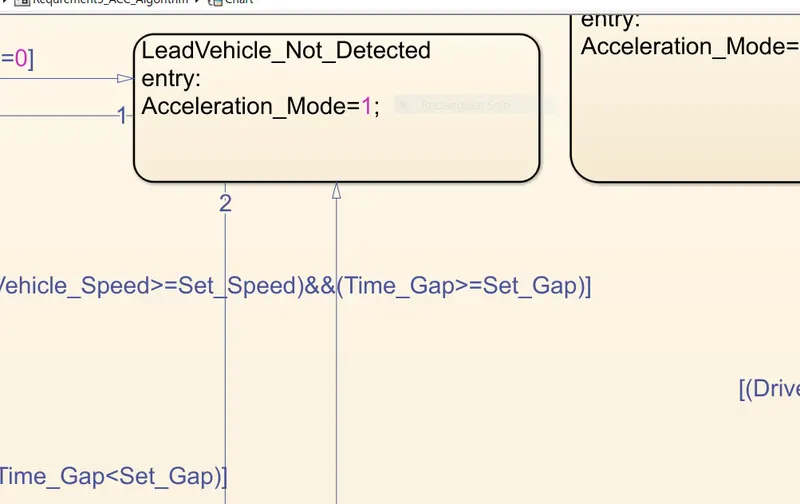
- Output signal Acceleration_Mode is equal to 1.
Requirement 3c (v) - LeadVehicle_Speed_lessthan_Set_Speed (ACC ON MODE): -
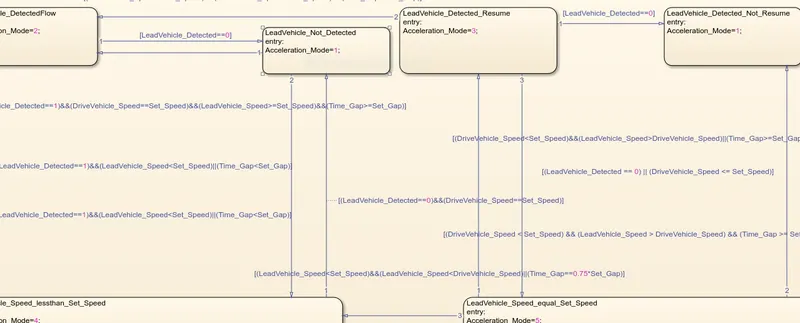
- Output signal Acceleration_Mode is equal to 4.
- Condition to transit from LeadVehicle_Speed_lessthan_Set_Speed to LeadVehicle_Not_Detected; Input signal condition [(LeadVehicle_Detected == 0) && (DriveVehicle_Speed == Set_Speed)]
- Condition to transit from LeadVehicle_Speed_lessthan_Set_Speed to LeadVehicle_Speed_equal_Set_Speed; Input signals condition [((LeadVehicle_Speed*1.25>=DriveVehicle_Speed) && (LeadVehicle_Speed * 0.75<=DriveVehicle_Speed)) && (DriveVehicle_Speed < Set_Speed) && ((Time_Gap<=1.25*Set_Gap) && (Time_Gap >=0.75*Set_Gap))]
Requirement 3c (vi) - LeadVehicle_Speed_equal_Set_Speed (ACC ON MODE): -
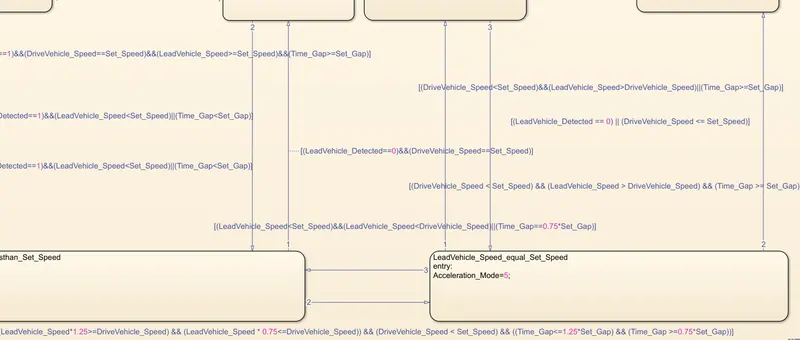
- Output signal Acceleration_Mode is equal to 5.
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Not_Detected_Resume; Input signal conditions is [(LeadVehicle_Detected == 0) || (DriveVehicle_Speed <= Set_Speed)]
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Detected_Resume; Input signal conditions [(DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed > DriveVehicle_Speed) || (Time_Gap >= Set_Gap)]
- Condition to transit from LeadVehicle_Speed_equal_Set_Speed to LeadVehicle_Speed_lessthan_Set_Speed; Input signals conditions [(LeadVehicle_Speed< Set_Speed) && (LeadVehicle_Speed
ADCC model subsystem: -
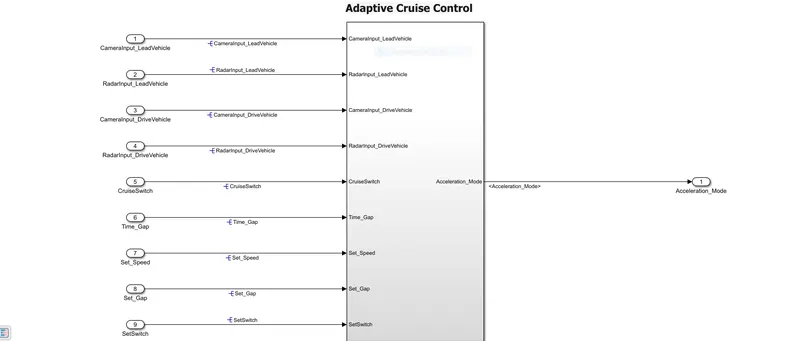
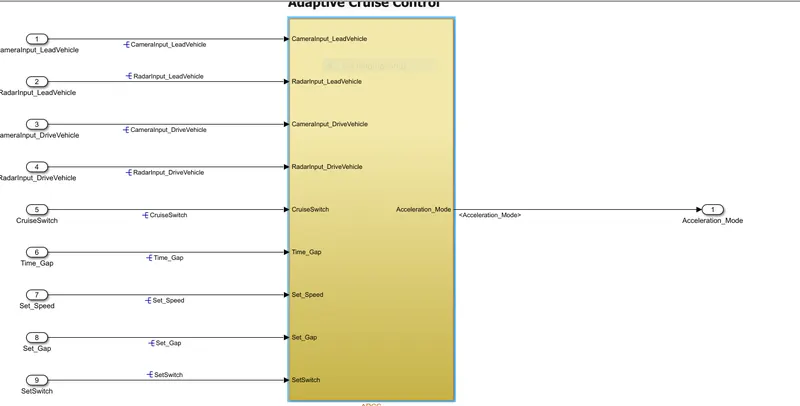
- Created an ACC model subsystem for code generation.
- for all requirements I created on subsystem and connected the inport and outport to respected signal.
SLDD file Creation: -
- Signals & Calibration Data List: -
Signal / Calibration Name
Signal Type
Data Type
Dimension
Min
Max
Initial Value
Units
CameraInput_LeadVehicle
Input
Uint8
1
0
255
-
-
RadarInput_LeadVehicle
Input
Uint8
1
0
255
-
-
CameraInput_DriveVehicle
Input
Uint8
1
0
255
-
-
RadarInput_DriveVehicle
Input
Uint8
1
0
255
-
-
Time_Gap
Input
Uint8
1
0
255
-
-
Set_Speed
Input
Uint8
1
0
255
-
-
Set_Gap
Input
Uint8
1
0
255
-
-
CruiseSwitch
Input
Boolean
1
0
1
-
-
SetSwitch
Input
Boolean
1
0
1
-
-
Acceleration_Mode
Output
Uint8
1
0
255
-
-
LeadVehicle_Speed
Output
Uint8
1
0
255
-
-
DriveVehicle_Speed
Output
Uint8
1
0
255
-
-
LeadVehicle_Detected
Output
Uint8
1
0
255
-
-
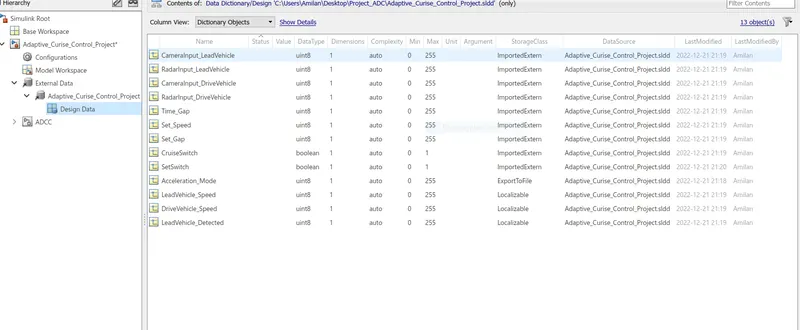
1. To create an SLDD file under modelling tan in the design section there is one option link data dictionary. Click on that tab.
2.The new window will open in that window click on new to create a new file and create new file save this file in the same directory.
3. Now open this file and add all given signals and constant with all parameters.
4. If you see it here, we can edit and save all parameters under one file.5. No need to change parameter every time you open the model next time.
6. Once you save all parameters for variable in SLDD it will be saved until you use the file for model.
7. also, you can use one SLDD file for more than one model.
Signal resolve and propagation: -
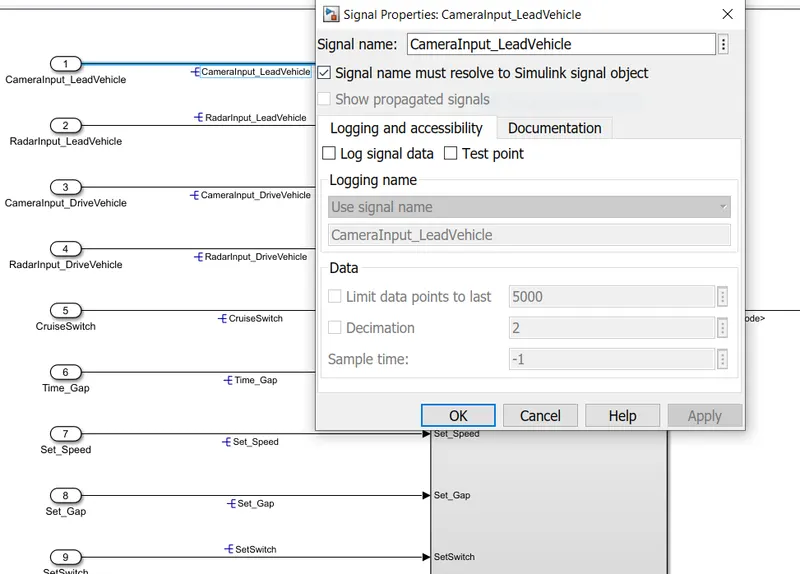
- In signal properties you can resolve and propagate the signal.
- If the signal is the first type appear in system you have to resolve at otherwise propagate it.
- Signal resolve and propagation is most important for code generation.
- You can propagate the signal directly on double click on signal and type (<>) only. Signal will propagate directly.
Requirement tagging: -
- Requirement tagging is nothing but linking your requirement document to the model subsystem which is related to that requirement.
- It is given advantage to understand the model when someone new is handling this file.
- We done requirement tagging on right click on subsystem under requirement parameter you can tag the requirement.
- First you have to select the requirement in requirement document to tag with related subsystem. Also, the file has to be saved in the same directory.
MAAB guideline check: - (model advisor)
1. Under the modelling tab there is a model adviser tab to check model with standard guidelines.
2. Tab on that tab this window will open to select model.
3. After selecting the model, the model adviser checked for the model first.
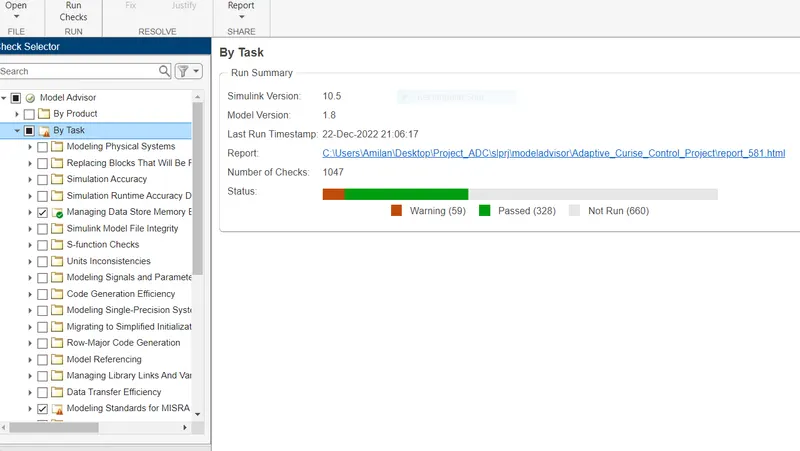
4. Then in the task option we have to select modelling standard for MAB. Then we have to select which guidelines we have to check.
5. Then run adviser check for selected checked guidelines.
6. If some errors occur you can check for that under the MAB tab.
7. There are also some warnings. if its greater than requirement solve the warning and check again for that warning.
8. You can check for individual errors and warnings also.
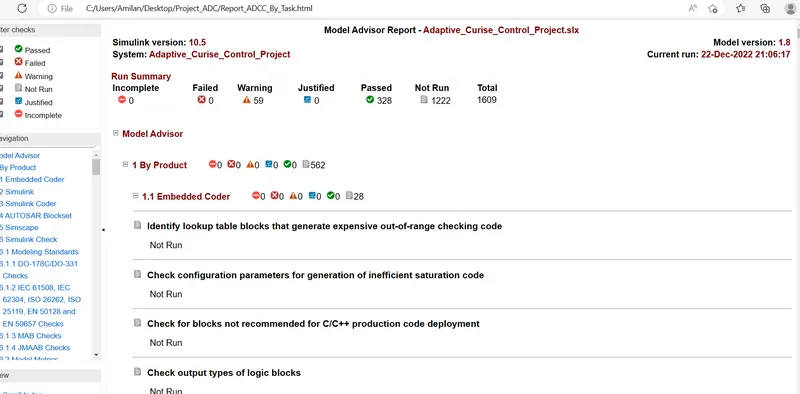
9. If you are searching for a particular block in the system. You can click in report on any block it will take you to that block.
10. After checking model with standard guidelines, you can generate a model adviser report. 11. If click on any label highlighted in the report it will go directly to that particular model or signal.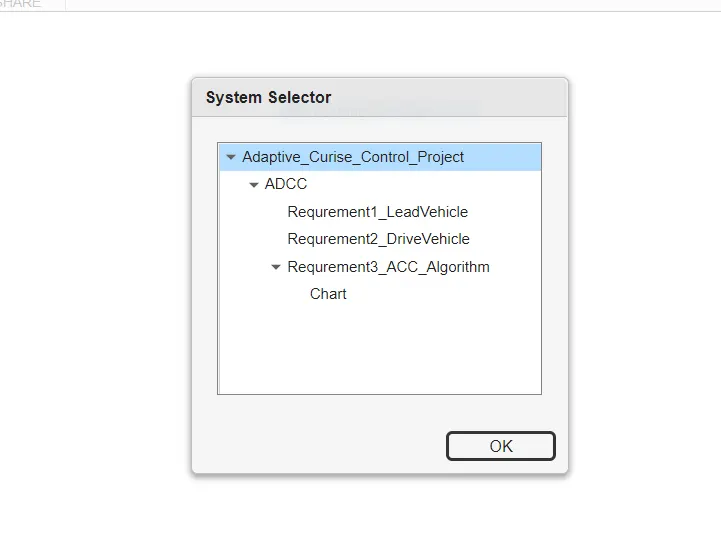
Code generation settings: -
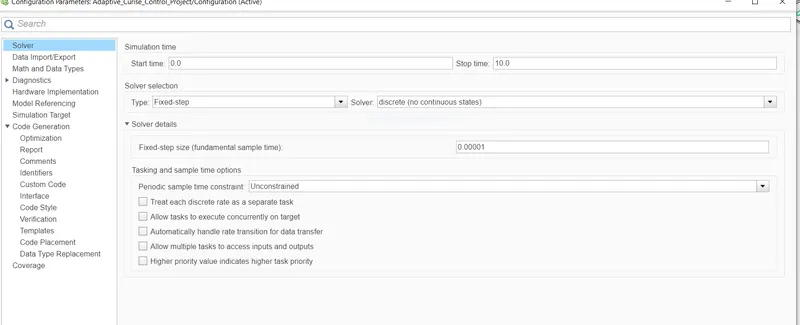
- There are mainly two settings we have to do which are solver setting and code generation setting.
- For code generation we can only use a fixed step solver.
- As per requirement we change the solver setting to fix step discrete and fixed step time as 0.01 sec.
- For embedded code generation in system target file will always ert.tlc which is embedded coder. Which generates embedded c code.
- In the interface setting support for floating point number will checked as per requirement.
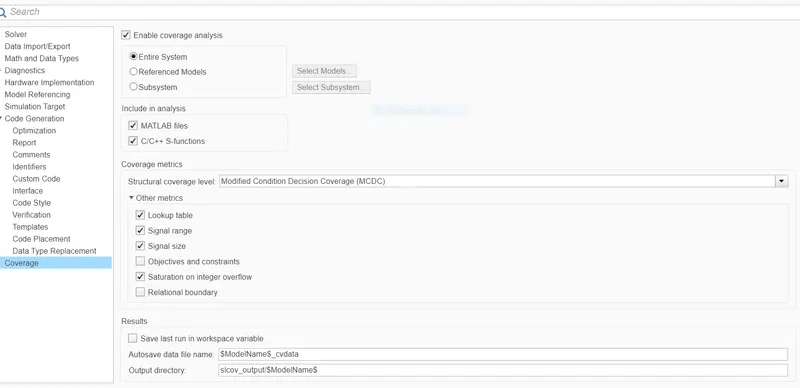
- Also, I had tried coverage for model to check execution.
Code generation steps: -
1. It is a simple step if your model has no error according to MAAB guidelines then you are good to go for code generation.
2. In the tool bar under the app section there is embedded coder option.
3. In that option the build code option is there. Once click on that tab your code will generate.
4. You can view your c code in view code tab on tool bar under code section.
code file: -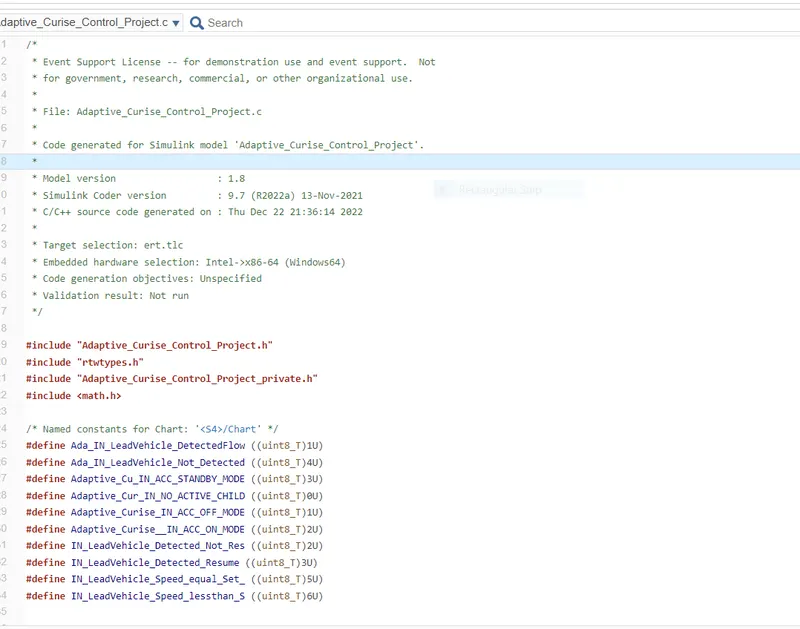 /** Event Support License -- for demonstration use and event support. Not* for government, research, commercial, or other organizational use.** File: Adaptive_Curise_Control_Project.c** Code generated for Simulink model 'Adaptive_Curise_Control_Project'.** Model version : 1.8* Simulink Coder version : 9.7 (R2022a) 13-Nov-2021* C/C++ source code generated on : Thu Dec 22 21:36:14 2022** Target selection: ert.tlc* Embedded hardware selection: Intel->x86-64 (Windows64)* Code generation objectives: Unspecified* Validation result: Not run*/#include "Adaptive_Curise_Control_Project.h"#include "rtwtypes.h"#include "Adaptive_Curise_Control_Project_private.h"#include/* Named constants for Chart: '
/Chart' */ #define Ada_IN_LeadVehicle_DetectedFlow ((uint8_T)1U)#define Ada_IN_LeadVehicle_Not_Detected ((uint8_T)4U)#define Adaptive_Cu_IN_ACC_STANDBY_MODE ((uint8_T)3U)#define Adaptive_Cur_IN_NO_ACTIVE_CHILD ((uint8_T)0U)#define Adaptive_Curise_IN_ACC_OFF_MODE ((uint8_T)1U)#define Adaptive_Curise__IN_ACC_ON_MODE ((uint8_T)2U)#define IN_LeadVehicle_Detected_Not_Res ((uint8_T)2U)#define IN_LeadVehicle_Detected_Resume ((uint8_T)3U)#define IN_LeadVehicle_Speed_equal_Set_ ((uint8_T)5U)#define IN_LeadVehicle_Speed_lessthan_S ((uint8_T)6U)/* Exported data definition *//* Definition for custom storage class: ExportToFile */uint8_T Acceleration_Mode; /* '/Unit Delay' */ /* Block states (default storage) */DW_Adaptive_Curise_Control_Pr_T Adaptive_Curise_Control_Proj_DW;/* External outputs (root outports fed by signals with default storage) */ExtY_Adaptive_Curise_Control__T Adaptive_Curise_Control_Proje_Y;/* Real-time model */static RT_MODEL_Adaptive_Curise_Cont_T Adaptive_Curise_Control_Proj_M_;RT_MODEL_Adaptive_Curise_Cont_T *const Adaptive_Curise_Control_Proj_M =&Adaptive_Curise_Control_Proj_M_;real_T rt_roundd_snf(real_T u){real_T y;if (fabs(u) < 4.503599627370496E+15) {if (u >= 0.5) {y = floor(u + 0.5);} else if (u > -0.5) {y = u * 0.0;} else {y = ceil(u - 0.5);}} else {y = u;}return y;}/* Model step function */void Adaptive_Curise_Control_Project_step(void){/* local block i/o variables */uint8_T LeadVehicle_Speed;uint8_T DriveVehicle_Speed;uint8_T LeadVehicle_Detected;/* Sum: '/Add' incorporates: * Inport: '/CameraInput_LeadVehicle' * Inport: '/RadarInput_LeadVehicle' */LeadVehicle_Speed = (uint8_T)(CameraInput_LeadVehicle + RadarInput_LeadVehicle);/* UnitDelay: '/Unit Delay' */ Acceleration_Mode = Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j;/* Sum: '/Add' incorporates: * Inport: '/CameraInput_DriveVehicle' * Inport: '/RadarInput_DriveVehicle' */DriveVehicle_Speed = (uint8_T)((uint8_T)(CameraInput_DriveVehicle +Acceleration_Mode) + RadarInput_DriveVehicle);/* SignalConversion: '/Signal Conversion' incorporates: * Inport: '/RadarInput_DriveVehicle' */LeadVehicle_Detected = RadarInput_DriveVehicle;/* Chart: '/Chart' incorporates: * Inport: '/CruiseSwitch' * Inport: '/SetSwitch' * Inport: '/Set_Gap' * Inport: '/Set_Speed' * Inport: '/Time_Gap' * UnitDelay: '/Unit Delay' */if (Adaptive_Curise_Control_Proj_DW.is_active_c3_Adaptive_Curise_Co == 0U) {Adaptive_Curise_Control_Proj_DW.is_active_c3_Adaptive_Curise_Co = 1U;Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Curise_IN_ACC_OFF_MODE;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 0U;} else {switch (Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P) {case Adaptive_Curise_IN_ACC_OFF_MODE:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 0U;if (CruiseSwitch) {Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Cu_IN_ACC_STANDBY_MODE;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;}break;case Adaptive_Curise__IN_ACC_ON_MODE:{if (!SetSwitch) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Adaptive_Cur_IN_NO_ACTIVE_CHILD;Adaptive_Curise_Control_Proj_DW.tp_ACC_ON_MODE = 0U;Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Cu_IN_ACC_STANDBY_MODE;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;} else if (!CruiseSwitch) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Adaptive_Cur_IN_NO_ACTIVE_CHILD;Adaptive_Curise_Control_Proj_DW.tp_ACC_ON_MODE = 0U;Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Curise_IN_ACC_OFF_MODE;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 0U;} else {switch (Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE) {case Ada_IN_LeadVehicle_DetectedFlow:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 2U;if (LeadVehicle_Detected == 0) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Ada_IN_LeadVehicle_Not_Detected;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;} else if (((LeadVehicle_Detected == 1) && (LeadVehicle_Speed <Set_Speed)) || (Time_Gap < Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Speed_lessthan_S;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 4U;}break;case IN_LeadVehicle_Detected_Not_Res:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;break;case IN_LeadVehicle_Detected_Resume:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 3U;if (LeadVehicle_Detected == 0) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Detected_Not_Res;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;} else if ((DriveVehicle_Speed == Set_Speed) && (LeadVehicle_Speed >=Set_Speed) && (Time_Gap >= Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Ada_IN_LeadVehicle_DetectedFlow;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 2U;} else if ((DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed >DriveVehicle_Speed) && (Time_Gap >= Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Speed_equal_Set_;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 5U;}break;case Ada_IN_LeadVehicle_Not_Detected:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;if ((LeadVehicle_Detected == 1) && (DriveVehicle_Speed == Set_Speed)&& (LeadVehicle_Speed >= Set_Speed) && (Time_Gap >= Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Ada_IN_LeadVehicle_DetectedFlow;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 2U;} else if (((LeadVehicle_Detected == 1) && (LeadVehicle_Speed <Set_Speed)) || (Time_Gap < Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Speed_lessthan_S;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 4U;}break;case IN_LeadVehicle_Speed_equal_Set_:Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 5U;if (((DriveVehicle_Speed < Set_Speed) && (LeadVehicle_Speed >DriveVehicle_Speed)) || (Time_Gap >= Set_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Detected_Resume;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 3U;} else if ((LeadVehicle_Detected == 0) || (DriveVehicle_Speed <=Set_Speed)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Detected_Not_Res;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;} else if (((LeadVehicle_Speed < Set_Speed) && (LeadVehicle_Speed <DriveVehicle_Speed)) || ((int32_T)rt_roundd_snf(0.75 *(real_T)Set_Gap) == Time_Gap)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Speed_lessthan_S;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 4U;}break;default:{/* case IN_LeadVehicle_Speed_lessthan_Set_Speed: */Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 4U;if ((LeadVehicle_Detected == 0) && (DriveVehicle_Speed ==Set_Speed)) {Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Ada_IN_LeadVehicle_Not_Detected;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;} else {int32_T tmp;int32_T tmp_0;uint8_T tmp_1;uint8_T tmp_2;tmp = (int32_T)rt_roundd_snf((real_T)LeadVehicle_Speed * 1.25);tmp_0 = (int32_T)rt_roundd_snf(1.25 * (real_T)Set_Gap);if (tmp < 256) {tmp_1 = (uint8_T)tmp;} else {tmp_1 = MAX_uint8_T;}if (tmp_0 < 256) {tmp_2 = (uint8_T)tmp_0;} else {tmp_2 = MAX_uint8_T;}if ((tmp_1 >= DriveVehicle_Speed) && ((int32_T)rt_roundd_snf((real_T)LeadVehicle_Speed * 0.75) <= DriveVehicle_Speed) &&(DriveVehicle_Speed < Set_Speed) && (Time_Gap <= tmp_2) &&(Time_Gap >= (int32_T)rt_roundd_snf(0.75 * (real_T)Set_Gap))){Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =IN_LeadVehicle_Speed_equal_Set_;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 5U;}}}break;}}}break;default:/* case IN_ACC_STANDBY_MODE: */Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 1U;if (!CruiseSwitch) {Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Curise_IN_ACC_OFF_MODE;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 0U;} else if (SetSwitch) {Adaptive_Curise_Control_Proj_DW.is_c3_Adaptive_Curise_Control_P =Adaptive_Curise__IN_ACC_ON_MODE;Adaptive_Curise_Control_Proj_DW.tp_ACC_ON_MODE = 1U;Adaptive_Curise_Control_Proj_DW.is_ACC_ON_MODE =Ada_IN_LeadVehicle_DetectedFlow;Adaptive_Curise_Control_Proje_Y.Acceleration_Mode_j = 2U;}break;}}/* End of Chart: '/Chart' */ }/* Model initialize function */void Adaptive_Curise_Control_Project_initialize(void){/* (no initialization code required) */}/* Model terminate function */void Adaptive_Curise_Control_Project_terminate(void){/* (no terminate code required) */}/** File trailer for generated code.** [EOF]*/Conclusion: -
The code generation for model-based development is very easy compared to writing millions of codes. It will be possible with the right solver and code generation setting and mainly due to model adviser check for standard MAAB guidelines. Hence, we can conclude that with proper setting and standard guidelines it will be very easy to build a code for model. It will be a cost efficient and time saving method of design and development of model. It will be possible due to MATLAB. There is a lot of software for same in modelling environment but for better understanding and easy to use we can always preferred MATLAB.
Note:The model file,Requirement tagging file,SLDD file,.c and .h file,Model advisor report were attached below.