Project 2 Adaptive Cruise Control
Introduction:
This is the project to create a Adaptive Cruise Control Simulink Model satisfying some Requirements.
In this our final Output is Acceleration Mode which is extracted after satisfying several conditions.
In this simulink model, three subsystems were used and Two Subsystem is to get output called LeadVechicle_speed, DriveVehicle_speed and LeadVehcicle_Detected. remaining subsytem is the main subsystem which contains state flow where the conditions are implemented and output of the other two subsystem were taken as a input and final output is given from that subsystem.
LeadVehicle_Speed Subsystem:
In this subsystem, the input signals are CameraInput_Leadvehicle and RadarInput, both a input's are given to the sum block to get the output LeadVehicle_Speed.
Subsystem2:
In this system the leadvehicle detected and DriveVehicle speed is the output which is obtained by summing the camera ,acceleration and radar input signals.
Subsystem3:
In this system state flow is used to intercheck the gap, time, speed for giving the output acceleration mode.
The given requirement conditions are completely feeded inside the flow chart where we can implement the logic.
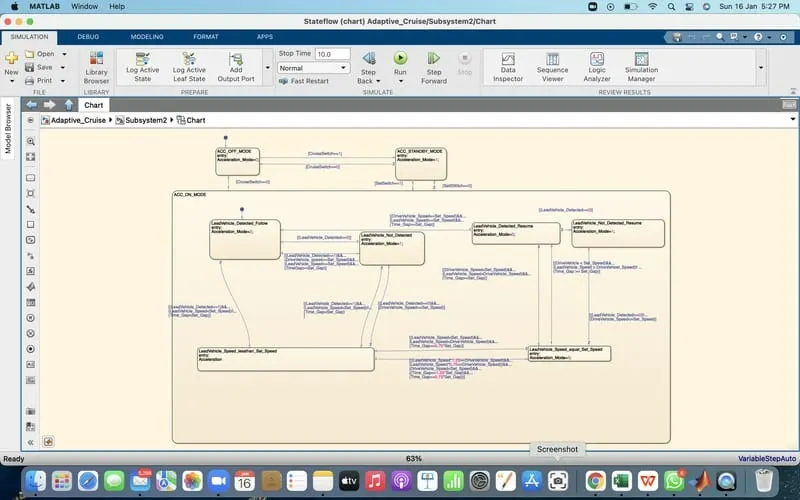
Result:
The system is created which is satisfying all the Requirements listed.
The SLDD is created and attached below.
Simulink and model and the screenshots of the system is attached.