Project 2
Q) Design and Develop a simulink model to understand Energy analysis of EVs on different driving cycles....
SOLUTION;
OBJECTIVE;
To design and develop a simulink model to understand energy analysis of EVs on driving cycles
BLOCKS ARE USED IN MODEL;
Driving cycle;
That is the driving cycle will be applied at the tires of the vehicle model and the simulation back calculates the energy at each stage such as shaft, motor, inverter, and battery.
Subsystem ;
Subsystem are used to reduce to the complexity of the model and to the make it the right
Scope;
Its provide to view the output of the model
Display;
Its provide to the view the output of the model
Constant ;
Output of the constant specified by the 'constant value' parameter
Vehicle body;
Represents a two-axle vehicle body in longitudinal motion.The b;ock accounts for body mass,aerodynamics drag,road incline and weight distribution between axles due to acceleration and road profile.
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body.The resulting traction motion developed by tries should be connected to this port
Solver configuration;
Defines solver settings to use for simulation
Current sensor;
The block represents an ideal current sensor,that is , a device that converts current measured in any electrical branch into a physical signal proportional to the current
Longitudinal Driver ;
A parameteric longitudinal speed tracking controller for generating normalized acceleration and braking commands based on reference and feedback velocities
Saturation;
Limit input signal to the upper and lower saturation values
Product ;
Multiply or Divide inputs . If there is only one input port and the multiplication parameter is set to element-wise,a single ,using the specified operation
Inport;
PRovide an input port for a subsystem or model.The other parameter can be used to explidly specify the input signal attributes
Terminator;
Used to prevents warnings about unconnected output ports
Simple gear;
Represents a fixed-ratio gear or gear box. No inertia is modeled in this block
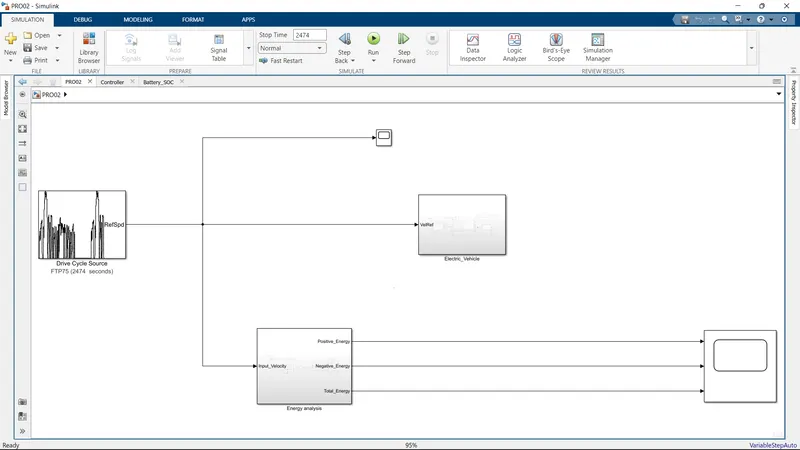
MODEL;
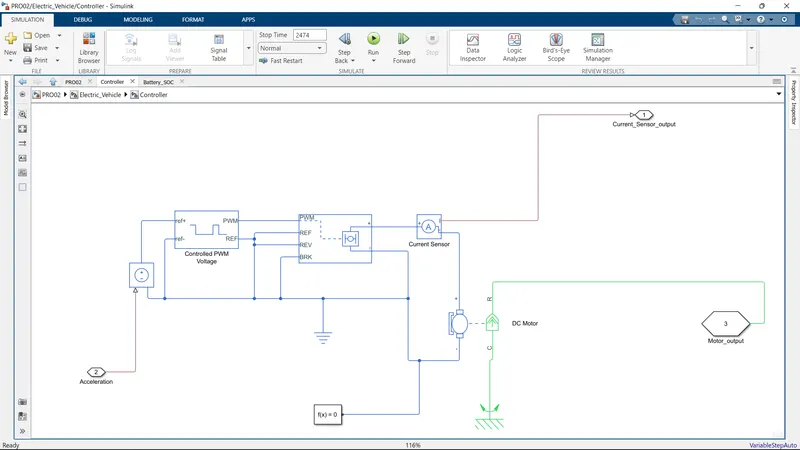
CONTROLLER;
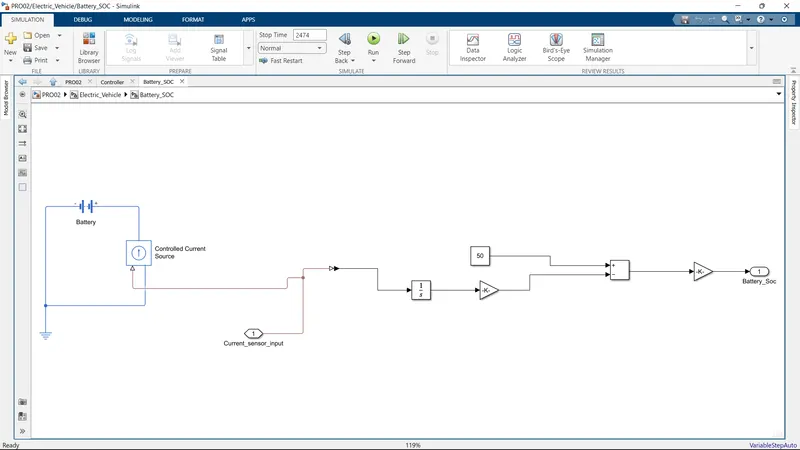
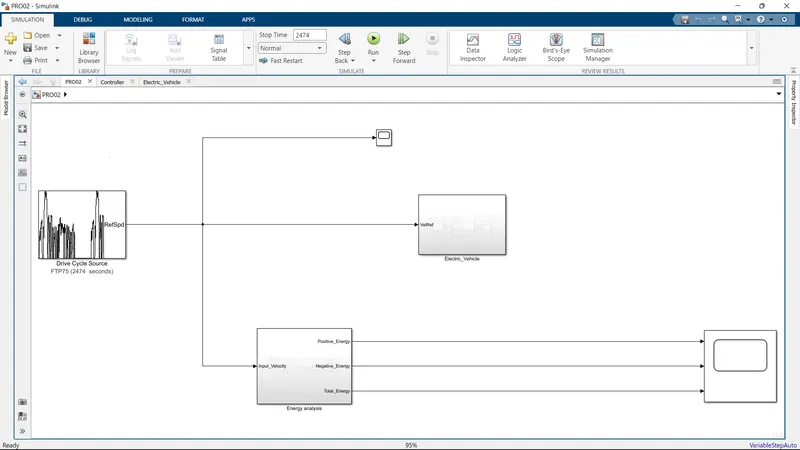
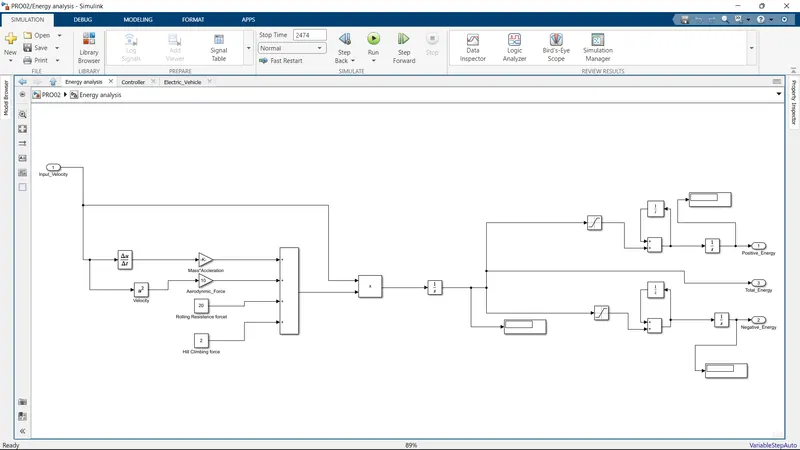
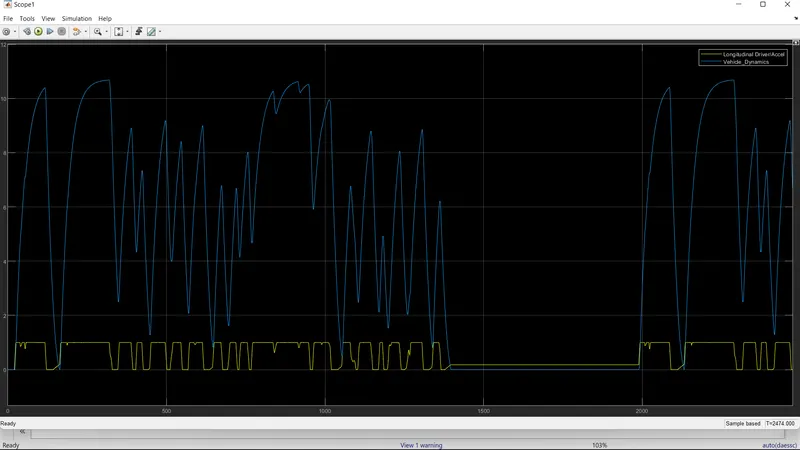
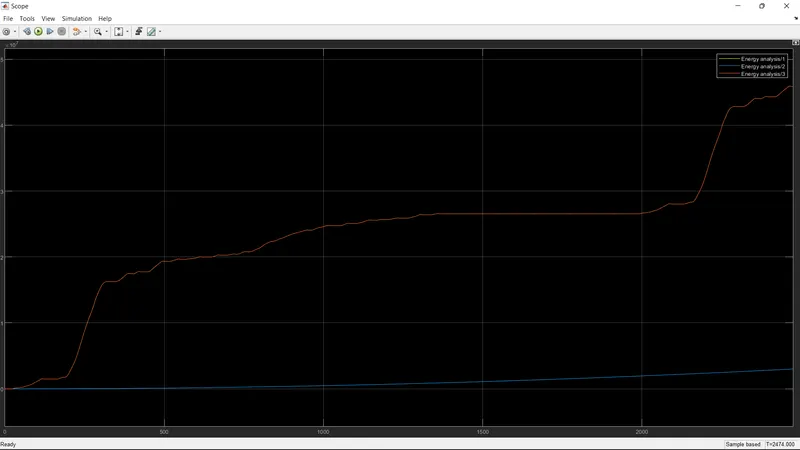
SCOPE (OUPUT WAVEFORM);