Project
AIM: To Study and analyze the BAJA All Terrain Vehicle (ATV) model using Simulink.
Objetive: To prepare a technical report of Baja ATV model.
Theory:
All Terrain Vehicle
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the American National Standards Institute (ANSI); is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles.
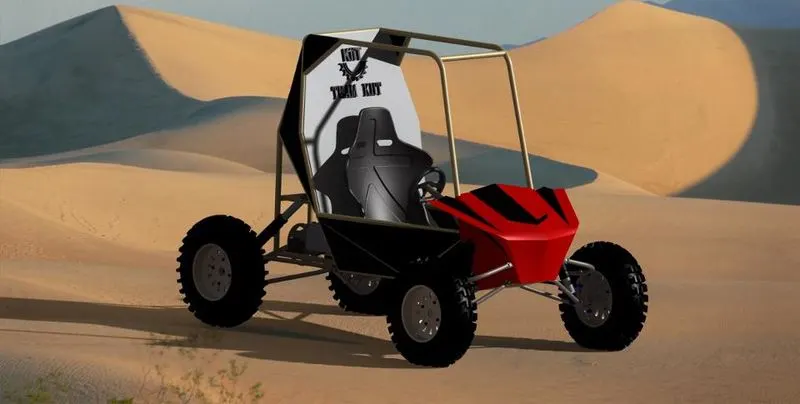
BAJA ATV (SAE)
Baja SAE is an Collegiate Design Series competition run by the Society of Automotive Engineers International (SAE International). Teams of students from universities all over the world design and build small off-road cars. The goal in Baja SAE racing is to design, build and race off-road vehicles that can withstand the harshest elements of rough terrain. The vehicles used in Baja SAE racing are often similar in appearance to dune buggies.
Major component used in CVT model:
- Engine
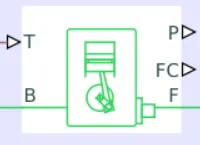
Ports:
- B – Rotational Conserving Port representing the Engine Block
- F – Rotational Conserving Port representing the Engine Crankshaft
- T – Physical signal input port specifying the normalized engine throttle level
- P – Physical signal output port reporting the instantaneous engine power
- FC – Physical signal input port reporting the fuel consumption rate
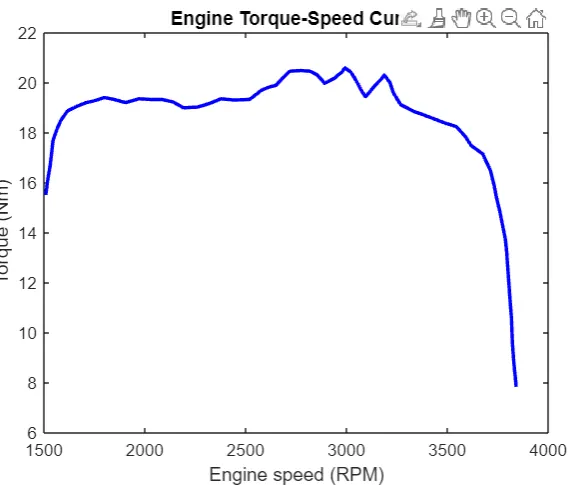
The Generic Engine block represents a general Internal Combustion (IC) Engine.The speed torque and speed power parameters are provided.
2. Simple Gear
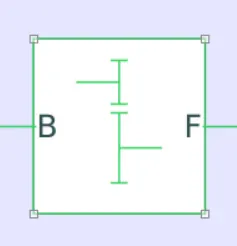
Ports:
- B – Base Gear or Driver Gear
- F – Follower Gear or Driver Gear
The simple gear is a combination of a driver and driven gear where the speed is reduced by the gear ratio.
3.Vehicle Body
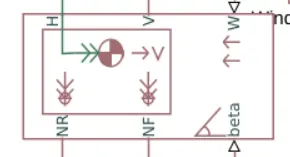
Ports:
- NR – Rear Axle Normal Force
- NF – Front Axle Normal Force
- Beta – Road Incline Angle
- V – Longitudinal Velocity
- W – Head Wind Speed
- H – Horizontal Motion
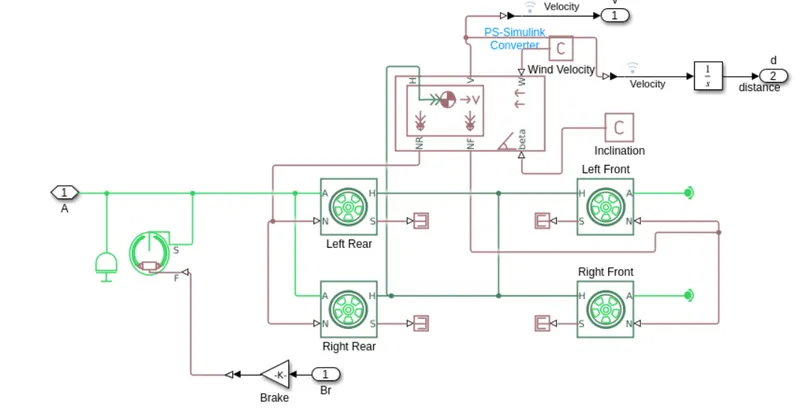
Two – axle vehicle with longitudinal dynamics and motion and adjustable mass, geometry, and drag properties. The vehicle can have the same or a different number of wheels on each axle.
4. Double shoe brake
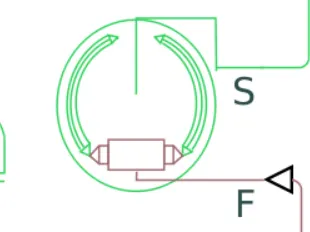
Ports:
- S – Rotational conserving port associated with the rotating drum shaft
- F – Physical signal input port associated with the applied actuating force
The Double-Shoe Brake block represents a frictional brake with two pivoted rigid shoes that press against a rotating drum to produce a braking action. The rigid shoes sit inside or outside the rotating drum in a diametrically opposed configuration. A positive actuating force causes the rigid shoes to press against the rotating drum. Viscous and contact friction between the drum and the rigid shoe surfaces cause the rotating drum to decelerate.
5. CVT TRANSMISSION
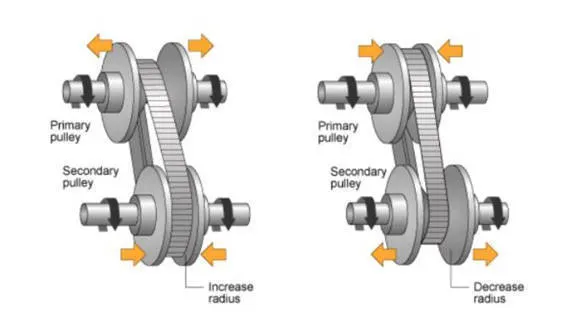
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
The most common type of CVT uses a V-belt which runs between two variable-diameter pulleys. The pulleys consist of two cone-shaped halves that move together and apart. The V-belt runs between these two halves, so the effective diameter of the pulley is dependent on the distance between the two halves of the pulley. The V-shaped cross-section of the belt causes it to ride higher on one pulley and lower on the other; therefore, the gear ratio is adjusted by moving the two sheaves of one pulley closer together and the two sheaves of the other pulley farther apart.
he distance between the center of the pulleys to where the belt makes contact in the groove is known as the pitch radius. When the pulleys are close together, the belt rides higher and the pitch radius increases. The ratio of the pitch radius on the driving pulley to the pitch radius on the driven pulley determines the gear when the pitch radius is small on the driving pulley and large on the driven pulley, then the rotational speed of the driven pulley decreases, resulting in a lower “gear”. When the pitch radius is large on the driving pulley and small on the driven pulley, then the rotational speed of the driven pulley increases, resulting in a higher “gear”. Thus, in theory, a CVT has an infinite number of “gears” that it can run through at any time, at any engine or vehicle speed.
6. Tire
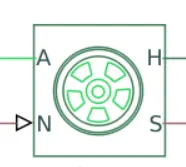
Ports:
- N – Normal Force
- S – Tire Slip
- A – Axle
- H – Mechanical translational port associated with the wheel hub that transmits the thrust generated by the tire to the remainder of the vehicle.
The vehicle body is connected to 4 tires each per axle to move the vehicle according to the power input to the axle.
Blocks used for making the CVT model:
- Signal Builder – To input the Brake, Throttle and CVT Ratio.
- Simulink to PS converter – To convert the Simulink signal to Simscape environment.
- Solver Configuration – To specify the solver parameters before starting the simulation.
- Mechanical Reference – To make sure all the components are clamped to the ground.
- Generic Engine – To run the engine with speed and torque values as input.
- PS to Simulink Converter – To convert Simscape signal to Simulink environment.
- Scope – To view the graph of the parameters for better understanding.
- Display – To view the calculated engine power.
- Inertia – To represent the solid inertia.
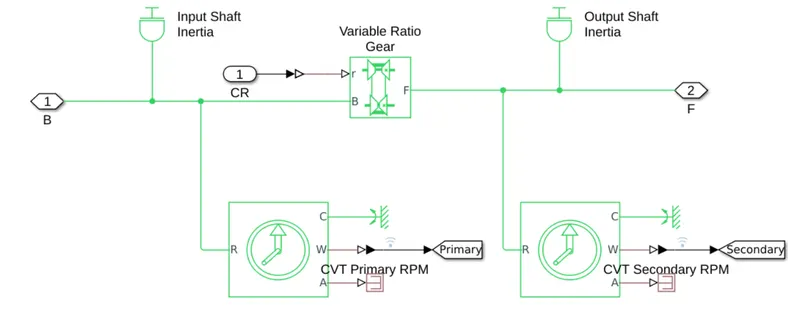
- Rotational Motion Sensor – To sense the rotational motion from the engine and give output as RPM.
- Variable Gear Ratio – To vary the speed according to the gear ratios.
- PS Terminator – Terminator for unconnected physical signal outputs.
- Double Shoe Brake – To apply brake to the vehicle when needed.
- PS Constant – Generate constant physical signal.
- Tire – For transportation of the vehicle.
- Rotational Free End – For mechanical component (Tire)
- Vehicle Body – To represent the BAJA ATV model body.
- Custom Measure Gauge – To measure the brake and throttle input.
- Knob – To increase, decrease and vice-versa of throttle and brake inputs.
- Lookup Table – To insert the CVT values from the workspace.
- Simple Gear – To reduce the speed of the engine with pre-defined gear ratio.
- Step – To increase or decrease an input value for a defined time interval.
MAIN MODEL:
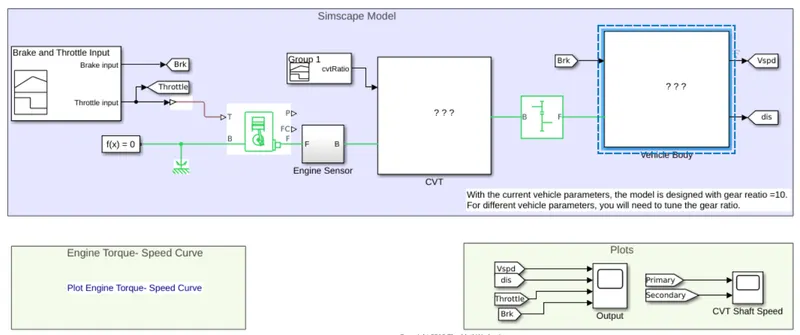
1. Engine Sensor
This block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
CVT System:
Vehicle Body:
Input:
Engine Speed
Input to Brake And throttle: -
VCT ratio input: -
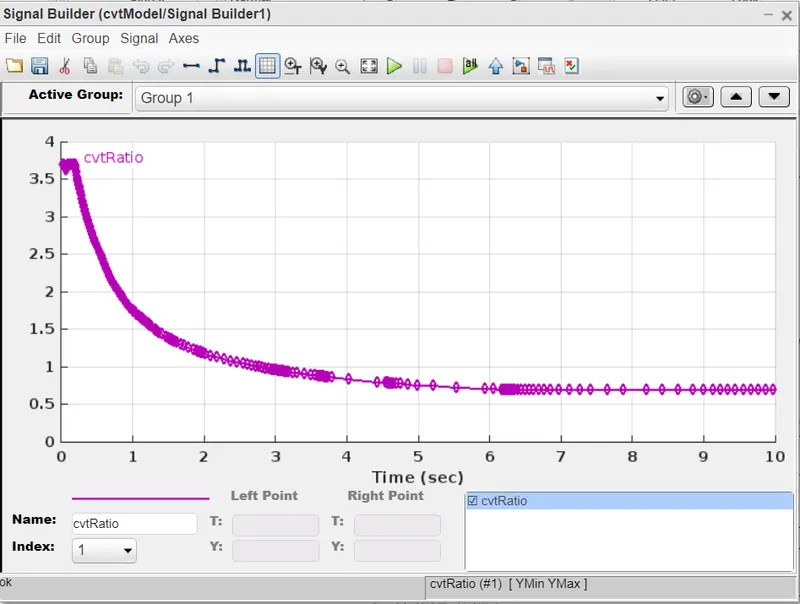
The CVT ratio is 10
Results:
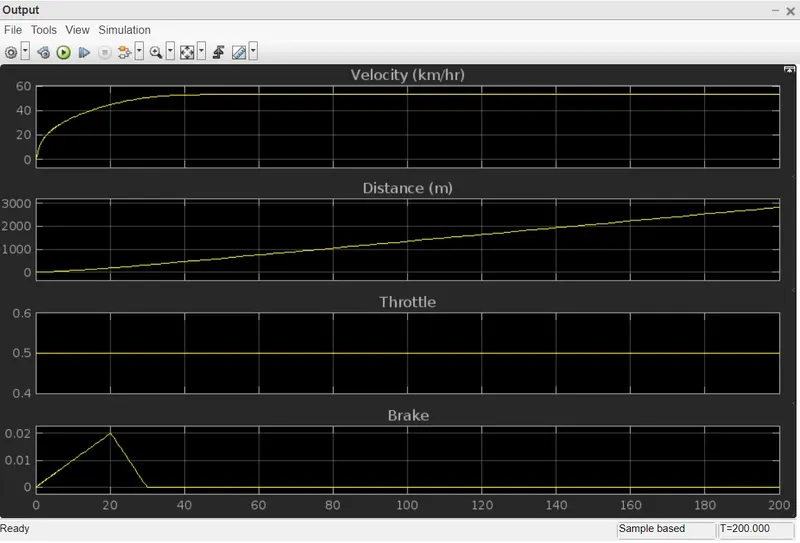
Output showing velocity, Distance, throttle & Brake.
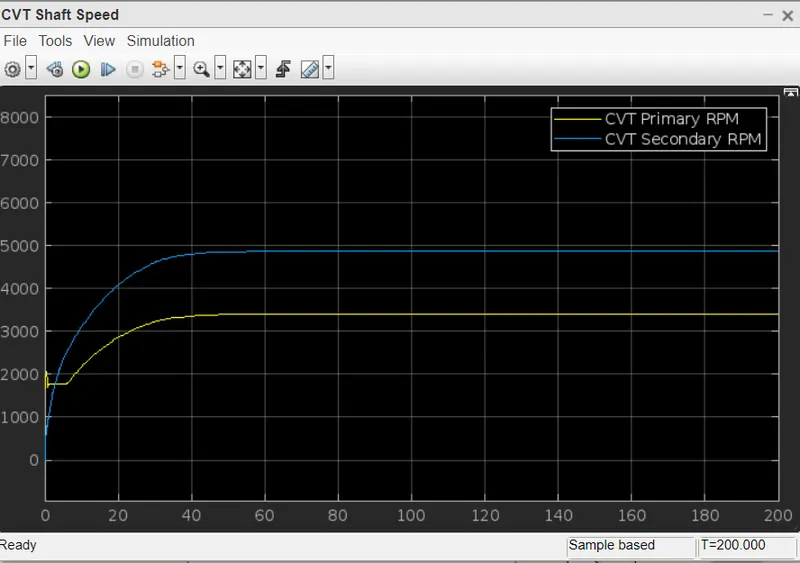
CVT shaft speed.