Project 1 (Mini Project on Vehicle Direction Detection
AIM : To devolop a vehicle direction detection system
Blocks Used :
- Inport
- Outport
- Constant
- GOTO
- FROM
- AND
- Equal
- MUX
- Signal Conversion
Block Diagram :
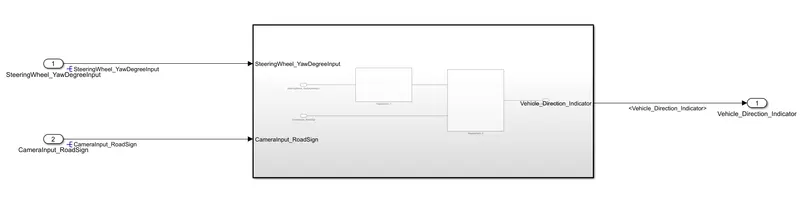
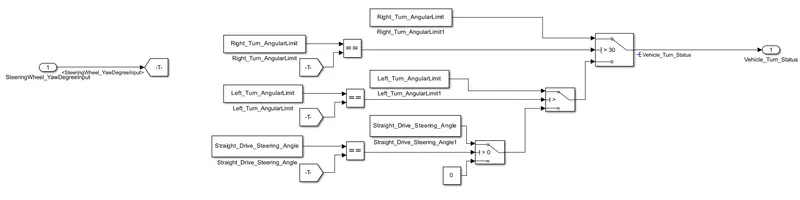 Requirement 1
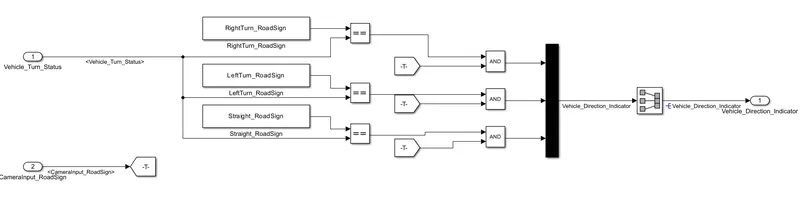 Requirement 2
Theory :
Requiremnt 1
The SteeringWheel_YawDegreeInput is considered as input and it's values are compared to the Calibration values i.e Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle using switch blocks, Initially the Input is compare to calibration value using Equal Block, the output from equal block is given as activation signal to the switch block, based on this the switch operates and vehicle direction is detected.
Requirement 2
The Output from the vehicle turn status is compared with Roadsign calibration values using Equal Block the output is 1 if both values match, This value is compared with Camerainput_Roadsign this gives the vehicle direction.