Project 1 (Mini Project on Vehicle Direction Detection
Aim of Project:-
To identify the direction the vehicle is taking based on the camera input and indicate driver if whether he is driving in the recommended direction.
Description of Project:-
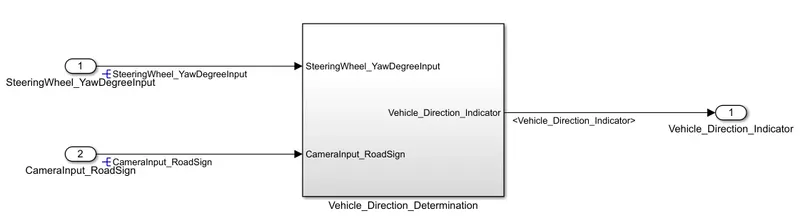
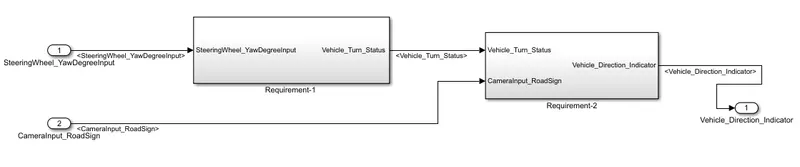
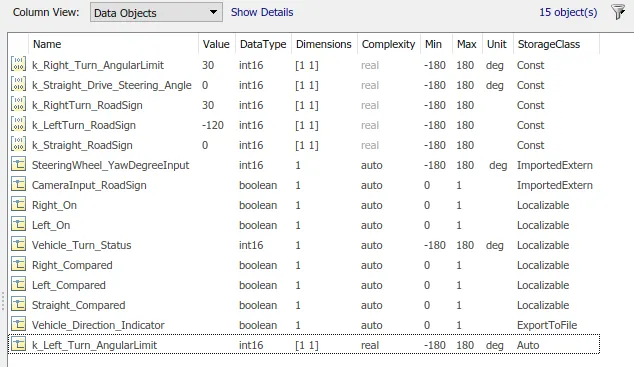
The two requirements are modelled as separate subsystems which are again enclosed in subsystem Vehicle Direction Determination with SteeringWheel_YawDegreeInput and CameraInput_RoadSign as input and Vehicle_Direction_Indicator as output.
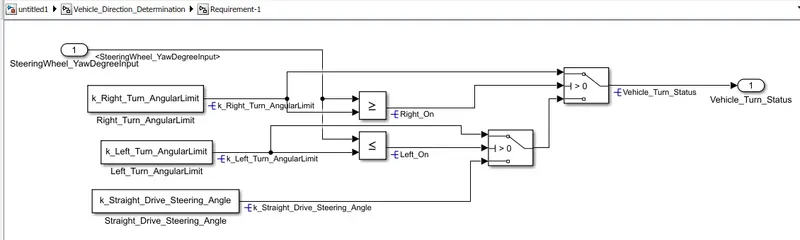
In Requirement-1 according to the value of SteeringWheel_YawDegreeInput using relational operators and switch blocks values corresponding to vehicle going left or right or straight(Right_Turn_AngularLimit, Left_Turn_AngularLimit & Straight_Drive_Steering_Angle) are given to Vehicle_Turn_Status.
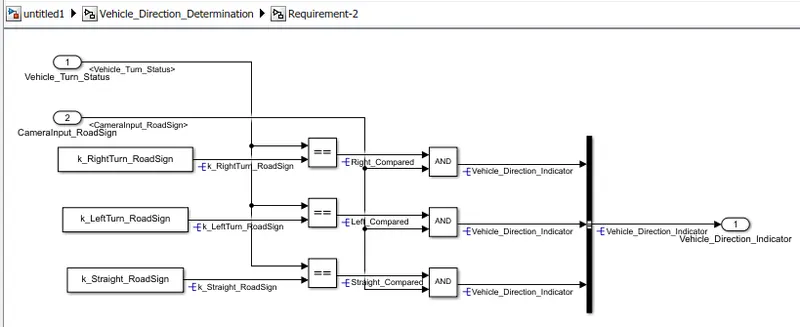
In Requirement-2 Vehicle_Turn_Status value is compared to RightTurn_RoadSign, LeftTurn_RoadSign & Straight_RoadSign and comparison output is cross-checked by CameraInput_RoadSign whether really the corresponding road sign was present on the side of the road.
If present then corresponding Vehicle_Direction_Indicator has value 1 and others as 0 as set of output triplet.
Simulink Model :-
SLDD :-
Result:-
I have developed requirements in Simulink model and declared signals & calibration values in SLDD.