Project 1 (Mini Project on Vehicle Direction Detection
Aim of Project
To determine the vehicle direction using the traffic sign recognition feature fed from a camera and would be compared with the inputs coming from the steering gear angular motion degree for the tuning purpose in order to get the final vehicle direction.
Description
Requirement 1:
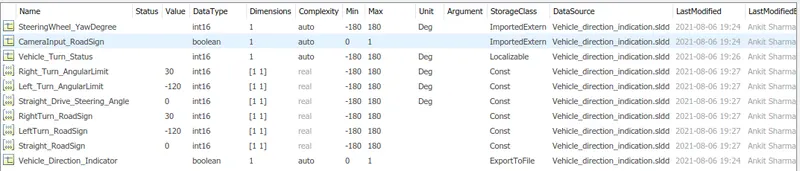
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
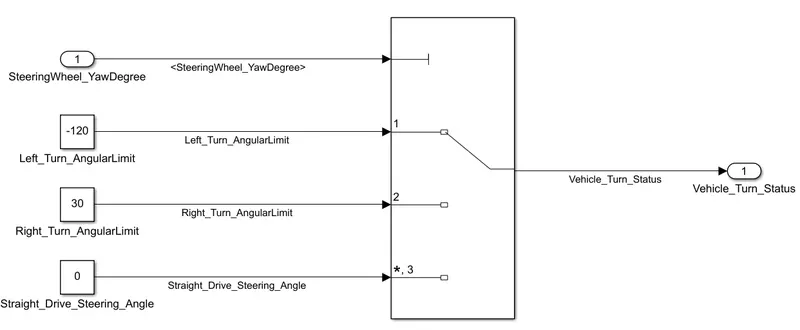
A multi-port switch has been used for comparing the steering wheel input with a left turn, right turn & straight drive calibrated values.
Requirement 2
- Keep this requirement as a separate subsystem. Inputs to this requirement are a local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from the camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
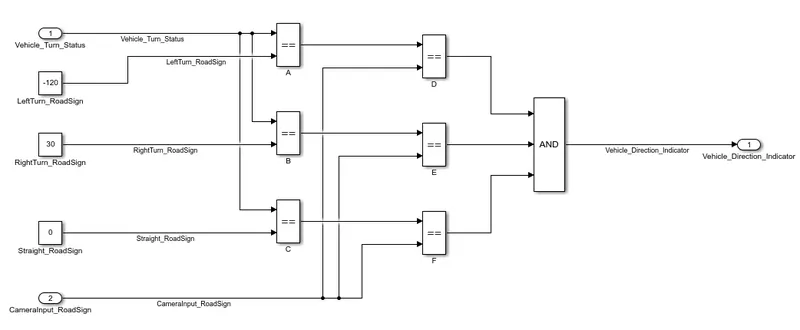
Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign)
Relational operators Block: A, B and C are used to compare Vehicle_Turn_Status signal against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign)
Relational operators Block: D, E and F are used to compare the CameraInput_RoadSign signal against A, B and C blocks output in boolean format.
Requirements subsystems:
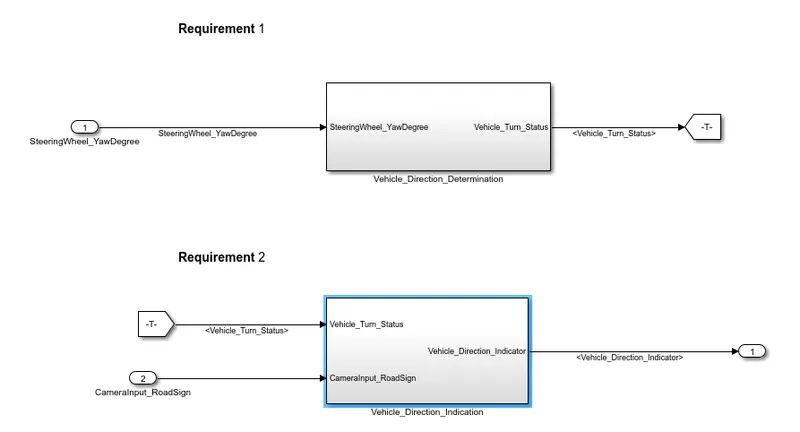
Main subsystem:
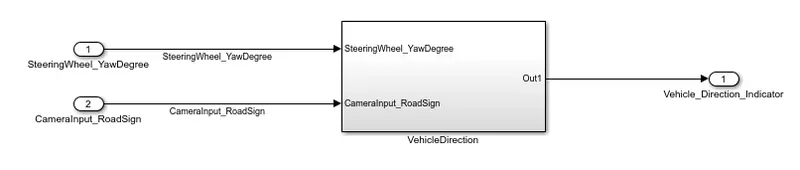
Creation of SLDD:
The code generation was executed using the embedded coder selection through model configuration block but, due to the MATLAB older version, it is showing an error and is not able to perform which is the same case for the requirement tagging process.