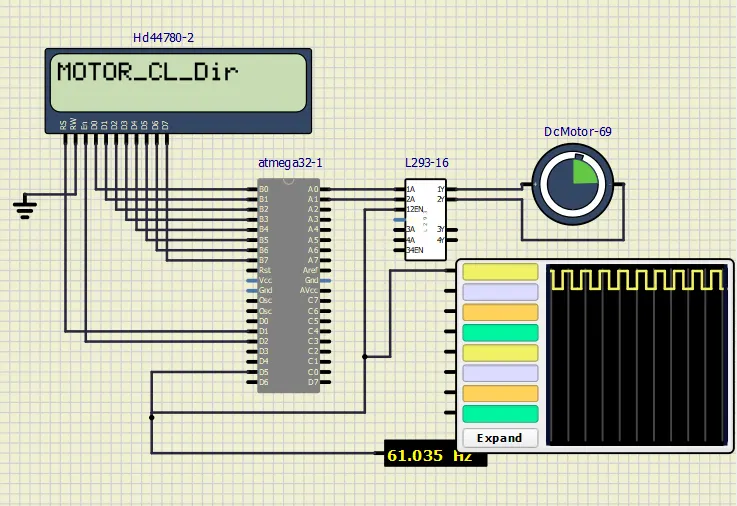
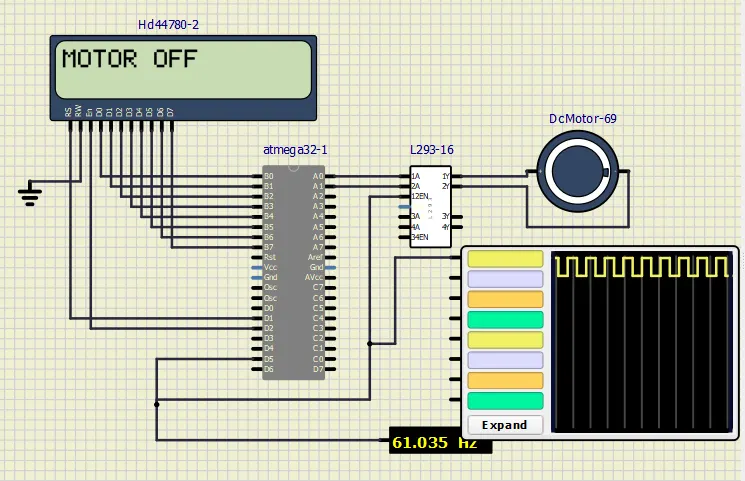
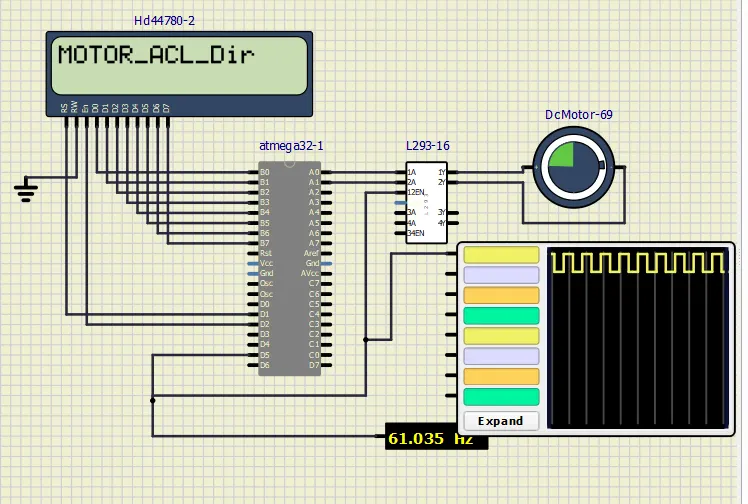
Project 1 - Controlling a DC motor using PWM and monitoring its Running status
Ans:
#include <avr/io.h> // processor for AVR
#define F_CPU 16000000L // clock frequency
#include <util/delay.h> // for delay function
#define rs_low PORTD &=~(1<<1); // bit 1 of portD resister select bit low for passing command to display
#define rs_high PORTD |=(1<<1); // bit 1 of portD resister select bit high for passing data to display
#define en_low PORTD &=~(1<<2); //bit 2 of portD set low for enable low
#define en_high PORTD |=(1<<2); //bit 2 of portD set high for enable high
#define lcd_port PORTB // all pin of PORTB connect to lcd display
void lcd_cmd( char cmd)
{
lcd_port=cmd; // pass command to lcd port
rs_low; // select resister low for passing command
en_high; // enable high and after some delay enable should be low
_delay_ms(1);
en_low;
}
void lcd_data( char data)
{
lcd_port=data; // pass data to lcd port
rs_high; // select resister high for passing data
en_high; // enable high and after some delay enable should be low
_delay_ms(1);
en_low;
}
void lcd_init()
{
lcd_cmd(0x38);_delay_ms(5); // 2 lines 5x7 matrix
lcd_cmd(0x02);_delay_ms(5); // return home
lcd_cmd(0x01);_delay_ms(5); // clearing the screen
lcd_cmd(0x0C);_delay_ms(5); // display on cursor off
lcd_cmd(0x06);_delay_ms(5); //Incrementing cursor
lcd_cmd(0x80);_delay_ms(5); // force cursor being 1st line
}
void lcd_curserpos(char x, char y)
{
if(( x<1||x>2)||(y<1||y>16)) //condition will check the 2 rows and 16 columns
{
x=1;
y=1;
}
if(x==1)
lcd_cmd(0x7F+y); // cursor force to start from 1st row
else
lcd_cmd(0xBF+y);// cursor force to start from 2nd row
}
void lcd_out(char x, char y, char *str)
{
lcd_curserpos(x,y);
while(*str)
{
lcd_data(*str);
str++;
}
}
int main(void)
{
DDRB|=0xff; // configuring all portB as an output pin
DDRD|=(1<<1); //pin 1 of portD set as output
DDRD|=(1<<2); //pin 2 of portD set as output
DDRD|=(1<<5); //OC1A pin used set ad output
DDRA|=(1<<0); // pin A0 and A1 pass to motor driver to provide direction to the motor
DDRA|=(1<<1);
lcd_init(); // initializing the 16x2 lcd display
while(1)
{
TCCR1A=0b10000001; // Clear OC1A/OC1B on compare match OC1A/OC1B at TOP, fast PWM 8 bit
TCCR1B=0b00001101;// fast PWM wage generation, prescaler 1024
OCR1A=128; // 50%duty cycle
PORTA=0x01;//to run motor in clockwise direction
lcd_out(1,1,"MOTOR_CL_Dir"); // row, column, string
_delay_ms(5000);
lcd_cmd(0x01);// clearing the display
_delay_ms(5);
PORTA=0x00;
lcd_out(1,1,"MOTOR OFF");
_delay_ms(5000);
PORTA=0x02;// to run motor anti clock wise
lcd_out(1,1,"MOTOR_ACL_Dir");
_delay_ms(5000);
PORTA=0x00;
lcd_cmd(0x01); // clearing the display
_delay_ms(5);
lcd_out(1,1,"MOTOR OFF");
_delay_ms(5000);
}
}