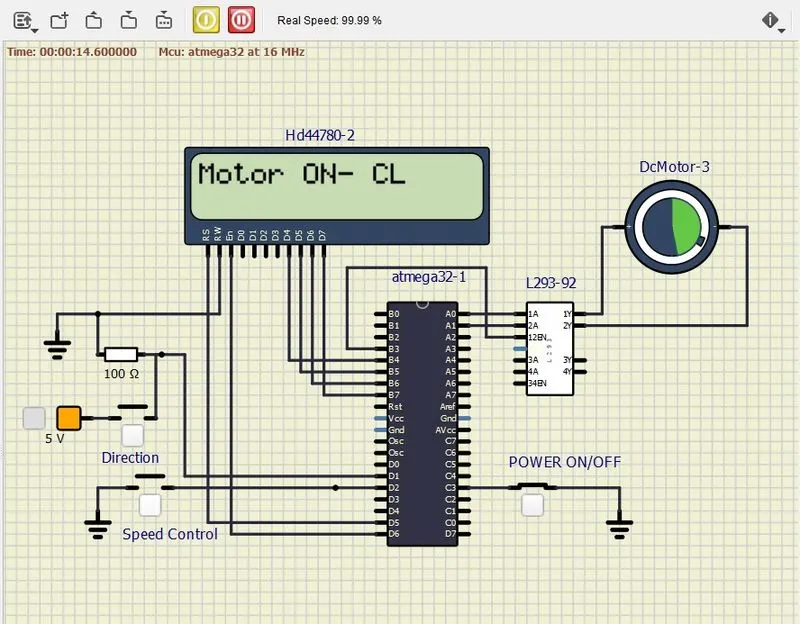
Project 1 - Controlling a DC motor using PWM and monitoring its Running status
Project Overview:
The project aims to control a DC motor using Pulse Width Modulation (PWM) and monitor its running status. PWM allows controlling the speed of the motor by varying the duty cycle of the PWM signal. The running status of the motor will be monitored and displayed to indicate the direction of rotation.
Goals:
1. Control a DC motor using PWM.
2. Monitor the running status of the motor.
3. Display the running status to indicate the motor's direction of rotation.
Key Highlights of the Project:
1. Utilize PWM to control the speed of the DC motor.
2. Implement a motor driver or motor control circuit to interface with the DC motor.
3. Monitor the motor's running status, i.e., the direction of rotation.
4. Display the running status to provide visual feedback.
Deliverables of this Project:
1. Working system to control a DC motor using PWM.
2. Motor control circuit or driver to interface with the DC motor.
3. Monitoring functionality to determine the running status of the motor.
4. Display mechanism to show the running status.
code:
#include <avr/io.h> //we are using I/O registers of AVR
#define F_CPU 16000000L // define the crystal frequency
#include "avr/interrupt.h" // we are using external interrupt pin
#include <util/delay.h> // delay function purpose
#define sw_dir (PIND & (1<<1)) // d1 pin is declared as push button for direction control.
#define sw_dspd (PIND & (1<<2)) // d2 pin is declared as push button for speed control.
#define pw (PINC & (1<<3)) // c3 is declared as push button for power ON/OFF
#define lcd_port PORTB //PORTB pins are for LCD data
#define RS_high PORTD |= (1<<5) // d5 pin is used for Register Select(RS)
#define RS_low PORTD &=~ (1<<5) // d5 pin is used for RS
#define EN_high PORTD |= (1<<6) // d6 pin is used for Enable
#define EN_low PORTD &=~ (1<<6) // d6 pin is used for En.
unsigned char i;
void lcd_cmd(char cmd) //command for lcd display
{
lcd_port = (cmd & 0xf0); //4 bits for 4 bit lcd mode
RS_low;
EN_low;
_delay_ms(1); //after 1ms disable lcd
EN_high; //enable the lcd
lcd_port = ((cmd<<4) & (0xf0)); //lcd port
RS_low;
EN_low;
_delay_ms(1); //after 1ms disable lcd
EN_high; //enable the lcd
}
void lcd_data (char data) //send the data to lcd
{
lcd_port = (data & 0xf0); //4 bits for 4 bit lcd mode
RS_high; //access data register
EN_low;
_delay_ms(1);
EN_high;
lcd_port = ((data<<4) & (0xf0)); //4 bits for 4 bit lcd mode
RS_high; //access data register
EN_low;
_delay_ms(1);
EN_high;
}
void lcd_init()
{
lcd_cmd(0x28);// used for 4 bit lcd mode
_delay_ms(5);
lcd_cmd(0x02); // return home
_delay_ms(5);
lcd_cmd(0x01); // clear screen
_delay_ms(5);
lcd_cmd(0x0C); // display on cursor off
_delay_ms(5);
lcd_cmd(0x06); // increment the display cursor
_delay_ms(5);
lcd_cmd(0x80); // force cursor to begin from 1st line
_delay_ms(5);
}
void cursorpos(char x,char y)
{
if((x<1 || x>2) || (y>16 || y<1 )) //condition will checks the 2 rows and 16 columns
{
x=1; //x= row
y=1; //y= column
}
if(x==1)
{
lcd_cmd(0x7F + y); //{ 80-1 = 7F} for starting the 1st line hex decimal value (80) {y we r using the 7F+y means we need to dtart from that column}
}
else //(x==2)
{
lcd_cmd(0xBF + y); //{0C-1 = 0B} for starting the 2nd line, 2nd row.
}
}
void lcd_out(char x, char y, char *str) //here we are checking which position we want to print
{
cursorpos(x,y);
while(*str)
{
lcd_data(*str);
str++;
}
}
int adc_read(char channel) // we r configuring the adc value
{
unsigned int a, result;
ADMUX = channel; // here we r going to use which channel we need to select in mux here using 2 bit
ADCSRA = 0X80; //control & status register to enable the adc conversion ,enable the interrupt flag, adc interrupt. ADEN=1
ADCH = 0X00; // showing the value 0 or clearing the adc register
ADCL = 0x00; // showing the value 0
ADCSRA |= (1<<6); // to start the conversion 6 bit ADSC high
while((ADCSRA & 0x40) != 0); // when the conversion become zero means conversion of adc (0x40 means interrupted pin )
a= ADCL; //dummy data type a and ais stored the ADCL register (ADC0-ADC7)
result = ADCH; // Store the high value (ADC8-ADC9)
result = result<<8; //to get proper result or alined value we need to do left shift
result = result | a ; // we r adding the ADCL + ADCH to get the 16 bits
return result;
}
int main(void)
{
DDRB = 0XFF; //Declaring all 8-pins as output.
DDRA |= ((1<<0)| (1<<1)); //Declaring A0 & A1 pins as output.
DDRD &=~ (1<<1); //Declaring D1 pin as input.
DDRD &=~ (1<<2); //Declaring D2 pin as input.
DDRD |= (1<<5); //Declaring D5 pin as output.
DDRD |= (1<<6); //Declaring D6 pin as output.
DDRC &=~ (1<<3); //Declaring C3 pin as input.
PORTD |= (1<<2); //enabling internal pull up resistor for D2.
PORTC |= (1<<3); //enabling internal pull up resistor for D3.
i=64; //initializing i=64 because we are running the motor with 25% duty cycle.
TCCR0=0X61; //Non-Inverting mode, PWM phase correct mode,NO prescalar.
GICR=(1<<INT0); //using INT0 for interrupt
MCUCR=0X02; //make interrupt negative edge triggered
sei(); //Enable global interrupt
lcd_init(); //Initialize lcd
while (1)
{
while(pw==0) //continue till the push button is released.
{
if(sw_dir == 0) //if the direction control push button is released.
{
PORTA = 0b00000001; // 1 0 to respective 1A 2A pins to rotate in clockwise direction.
lcd_out(1,1,"Motor ON- CL "); //Running clock wise direction
}
else
{
PORTA = 0b00000010; // 1 0 to respective 1A 2A pins to rotate in Anti-Clockwise direction.
lcd_out(1,1,"Motor ON- ACL");
}
OCR0 = i; //i increases in ISR, the corresponding value is to be loaded into OCR0.
}
PORTA = 0x00; // 0 0 to respective 1A 2A pins to Stop rotation.
lcd_out(1,1,"Motor is TURNOFF");
}
}
ISR(INT0_vect) //interrupt service routine
{
i=i+20; // as i increases the duty cycle also increases. i increases by 20 in each push//
// and the corresponding value is to be loaded into OCR0 in while loop//
}
Expected Outcomes:
1. Understanding of PWM and its application in controlling the speed of a DC motor.
2. Knowledge of motor drivers and their role in interfacing the motor with the microcontroller.
3. Ability to monitor the motor's running status and interpret it as the direction of rotation.
4. Implementation of a display mechanism, such as an LCD, to provide visual feedback of the running status.
Power Switch: OFF, Direction Switch: OFF, Speed Switch: OFF :: Motor is TURN OFF Condition
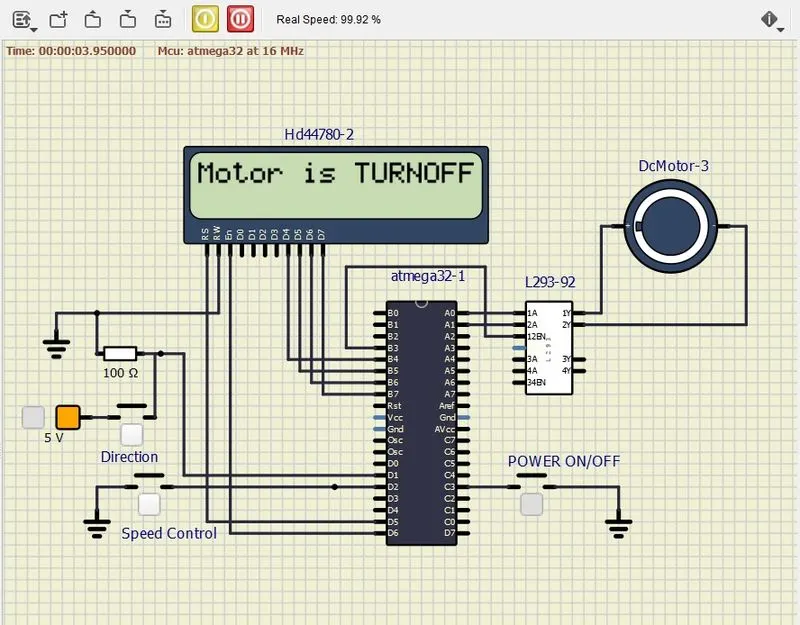
Power Switch: ON, Direction Switch: OFF, Speed Switch: OFF :: Motor is TURN ON Condition
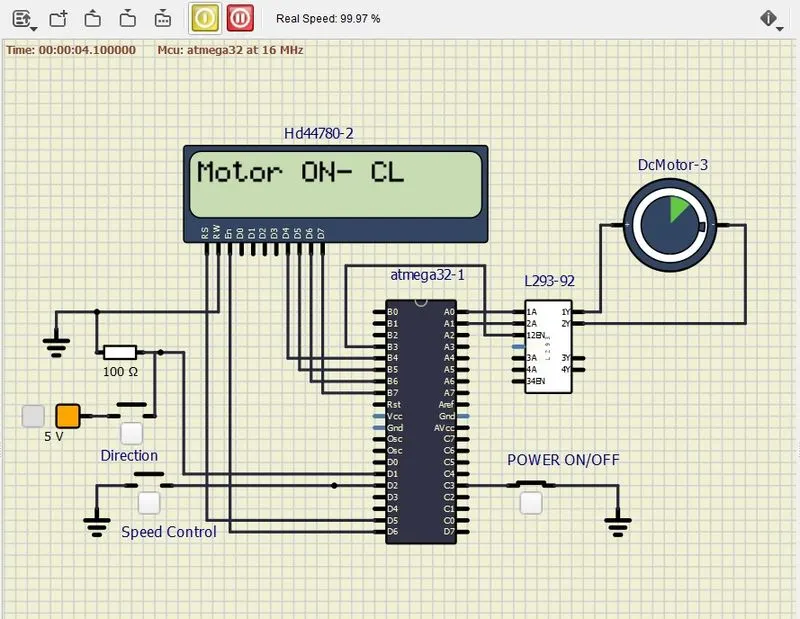
Power Switch: ON, Direction Switch: ON, Speed Switch: OFF :: Motor is TURN ON and Direction of Rotation: REVERSE
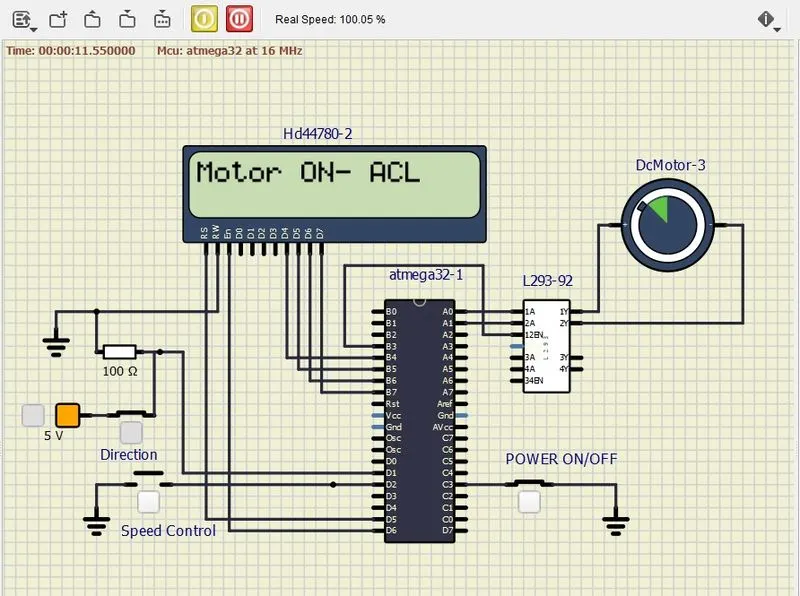
Power Switch: ON, Direction Switch: OFF, Speed Switch: ON :: Motor is TURN ON and Speed of Motor: INCREASED