Project 1 - Controlling a DC motor using PWM and monitoring its Running status
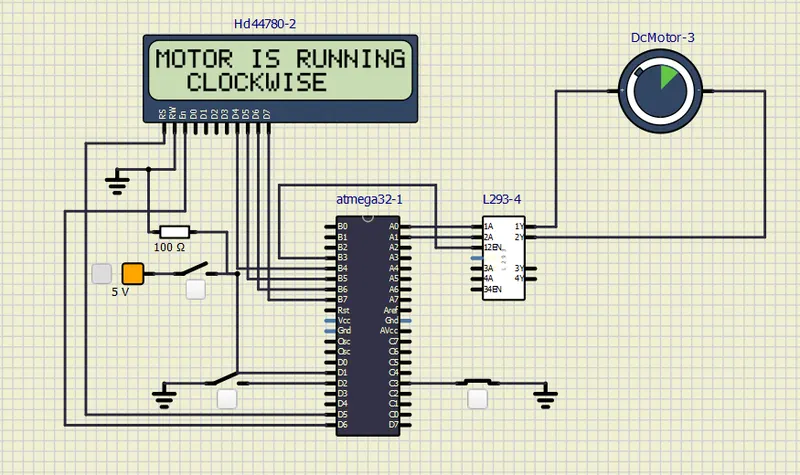 /*
* project1.c
*
* Created: 11/25/2022 11:01:37 AM
* Author : hp
*/
#include <avr/io.h> //we are using the I/O register of avr
#define F_CPU 16000000ul //define cpu frequency
#include "avr/interrupt.h" //we are using external interrupt pin
#include <util/delay.h> //delay function
#define sw_dir (PIND&(1<<1)) //d1 pin is declared as push button for direction control
#define sw_spd (PIND&(1<<2)) //d2 pin is declared as push button for speed control
#define pw (PINC&(1<<3)) //c3 pin is declared as push button for Power ON/OFF
#define lcd_port PORTB //portb pins are dedicated for lcd data
#define RS_high() PORTD |=(1<<5); //d5 pin is used for rs
#define RS_low() PORTD &=~(1<<5);
#define EN_high() PORTD |=(1<<6); //d6 pin is used for en
#define EN_low() PORTD &=~(1<<6);
unsigned char i; //variable declared to increase the duty cycle in PWM
void lcd_cmd(char cmd)
{
lcd_port=(cmd&0xf0); //Masking 4bits for 4bit lcd mode
RS_low();
EN_low();
_delay_ms(1);
EN_high();
lcd_port=((cmd<<4)&(0xf0));
RS_low();
EN_low();
_delay_ms(1);
EN_high();
}
void lcd_data(char data)
{
lcd_port=(data &0xf0); //Masking 4bits for 4bit lcd mode
RS_high();
EN_low();
_delay_ms(1);
EN_high();
lcd_port=((data<<4)&(0xf0));
RS_high();
EN_low();
_delay_ms(1);
EN_high();
}
void lcd_init()
{
lcd_cmd(0x02);_delay_ms(5); //return the cursor to home
lcd_cmd(0x01);_delay_ms(5); //clear screen
lcd_cmd(0x0C);_delay_ms(5); //display ON cursor OFF
lcd_cmd(0x06);_delay_ms(5); //increment cursor
lcd_cmd(0x80);_delay_ms(5); //force cursor to begin 1st line
lcd_cmd(0x28);_delay_ms(5); //used for 4bit lcd mode
}
void cursorpos(char x,char y)
{
if(( x < 1 || x > 2 ) || ( y > 16 || y < 1 ))
{
x=1;
y=1;
}
if(x==1)
lcd_cmd(0x7F+y);
else
lcd_cmd(0xBF+y);
}
void lcd_out(char x,char y,char *str)
{
cursorpos(x,y);
while(*str)
{
lcd_data(*str);
str++;
}
}
int main(void)
{
DDRD=0xFF;//Declaring all B pins as outputs
DDRA|=((1<<0)|(1<<1));//
DDRD&=~(1<<1);//Declaring D1 pin as input
DDRD&=~(1<<2);//Declaring D2 pin as input
DDRD|=(1<<5);//Declaring D5 pin as output
DDRD|=(1<<6);//Declaring D6 pin as output
DDRC&=~(1<<3);//Declaring C3 pin as input
PORTC|=(1<<2);//enabling internal pull up resistor for D2
PORTC|=(1<<3);//enabling internal pull up resistor for D3
i=64;//initializing i=64 because we are running the motor with 25% duty cycle
TCCR0=0x61;//non inverting mode, PWM phase correct mode,NO prescalers
GICR=(1<<INT0);//using INT0 for interrupt
MCUCR=0x02;//make interrupt negative edge triggered
sei();//enable global interrupt
lcd_init();
while(1)
{
while(pw==0)//continuous till the power push button is released
{
if(sw_dir==0)//if the direction control push button is released
{
PORTA=0b00000001;//1 0 t0 respective 1A 2A pins to rotate in clockwise direction
lcd_out(1,1,"MOTOR IS RUNNING");
lcd_out(2,3,"CLOCKWISE");
}
else
{
PORTA=0b00000010;// 0 1 t0 respective 1A 2A pins to rotate in anticlockwise direction
lcd_out(1,1,"MOTOR IS RUNNING");
lcd_out(2,3,"ANTICLOCKWISE");
}
OCR0=i;// As, i increases in ISR , The corresponding value is to be loaded into OCR0
}
PORTA=0b00000000;//0 0 t0 respective 1A 2A pins to stop rotation
lcd_out(1,1,"MOTOR IS OFF");
lcd_out(2,3,"CAUTION!!!!!");
}
}
ISR(INT0_vect)//Interrupt service routine
{
i=i+20;//as i increases the duty cycle also increases.i
}