Frequency Analysis of a rotating shaft
AIM: - To simulate the FEA frequency analysis on the rotating shaft.
PHYSICS: -
Vibration: - To and fro motion of a particle w.r.t to a fix point is is called vibration.
Amplititude: - The maximum didplacement of particle during vibration is called amplitude.
Resonance: - When the when the frequency of disturbiong force is equal to the natural frequency of system, this phenomena is called resonance. This results in larger amplitude. The system will oscillate at a higher amplitude than when the same force is applied at other, non-resonant frequencies. Frequencies at which the response amplitude is relative maximum are also known as resonant frequencies or resonance frequencies of the system.
The increase in amplitude of oscillation of an electric or mechanical system exposed to a periodic force whose frequency is equal or very close to the natural undamped frequency of the system. Resonance phenomena occur with all types of vibrations or wave there is mechanical resonance, accuastic resonance, electromagnetic resonance, nuclear magnetic resonance (NMR), electron spin resonance (ESR) and resonance of quantum wave. Resonant systems can be used to generate vibrations of a specific frequency (e.g., musical instrumemtal), or pick out specific frequencies from a complex vibration containing many frequencies (e.g., filters).
Resonance of a driven, damped harmonic oscillator: -
Consider a damped mass on a spring driven by a sinusoidal, externally applied force. Newton's 2nd law takes the form
-
m d 2 x d t 2 = F 0 sin ( ω t ) − k x − c d x d t , {\displaystyle m{\frac {\mathrm {d} ^{2}x}{\mathrm {d} t^{2}}}=F_{0}\sin(\omega t)-kx-c{\frac {\mathrm {d} x}{\mathrm {d} t}},}
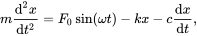
(1)
where m is the mass, x is the displacement of the mass from the equilibrium point, F0 is the driving amplitude, ω is the driving angular frequency, k is the spring constant, and c is the viscous damping coefficient. This can be rewritten in the form
-
d 2 x d t 2 + 2 ζ ω 0 d x d t + ω 0 2 x = F 0 m sin ( ω t ) , {\displaystyle {\frac {\mathrm {d} ^{2}x}{\mathrm {d} t^{2}}}+2\zeta \omega _{0}{\frac {\mathrm {d} x}{\mathrm {d} t}}+\omega _{0}^{2}x={\frac {F_{0}}{m}}\sin(\omega t),}
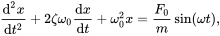
(2)
where
- ω 0 = k m {\displaystyle \omega _{0}={\sqrt {\frac {k}{m}}}}
 is called the undamped angular frequency of the oscillator or the natural frequency
- ζ = c 2 m k {\displaystyle \zeta ={\frac {c}{2{\sqrt {mk}}}}}
 is called the damping ratio.
Many sources also refer to ω0 as the resonant frequency. However, as shown below, when analyzing oscillations of the displacement x(t), the resonant frequency is close to but not the same as ω0. In general the resonant frequency is close to but not necessarily the same as the natural frequency. The general solution of Equation (2)is the sum of a trasient solution that depends on initial conditions and a stedy state solution that is independent of initial conditions and depends only on the driving amplitude F0, driving frequency ω, undamped angular frequency ω0, and the damping ratio ζ. The transient solution decays in a relatively short amount of time, so to study resonance it is sufficient to consider the steady state solution.
It is possible to write the steady-state solution for x(t) as a function proportional to the driving force with an induced phase change φ,
-
x ( t ) = F 0 m ( 2 ω ω 0 ζ ) 2 + ( ω 0 2 − ω 2 ) 2 sin ( ω t + φ ) , {\displaystyle x(t)={\frac {F_{0}}{m{\sqrt {\left(2\omega \omega _{0}\zeta \right)^{2}+(\omega _{0}^{2}-\omega ^{2})^{2}}}}}\sin(\omega t+\varphi ),}
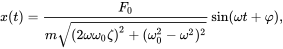
(3)
where
- φ = arctan ( 2 ω ω 0 ζ ω 2 − ω 0 2 ) + n π . {\displaystyle \varphi =\arctan \left({\frac {2\omega \omega _{0}\zeta }{\omega ^{2}-\omega _{0}^{2}}}\right)+n\pi .}
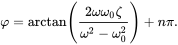
The phase value is usually taken to be between −180° and 0 so it represents a phase lag for both positive and negative values of the arctan argument.
 ) and damping ratio (ζ {\displaystyle \zeta }
 )
Resonance occurs when, at certain driving frequencies, the steady-state amplitude of x(t) is large compared to its amplitude at other driving frequencies. For the mass on a spring, resonance corresponds physically to the mass's oscillations having large displacements from the spring's equilibrium position at certain driving frequencies. Looking at the amplitude of x(t) as a function of the driving frequency ω, the amplitude is maximal at the driving frequency
ω r = ω 0 1 − 2 ζ 2 . {\displaystyle \omega _{r}=\omega _{0}{\sqrt {1-2\zeta ^{2}}}.} 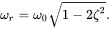
ωr is the resonant frequency for this system. Again, note that the resonant frequency does not equal the undamped angular frequency ω0 of the oscillator. They are proportional, and if the damping ratio goes to zero they are the same, but for non-zero damping they are not the same frequency. As shown in the figure, resonance may also occur at other frequencies near the resonant frequency, including ω0, but the maximum response is at the resonant frequency.
Also note that ωr is only real and non-zero if ζ < 1 / 2 {\displaystyle \zeta <1/{\sqrt {2}}}  , so this system can only resonate when the harmonic oscillator is significantly underdamped. For systems with a very small damping ratio and a driving frequency near the resonant frequency, the steady state oscillations can become very large.
Resonance of a pendulum
For other driven, damped harmonic oscillators whose equations of motion do not look exactly like the mass on a spring example, the resonant frequency remains
- ω r = ω 0 1 − 2 ζ 2 , {\displaystyle \omega _{r}=\omega _{0}{\sqrt {1-2\zeta ^{2}}},}
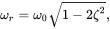
but the definitions of ω0 and ζ change based on the physics of the system. For a pendulum of length l and small displacement angle θ, Equation (1) becomes
- m l d 2 θ d t 2 = F 0 sin ( ω t ) − m g θ − c l d θ d t {\displaystyle ml{\frac {\mathrm {d} ^{2}\theta }{\mathrm {d} t^{2}}}=F_{0}\sin(\omega t)-mg\theta -cl{\frac {\mathrm {d} \theta }{\mathrm {d} t}}}
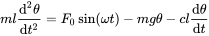
and therefore
- ω 0 = g l , {\displaystyle \omega _{0}={\sqrt {\frac {g}{l}}},}

- ζ = c 2 m l g . {\displaystyle \zeta ={\frac {c}{2m}}{\sqrt {\frac {l}{g}}}.}

Mode: – The mode is a statistical term that refers to the most frequently occurring number found in a set of numbers. The mode is found by collecting and organizing data in order to count the frequency of each result. The result with the highest count of occurrences is the mode of the set, also referred to as the modal value.
A mode shape is a specific pattern of vibration executed by a mechanical system at a specific frequency. Different mode shapes will be associated with different frequencies. The experimental technique of modal analysis discovers these mode shapes and the frequencies.
Modes are inherent properties of a structure and are determined by the material properties (mass, damping and stiffness) and boundary conditions of the structure. Each mode is defined by a natural (modal or resonant) frequency, modal damping and a mode shape (i.e. the so called Modal parameters).
whirling of shaft
The critical speed is the theoretical angular velocity which excites the natural frequency of a rotating object, such as a shaft. As the speed of rotation approaches the objects natural frequency, the object begins to resonate which dramatically increases systemic vibration. The resulting resonance occurs regardless of orientation.
When the rotational speed is equal to the numerical value of the natural vibration then that speed is called critical speed.
For a rotating shaft there is a speed at which, for any small initial deflection, the centrifugal force is equal to the elastic restoring force. At this point the deflection increases greatly and the shaft is said to "whirl". Below and above this speed this effect is very much reduced. This critical (whirling speed) is dependent on the shaft dimensions, the shaft material and the shaft loads.
All rotating shafts, even in the absence of external load, deflect during rotation. No shaft is perfectly straight and no shaft with attached masses is perfectly statically balanced such that the centre of gravity coincides with the axis of rotation.
At Morse Air Systems, we calculate the critical speed of our fan designs. We ensure the operation speed is at least 20 % either side of the calculated critical speed. This will result in the fan running well outside the "danger zone".
Geometry setup: -
- 2D sketch
- 3D model
STEPS FOR FEA SIMULATION
For doing FEA analysis in Solidworks make sure that the simulation is enable in Add ins of the Solidworks.
- Firstly, click on simulation option after that go to the new study option as mention in figure with the red colour.
- Now the select the type of analysis which you want to do like static, dynamic, frequency etc as shown in figure after that click on ok button. Here I am going to study for frequency analysis.
- Now you will enter in the window which you have selected for the analysis as shown in the figure below.
Now the option which we have to provide for doing analysis is highlighted with the red colour box in figure below. Both red colour box represents the same option.
- Now right click on part and select apply material option as shown in the figure below.
- After that one dialog box will appear, choose the material from the dialog box as per your requirement and click on apply button. Here I used alloy steel for the material. When you click on the apply option the colour of your design will change.
- Now right click on fixture option and select the type of fixture which you want in your design. Here I am using bearing fixture option to provide bearing support at the both faces of the shaft in order to make it bearing support and click on ok button.
- For meshing of the design we need to right click on mesh option and click on create mesh. After that there is two way to do meshing one is automatic and second is manual. Here I used for manual method and provide the size of mesh as 2 mm as shown in figure. Smaller the mesh size will give you more accurate result.
- Because of meshing, the design looks different from the previous figure as shown in figure.
- Now right click on the part and click on run option. The name may vary according to your design but to run the simulation we need to follow this step. When you click on run button it starts the simulation.
Results: -
|
Parameter |
Values |
|
Mesh size |
2 mm |
|
Total Nodes |
1484668 |
|
Total Elements |
1057994 |
|
Material |
Alloy steel |
There is different mode shape after frequency simulation
Mode 1. Minimum and Maximum amplitude are 0.04 and 1.881.
Mode 2. Minimum and Maximum amplitude are 0.002 and 1.881.
Mode 3. Minimum and Maximum amplitude are 2.12 x 10⁻⁵ and 3.457.
Mode 4. Minimum and Maximum amplitude are 0.264 x 10⁻³ and 2.533.
Mode 5. Minimum and Maximum amplitude are 1.382 x 10⁻³ and 2.534.
Resonant frequencies: -
Conclusion: -
- The mode shape which I obtain is not same it varies in all direction as shown in the figure.
- The frequency obtain is greater than resonance frequency.