Final Project: Electric Rickshaw modelling
OBJECTIVES:
Create a detailed MATLAB model of an electric rickshaw (three-wheel passenger vehicle) as per the details below:
- Rear wheels driven by PM brushed type motor
- Assume efficiency points of motor controller and motor
- Make an excel sheet of all input and assumed data
- Results: For any three standard driving cycles show energy consumption, the temperature rise of the motor and controller for 100 km constant speed driving at 45 kmph.
METHODOLOGY:
- Identify what amount of propulsion power is required.
- To design any vehicle 1st we have to calculate propulsion power then the motor is selected.What is the best suitable motor for that propulsion power, here we have to use PM brushed motor.
- Then type of battery and range of battery according to the range.
- The electric vehicle consists of a battery, motors, and controller then it generates propulsion power.
- Lastly based on the motor rating or operating range and no km/charge we want to depend on everything battery capacity and then battery capacity is selected.
INTRODUCTION:
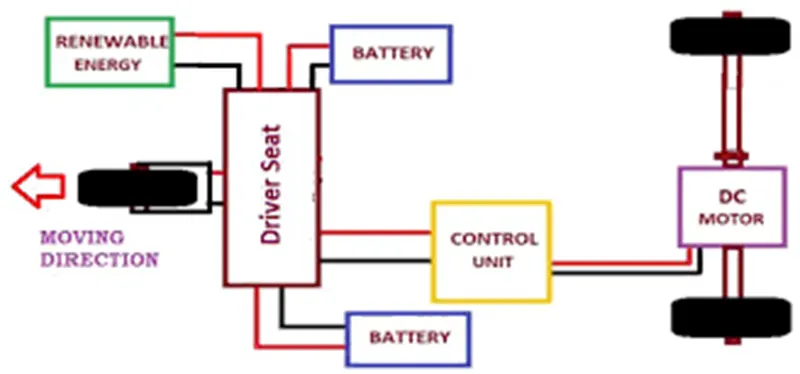
- Electric E-Rickshaw is also known as auto which are going more popular after 2017 in the Indian market. This E-rickshaw is the best alternative to petrol/CNG auto-rickshaw and human or horse-pulled rickshaws because of their low fuel cost, zero emissions and less human efforts.
- The electrical system used in the Indian version is 48VDC can run 90-100 km/full charge, top speed 25 km/hour and this electric motor power ranging from 650-1400 Watts: the battery takes 8-10 hrs to become fully charged. Basic seating capacity is driver plus 4 passengers total of 5 persons.
Modeling:
- Here basically, e-rickshaw is designed in CREO and MATLAB Simulink In the designed electric rickshaw main blocks are battery, drive cycle, controlled, DC Motor, Vehicle body and transmission system. Drive cycle is the input of human effort that how he is going to drive his actual cycle We can use dive cycle like FTP75, WOT or by using Excel
- The main objective of this project is to obtain speed by the driver, to estimate the temperature of the motor and controller, to estimate the state of charge (SOC) and distance travel by the vehicle. There is a SOC block that will estimate the state of charge of the battery, distance is calculated by speed and time parameter for all the three Drive cycle.
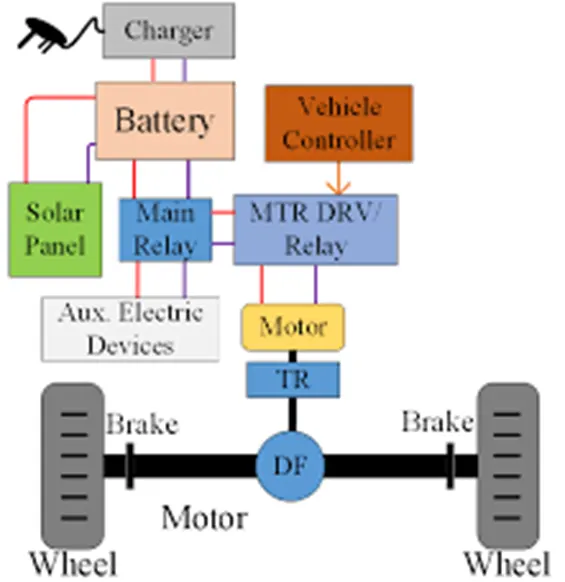
- The body design is varied from load carriers, passenger vehicles with no roof, to full body with windshield for drivers comfort. It consists of a controller unit. They are sold on the basis of voltage supplied and current output, also the number of MOSFET (metal oxide field-effect transistors) used. The battery used is mostly a lead-acid battery with a life of 6-12 months. Deep cycle batteries designed for electric vehicles are rarely used. The weight of the electric car has also been a recurring design difficulty in them.
Parameters Assumptions:
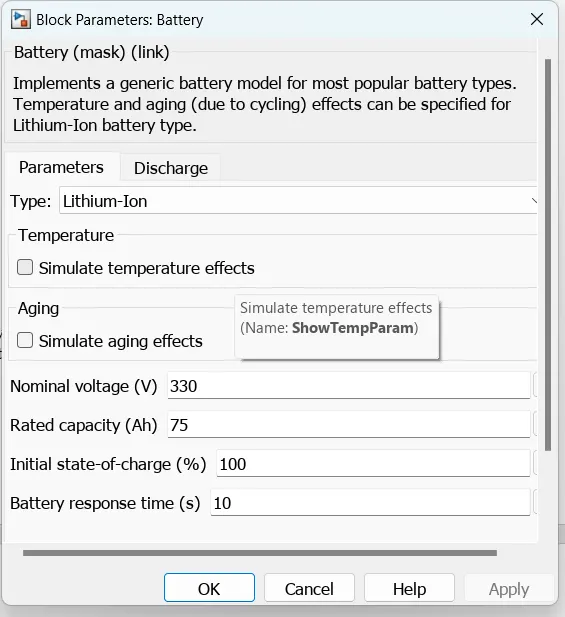
- Battery Type Lithium-ion 330 V 75
- Vehicle kerb weight 260 kgs
- Load capacity 340 kgs
- Vehicle speed 7 kmph
- Driving range 140 km (160 Ah)
- No of wheels per axel 2
- Frontal Area 91m
- Drag coefficient 5
- Wheel radius 306m
- Vertical load 3000 N
- Nominal Voltage 330 V
- Rated capacity 75Ah
- Initial SOC 100 %
- Internal Resistance 5 ohm
Full model:
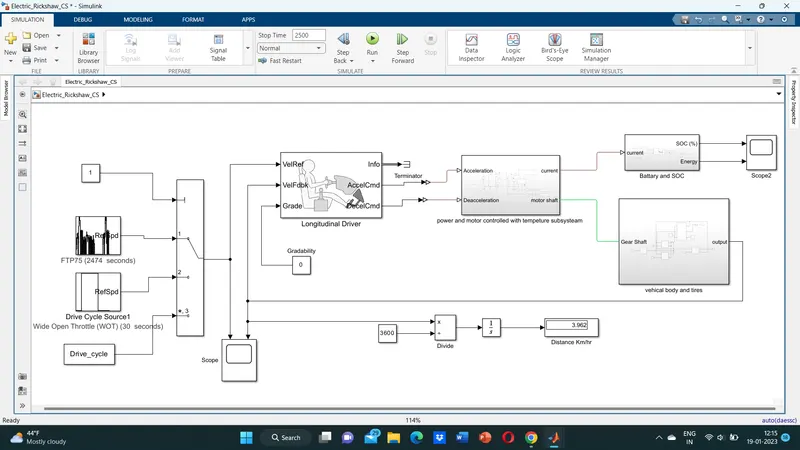
- Initially the current flow to DC Motor from the battery through the DC-DC power converter to drive the motor. The required voltage will be controlled in the controller. The Controller will follow the given drive cycle reference and run the motor in the required rpm
- Then the motor power is transmitted to the wheels of a vehicle through the gearbox and the controller will take the vehicle speed and compare and control.
Procedure:
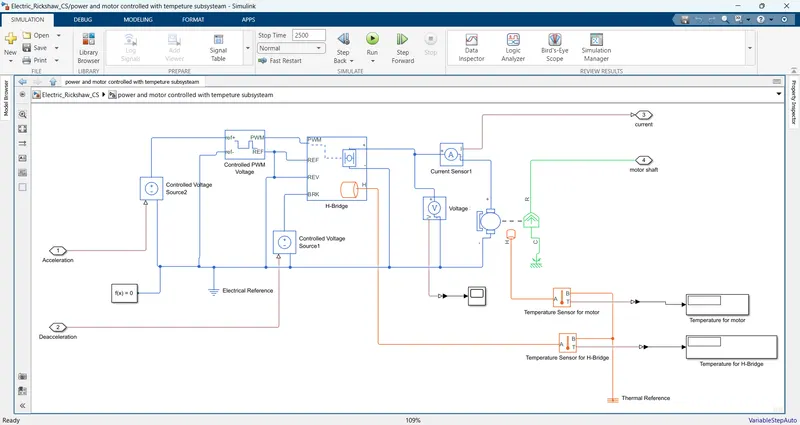
Power and Motor Controlled Subsystem Model ( With Temperature Senor)
H-Bridge:
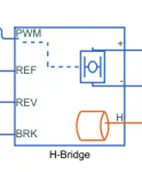
This block represents an H-bridge motor drive. The block can be driven by the Controlled PWM Voltage block in PWM or Averaged mode. In PWM mode, the motor is powered if the PWM port voltage is above the Enable threshold voltage
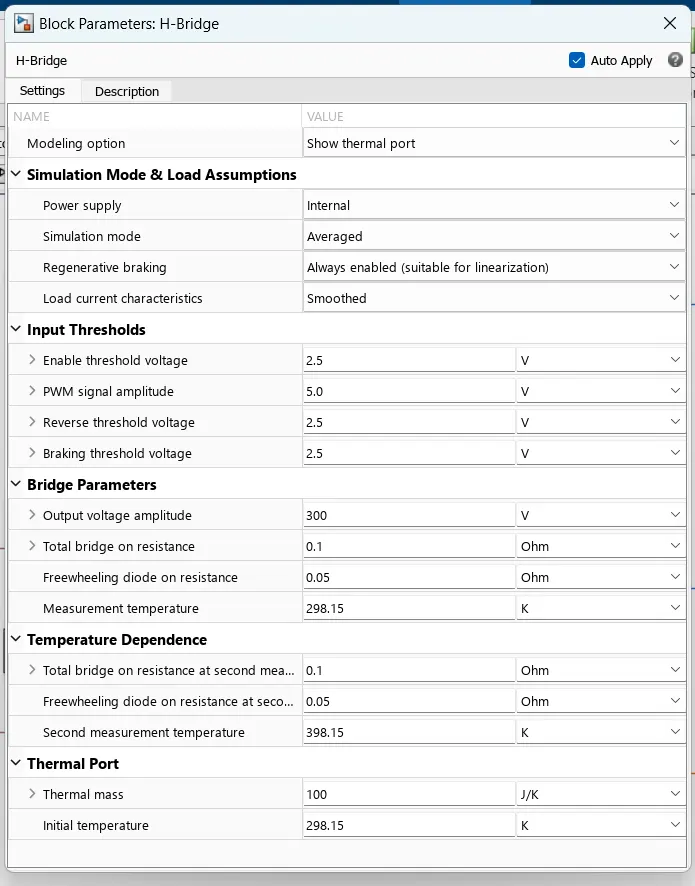
In Averaged mode. The PWM port voltage divided by the PWM signal amplitude parameter defines the ratio of the on-time to the PWM period. Using this ratio and assumptions about the load, the block applies an average voltage to the load
That achieves the correct average load current. The Simulation mode parameter value must be the same for the Controlled PWM Voltage and H-Bridge block.
- If the REV port voltage is greater than the Reverse threshold voltage, then the output voltage polarity is reversed.
- If the BRK port voltage is greater than the Braking threshold voltage, then the output terminals are short-circuited via one bridge arm in series with the parallel combination of a second bridge arm and a freewheeling diode.
- Voltages at ports PWM, REV and BRK are defined relative to the REF port. If exposing the power supply connections, the block only supports PWM mode.
Parameters:
DC Motor:
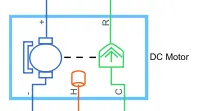
- This block represents the electrical and torque characteristics of a DC motor includes Thermal port to series the temperature of Motor
- The block assumes that no electromagnetic energy is lost, and hence the back emf and torque constants have the same numerical value when in Si units Motor
- Motor parameters can either be specified directly or derived from the no-load speed and stall torque. If no information is available on armature inductance, this parameter can be set to some small non-zero value.
- When a positive current flows from the electrical to-ports, a positive torque acts from the mechanical C to R ports. Motor torque direction can be changed by altering the sign of the back-emf or torque constants.
- The Motor controller will get input from the longitudinal driver. Its tasks are to control the speed of the motor and drive according to the input of the driver.
- Majorly motor controlled we designed had two main parts named PWM voltage generator and H-Bridge Input 1 is getting from the accelmd of a longitudinal driver and it is given to a controlled voltage source block where it is input to the controlled PWM voltage will generate a PWM signal in such a way that H-bridge will generate the required voltage to operate the DC motor for the given driver input
- PWM voltage block negative reference and REF are grounded and REF of H bridge respectively. H-bridge is a motor controller that has IGBT components aligned in the shape of H and will operate only two at a time respectively to the input of the signal from the PWM block.
- When deceleration occurs this H-bridge will give an output from the positive and negative terminals of it. These negative & positive terminals are later connected to the DC motor and battery. All these components are the simscape electrical components so they need a connection to the solver configuration block which helps to solve the simulation.
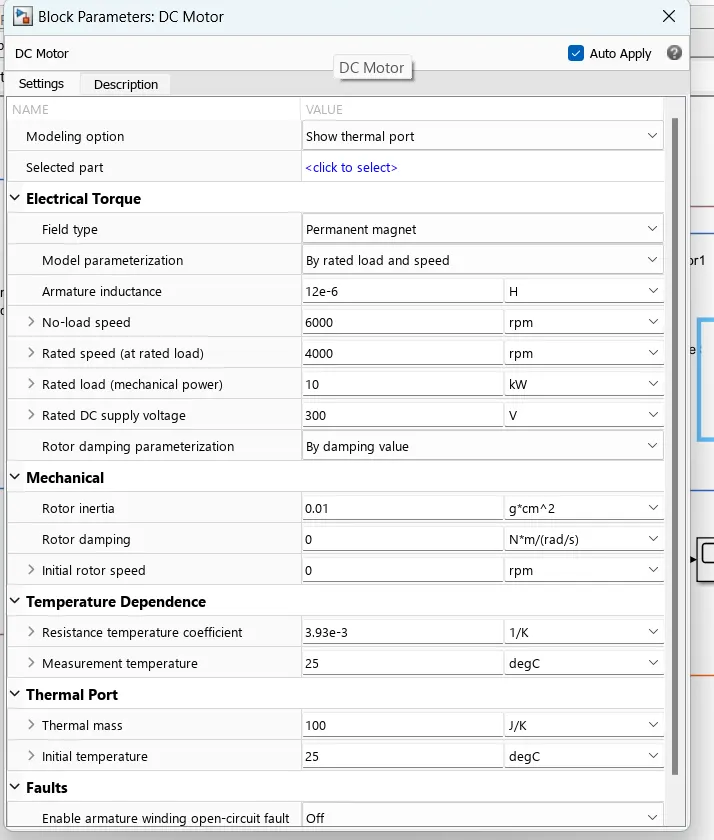
Parameters:
Controlled PWM Voltage:
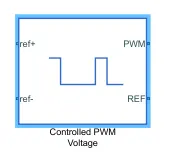
- This block creates a Pulse-Width Modulated (PWM) voltage across the PWM and REF ports. The output voltage is zero when the pulse is low and is equal to the Output voltage amplitude parameter when high.
The duty cycle is set by the input value. Right-click the block and select Simscape Block choices to switch between electrical ref/-ref ports and PS input u to specify the input value.
At time zero, the pulse is initialized as high unless the duty cycle is set to zero or the Pulse delay time is greater than zero.
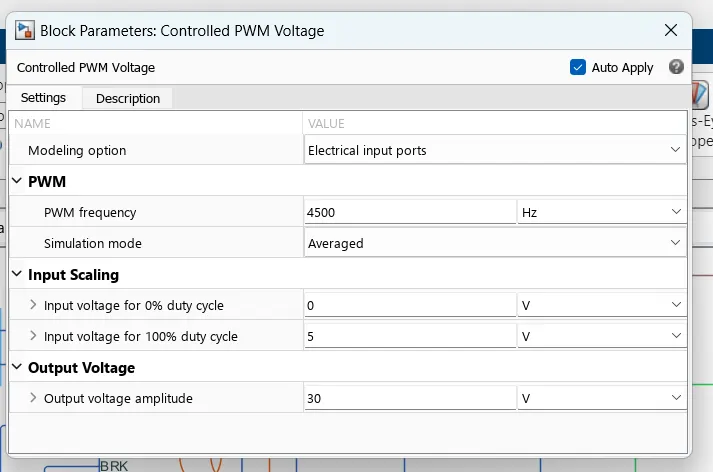
The Simulation mode can be set to PWM or Averaged. In PWM mode, the output is a PWM signal. In Averaged mode, the output is constant with a value equal to the averaged PWM signal. Select Simulation mode as Averaged.
Parameters:
Temperature Sensor:
- Temperature Sensor is used to measure the temperature of the H-Bridge and Motor.
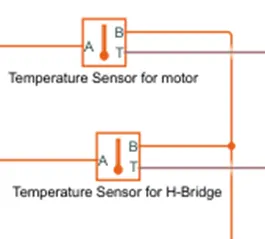
This block measures temperature in a thermal network. There is no heat flow through the sensor. The physical signal port T reports the temperature difference across the sensor.
The measurement is positive when the temperature at port A is greater than the temperature at port B.
Solver Configuration:
Defines solver settings to use for simulation.
Vehicle Body and Tire Subsystem Model:
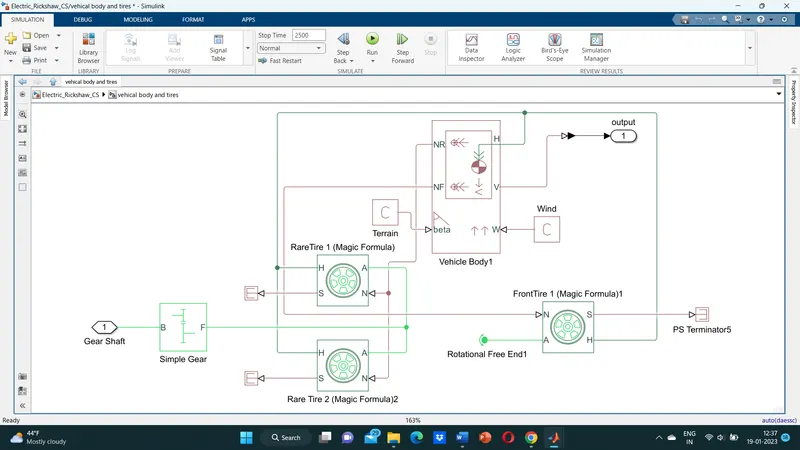
- Motor will produce the rotational output which will give to the vehicle body and transmission system. The rotational output is taken by the gear system here to maintain the constant speed throughout the transmission without any loss in speed from the motor to tires.
- Below is a diagram that is how it is inside the vehicle body and transmission system and in the main design, it is referred just only as a transmission system. Here I created a Rear-wheel drive transmission system.
- The gear output is given to axels of Rear tires in the circuit it is shown that gear is connected to Rear wheels and the front tire is free to rotational motion, thus the vehicle moves forward. N is the normal force caused by the tires and it is given to the vehicle body normal force port.
- The vehicle body has an H-Hub, S- Tire slip, N-Normal force. As axel connection, wind velocity, inclination angle. The tires hub is connected as a common node to the vehicle body.
- The vehicle body wind velocity is connected to a constant block and the beta-inclination angle is connected to another constant block where we can assign wind velocity and inclination angle as per requirement. Velocity is the output port where we can get at which speed the vehicle is moving. The velocity is taken out to get the distance travelled and state of charge.
Vehicle Body:
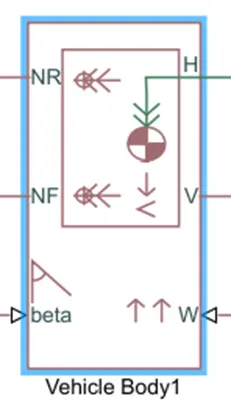
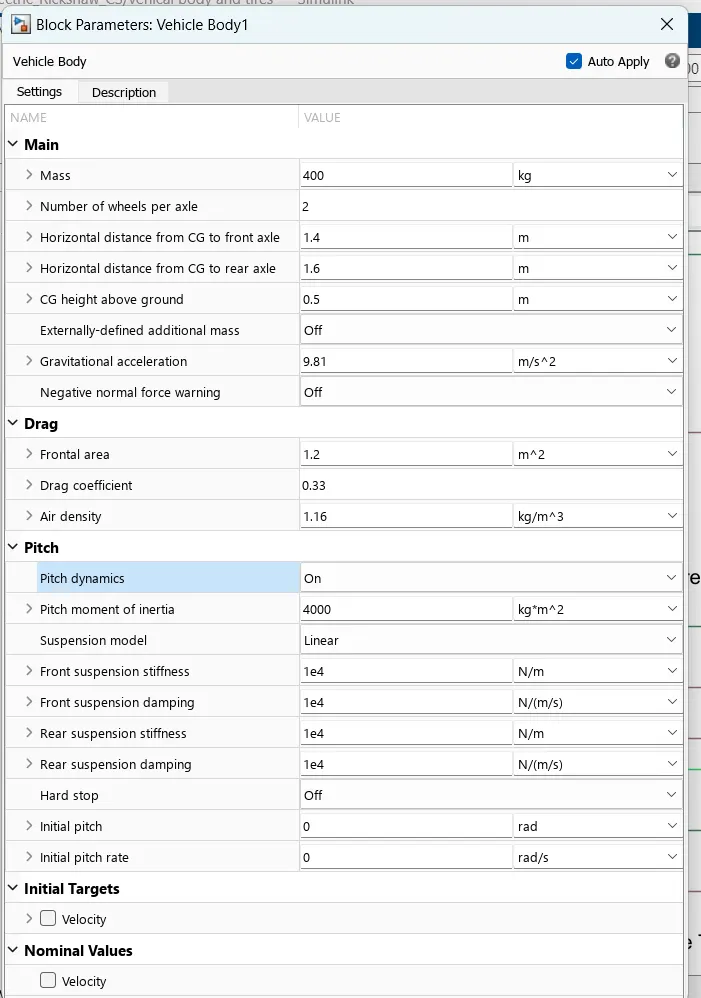
- This 2 axle (3 wheel) assebly is now connected to a Velocity Body simscape block.
- This block basically represents a two-axle vehicle body in longitudinal motion.The block accounts for -
body mass,aerodynamic drag,road incline,weight distribution between axles due to acceleration road profile. - Here, the connection H is the mechanical translational conserving port hub.
NF & NR correspond to the output ports for nomral reaction forces on front axle and rear axle wheels respectively.
Connection V represents the actual output translational velocity of the vehicle.
Beta is the road inclination angle & W corresponds to the headwind speed.
Parameters:
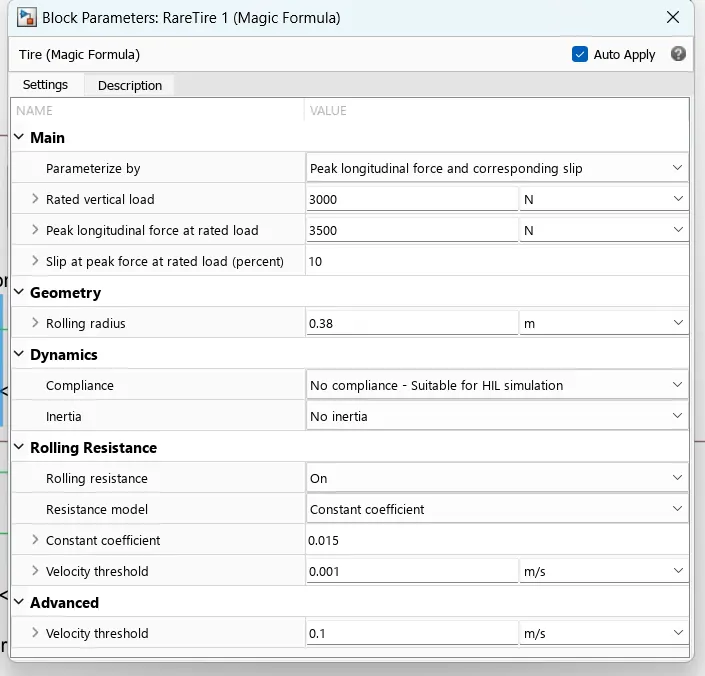
Tire:
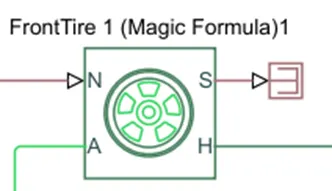
The N port of the tire corresponds to the Normal Reaction acting on it.
The A port corresponds to the Mechanical Rotational conserving port for the wheel axle. Thus both the wheels on the same axle should form a connection through their respective A ports.
Connection H corresponds to the Mechanical Translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Thus, all the 4 wheels form a connection through their respective H ports and this is in turn connected to the translational hub of the vehicle body.
The connection S represents the output port for slip of the tire.
Parameters:
Simple Gear:
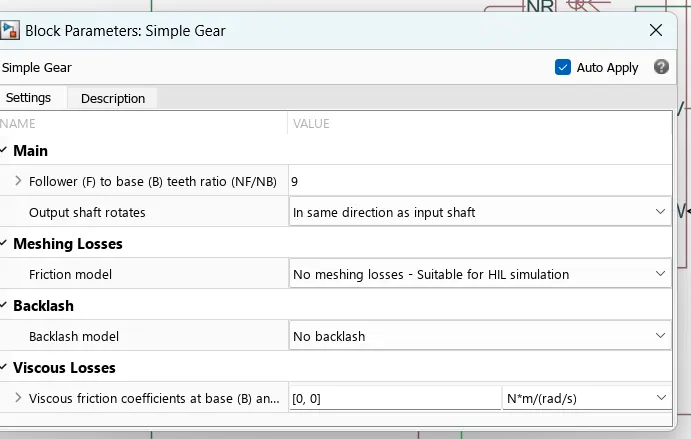
The input for this subsystem is taken as the Rotational speed of the motor. This input is fed to the front axle through a Simple Gear representing the Final Drive Ratio of 2
Here, the rotational direction of the output shaft is kept the same as that of the input shaft. Also, no meshing losses are considered for the simulation.
Parameters:
Batery and SOC Sub block:
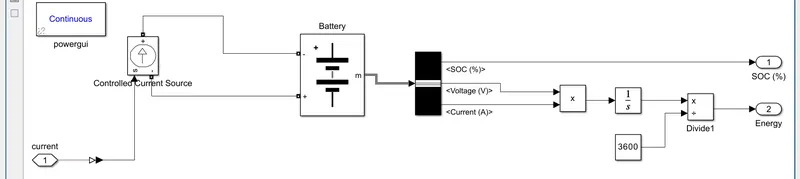
Battery Pack :To model the Battery pack, a generic battery block is used.
This battery(Type:LI) is the most popular battery types. Temperature and aging (due to cycling) effects can be specified for Lithium-Ion battery type.Also, the temperature and the battery aging are disabled.
Parameter:
BUS Selector:
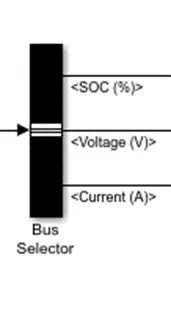
The Bus Selector block outputs the signals you select from the input bus The block can output the selected elements separately or in a new virtual bus
Here just we have mange the output and connect it with different Scope Block.
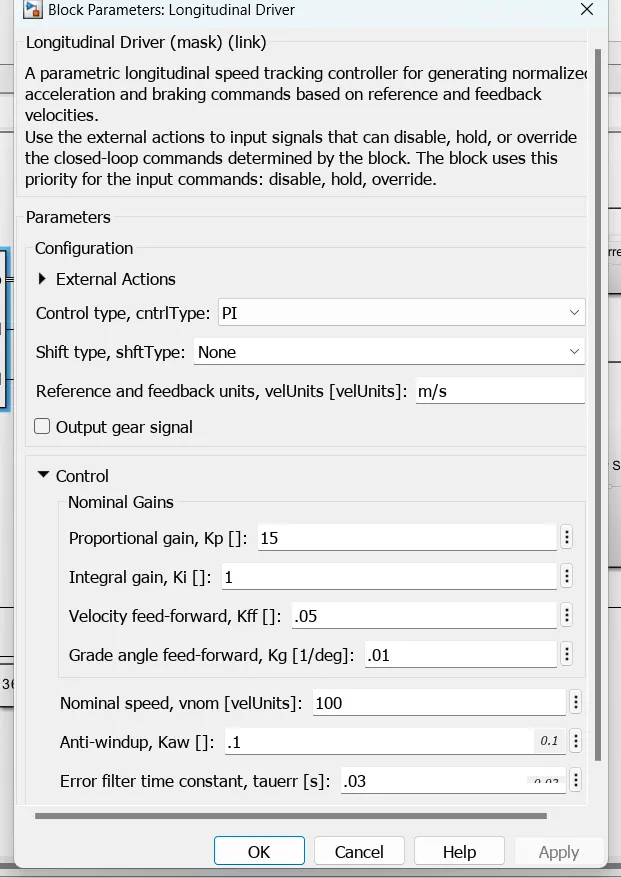
Longitudinal Driver :From powertrain blockset
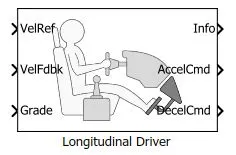
- It is a parametric longitudinal speed tracking controller for generating normalized Acceleration and Braking commands based on reference and feedback velocities.
- VelRef port is the reference velocity port where the input drive cycle data is fed.
- VelFdbk port corresponds to the feedback velocity. The actual velocity output given by the vehicle body is connected here. By comparing the actual (feedback) velocity with the reference velocity, the driver block generates acceleration and braking signals in order to minimise the error between the two concerned velocities.
- Grade is the hill climbing angle. For this simulation, no inclination is considered and hence, a constant block with value 0 is connected.
- Info gives calculations like difference in reference vehicle speed and vehicle speed.
- AccelCmd & DecelCmd correspond to the acceleration and deceleration commands generated respectively and connected to the corresponding ports of the Controlled PWM Voltage block.
Parameters:
Reference velocity (Drive cycle) :
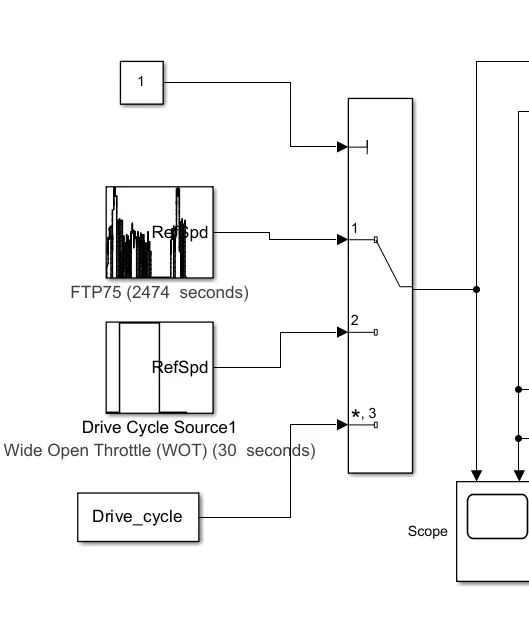
- Drive cycle is assumed as the driver's input of a vehicle, it replaced how a driver will drive a vehicle. Here I have used three drive cycles which are used to test the vehicle performances.
- These drive cycles will have high-speed low speed braking conditions in it.
- There are different drive cycles like WOT FTP75 etc. Here in this model I have used FTP 75 WOT & Manically prepared in excel Drive Cycle source.
Results:
For FTP75 Drive Cycle:
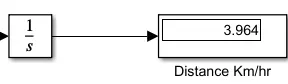
By running the Vehicle with F1P75 Drive cycle for 2500 see the distance travelled is 3.964 km
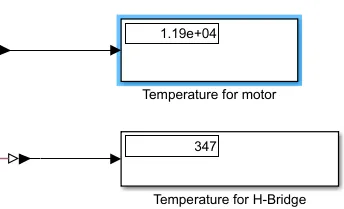
The Temperature of Motor is increased to 1.19e+04 K.
The Temperature of Controller is 347K.
Plots:
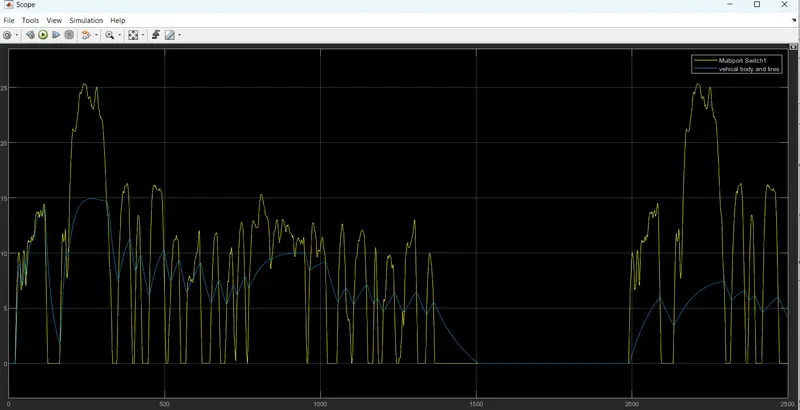
The actual Speed is approximately followed the 90% of reference Drive cycle.
- As can be seen from the above picture, the actual velocity of the vehicle differs from the reference drive cycle velocity.
- This is because, the chosen battery capacity and motors are not able to propel the speed upto the required extent.
- If a battery of higher capacity is chosen, the actual velocity will tend to match with the reference velocity.
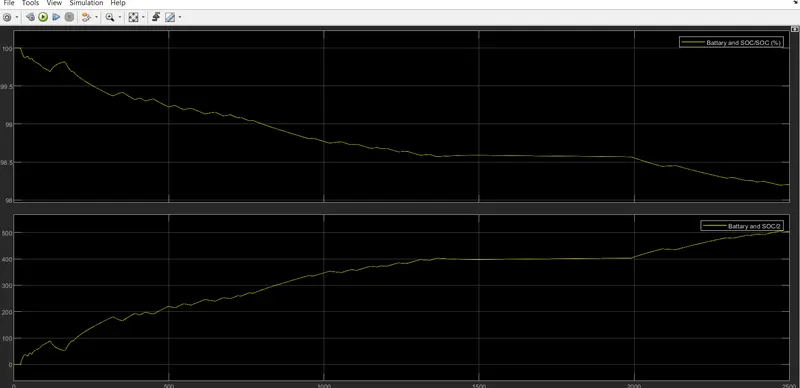
- The State-of-Charge of the battery at the end of simulation run is nearly about 98 %. Only 2% Battery is used for 3.064 km
- This means that the battery is not completely drained at the end and the vehicle can run on the same drive cycle for a more times before the battery SOC becomes 0.
- Also, the thing to be noted here is, since we had enabled the regenerative braking for the simulation, the battery SOC increases slightly whenever the vehicle undergoes heavy deceleration.
For WOT Drive Cycle:
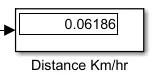
By running the Vehicle with WOT Drive cycle for 30 sec. the distance travelled is 0.06186km
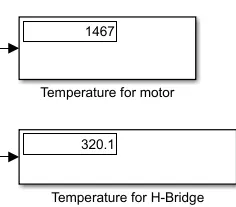
The Temperature of Motor is increased to 1467k.
The Temperature of Controller is = 320k.
Plots:
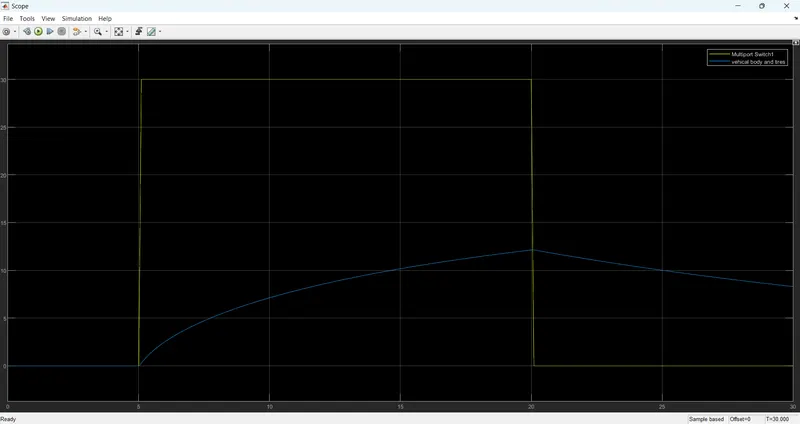
The actual Speed is approximately followed the 35% of reference Drive cycle
- As can be seen from the above picture, the actual velocity of the vehicle differs from the reference drive cycle velocity.
- This is because, the chosen battery capacity and motors are not able to propel the speed upto the required extent.
- If a battery of higher capacity is chosen, the actual velocity will tend to match with the reference velocity.
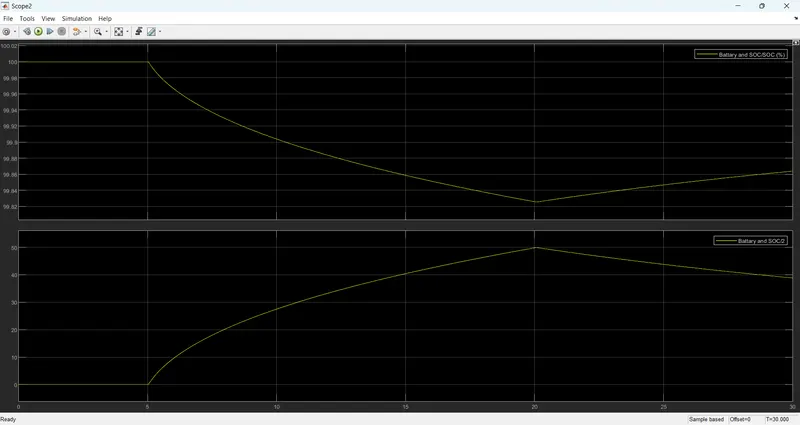
The SoC% of the battery is reduced to 99.6% till 20 sec after that the battery get charged by by back EMF.
For Manually prepared Drive Cycle:
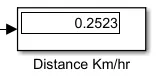
- On running the Vehicle with Manually prepared Drive cycle for 120 sec the distance travelled is 0.2523km
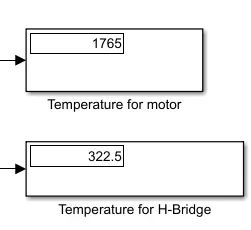
The Temperature of Motor is increased to 1765k.
The Temperature of Controller is 322.5k.
Plots:
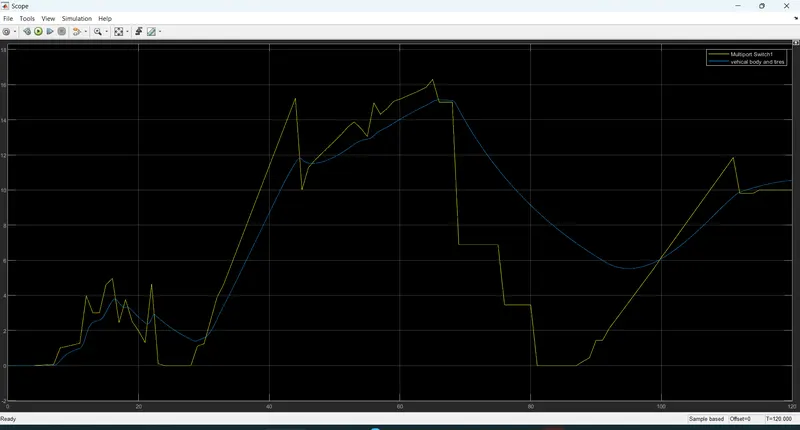
The actual path of the speed is approximately followed the of reference Drive cycle as above.
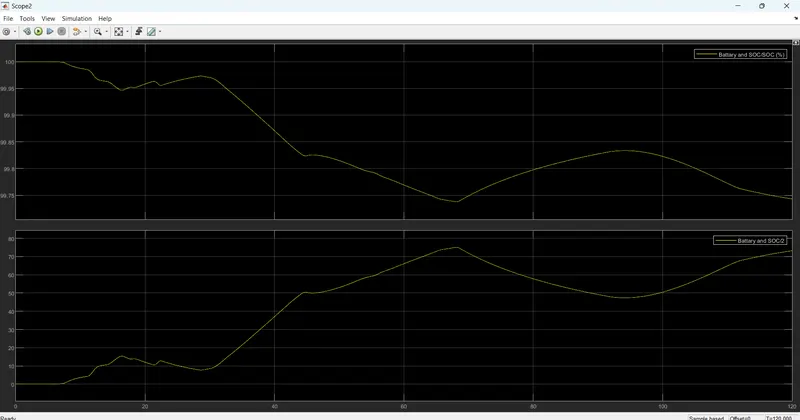
The SoC% of the battery is reduced to = 99.75 %.
CONCLUSION:
- Here I have compromised with the temperature of Motor and controller to achieve vehicle speed is near to reference speeds. Since I haven't used any cooling system in the model. In the real time application, the motor temperature is less than 100 C
- In the real time application, the motor, battery & controller temperature is controlled by air cooling. Hence, the temperature of this components is not increased to this extent.
- Hence. Created a MATLAB model of an Electric Rickshaw (three wheel passenger vehicle) by using Li-ionbattery, PM Brushed DC Motor.
- Detremined the variations of Temperature of Motor and controller, SoC% and Energy consumed by the by vehicle for all the three Reference Drive cycles (.e: FTP75, WOT, Manually prepared).
- This Battery powered Rickshaw will be the most popular mode of transport in the future.
Note: I have Latest version hence many time they will ask for old version hence converted but not sure it will run or not, providing you the screenshort.